

方向盘和横向位置参数的相互关系:对驾驶性能评估的建议
Jinhui Xu1, Mohammad Fard1, Neng Zhang1
1School of Engineering, RMIT University, Australia.
Journal of safety research
|March 14, 2024

概括
驾驶性能评估可以通过选择独立的参数来改进. 转向角度的最佳组合是平均转向角度 (ASA) 和转向角度范围 (SAR),而对于横向位置,横向位置的标准偏差 (SDLP) 和车道外持续时间.
科学领域:
- 人类因素 人类因素
- 汽车工程 汽车工程
- 道路交通安全 道路交通安全
背景情况:
- 司机注意力丧失是道路交通事故的主要原因之一.
- 基于车辆的参数,如方向盘角度和横向位置,客观地评估驾驶性能,特别是在单调的任务中.
研究的目的:
- 为了确定八个常用的驾驶性能参数的独立性.
- 为准确的驾驶评估确定最佳参数组合.
主要方法:
- 15名参与者在模拟器上执行了一小时的单调高速公路驾驶任务.
- 八个参数 (四个转向角度,四个横向位置) 通过相关性和多对线性测试进行了分析.
主要成果:
- 几个参数高度相关,表明它们不应该同时使用.
- 推的最佳组合:用于转向的ASA和SAR;用于横向位置的SDLP和出轨.
- 车道外持续时间与其他参数的相关性很小,这使得它成为一个强有力的指标.
结论:
- 选择独立的参数可以提高驾驶性能的评估.
- 推的参数组合可以改善未来的驾驶研究和道路安全评估.

相关概念视频
 01:22
Controller Configurations
96
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
96
 01:27
Curvilinear Motion: Normal and Tangential Components
398
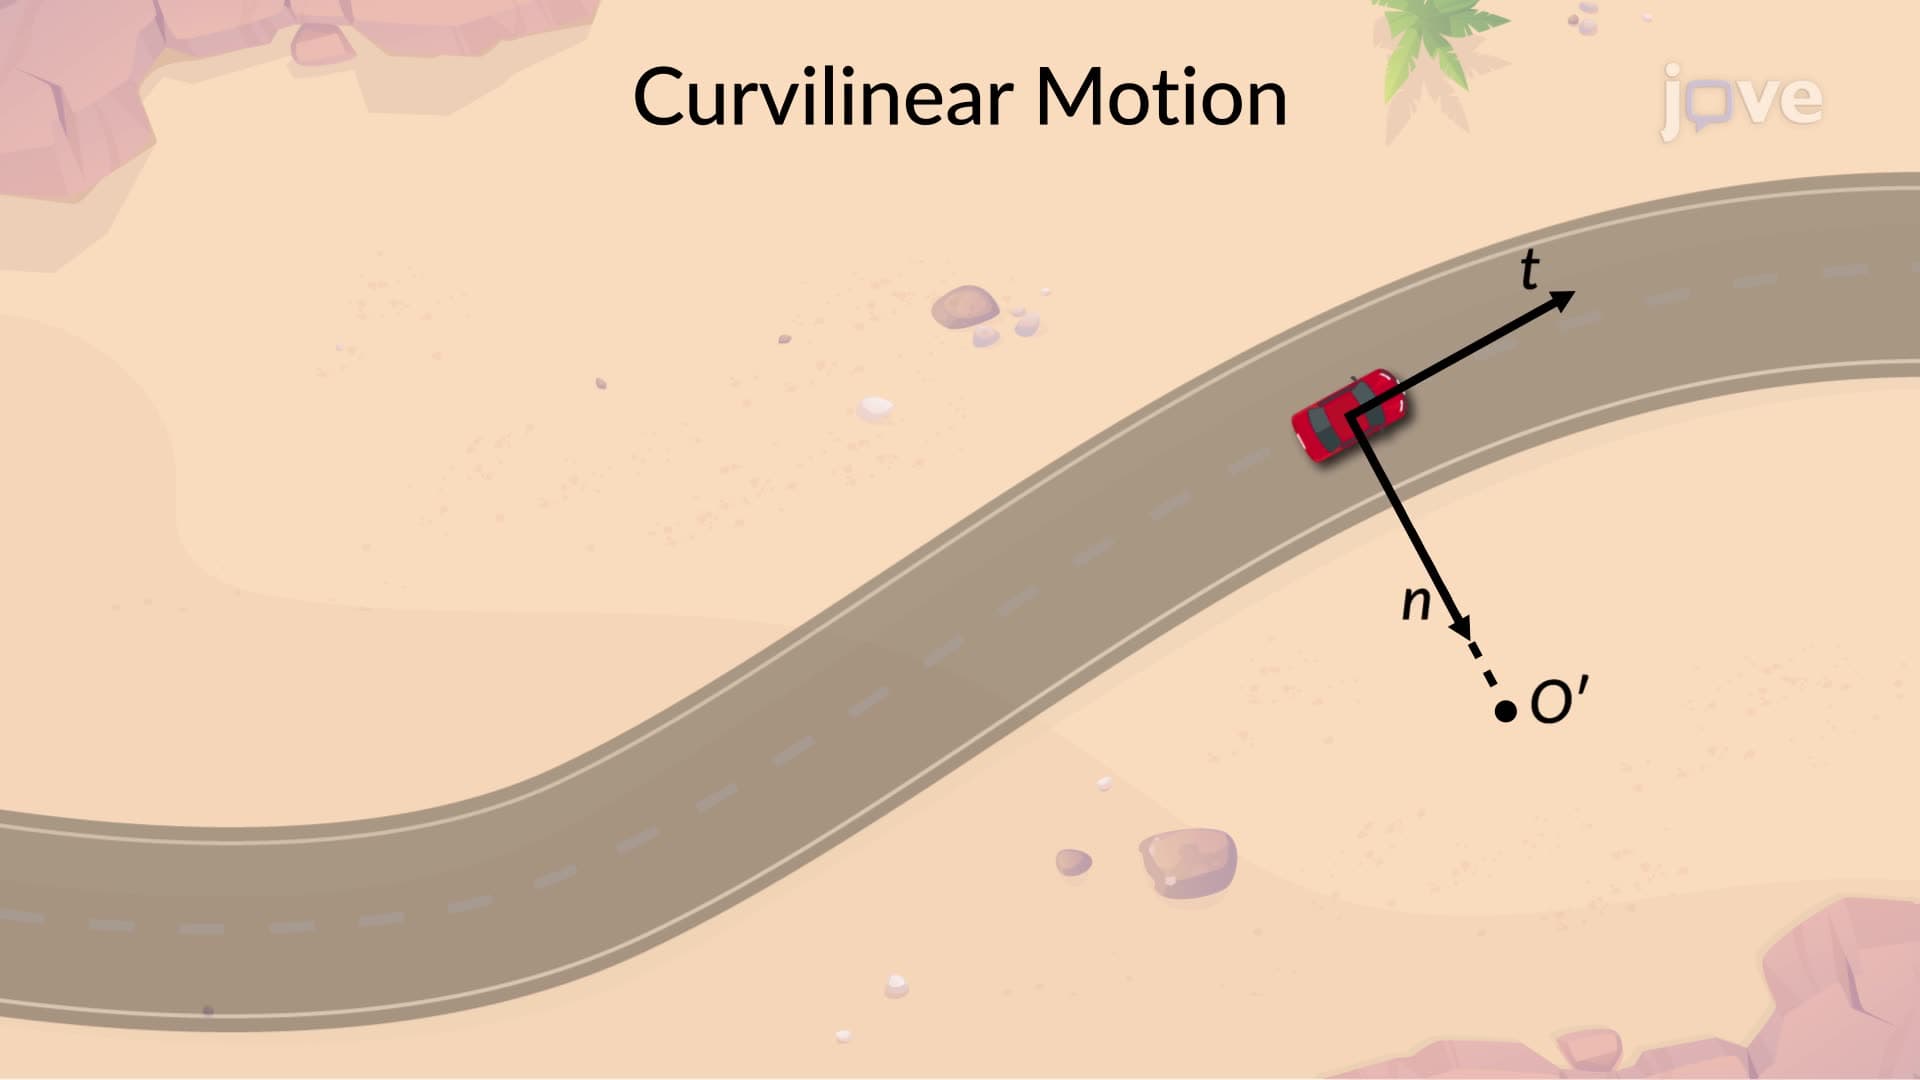
When a car traverses a curved road, its motion can be elucidated by breaking it down into tangential and normal components. The car-centric coordinates attached to the vehicle move with it.
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
398
 01:23
Curvilinear Motion: Rectangular Components
454
Curvilinear motion characterizes the movement of a particle or object along a curved path, notably evident when envisioning a car navigating a winding road. If the car starts at point A, its position vector is established within a fixed frame of reference, where the ratio of the position vector to its magnitude signifies the unit vector pointing in the position vector's direction.
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
454
 01:18
Hierarchy of Motor Control
2.7K
The hierarchy of motor control refers to the different levels of organization and processing involved in controlling movement in the body. These levels range from higher cortical areas involved in planning and decision-making to lower spinal cord reflexes that respond automatically to external stimuli.
2.7K
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
335
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
335
 01:19
Root-Locus Method
148
A cruise control system in a car is designed to maintain a specified speed automatically by adjusting the gas pedal. The system continuously measures the vehicle's speed and makes fine adjustments to the pedal to achieve this goal. The root locus method is particularly useful for understanding how the cruise control system's behavior changes under varying conditions, such as when the car goes uphill, downhill, or faces strong wind resistance.
This system can be represented by a block...
This system can be represented by a block...
148