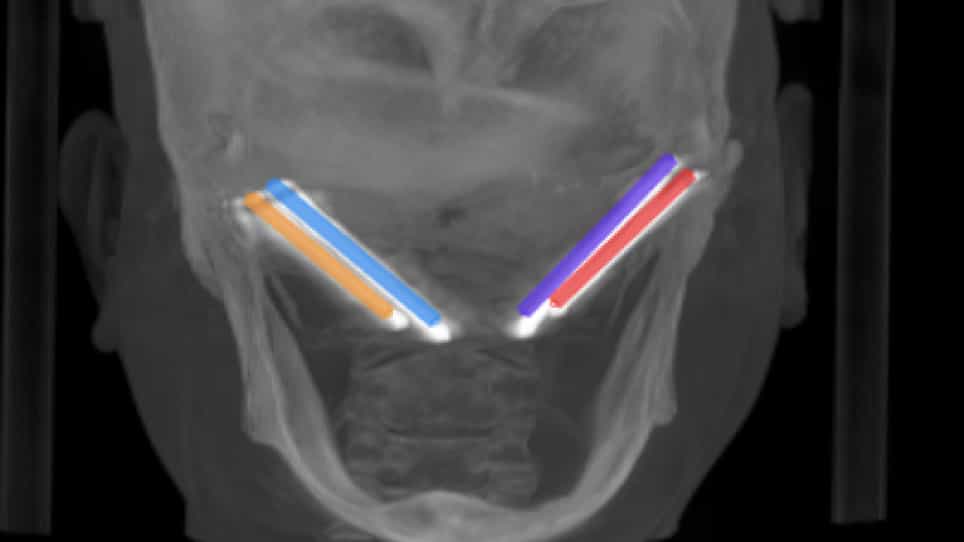
与静态引导和动态导航系统对机器人引导牙植入物放置的位置精度的比较:系统性审查和元分析
Madiha Khan1, Faizan Javed1, Zainab Haji1
1Operative Dentistry and Endodontics, Section of Dentistry, Department of Surgery, Aga Khan University Hospital, Karachi, Pakistan.
The Journal of prosthetic dentistry
|March 15, 2024

概括
机器人计算机辅助植入体手术 (r-CAIS) 与数字计算机辅助植入体手术 (d-CAIS) 相比,显示出更高的位置精度. 需要进一步的研究来比较r-CAIS与静态计算机辅助植入体手术 (s-CAIS).
科学领域:
- 牙科植入物学 牙科植入物学
- 机器人手术 机器人手术
- 手术导航 手术导航
背景情况:
- 机器人计算机辅助植入体手术 (r-CAIS) 的出现带来了潜在的好处.
- 然而,与其他指导手术方法相比,其位置准确性仍未得到充分理解.
研究的目的:
- 系统地审查和元分析r-CAIS的位置精度.
- 为了比较r-CAIS与静态 (s-CAIS) 和数字 (d-CAIS) 计算机辅助植入体手术的位置精度.
主要方法:
- 对五个数据库进行了全面的系统搜索,并通过手动搜索进行了补充.
- 包括的研究评估了r-CAIS的位置精度,并使用Cochrane工具 (临床) 和QUIN工具 (体外) 评估偏差风险.
- 一项元分析特别比较了r-CAIS与d-CAIS的位置精度.
主要成果:
- 分析了13项研究 (9项试验室,4项临床),涉及920种植入物.
- 在6项研究中发现了偏差的高风险;在7项研究中,偏差低至中等.
- 机器人计算机辅助植入体手术 (r-CAIS) 在冠状,顶端和角偏差 (P<.001对所有) 中表现出明显更高的精度,而不是数字计算机辅助植入体手术 (d-CAIS).
结论:
- 机器人计算机辅助植入体手术 (r-CAIS) 与数字计算机辅助植入体手术 (d-CAIS) 相比,提供了更高的位置精度.
- 目前没有足够的证据来比较r-CAIS与静态计算机辅助植入体手术 (s-CAIS) 的位置精度.
- 由于数据有限和研究偏见,研究结果应谨慎解释.
相关概念视频
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Vector Functions and Motion: Problem Solving
Accurate position tracking is fundamental to the safe and effective operation of unmanned aerial vehicles (UAVs), particularly during precision maneuvers near complex structures. In this scenario, a drone is programmed to perform a high-precision inspection of a vertical structure, starting at position ((x, y, z) = (3, 0, 0)), with an initial velocity oriented in the positive z-direction. The trajectory of the drone is governed by a time-dependent acceleration function a(t), which is predefined...