TAT-HUM:在Python中用于人类运动的轨迹分析工具包
相关实验视频
Updated: Jun 30, 2025

16:14
Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
13.5K
Xiaoye Michael Wang1, Timothy N Welsh2
1Centre for Motor Control, Faculty of Kinesiology & Physical Education, University of Toronto, Toronto, Ontario, Canada. michaelwxy.wang@utoronto.ca.
Behavior research methods
|March 20, 2024

概括
本研究介绍了一个用于分析人类运动轨迹的Python工具包,简化了从复杂的运动数据中提取行为见解. 该工具包为离散快速定位运动提供自动和手动分析选项.
科学领域:
- 生物力学 生物力学
- 人类运动分析 人类运动分析
- 计算神经科学是一种神经科学.
背景情况:
- 人类运动轨迹为行为机制提供了洞察力.
- 分析复杂和动态的运动数据带来了重大挑战.
- 现有的方法可能缺乏灵活性,以满足不同的轨迹分析需求.
研究的目的:
- 介绍一种新的Python工具包,用于分析人类运动轨迹.
- 为从离散的快速定位运动中提取有意义的信息提供工具.
- 为了促进更容易和更灵活的动力学分析的人类运动.
主要方法:
- 使用开源库 (NumPy,SciPy) 开发一个Python工具包.
- 实现自动化 (原始数据处理) 和手动 (选择性功能使用) 分析方法.
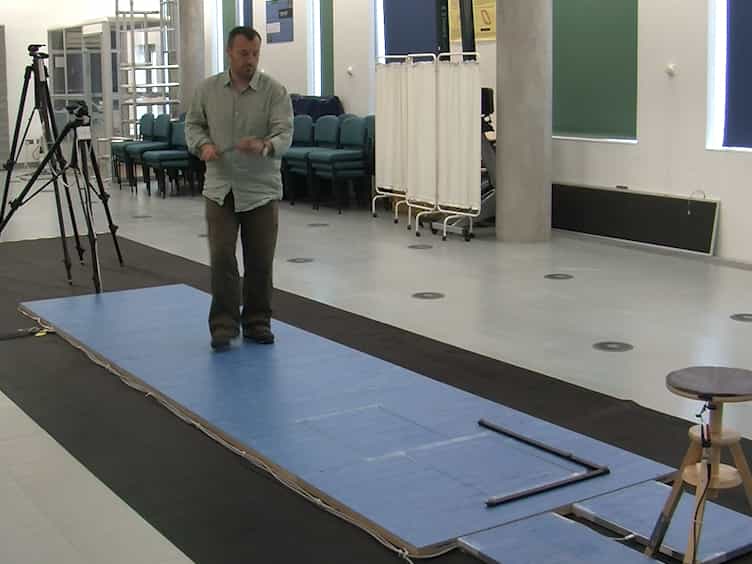
- 通过使用空间暗示范式的行为实验进行验证.
主要成果:
- 该工具包成功分析了人类运动轨迹数据.
- 自动化方法有效地产生相关的动力学测量.
- 手动方法为特定的分析需求提供了用户控制的灵活性.
结论:
- 介绍的Python工具包增强了对人类运动轨迹的分析.
- 它为研究人类行为和动力学的研究人员提供了灵活和可访问的资源.
- 公共可用的数据和脚本鼓励采用和进一步研究运动分析.
相关概念视频
 01:24
Absolute Motion Analysis- General Plane Motion
219
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
219
 01:25
Relative Motion Analysis using Rotating Axes
460
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
460
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
402
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
402
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
335
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
335
 01:10
Relative Motion Analysis - Acceleration
357
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
357