

协同形态和反控制,用于通过空中机器人穿越未知的符合障碍物
Emanuele Aucone1,2, Christian Geckeler3,4, Daniele Morra5
1Environmental Robotics Laboratory, Department of Environmental Systems Science, ETH Zürich, Zürich, Switzerland. eaucone@ethz.ch.
Nature communications
|March 27, 2024

概括
这项研究以动物为灵感,介绍了一种无人机,它能够通过与障碍物进行物理交互来导航植被. 它的新设计和控制策略使它能够在混乱的环境中安全和多功能地穿越.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 生物启发工程 生物启发工程
- 控制系统 控制系统
背景情况:
- 动物通过身体互动在复杂的植被中导航,沿着障碍物推进和滑动.
- 目前的无人机缺乏与符合环境的直接物理相互作用的多功能性.
- 形态,感知和控制之间的协同作用是动物类穿越的关键.
研究的目的:
- 开发一种能够通过模仿动物交互策略穿越植被的无人机.
- 为了使无人机能够与未知的障碍物特性交互并通过混乱的环境移动.
- 创建一个极简但有效的控制策略,体现空中物理相互作用.
主要方法:
- 设计了一个带有传感器的光盘状外的无人机,用于多功能接触和滑动.
- 实现了一种基于优化的控制器,用于安全状态约束和振荡阻尼.
- 采用以任务为导向的设计,不需要环境交互模型.
主要成果:
- 无人机成功地穿越了具有未知和可变弹性反应的障碍物.
- 实验验证表明,与具有不同刚度的轮表面有效相互作用.
- 该系统展示了在孤立的分支中导航的能力,证明了体现的空中物理相互作用.
结论:
- 拟议的体现空中物理交互策略使无人机在杂乱的植被中进行导航.
- 这种方法为无人机在以前无法进入的环境中运行提供了一条途径.
- 潜在的应用包括环境监测,精密农业和搜救行动.
相关概念视频
 01:24
One-Degree-of-Freedom System
488
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
488
 01:16
Hydraulic Jump: Problem Solving
60
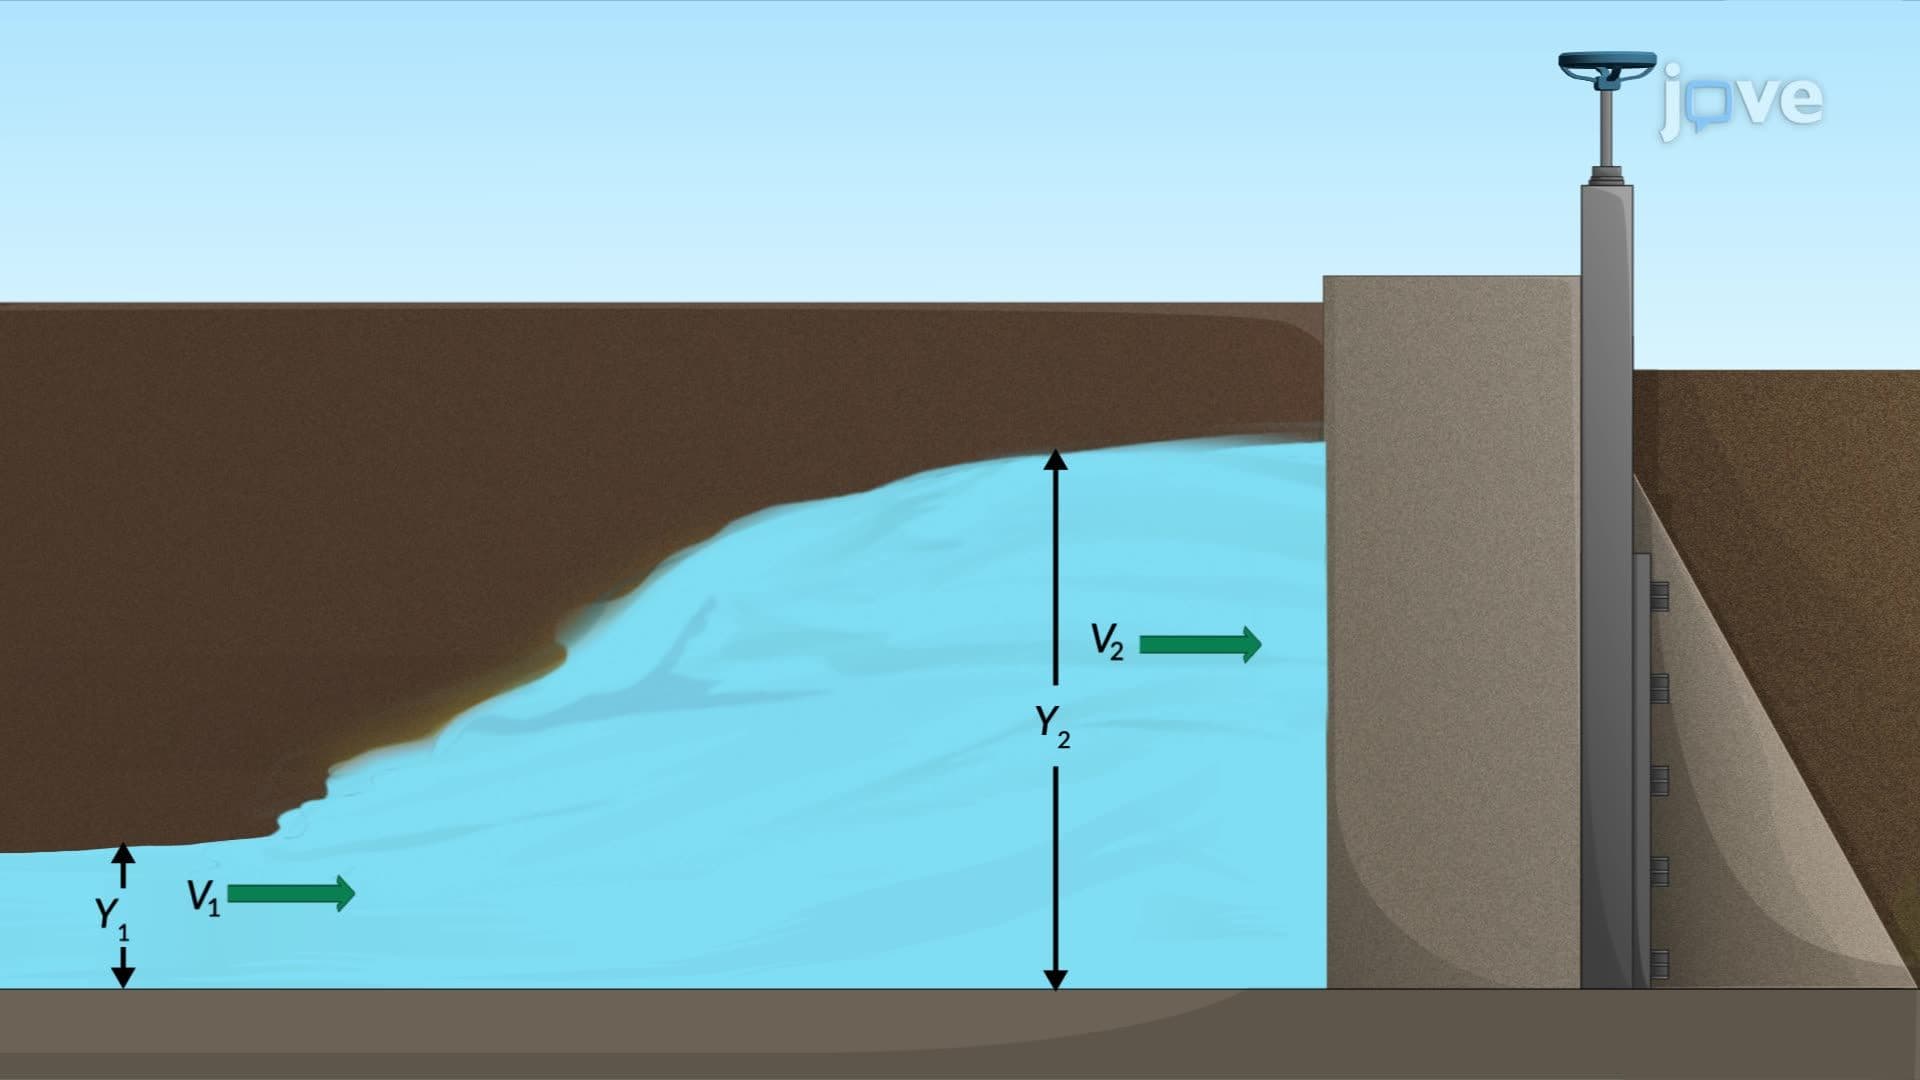
To analyze a hydraulic jump in a rectangular channel with a flow speed of 6 meters per second, follow these steps:Calculate Effective Upstream Velocity:When the downstream gate closes, a hydraulic jump forms, traveling upstream at 2 meters per second. This wave speed combines with the initial channel flow velocity, creating an effective upstream velocity.Identify Flow Velocities Before and After the Hydraulic Jump:Upstream of the hydraulic jump, the effective flow velocity includes both the...
60
 01:26
Feedback control systems
307
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
307
 01:30
Three-Dimensional Force System:Problem Solving
666
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
666
 01:18
Hierarchy of Motor Control
2.7K
The hierarchy of motor control refers to the different levels of organization and processing involved in controlling movement in the body. These levels range from higher cortical areas involved in planning and decision-making to lower spinal cord reflexes that respond automatically to external stimuli.
2.7K
 01:17
Rolling Resistance: Problem Solving
324
Rolling resistance, also known as rolling friction, is the force that resists the motion of a rolling object, such as a wheel, tire, or ball, when it moves over a surface. It is caused by the deformation of the object and the surface in contact with each other, as well as other factors like internal friction, hysteresis, and energy losses within the materials. Rolling resistance opposes the object's motion, requiring additional energy to overcome it and maintain movement. In practical...
324