相关实验视频
Updated: May 5, 2026
10:19
3D Kinematic Gait Analysis for Preclinical Studies in Rodents
Published on: August 3, 2019
10.7K
用无标记和基于标记的运动捕捉来比较行走过程中下肢的动力学和关节时刻计算
Tianchen Huang1, Mianfang Ruan1, Shangjun Huang2
1Sports Biomechanics Laboratory, College of Physical Education and Health, Wenzhou University, Wenzhou, China.
Frontiers in bioengineering and biotechnology
|March 27, 2024

概括
无标记的运动捕捉系统与基于标记的系统密切匹配,用于在松平面下肢步行分析. 然而,在膝盖和脚上/绑架时刻存在差异.
科学领域:
- 生物力学 生物力学
- 运动捕捉技术的技术.
- 步态分析 步态分析
背景情况:
- 基于标记器的运动捕捉系统是步态分析的黄金标准.
- 无标记系统在易于使用和设置方面提供了潜在的优势.
- 对基于标记的系统进行无标记系统的验证对于临床采用至关重要.
研究的目的:
- 为了量化下肢动力学和关节时刻的差异,在路径之间的无标记和基于标记的运动捕捉系统.
- 为了比较特定无标记系统 (TsingVA) 与基于标记系统 (Nokov) 的准确性.
- 用两种系统评估逆动态计算的可靠性.
主要方法:
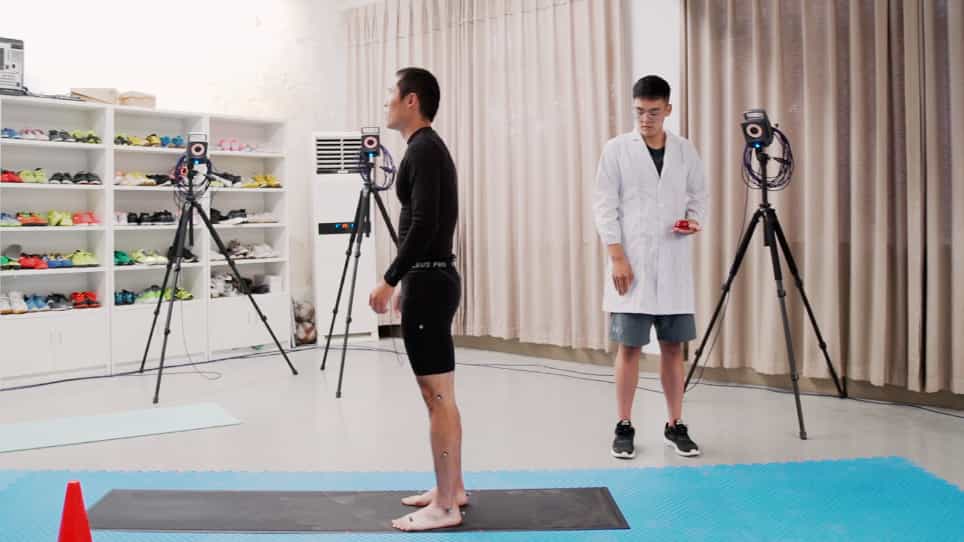
- 同时获取16名健康参与者的下肢动力学数据,使用无标记器和基于标记器的系统,频率为120Hz.
- 在1200赫兹时同步记录地面反应力.
- 使用Visual3D软件执行的反向动态计算.
主要成果:
- 无标记器和基于标记器的系统在斜面平面动力学和关节运动时刻中显示出高度相似性.
- 关节中心位置的最小差异在脚 (0.74厘米MAD) 观察到.
- 在膝盖和脚上发现了显著的偏差,而其他时刻显示出高相关性 (CMC>0.75).
结论:
- 无标记式运动捕捉系统与用于下肢步行分析的基于标记器的系统具有很高的相似性,特别是在手足平面.
- 这些系统在动力学和逆动力学方面提供了可比的结果.
- 建议在使用无标记系统的膝盖和脚上进行ad/abduction时刻计算时谨慎.
相关概念视频
 01:17
Kinematic Equations - II
12.1K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
12.1K
 01:18
Kinematic Equations - III
9.9K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
9.9K