简单的反向动力学计算 考虑关节运动效率
IEEE transactions on cybernetics
|March 27, 2024

概括
本研究介绍了一种用于工业机器人的直接逆动力学 (IK) 方法. 它优化了关节运动,以实现精确的端效应器定位和高效的机器人操作,并通过冗余操纵器进行验证.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统 控制系统
- 优化优化 优化优化
背景情况:
- 反向动力学 (IK) 对于工业操纵器控制至关重要,但存在重大挑战.
- 现有的方法往往难以平衡端效应器精度与联合运动效率.
研究的目的:
- 为工业串行操纵器开发一个简单而有效的IK计算方案.
- 在IK解决方案中将端效应器精度与联合运动效率相结合.
主要方法:
- 以两种标量函数为数值优化问题的形式制定了IK:一个用于端效应器姿势,一个用于关节运动效率.
- 开发了一种基于同步扰动随机近似的新型算法,使用规范有限更新向量 (NLSPSA) 来解决优化问题.
主要成果:
- 拟议的方法成功计算了对所需的终端效应器位置和方向的联合变量,同时最大限度地降低了运动成本.
- 基于NLSPSA的算法显示了高计算效率,简化了实现.
- 使用冗余操纵器的数值示例证实了该方法的有效性和实用性.
结论:
- 拟议的IK方案通过考虑准确性和效率,为工业操纵器提供了一个实际的解决方案.
- NLSPSA算法提供了一种简单,高效,易于实施的方法来解决复杂的IK问题.
相关概念视频
 01:15
Kinematic Equations: Problem Solving
12.4K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
12.4K
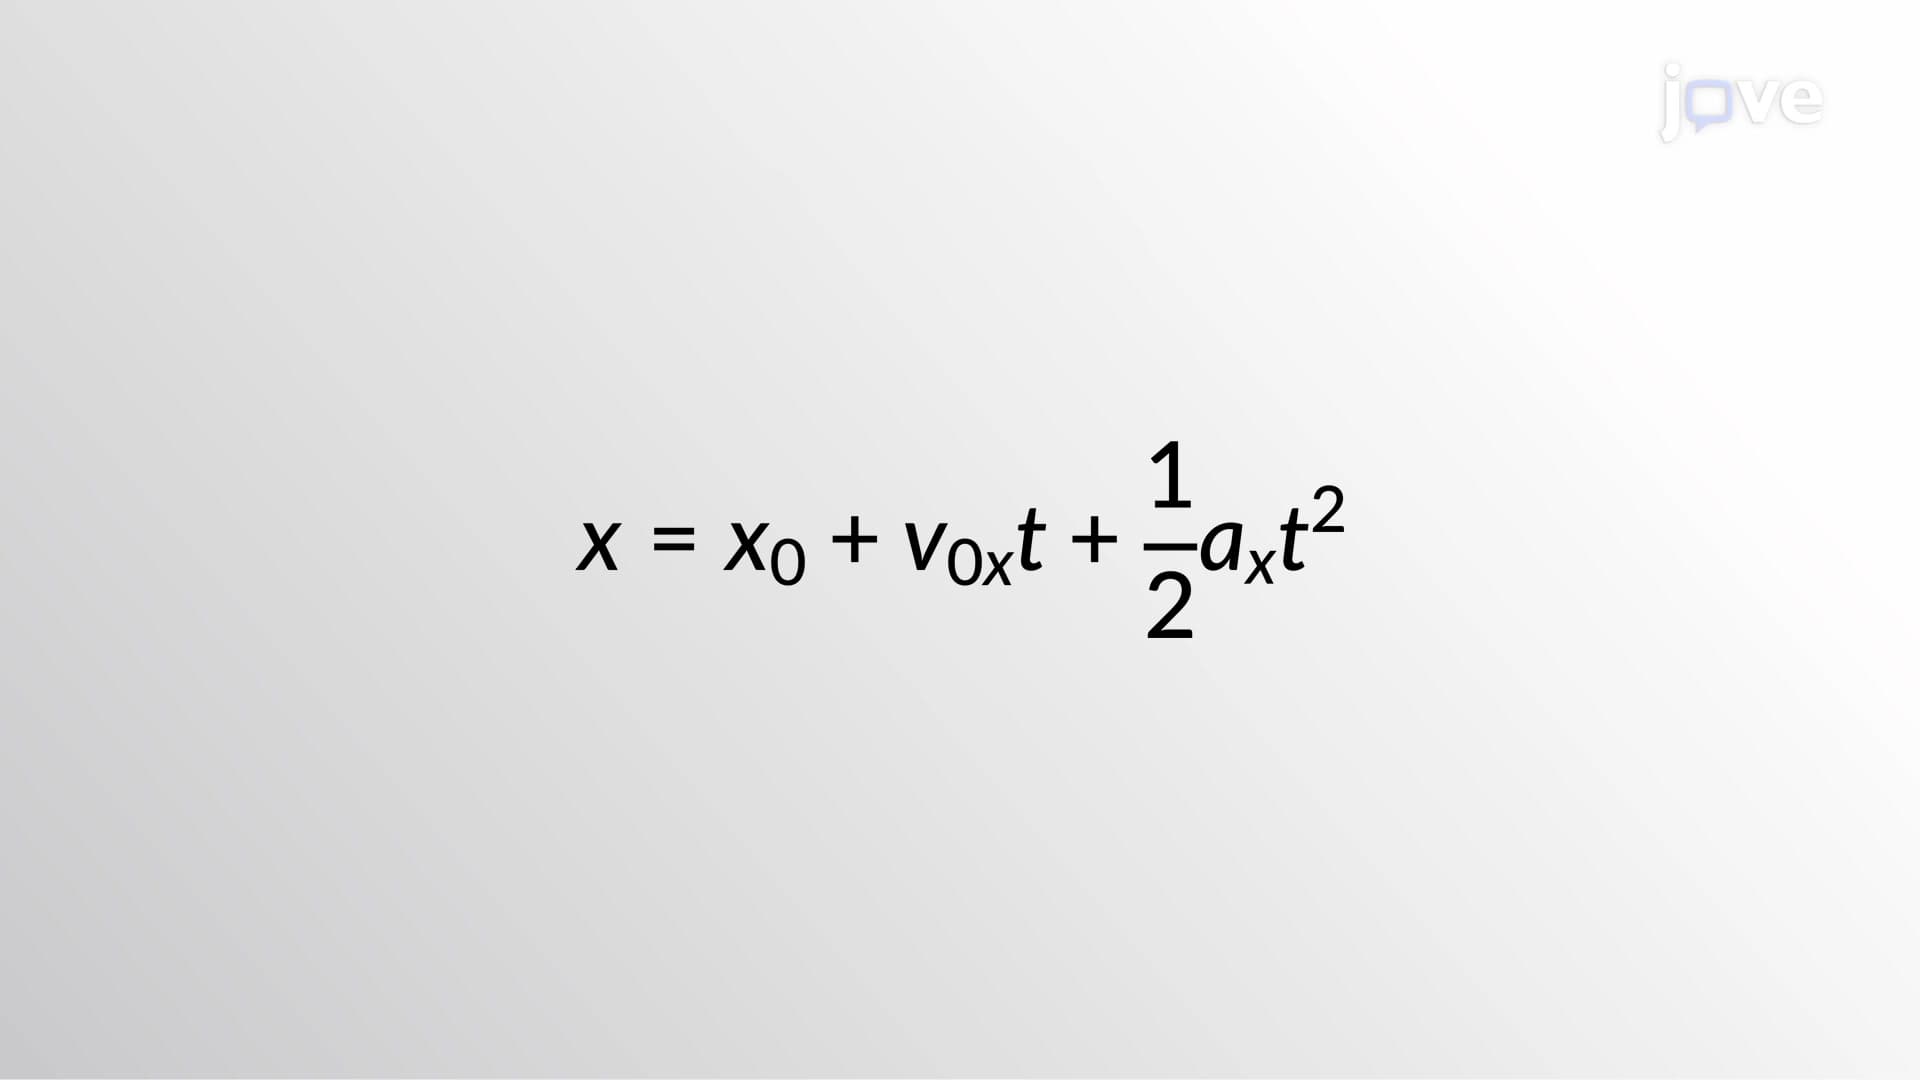 01:17
Kinematic Equations - II
9.5K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
9.5K
 01:18
Kinematic Equations - III
7.6K
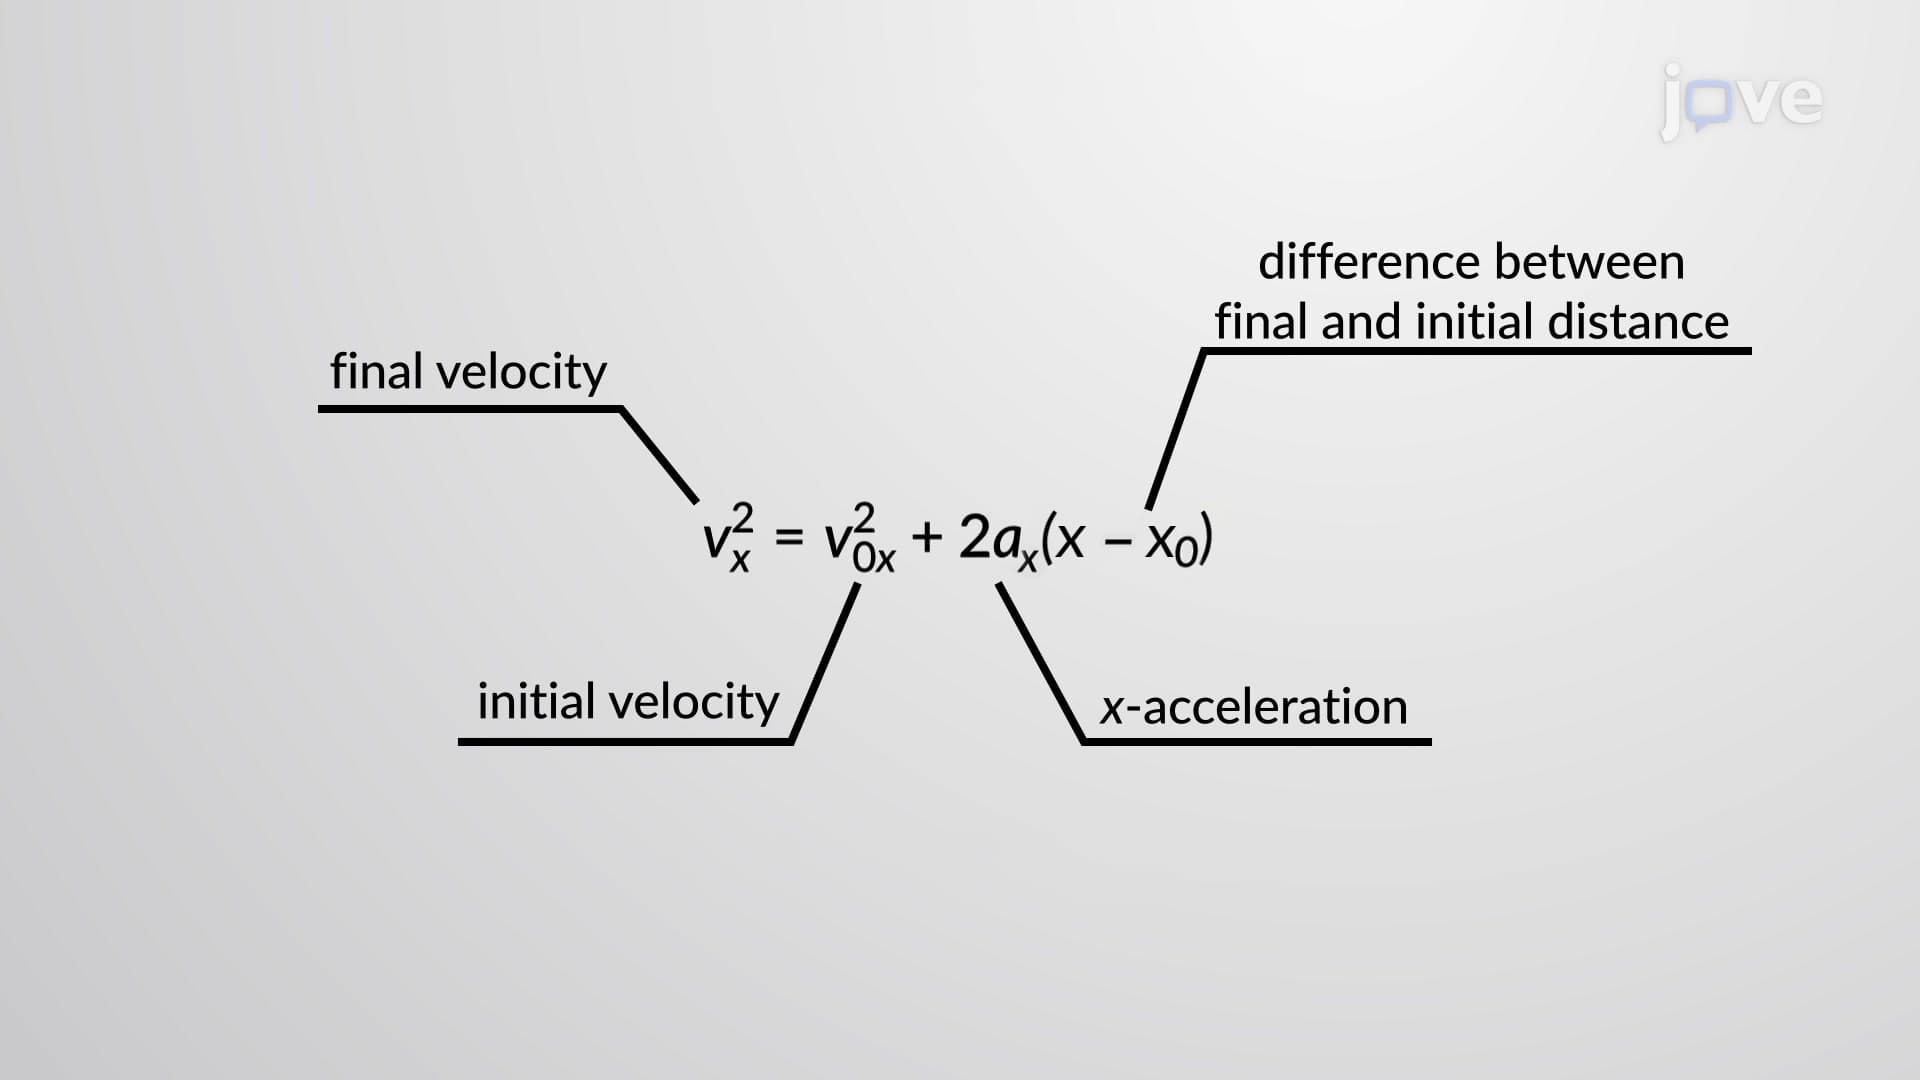
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
7.6K
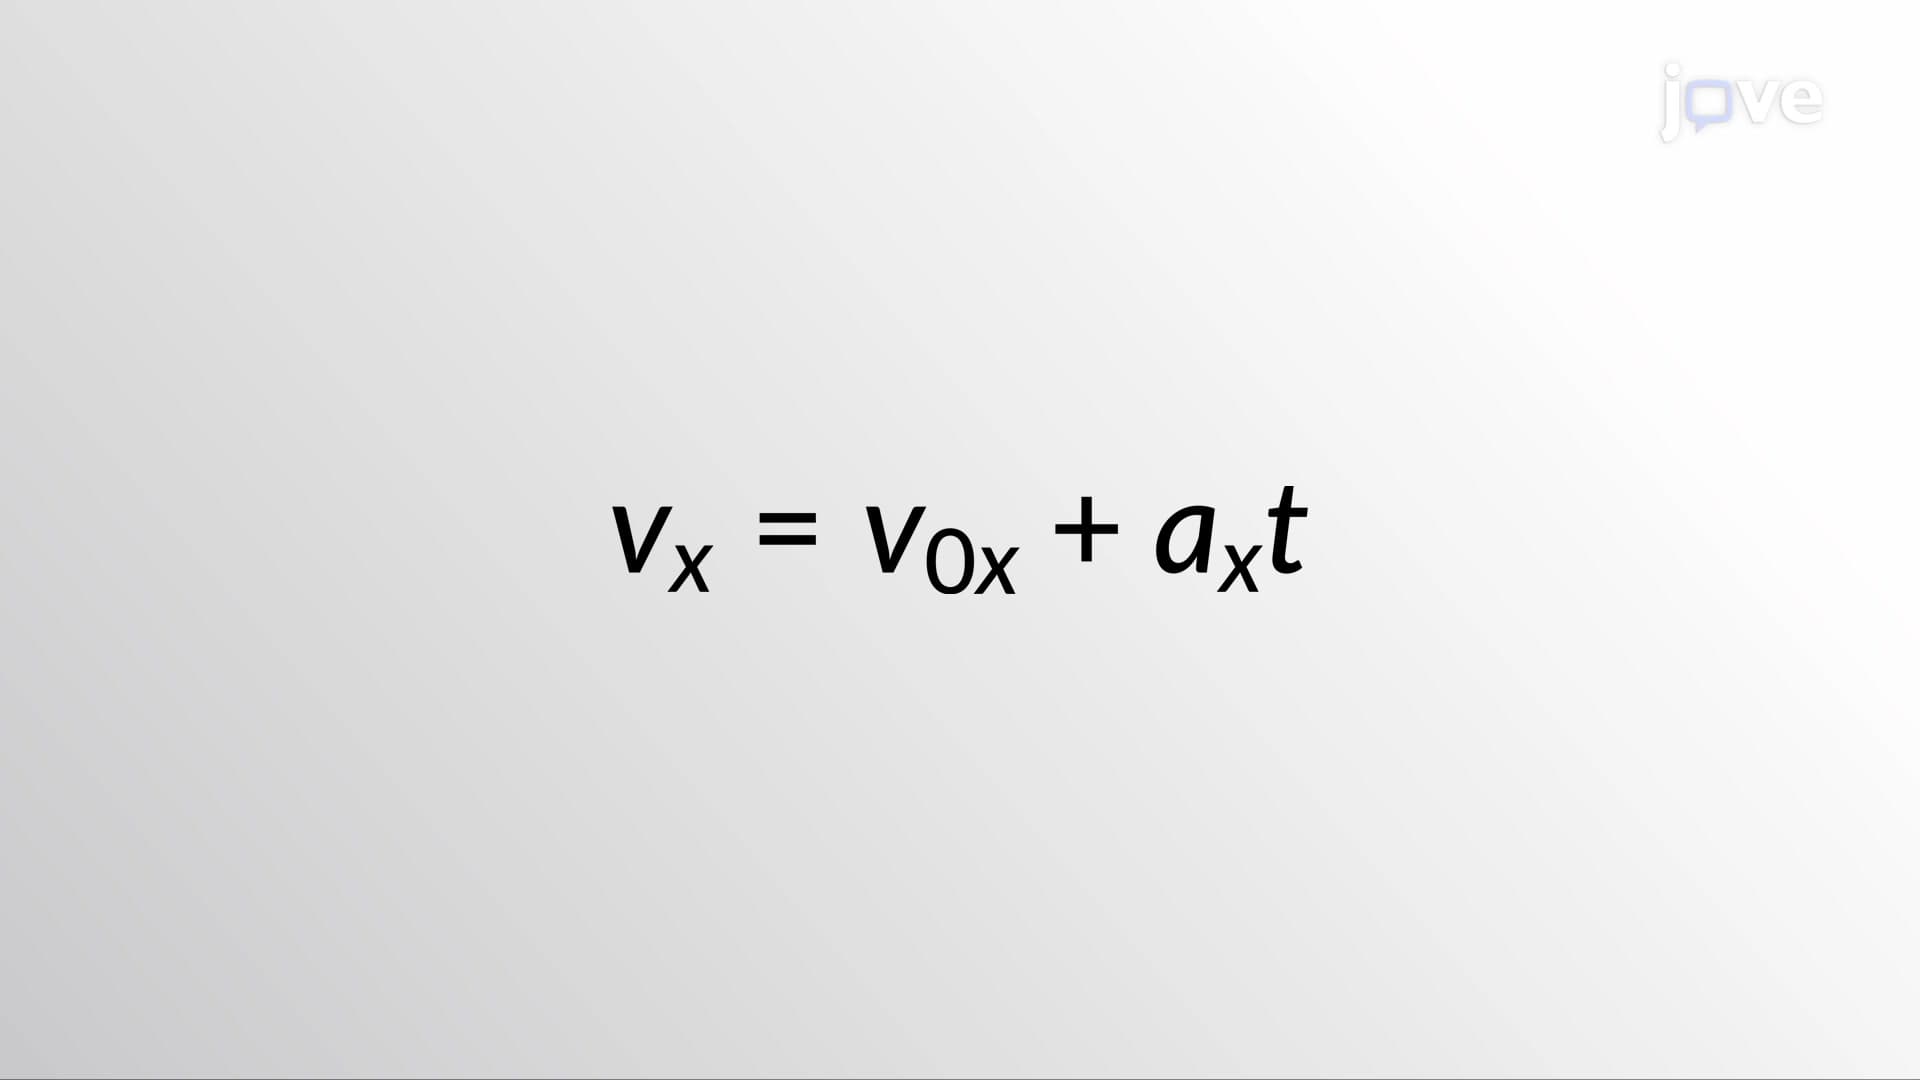 01:26
Kinematic Equations - I
10.5K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
10.5K
 01:30
Kinematic Equations for Rotation
324
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
324
 01:13
Kinetic Energy for a Rigid Body
212
Imagine a solid object involved in a general planar movement, with its center of mass pinpointed at a spot labeled G. The object's kinetic energy relative to an arbitrary point A can be quantified for each of its particles - the ith particle in this case. This measurement is achieved through the employment of the relative velocity definition. The position vector, known as rA, extends from point A to the mass element i.
212