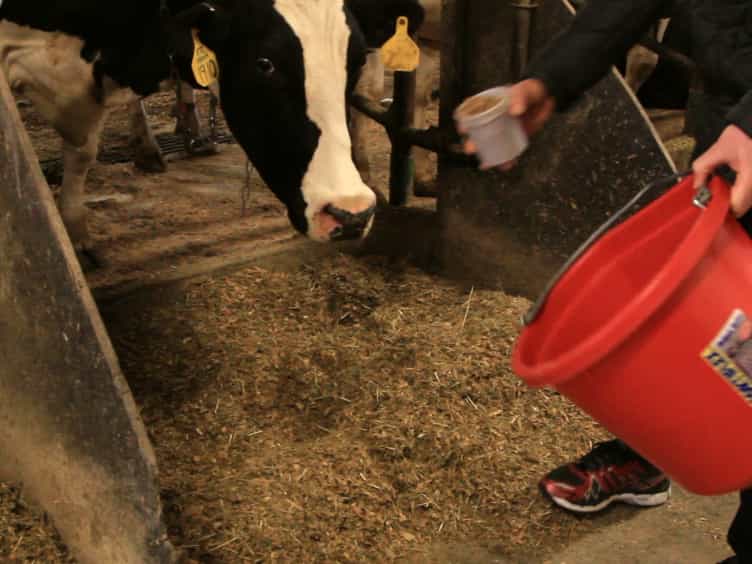

基于四卡尔曼波器的IMU自动校准,用于识别奶牛的运动
Carlos Muñoz-Poblete1, Cristian González-Aguirre2, Robert H Bishop3
1Electrical Engineering Department, Universidad de La Frontera, Temuco 4811230, Chile.
Sensors (Basel, Switzerland)
|March 28, 2024

概括
一个新的自我校准算法通过使用四卡尔曼波器来增强牛的运动方向估计. 这种方法准确地跟踪动物的行为,如安装,以最小的功耗.
科学领域:
- 机器人和自动化 机器人和自动化
- 动物行为监测 动物行为监测
- 传感器融合式传感器
背景情况:
- 准确的方向估计对于理解动物行为至关重要,特别是在畜牧业.
- 现有的追踪动物移动的方法往往缺乏稳定性或需要手动校准.
- 带式惯性导航系统 (SINS) 为自主定位跟踪提供了一个潜在的解决方案.
研究的目的:
- 开发和评估用于牛的运动方向估计的自我校准算法.
- 为了提高检测特定行为的准确性,例如使用惯性传感器数据进行安装.
- 在准确性和功耗方面评估算法的性能.
主要方法:
- 使用四卡尔曼波器实现自校准算法,用于方向预测和偏差校正.
- 集成加速度计和磁力计数据,以更新方向估计.
- 开发一种使用加速度计数据进行倾斜调整的替代更新方法.
- 实验验证将拟议的算法与IvenSense MPU9250和Bosch BNO055传感器上的现有方法进行比较.
主要成果:
- 拟议的自我校准算法在MPU9250上实现了0.077rad的平均误差,功耗为277.7mW.
- 在BNO055上,该算法显示平均误差为0.149rads,并消耗了308.5mW.
- 与 BNO055 的内置算法进行比较,发现了类似的性能 (0.139 rads 误差,307.5 mW 消耗).
结论:
- 开发的自我校准算法为牛的移动提供了准确的方向估计.
- 该算法在检测诸如安装等行为方面表现出有效性.
- 该系统提供了一种可行的低功耗解决方案,用于在野外条件下自主监测动物行为.

相关概念视频
 01:20
Calibration Curves: Linear Least Squares
A calibration curve is a plot of the instrument's response against a series of known concentrations of a substance. This curve is used to set the instrument response levels, using the substance and its concentrations as standards. Alternatively, or additionally, an equation is fitted to the calibration curve plot and subsequently used to calculate the unknown concentrations of other samples reliably.
For data that follow a straight line, the standard method for fitting is the linear...
For data that follow a straight line, the standard method for fitting is the linear...
 01:25
Relative Motion Analysis using Rotating Axes
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...