

维护安全 基于利亚普诺夫模型的预测约会控制,用于受外部干扰的异质船舶
IEEE transactions on cybernetics
|April 3, 2024

概括
这项研究引入了一种新的控制框架,用于自主水下和水面车辆,以实现尽管存在干扰,但安全的约会. 该方法确保了异质海洋系统的稳定性和精度.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统 控制系统
- 海洋工程 海洋工程
背景情况:
- 由于外部干扰和输入限制,对异质海洋系统 (自主水下车辆 - AUV,自主水面车辆 - ASV) 的合作控制具有挑战性.
- 确保安全和精确的约会需要先进的控制策略,可以处理系统的不确定性和约束.
研究的目的:
- 开发一个基于Lyapunov的模型预测控制 (LMPC) 框架,用于干扰的AUV和ASV的合作聚会.
- 在高度非线性海洋系统中,同时解决状态约束和外部干扰.
主要方法:
- 将规定的绩效控制 (PPC) 纳入LMPC框架,以转换国家约束.
- 使用干扰观察器 (DOB) 设计PPC辅助辅助控制规则,以实现强大的合同约束.
- 通过解决MPC问题,开发一个维护安全的LMPC (SP-LMPC) 控制器,用于同等不受约束的系统.
主要成果:
- 拟议的LMPC-PPC框架有效地将国家受约束的问题转变为不受约束的问题,保持约会安全.
- SP-LMPC控制器从辅助控制规律中继承了强度和稳定性,确保在干扰下可靠的性能.
- 理论分析证实了开发的控制策略的递归可行性和闭环稳定性.
结论:
- 新的LMPC-PPC框架为扰乱的异质海洋系统的合作聚会提供了强大而稳定的解决方案.
- 这种方法为在复杂的海洋机器人应用中同时管理状态约束和外部干扰提供了一个新的范式.
- 模拟和比较验证了拟议的安全维护LMPC算法的有效性和优越性.


相关概念视频
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
1.8K
In fluid mechanics, buoyancy and stability are key concepts for understanding the behavior of submerged and floating bodies. When a stationary body is fully or partially submerged in a fluid, the fluid exerts a force on the body known as the buoyant force. This force acts vertically upward through a point called the center of buoyancy, which is the center of the displaced fluid volume. According to Archimedes' principle, the magnitude of the buoyant force is equal to the weight of the fluid...
1.8K
 01:22
Multi-input and Multi-variable systems
106
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
In the absence...
106
 01:19
Root-Locus Method
148
A cruise control system in a car is designed to maintain a specified speed automatically by adjusting the gas pedal. The system continuously measures the vehicle's speed and makes fine adjustments to the pedal to achieve this goal. The root locus method is particularly useful for understanding how the cruise control system's behavior changes under varying conditions, such as when the car goes uphill, downhill, or faces strong wind resistance.
This system can be represented by a block...
This system can be represented by a block...
148
 01:18
Uniform Depth Channel Flow: Problem Solving
63
To calculate the flow rate for a trapezoidal channel, first, identify the bottom width, side slope, and flow depth of the channel. The cross-sectional area (A) corresponding to the depth of flow (y), channel bottom width (B), and side slope (θ) is determined by:Next, calculate the wetted perimeter, which includes the bottom width and the sloped side lengths in contact with the water. Using the values of the cross-sectional area and the wetted perimeter, determine the hydraulic radius by...
63
 01:24
Pole and System Stability
291
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
291
 01:13
Stability of Equilibrium Configuration: Problem Solving
606
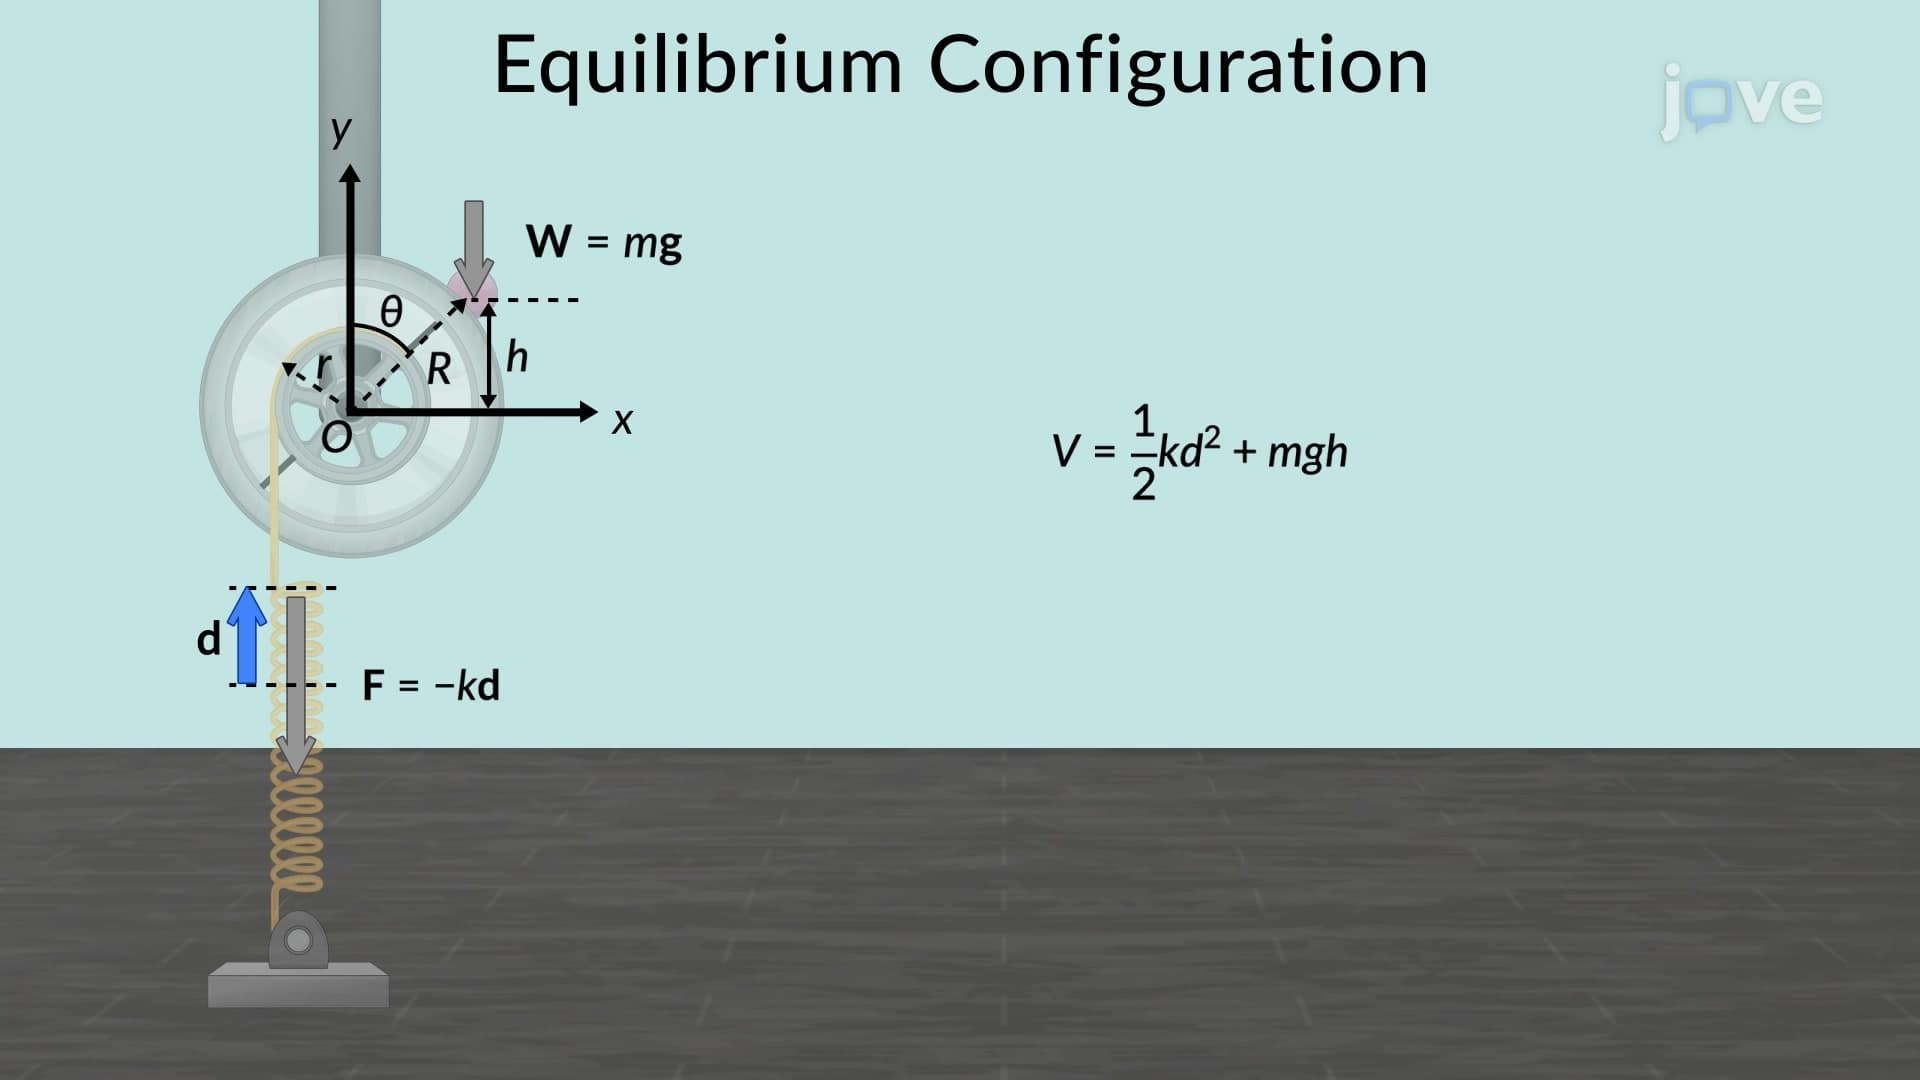
The stability of equilibrium configurations is an important concept in physics, engineering, and other related fields. In simple terms, it refers to the tendency of an object or system to return to its equilibrium position after being disturbed. The stability of an equilibrium configuration can be analyzed by considering the potential energy function of the system and examining its behavior near the equilibrium point.
Problem-solving in the context of the stability of equilibrium configuration...
Problem-solving in the context of the stability of equilibrium configuration...
606