
在估计运动参数时,比较两种光滑方法
Stephan R Kuberski1, Adamantios I Gafos1
1Department of Linguistics and Cognitive Sciences, University of Potsdam, Germany.

概括
与数字过相比,Spline光滑显著减少了语音动力学参数估计中的错误. 这突出了线作为语音分析的卓越方法,与人类运动科学发现相一致.
科学领域:
- 语音科学是一种语言科学.
- 人类运动科学 人类运动科学
背景情况:
- 具有有限差异的数字过在语音分析中很常见.
- 在人类运动科学中,用于信号处理的平是普遍存在的.
研究的目的:
- 比较语音信号处理的数字过和线条平滑.
- 使用这两种方法评估动力学参数估计的准确性.
- 通过回归分析评估符合已知的参数关系.
主要方法:
- 应用数字过 (有限差异) 和对语音信号的线条平滑.
- 使用两种光滑技术估计的动力学参数.
- 进行回归分析,将参数估计与既定规律进行比较.
主要成果:
- 间隙光滑产生了显著较小的回归误差.
- 数字过在参数估计中显示出更大的错误.
- 脊线的优势在语音数据分析中是显而易见的.
结论:
- 线条平滑是一种更准确的语音动力学分析方法.
- 这些发现支持了超出人类运动科学范围的线的更广泛适用性.
- 这项研究证实了脊柱平滑在语音领域的有效性.
更多相关视频
相关概念视频
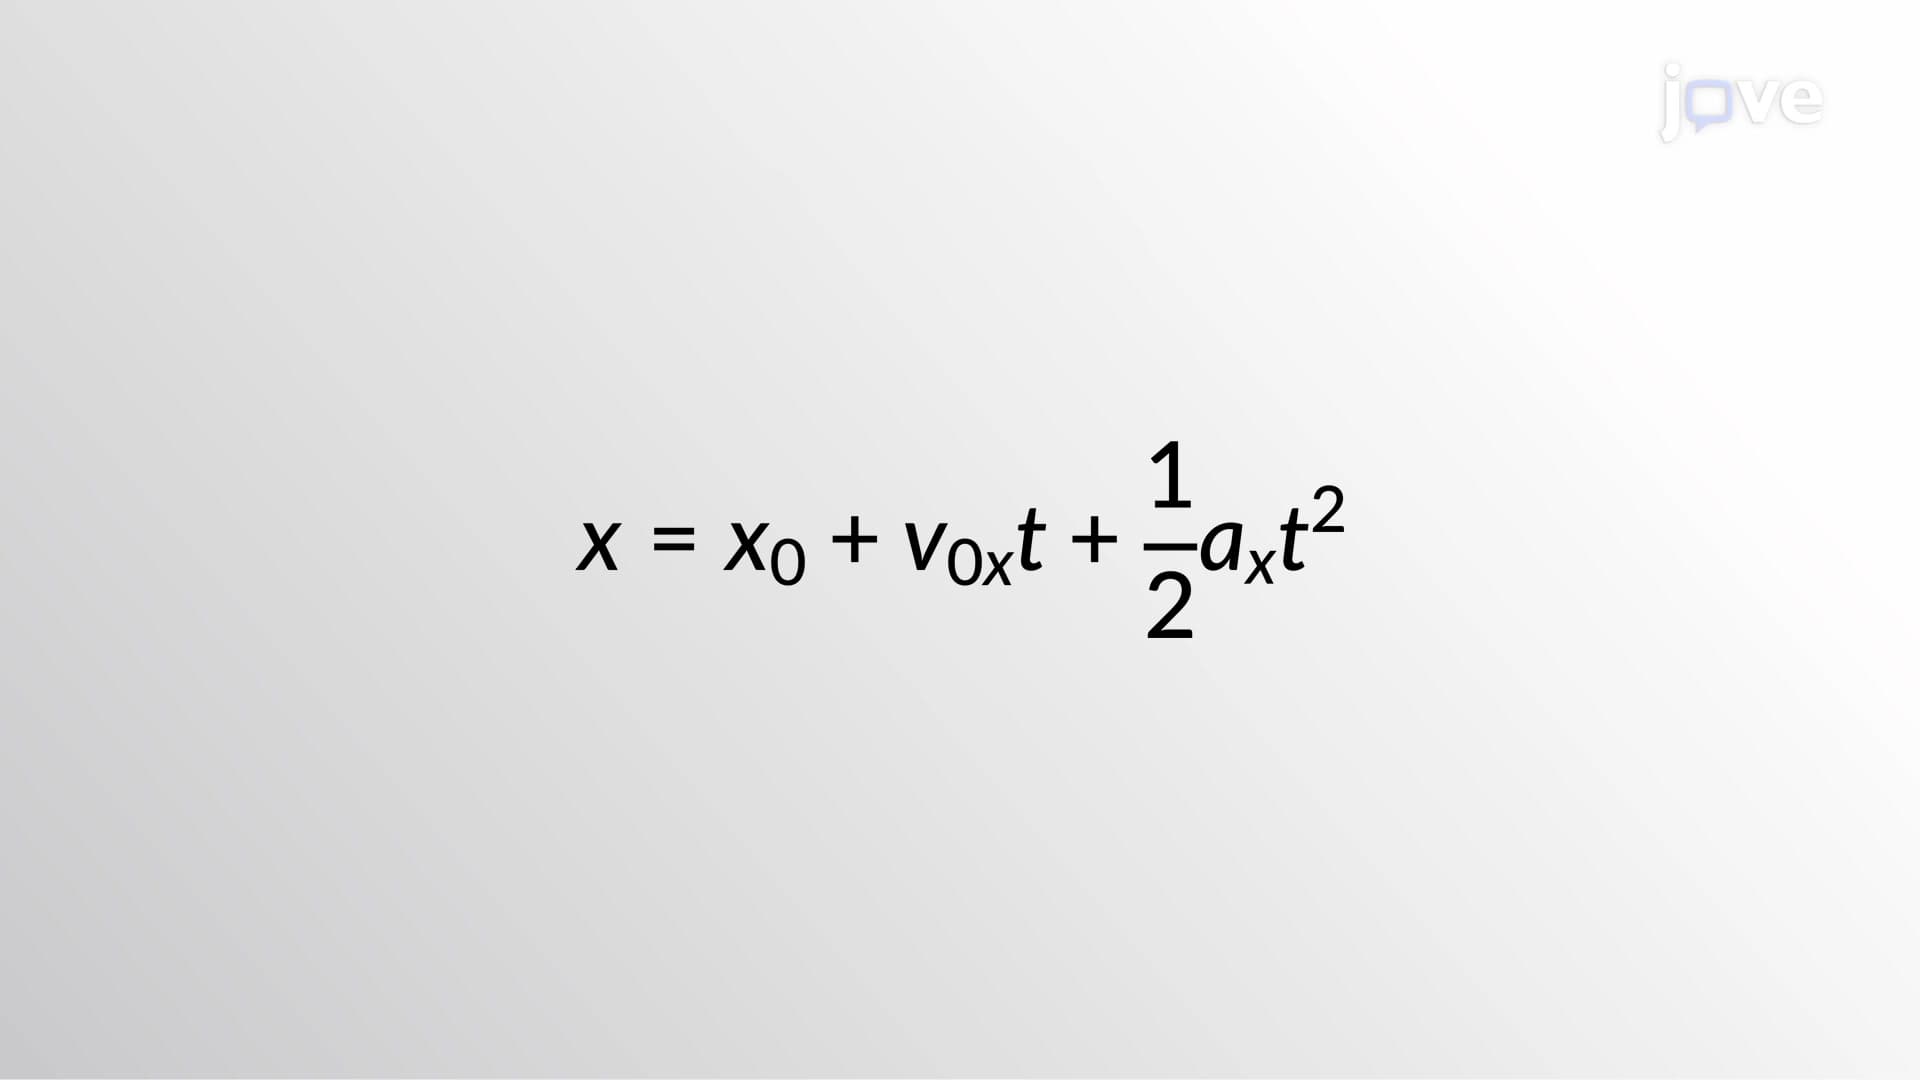 01:17
Kinematic Equations - II
9.5K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
9.5K
 01:18
Kinematic Equations - III
7.6K
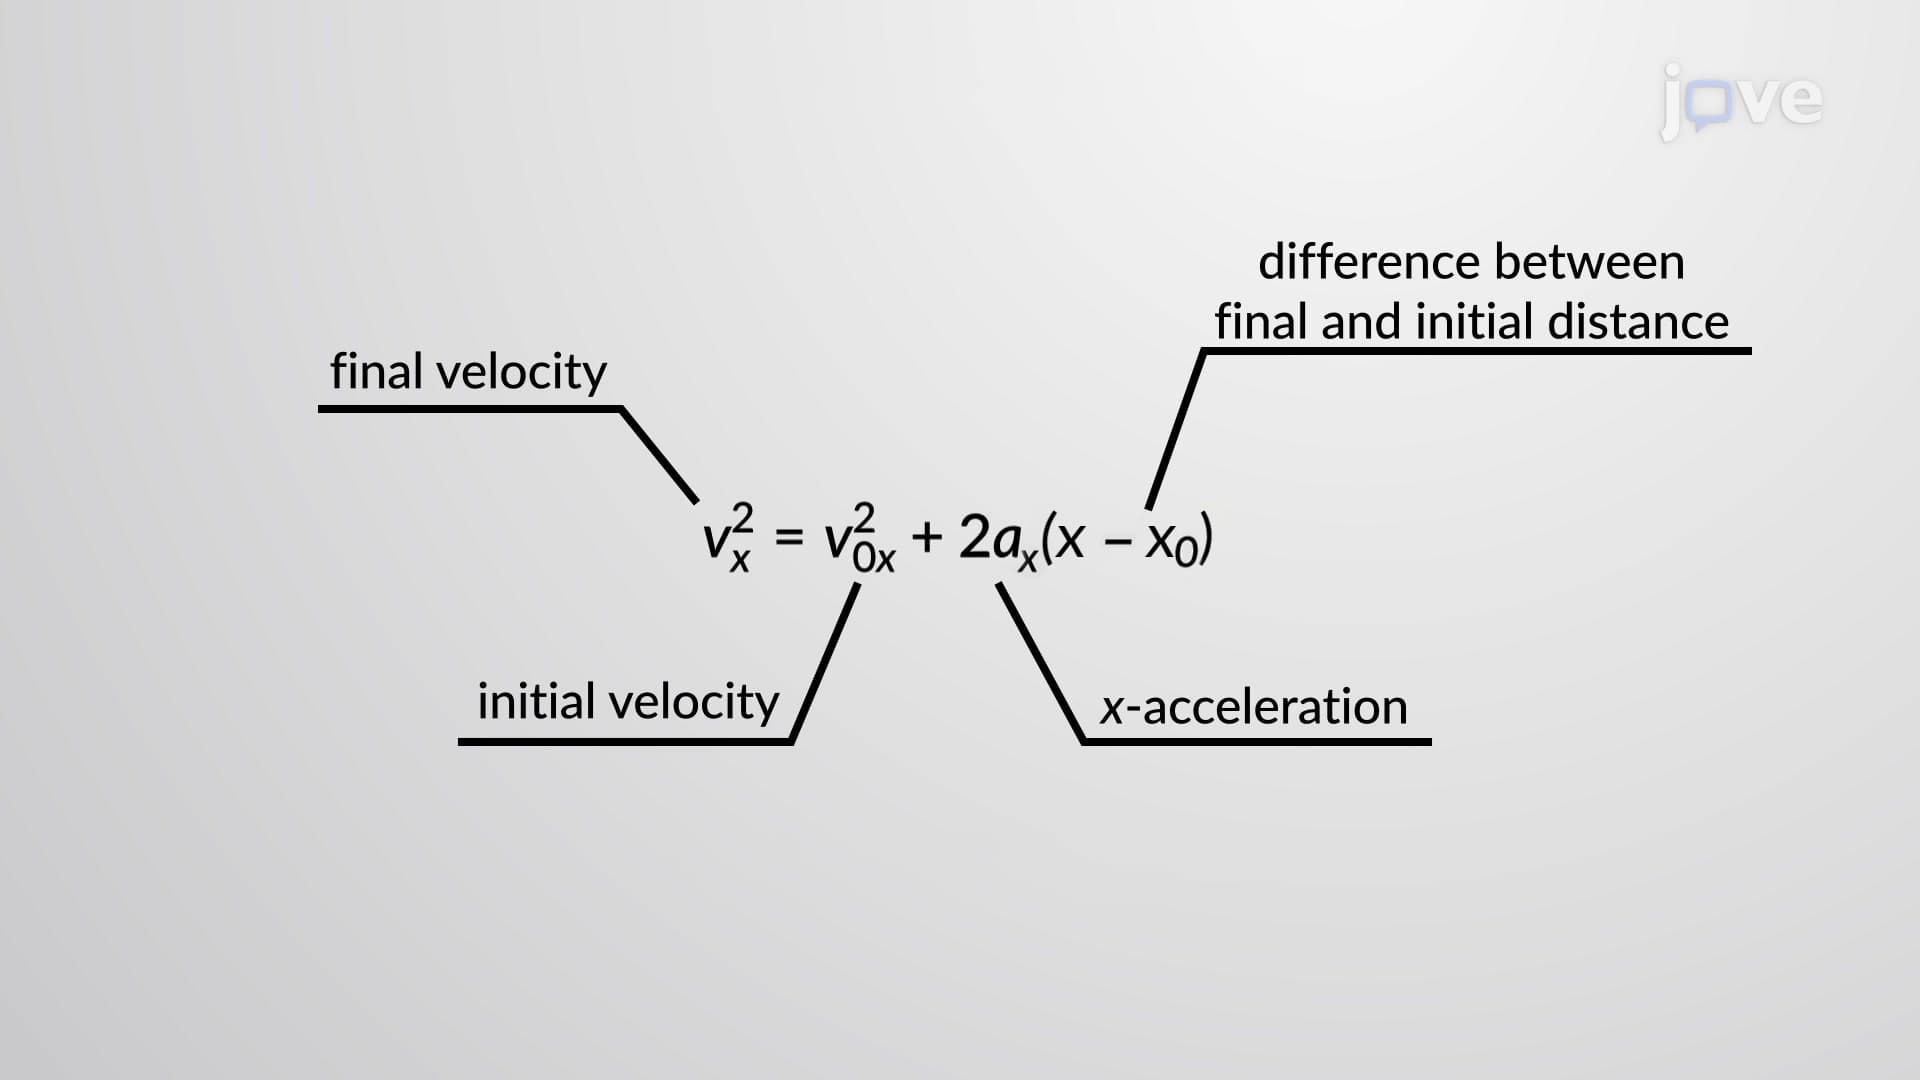
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
7.6K
 01:15
Kinematic Equations: Problem Solving
12.4K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
12.4K
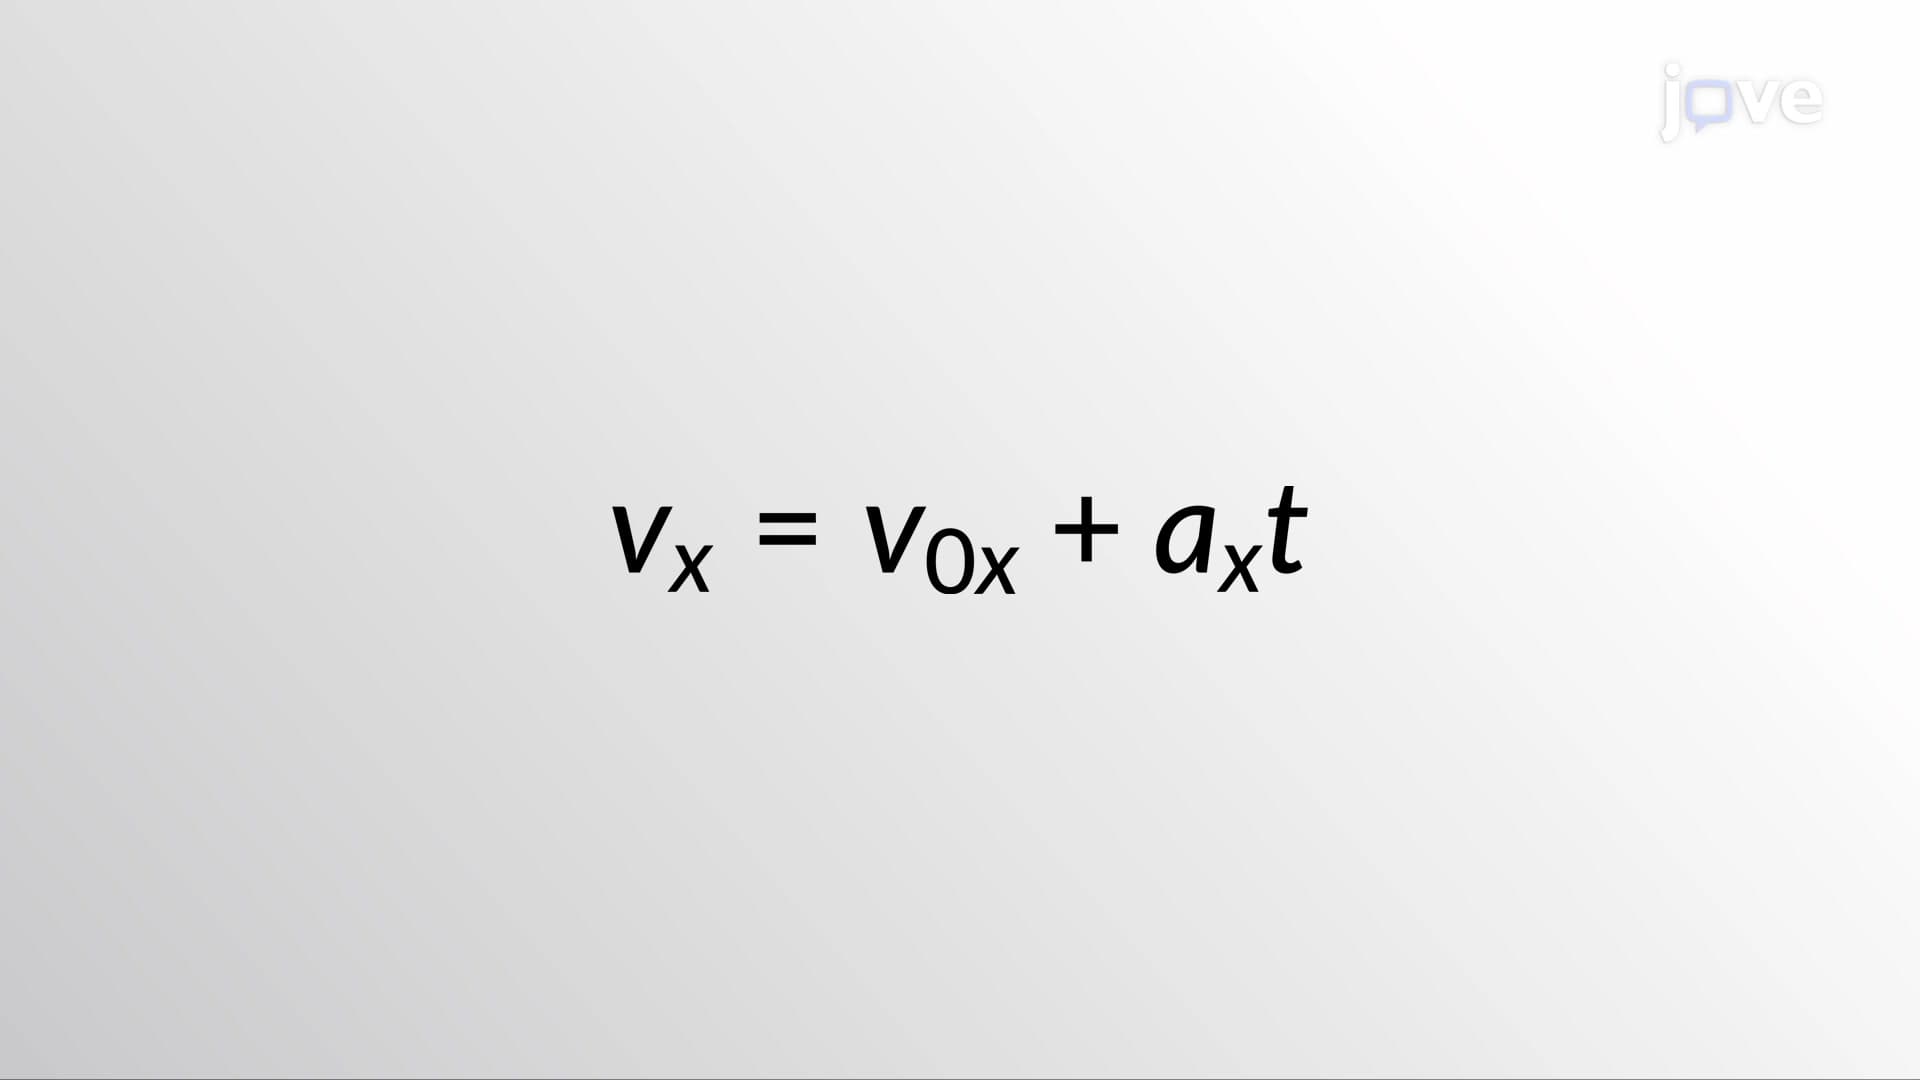 01:26
Kinematic Equations - I
10.5K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
10.5K
 01:30
Kinematic Equations for Rotation
324
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
324
 01:24
Relative Motion Analysis - Velocity
359
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
359