相关实验视频
Updated: Jun 29, 2025
08:47
Rapid Manufacturing of Thin Soft Pneumatic Actuators and Robots
Published on: November 8, 2019
7.6K
对于热活性软执行器的统一命名方案:对材料,工作原理和应用的审查
Trevor Exley1, Emilly Hays1, Daniel Johnson1
1Advanced Robotic Manipulators (ARM) Lab, the Department of Biomedical Engineering, University of North Texas, Denton, Texas, USA.
Robotics reports (New Rochelle, N.Y.)
|April 8, 2024

概括
一个新的命名惯例",人工肌肉的相变弹性体",澄清了软机器人研究. 这提高了热活性执行器在虚拟现实和辅助设备等应用中的可发现性.
科学领域:
- 材料科学 材料科学 材料科学
- 工程 工程师 工程师 工程师
- 化学 化学 化学
背景情况:
- 软机器人文学受到了诸如"智能"或"智能"材料之类的模糊术语的影响.
- 这种模两可,阻碍了在不同领域的清晰沟通和可搜索性.
- 热活性软执行器需要特定的命名,以适用于各种应用.
研究的目的:
- 为软机器人提出一个清晰,功能和描述性的命名方案.
- 提高软机器人技术创新的可搜索性和理解性.
- 提供根据应用选择热活性执行器的指南.
主要方法:
- 将工作原理,材料和应用合成一个统一的命名结构.
- 审查热活性软执行器领域.
- 分析潜在的应用和未来的研究方向.
主要成果:
- 引入了一个精确的命名法:"用于人工肌肉的相变弹性体".
- 展示了这种命名惯例如何提高对"软执行器软材料"的清晰度.
- 突出了热活性执行器的广泛应用.
结论:
- 标准化命名方案对于推进软机器人研究至关重要.
- 清晰的命名方便软执行器在虚拟现实和辅助技术等领域的应用.
- 需要进一步的研究来完善执行器的选择和实施.
相关概念视频
 01:11
ortho–para-Directing Activators: –CH3, –OH, –NH2, –OCH3
6.0K
All ortho–para directors, excluding halogens, are activating groups. These groups donate electrons to the ring, making the ring carbons electron-rich. Consequently, the reactivity of the aromatic ring towards electrophilic substitution increases. For instance, the nitration of anisole is about 10,000 times faster than the nitration of benzene. The electron-donating effect of the methoxy group in anisole activates the ortho and para positions on the ring and stabilizes the corresponding...
6.0K
 01:16
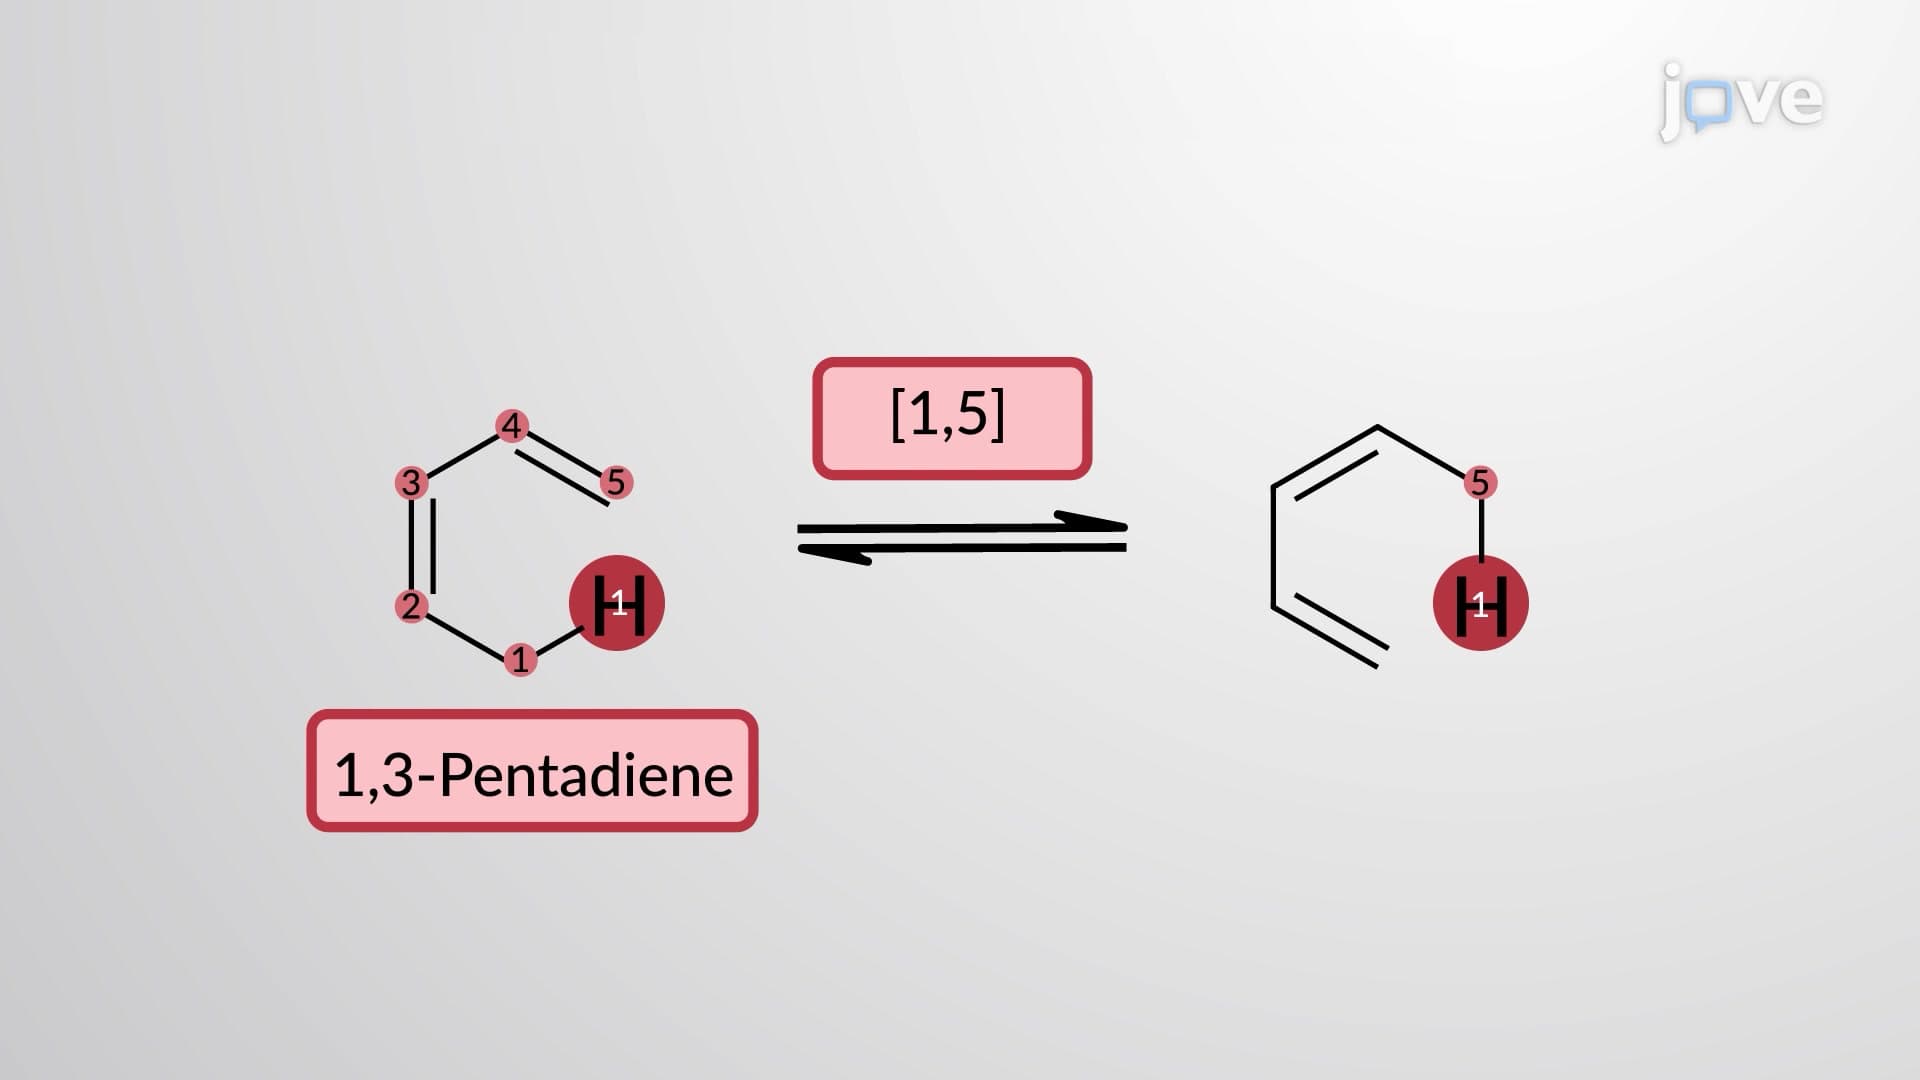
Thermal Sigmatropic Reactions: Overview
2.1K
Sigmatropic rearrangements are a class of pericyclic reactions in which a σ bond migrates from one part of a π system to another. These are intramolecular rearrangements where the total number of σ and π bonds remain unchanged.
Sigmatropic shifts are classified based on an order term [i, j ], where i and j indicate the number of atoms across which each end of the σ bond migrates. Below are examples of a [3,3] sigmatropic shift in...
Sigmatropic shifts are classified based on an order term [i, j ], where i and j indicate the number of atoms across which each end of the σ bond migrates. Below are examples of a [3,3] sigmatropic shift in...
2.1K