
对无人驾驶飞行器发动机故障诊断的皮埃佐传感器放置的非线性复发性分析
Andrzej Koszewnik1, Leszek Ambroziak2, Daniel Ołdziej2
1Bialystok University of Technology, Wiejska Street 45C, Bialystok, 15-351, Poland. a.koszewnik@pb.edu.pl.
Scientific reports
|April 9, 2024

概括
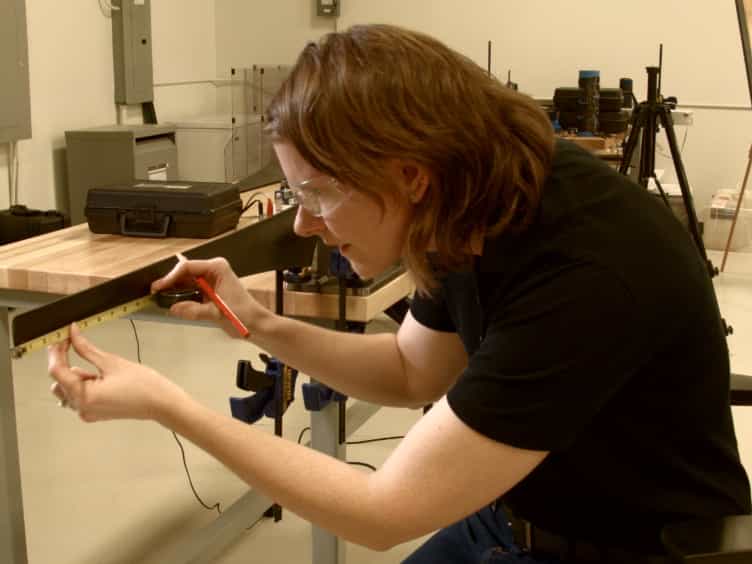
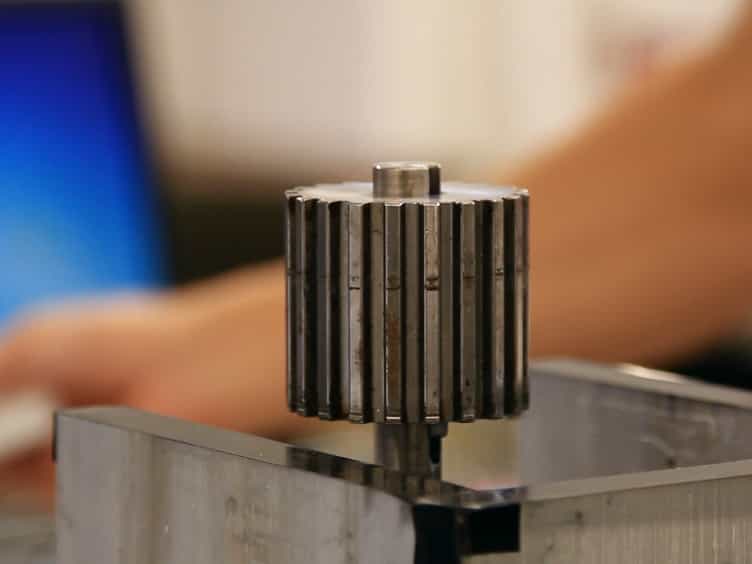
这项研究使用压缩传感器和非线性复发分析来诊断多直升机无人机 (UAV) 推进系统. 最佳的传感器放置在手臂侧面,可以提高故障检测和运动健康监测.
科学领域:
- 工程 工程师 工程师 工程师
- 航空航天工程 航空航天工程
- 振动分析 振动分析
背景情况:
- 多飞机无人机 (UAV) 需要强大的推进系统诊断.
- 在故障操作期间的过渡状态 (例如,电机阶段问题) 需要有效的监控.
- 使用压电传感器进行振动分析提供了一个有前途的诊断方法.
研究的目的:
- 调查压电传感器的最佳放置,以有效诊断多飞机推进系统.
- 用非线性方法分析振动时间序列,用于故障检测.
- 为了评估不同传感器位置对推进系统变化的灵敏度.
主要方法:
- 对振动时间序列数据进行非线性分析.
- 在短时间窗口中应用的反复性量化分析.
- 主要组件分析 (PCA) 用于分析复发量化.
- 测试不同脉冲宽度调制 (PWM) 工作周期和传感器位置 (侧面与顶部).
主要成果:
- 压电传感器对振动很敏感,这表明推进系统的健康状况.
- 非线性复发分析有效地检测到无人机电机速度的变化.
- 压力传感器的侧面位置对推进系统变化的敏感性更高.
- 主要组件分析证实了侧面传感器位置的优越性.
结论:
- 非线性复发分析是诊断多飞机推进系统的可行方法.
- 最佳的压力传感器放置,特别是在手臂的侧面,显著提高了诊断的有效性.
- 这项研究为加强多飞机电机的健康监测和故障检测提供了基础.
相关概念视频
 01:19
Root-Locus Method
148
A cruise control system in a car is designed to maintain a specified speed automatically by adjusting the gas pedal. The system continuously measures the vehicle's speed and makes fine adjustments to the pedal to achieve this goal. The root locus method is particularly useful for understanding how the cruise control system's behavior changes under varying conditions, such as when the car goes uphill, downhill, or faces strong wind resistance.
This system can be represented by a block...
This system can be represented by a block...
148
 01:19
Plotting and Calibrating the Root Locus
116
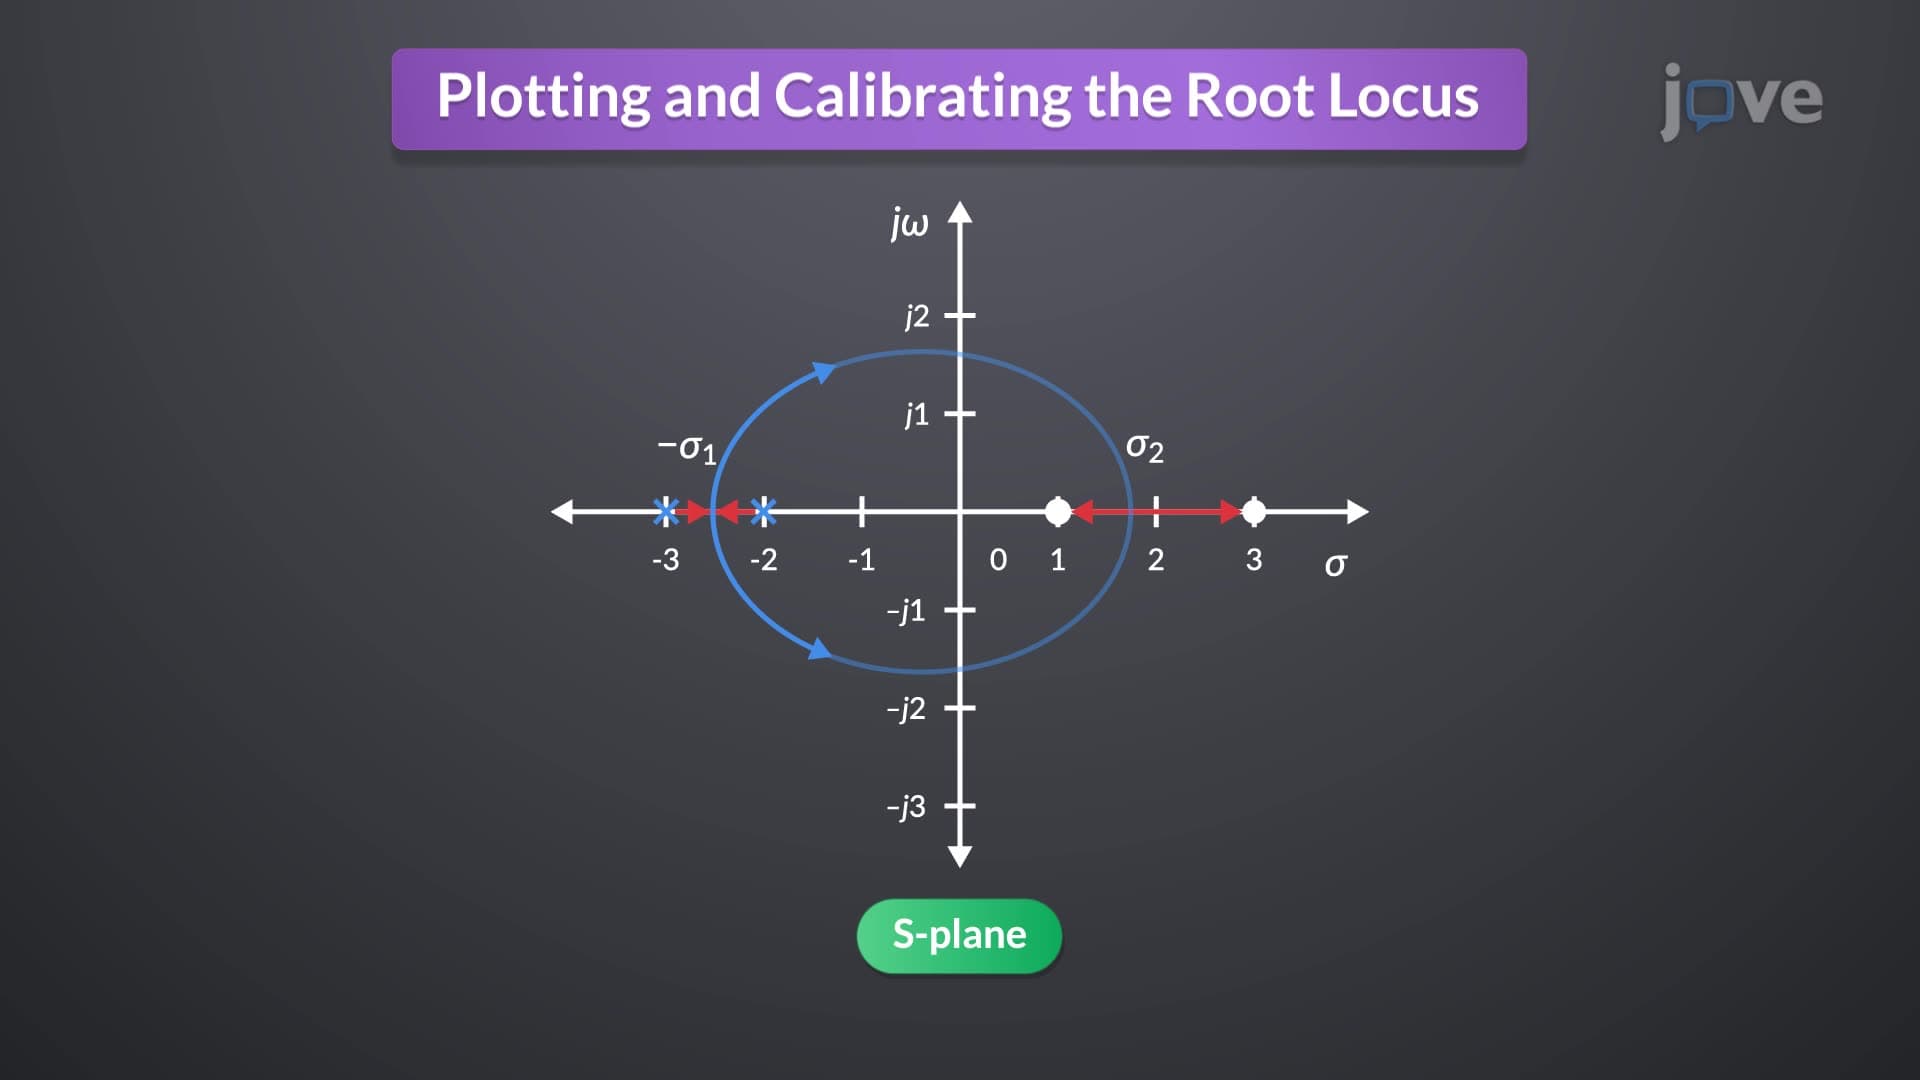
Root loci often diverge as system poles shift from the real axis to the complex plane. Key points in this transition are the breakaway and break-in points, indicating where the root locus leaves and reenters the real axis. The branches of the root locus form an angle of 180/n degrees with the real axis, where n is the number of branches at a breakaway or break-in point.
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
116
 01:24
PI Controller: Design
260
Proportional Integral (PI) controllers are a fundamental component in modern control systems, widely used to enhance performance and mitigate steady-state errors. They are particularly effective in applications such as automatic brightness adjustment on smartphones, where they excel at mitigating steady-state errors for step-function inputs. Unlike PD controllers, which require time-varying errors to function optimally, PI controllers leverage their integral component to address residual...
260
 01:07
Time-Domain Interpretation of PD Control
98
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
98