精确的无人机角位置估计在复杂的背景与边界分类的边界分类

Yu-Shiuan Tsai1, Cheng-Sheng Lin1, Guan-Yi Li1
1Dept. of Computer Science and Engineering, National Taiwan Ocean University, Zhongzheng District, Keelung, Taiwan.
Heliyon
|April 10, 2024

概括
这项研究引入了一种用于精确通道框架检测的新方法,改善了复杂环境中的无人机导航. 我们的方法使用YOLACT和组回归来准确定位,优于传统的基于颜色的技术.
科学领域:
- 计算机视觉 计算机视觉
- 机器人技术 机器人技术 机器人技术
- 人工智能的人工智能
背景情况:
- 准确的无人机导航需要精确检测通道框架,特别是在复杂的环境中.
- 传统的方法往往在不同的角度和复杂的背景下扎.
- 仅依赖色彩信息的现有技术具有局限性.
研究的目的:
- 开发一种高效,强大的方法,用于精确的通道框架检测.
- 为了提高无人机导航系统的准确性.
- 为了克服传统基于颜色的检测技术的局限性.
主要方法:
- 利用YOLACT (你只看系数) 和小组回归来进行检测.
- 采用边缘图像检测,二进制,侵蚀和Hough Transform进行细分.
- 使用K-means集群用于分类和线性回归用于精确定位.
主要成果:
- 与传统技术相比,拟议的方法显示出更高的性能.
- 通过各种角度和复杂的背景有效地识别通道框架.
- 通过广泛的实验验验证了强大而精确的定位能力.
结论:
- 开发的方法为无人机 (UAV) 应用提供了显著的进步.
- 精确的通道框架检测对于可靠的无人机导航至关重要.
- 整合YOLACT和群体回归为具有挑战性的环境提供了强大的解决方案.


相关概念视频
 01:05
Difference from Background: Limit of Detection
6.4K
The limit of detection (LOD) is the smallest amount of analyte that can be distinguished from the background noise. The LOD value corresponds to the concentration at which the analyte signal is three times larger than the standard deviation of the blank signal. Below this value, the analyte signal cannot be differentiated from the background noise. It is calculated by dividing the calibration slope by 3 times the standard deviation of the blank signals.
The LOD indicates the presence or absence...
The LOD indicates the presence or absence...
6.4K
 01:22
Force Classification
1.2K
Forces play a crucial role in the study of physics and engineering. They are essential in describing the motion, behavior, and equilibrium of objects in the physical world. Forces can be classified based on their origin, type, and direction of action.
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
1.2K
 01:18
Boundary Layer Characteristics
109
When a fluid encounters a solid surface, a boundary layer forms due to the interaction between the fluid's motion and the stationary surface. This phenomenon is characterized by a thin region adjacent to the surface where viscous forces dominate, influencing the fluid's velocity profile. The development of the boundary layer begins at the leading edge of the surface and evolves as the fluid moves downstream.As the fluid flows over the surface, friction between the fluid and the wall slows down...
109
 01:21
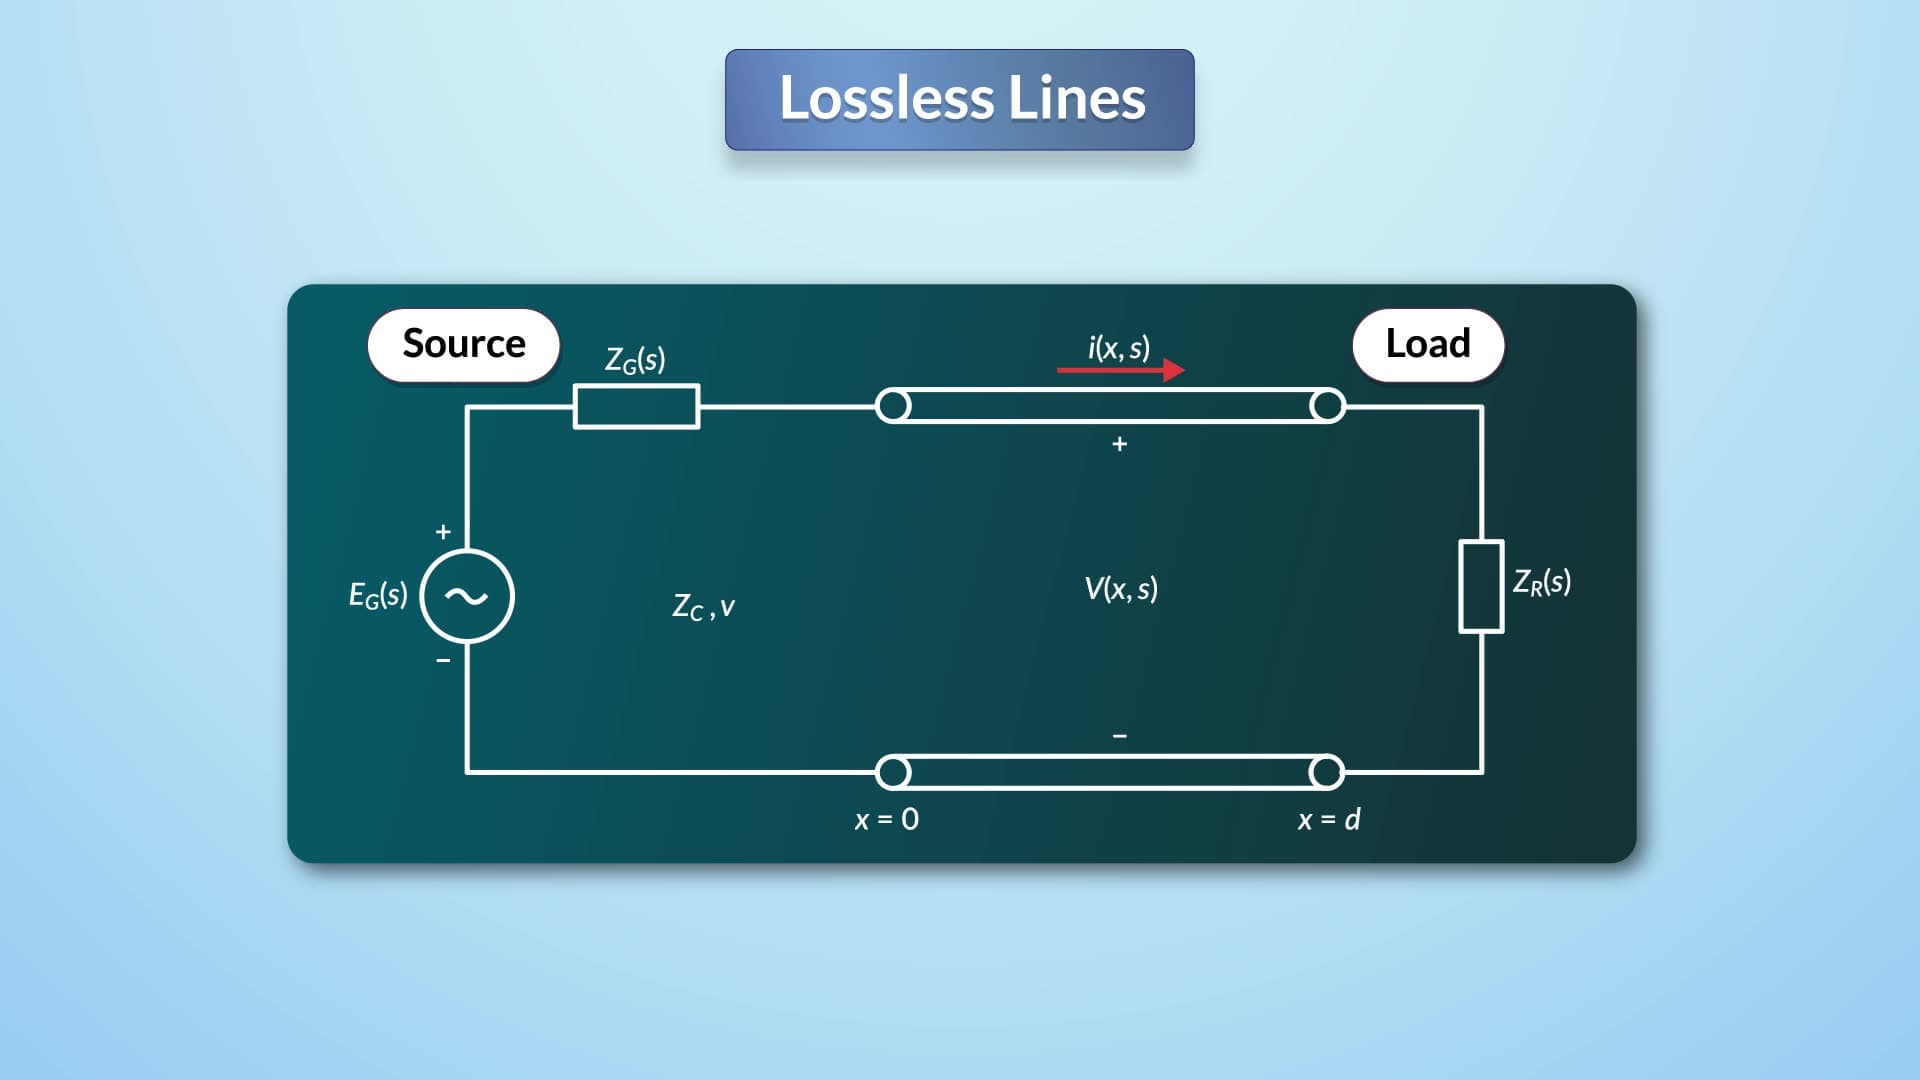
Boundary Conditions: Lossless Lines
93
Consider a single-phase, two-wire, lossless transmission line terminated by an impedance at the receiving end and a source with Thevenin voltage and impedance at the sending end. The line, with length, has a surge impedance and wave velocity determined by the line's inductance and capacitance.
At the receiving end, the boundary condition states that the voltage equals the product of the receiving-end impedance and current. This relationship is expressed as a function of the incident and...
At the receiving end, the boundary condition states that the voltage equals the product of the receiving-end impedance and current. This relationship is expressed as a function of the incident and...
93
 01:18
Uniform Depth Channel Flow: Problem Solving
63
To calculate the flow rate for a trapezoidal channel, first, identify the bottom width, side slope, and flow depth of the channel. The cross-sectional area (A) corresponding to the depth of flow (y), channel bottom width (B), and side slope (θ) is determined by:Next, calculate the wetted perimeter, which includes the bottom width and the sloped side lengths in contact with the water. Using the values of the cross-sectional area and the wetted perimeter, determine the hydraulic radius by...
63
 01:29
Position Vectors
878
A position vector is a fundamental concept in mathematics that helps determine the position of one point with respect to another point in space. It is a vector that describes the direction and distance between two points. Position vectors are highly useful in the field of math and science, as they help represent spatial relationships and make calculations easier.
For instance, we want to locate a point P(x, y, z) relative to the origin of coordinates O. In that case, we can define a position...
For instance, we want to locate a point P(x, y, z) relative to the origin of coordinates O. In that case, we can define a position...
878