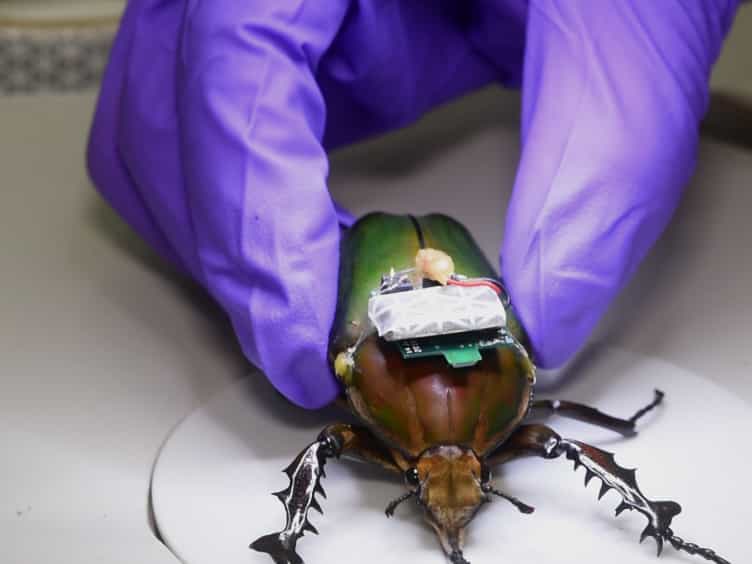

一个敏捷的单脚跳跃四旋翼飞机与协同的混合动力机车
Songnan Bai1, Qiqi Pan2,3, Runze Ding1
1Department of Biomedical Engineering, City University of Hong Kong, Tat Chee Avenue, Hong Kong SAR, China.
Science robotics
|April 10, 2024

概括
灵感来自大自然,一个新的混合跳跃和飞行机器人集成一个纳米四旋翼机与一个被动的望远镜腿,以获得卓越的机动性. 这种机器人系统实现了敏捷的运动,在复杂的环境中提高了敏捷性和多功能性.
科学领域:
- 机器人技术和自主系统
- 生物启发工程 生物启发工程
- 航空机械学 航空机械
背景情况:
- 大自然展示了先进的多式联运机动,结合了空中和地面运动.
- 现有的跳跃机器人经常面临局限性,因为它们依赖于立场阶段腿部执行.
- 需要灵活多功能机器人平台,能够进行复杂的环境导航.
研究的目的:
- 引入一款高性能混合跳跃和飞行机器人,其灵感来源于自然多式联运机动.
- 通过一种新的被动腿设计,克服传统跳跃机制的局限性.
- 在一个单一的机器人平台上实现敏捷跳跃和多功能飞行能力.
主要方法:
- 纳米四旋翼机与被动望远镜腿的集成,用于混合动力机动.
- 开发一种基于推力进行连续跳跃的控制方法.
- 实现可拆卸的活性空气动力学表面,以提高机动性.
主要成果:
- 机器人实现了2.38米/秒的平均垂直跳跃速度和1.63米的跳跃高度.
- 演示了敏捷的跳跃机动,可调节的跳跃高度和减少立场阶段持续时间.
- 启用间歇性中飞跳跃,飞行方向快速变化,提高灵活性.
结论:
- 开发的混合跳跃和飞行机器人通过多式联动机器表现出卓越的移动性.
- 被动腿设计提供了一个有前途的方法,可以与旋翼飞机无集成.
- 这项技术增强了机器人的敏捷性和多功能性,用于复杂环境的探索和操作.
相关概念视频
 01:24
Absolute Motion Analysis- General Plane Motion
219
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
219
 01:24
One-Degree-of-Freedom System
487
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
487
 01:29
Hydraulic Jump
78
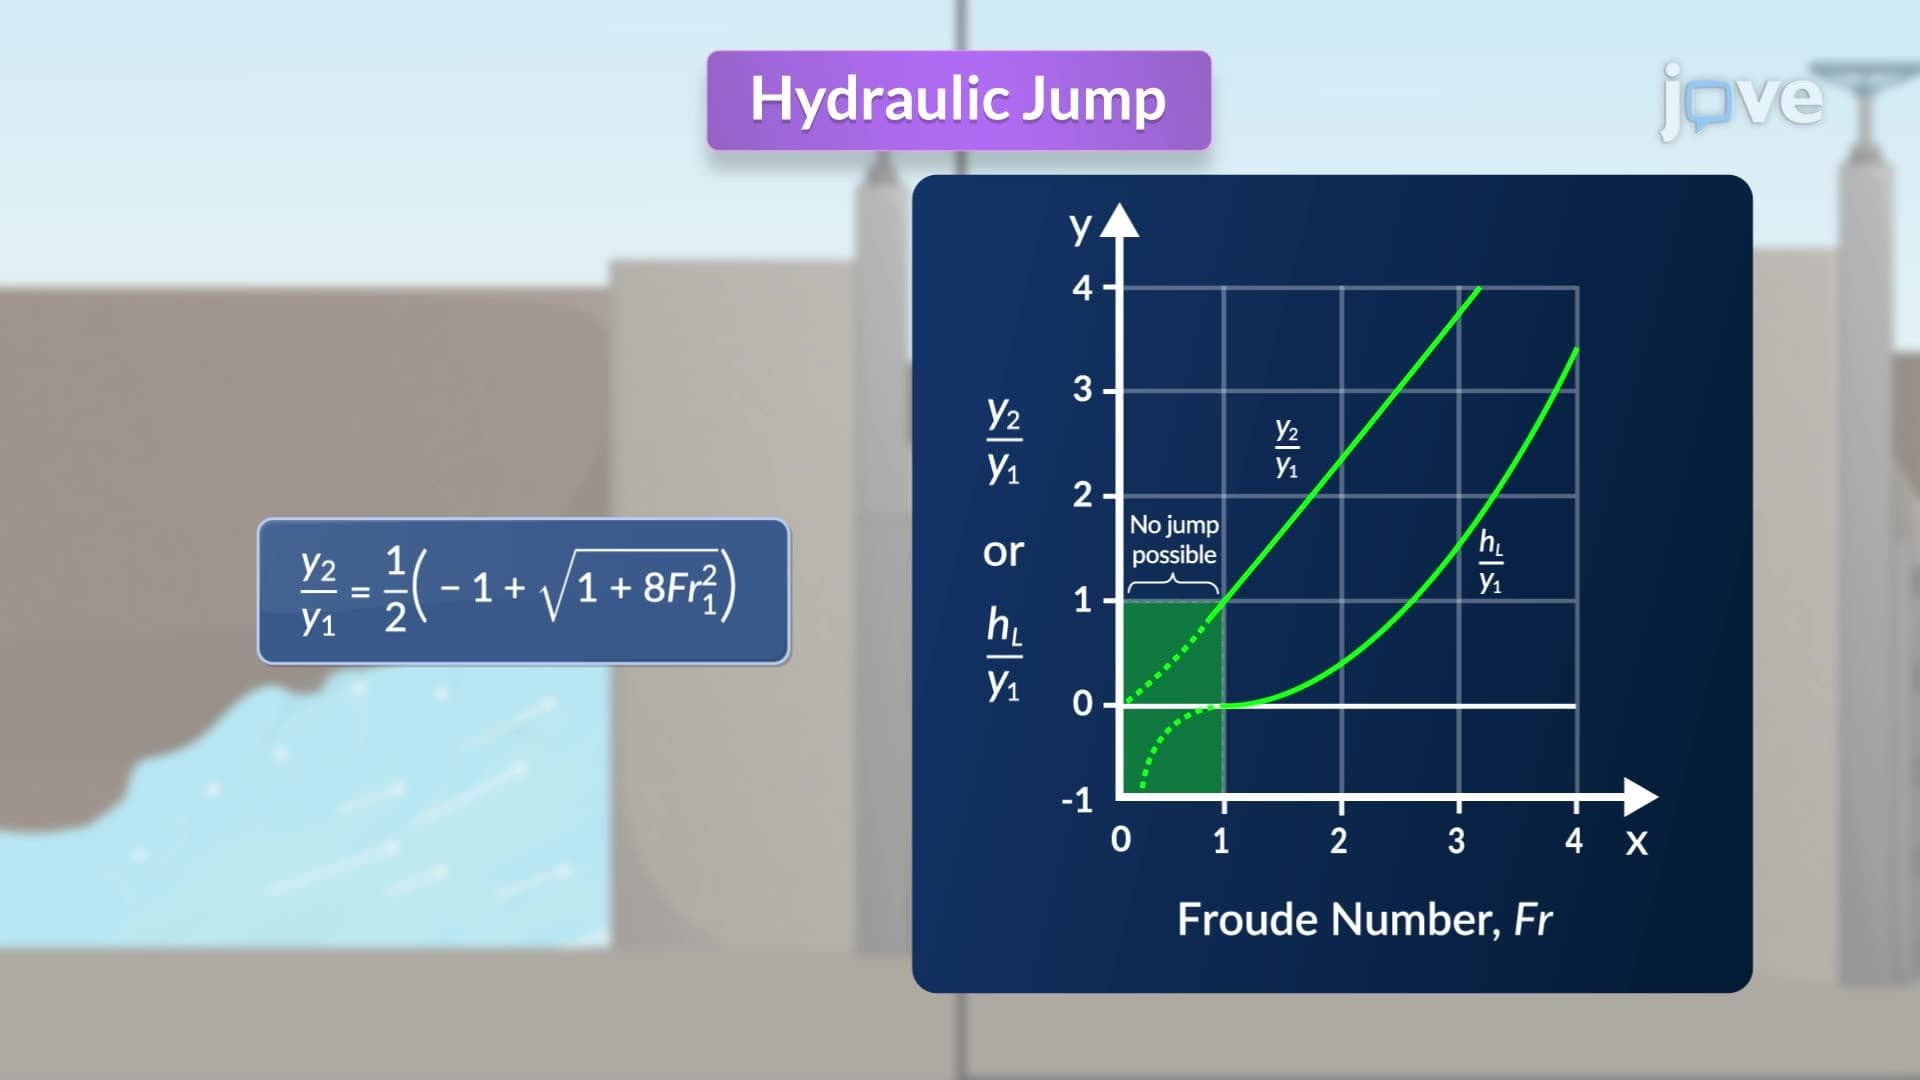
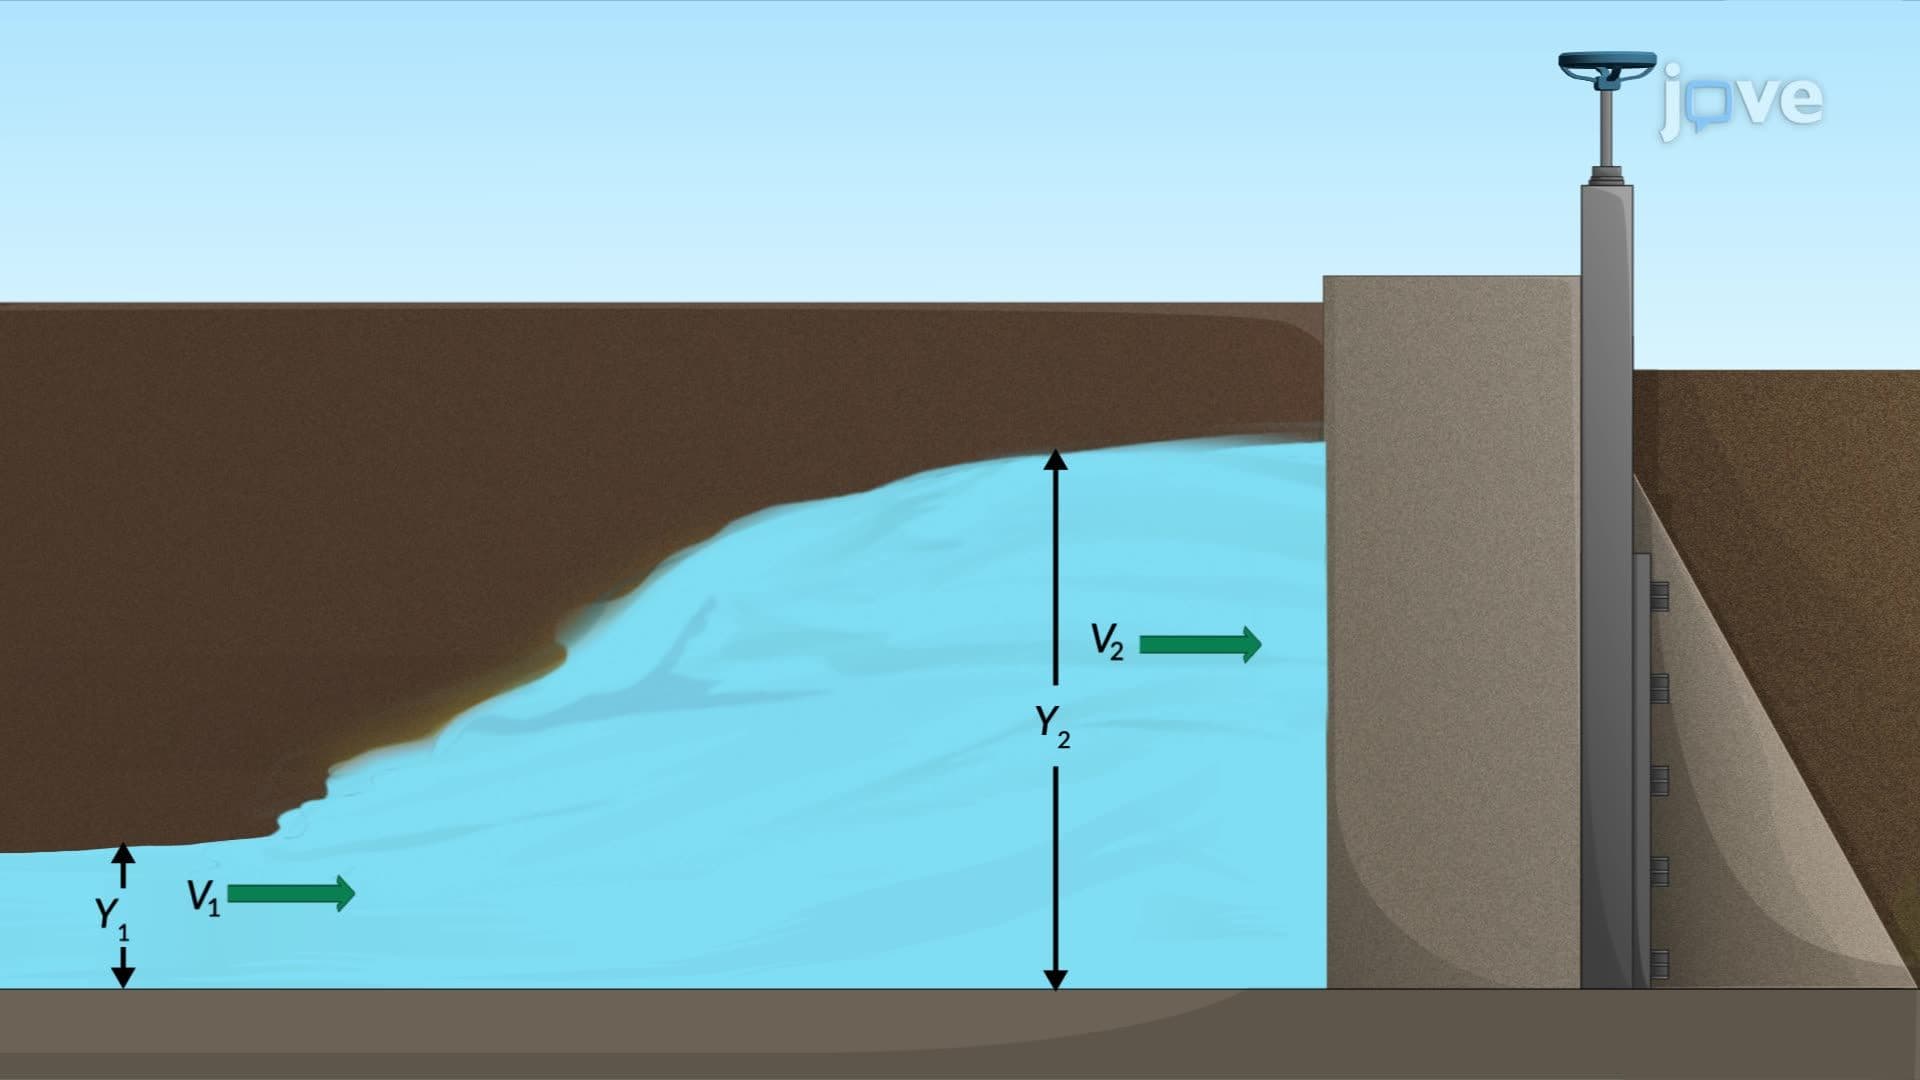
A hydraulic jump is a sudden rise in fluid depth in open channels, occurring when high-velocity (supercritical) flow transitions to low-velocity (subcritical) flow. This phenomenon requires an upstream Froude number greater than 1, as flows with Fr1<1 remain subcritical, making a hydraulic jump impossible due to the need for negative head loss, which violates thermodynamic principles.The characteristics of a hydraulic jump depend on the upstream Froude number and are classified as...
78
 01:16
Hydraulic Jump: Problem Solving
60
To analyze a hydraulic jump in a rectangular channel with a flow speed of 6 meters per second, follow these steps:Calculate Effective Upstream Velocity:When the downstream gate closes, a hydraulic jump forms, traveling upstream at 2 meters per second. This wave speed combines with the initial channel flow velocity, creating an effective upstream velocity.Identify Flow Velocities Before and After the Hydraulic Jump:Upstream of the hydraulic jump, the effective flow velocity includes both the...
60
 01:26
Kinetic Friction
923
Consider a truck trying to pull a stationary car. As the truck exerts a force on the car, static friction is created at the point of contact between the two surfaces. This frictional force resists the car's movement and keeps it at rest. However, when the applied force by the truck surpasses the limiting static frictional force, an interesting phenomenon occurs. The frictional force at the interface reduces to a lower value, known as the kinetic frictional force. At this point, the car...
923
 01:02
Gyroscope
3.0K
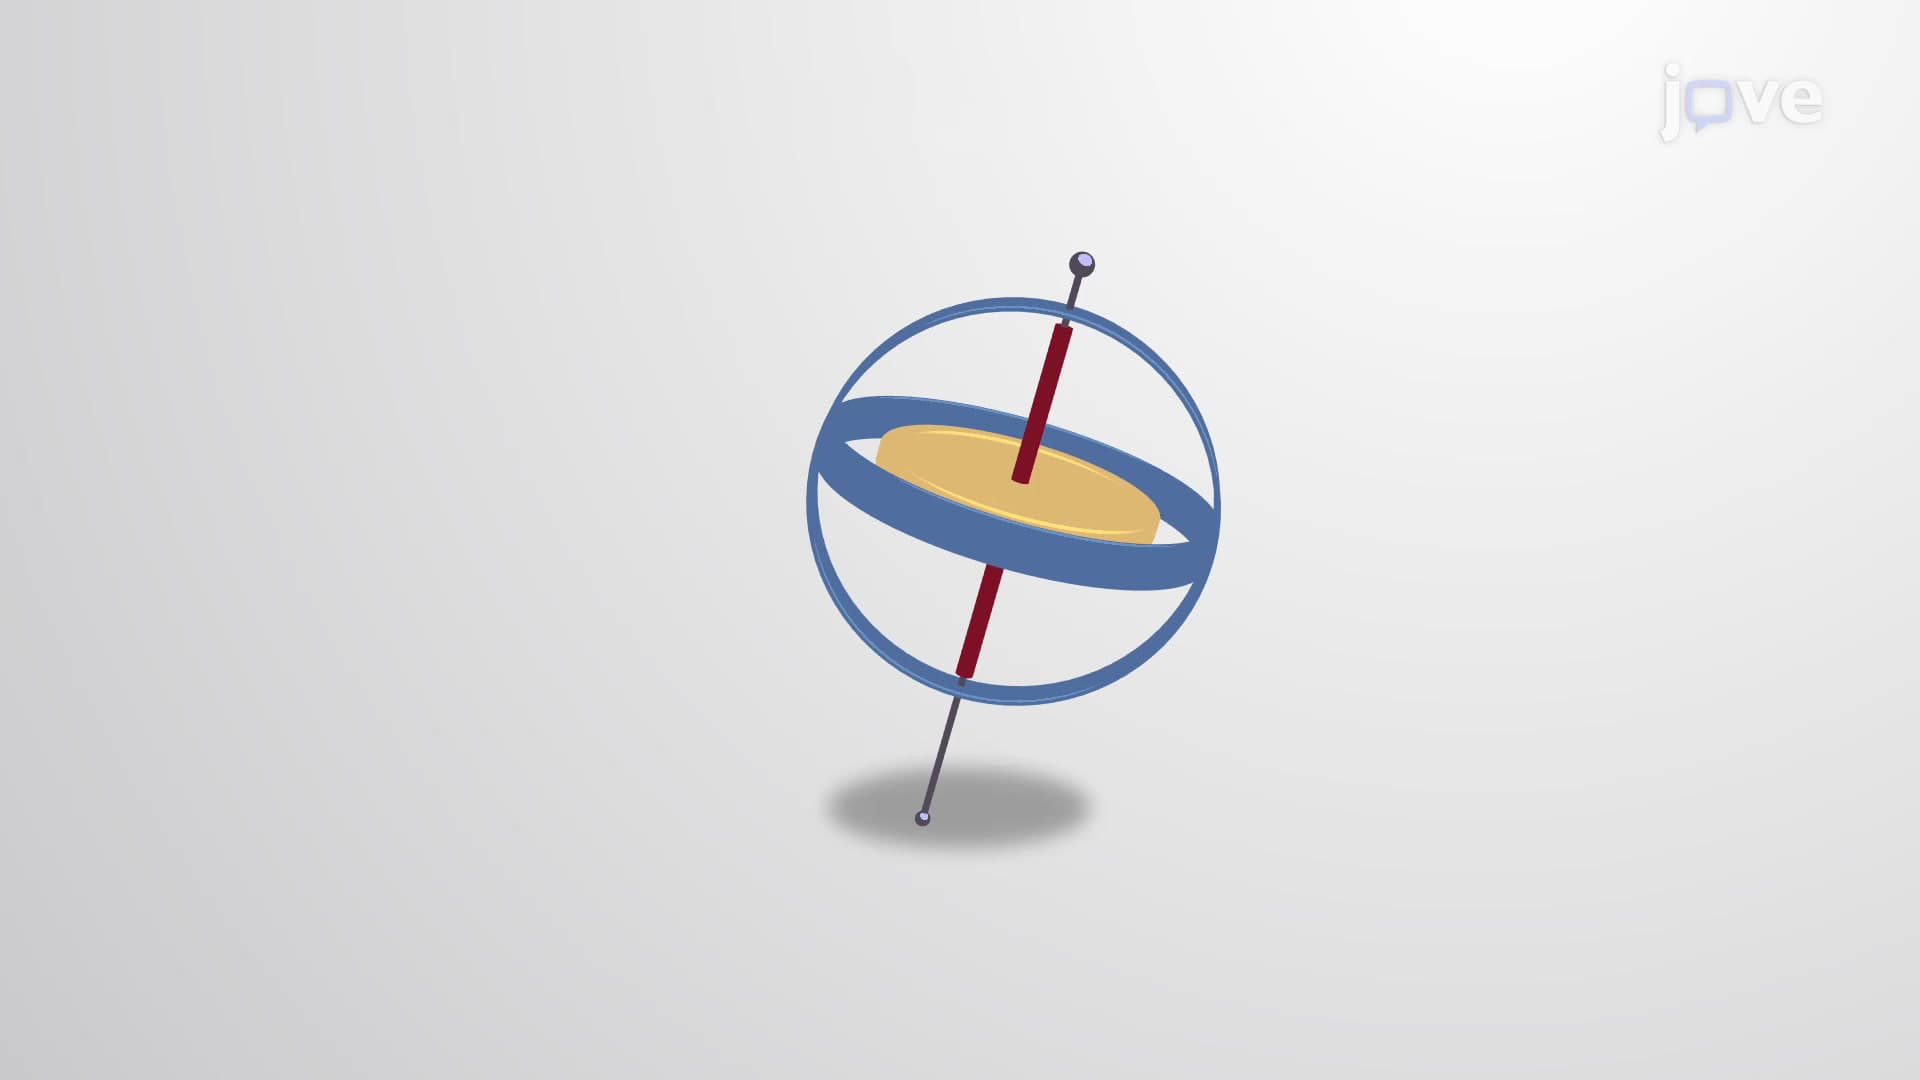
A gyroscope is defined as a spinning disk in which the axis of rotation is free to assume any orientation. When spinning, the orientation of the spin axis is unaffected by the orientation of the body that encloses it. The body or vehicle enclosing the gyroscope can be moved from place to place, while the orientation of the spin axis remains the same. This makes gyroscopes very useful in navigation, especially where magnetic compasses cannot be used, such as in crewed and crewless spacecraft,...
3.0K