
一个基于感知子的多层球形视觉指南针,使用全球特征
Yao Du1, Carlos Mateo2, Omar Tahri2
1Université Bourgogne, 21000 Dijon, France.
Sensors (Basel, Switzerland)
|April 13, 2024

概括
这项研究引入了使用球形时刻和图像面具的视觉指南针,以克服机器人导航中的挑战. 该方法准确地实时估计旋转,适合嵌入式系统.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 计算机视觉 计算机视觉
- 导航系统 导航系统
背景情况:
- 视觉指南针的光度方法面临的挑战是图像区域的变化和对全球特征的翻译运动效应的建模.
- 场景深度的变化,特别是在非平面环境中,使翻译运动对全球特征的影响复杂化.
研究的目的:
- 开发一种强大的视觉指南针方法,使用全球特征来处理图像区域变化和转移运动的变化.
- 为了实现嵌入式机器人应用程序的实时旋转估计.
主要方法:
- 利用球形时刻作为全球特征进行视觉对比.
- 采用图像掩盖来缓解由区域出现/消失引起的全球特征值的突然变化.
- 应用神经网络来建模翻译运动对全球特征的影响.
主要成果:
- 拟议的方法证明了准确和可靠的旋转估计.
- 实现实时推断速度,使其适合嵌入式机器人应用程序.
- 在真实世界和合成数据集上的实验结果验证了该方法的性能与最先进的技术相比.
结论:
- 视觉指南针方法有效地结合了图像掩盖和神经网络,以克服光度导航中的关键挑战.
- 该技术为机器人系统的实时旋转估计提供了快速有效的解决方案.
更多相关视频
 09:27
Using Eye Movements Recorded in the Visual World Paradigm to Explore the Online Processing of Spoken Language
Published on: October 13, 2018
10.0K
 07:12
Development of a Gaze-Contingent Display Framework Designed for Perceptual and Oculomotor Research with Simulated Central Vision Loss
Published on: April 11, 2025
328
相关概念视频
 01:23
Spherical Coordinates
10.1K
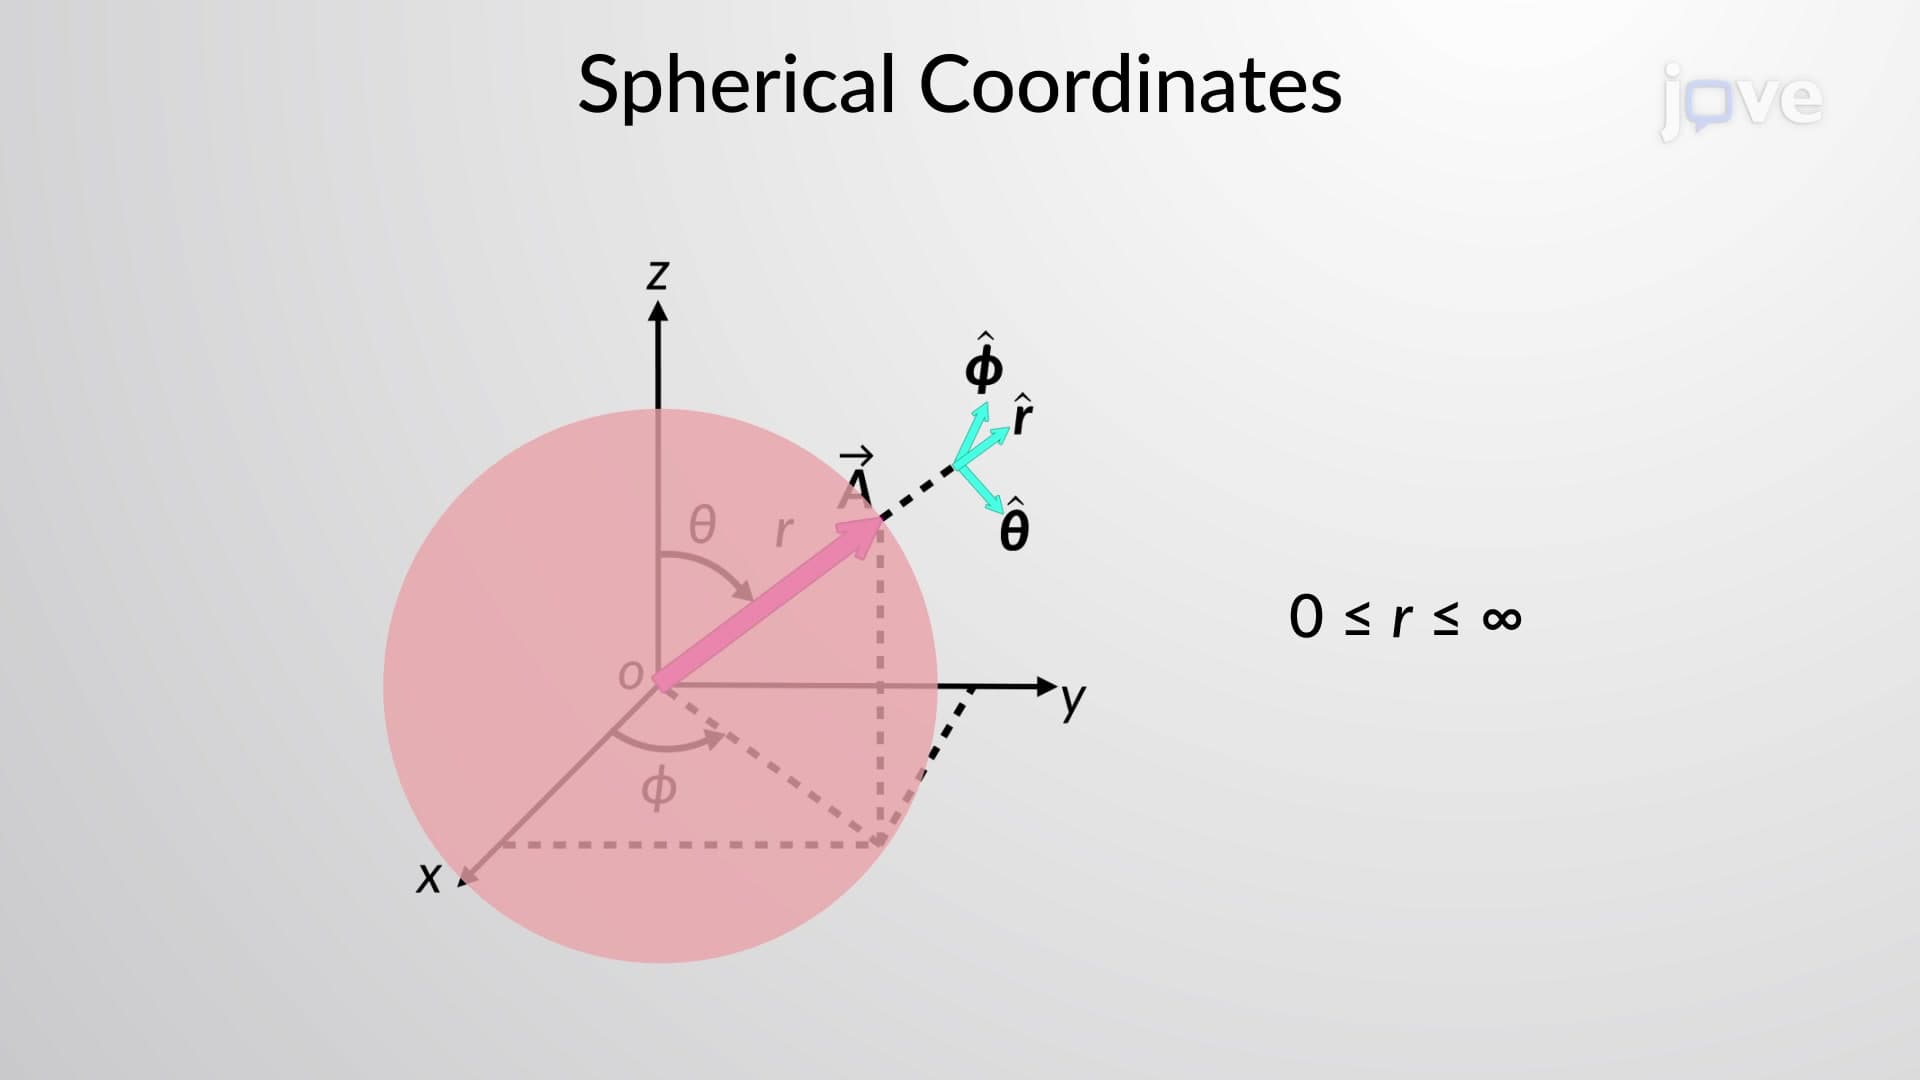
Spherical coordinate systems are preferred over Cartesian, polar, or cylindrical coordinates for systems with spherical symmetry. For example, to describe the surface of a sphere, Cartesian coordinates require all three coordinates. On the other hand, the spherical coordinate system requires only one parameter: the sphere's radius. As a result, the complicated mathematical calculations become simple. Spherical coordinates are used in science and engineering applications like electric and...
10.1K
 01:22
Polar and Cylindrical Coordinates
14.5K
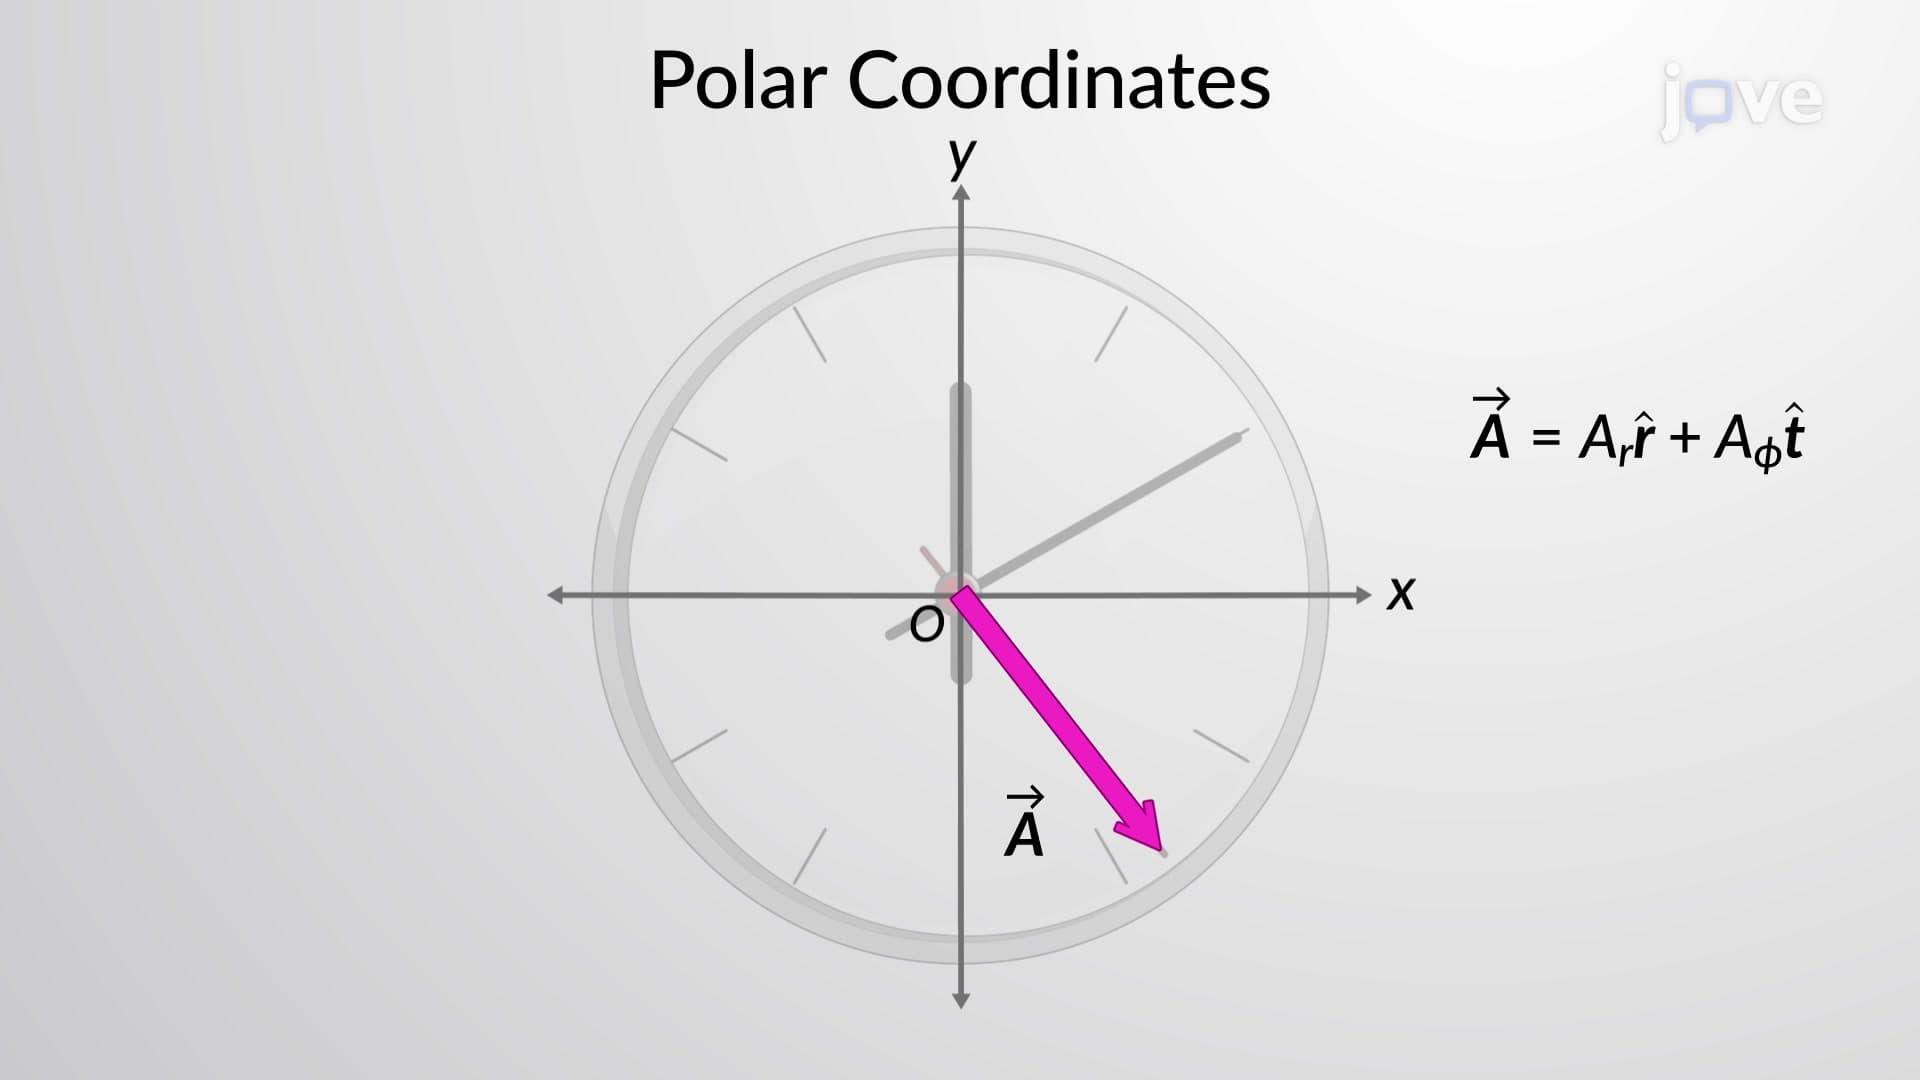
The Cartesian coordinate system is a very convenient tool to use when describing the displacements and velocities of objects and the forces acting on them. However, it becomes cumbersome when we need to describe the rotation of objects. So, when describing rotation, the polar coordinate system is generally used.
14.5K
 01:27
Curvilinear Motion: Polar Coordinates
361
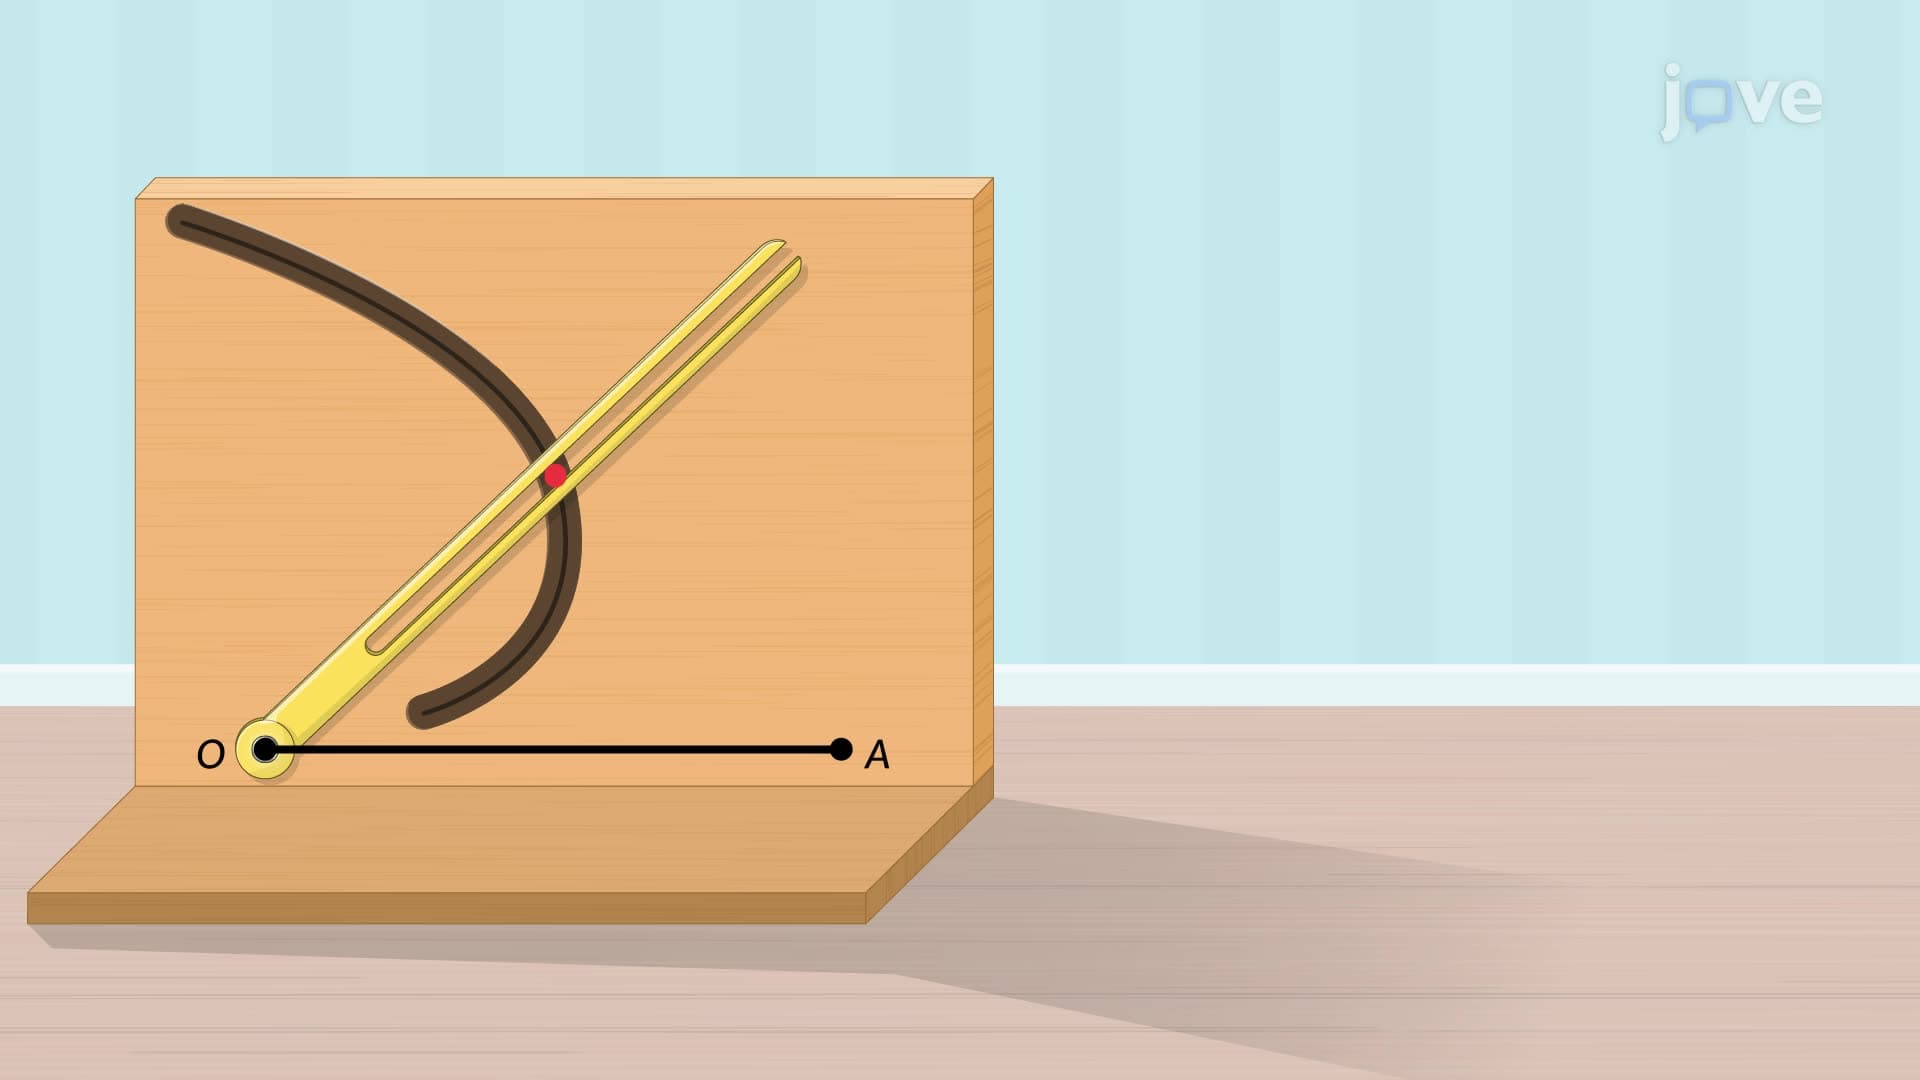
In polar coordinates, the motion of a particle follows a curvilinear path. The radial coordinate symbolized as 'r,' extends outward from a fixed origin to the particle, while the angular coordinate, 'θ,' measured in radians, represents the counterclockwise angle between a fixed reference line and the radial line connecting the origin to the particle.
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
361
 01:28
Field Application of Global Positioning System
45
The Global Positioning System (GPS) has become an indispensable tool in fieldwork, offering unparalleled precision and efficiency for surveying, navigation, and infrastructure development. By harnessing signals from a constellation of satellites, GPS receivers determine the location of objects with remarkable speed and accuracy, often completing calculations within a second.Advantages of Modern GPS TechnologyContemporary GPS receivers are designed to meet the practical demands of field...
45
 01:15
Depth Perception and Spatial Vision
643
Depth perception is the ability to perceive objects three-dimensionally. It relies on two types of cues: binocular and monocular. Binocular cues depend on the combination of images from both eyes and how the eyes work together. Since the eyes are in slightly different positions, each eye captures a slightly different image. This disparity between images, known as binocular disparity, helps the brain interpret depth. When the brain compares these images, it determines the distance to an object.
643
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
402
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
402