

人类头部摄像机稳定使用软的机器人子和坚固的分数顺序控制器
Jorge Muñoz1, Raúl de Santos-Rico2, Lisbeth Mena2
1Center for Automation and Robotics, Spanish National Research Council (CSIC), 28049 Madrid, Spain.
Biomimetics (Basel, Switzerland)
|April 26, 2024

概括
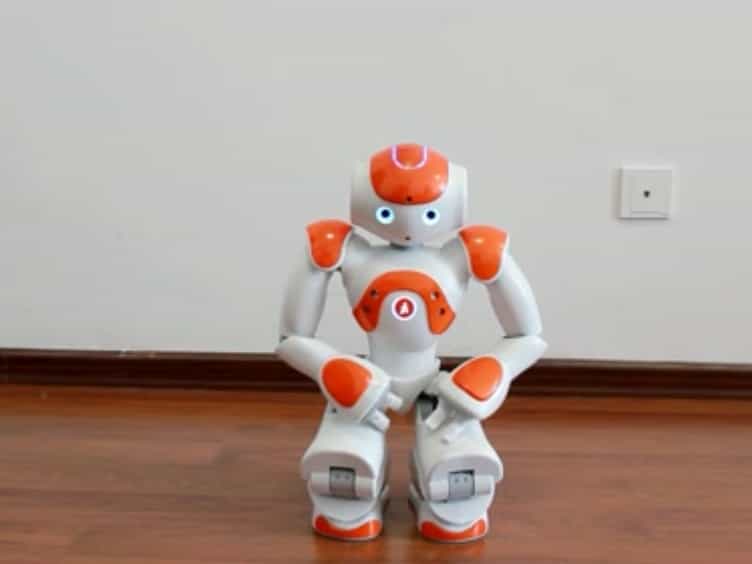
这项研究介绍了一种生物灵感的软子,用于在行走时稳定人形机器人头部摄像头. 分数顺序控制与PID控制相比,显示出更高的稳定性和性能.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 生物机械工程 生物机械工程
- 控制系统 控制系统
背景情况:
- 人形机器人在移动时由于干倾斜而经历头部摄像头干扰.
- 目前的稳定方法依赖于软件纠正或机械运动取消.
- 生物启发的策略为更自然,更顺服的头部运动提供了潜力.
研究的目的:
- 提出和验证人类机器人头部摄像头稳定的一种新型机械方法.
- 为了研究生物灵感软用于头部运动的有效性.
- 为了比较经典的PID和分数顺序控制来稳定柔软的机器人子.
主要方法:
- 开发一个生物灵感的软子,用于人形机器人.
- 实现和比较一个比例积分导数 (PID) 控制器和一个分数顺序控制器.
- 广泛的实验验证,包括真实机器人运动,不同的头部负载和短暂的干扰.
主要成果:
- 分数顺序控制器显著超过了PID控制器.
- 拟议的软部方法在头部摄像头稳定方面表现出增强的稳定性和性能.
- 实验结果验证了分数顺序控制策略的优越性.
结论:
- 生物灵感的软子为人形机器人头部相机稳定提供了有效的机械解决方案.
- 分数顺序控制为复杂,非线性软机器人系统提供了卓越的性能和稳定性.
- 这种方法使人形机器人在移动过程中能够实现更自然,更稳定的头部运动.

相关概念视频
 01:24
One-Degree-of-Freedom System
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Planar Rigid-Body Motion
Understanding the movement of a rigid body in planar motion involves recognizing that every particle within this body is traversing a path that maintains a consistent distance from a specific plane. This concept is fundamental in the study of physics and mechanical engineering, and it allows us to comprehend better how objects move in space.
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Kinematic Equations for Rotation
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...