将拉普拉斯剩余功率序列方法调整为考德里·多德·吉本方程
Samy A Abdelhafeez1, Anas A M Arafa1,2, Yousef H Zahran3
1Department of Mathematics and Computer Science, Faculty of Science, Port Said University, Port Said, Egypt.
Scientific reports
|April 29, 2024

概括
本研究介绍了拉普拉斯余数列方法来解决分数考德里·多德·吉本方程 (CDGE). 这种新的方法为科学和工程中的复杂现象建模提供了更快,更准确的解决方案.
科学领域:
- 应用数学 应用数学 应用数学
- 非线性动力学是一种非线性动力学.
- 分数微积分的计算.
背景情况:
- 非线性微分方程对于模拟现实世界现象至关重要.
- 考德里·多德·吉本方程 (CDGE) 描述了各种化学,物理和生物过程.
- 分数衍生品比整数顺序衍生品更具现实性和灵活性.
研究的目的:
- 提出和验证拉普拉斯剩余功率序列方法 (LRPSM) 解决分数考德里·多德·吉本方程 (fCDGE).
- 为了证明fCDGE的LRPSM的效率和准确性.
- 分析各种分数顺序的解决方案的行为.
主要方法:
- 该研究采用拉普拉斯剩余功率序列方法 (LRPSM).
- 该LRPSM是用来找到分数考德里·多德·吉本方程的分析解决方案.
- 数字模拟和图形表示用于展示结果.
主要成果:
- 拉普拉斯剩余功率序列方法为分数考德里·多德·吉本方程提供了高效和快速的解决方案.
- 该方法证明了快速收,产生准确的结果.
- 对不同分数顺序的结果的分析强调了该方法的稳定性.
结论:
- 拟议的拉普拉斯剩余功率序列方法是解决像fCDGE这样的分数非线性微分方程的可靠技术.
- 分数顺序模型为描述复杂系统提供了增强的现实主义.
- 对于应用数学和相关领域的研究人员来说,LRPSM是一个有希望的工具.
相关概念视频
 01:25
Poisson's And Laplace's Equation
2.8K
The electric potential of the system can be calculated by relating it to the electric charge densities that give rise to the electric potential. The differential form of Gauss's law expresses the electric field's divergence in terms of the electric charge density.
2.8K
 01:22
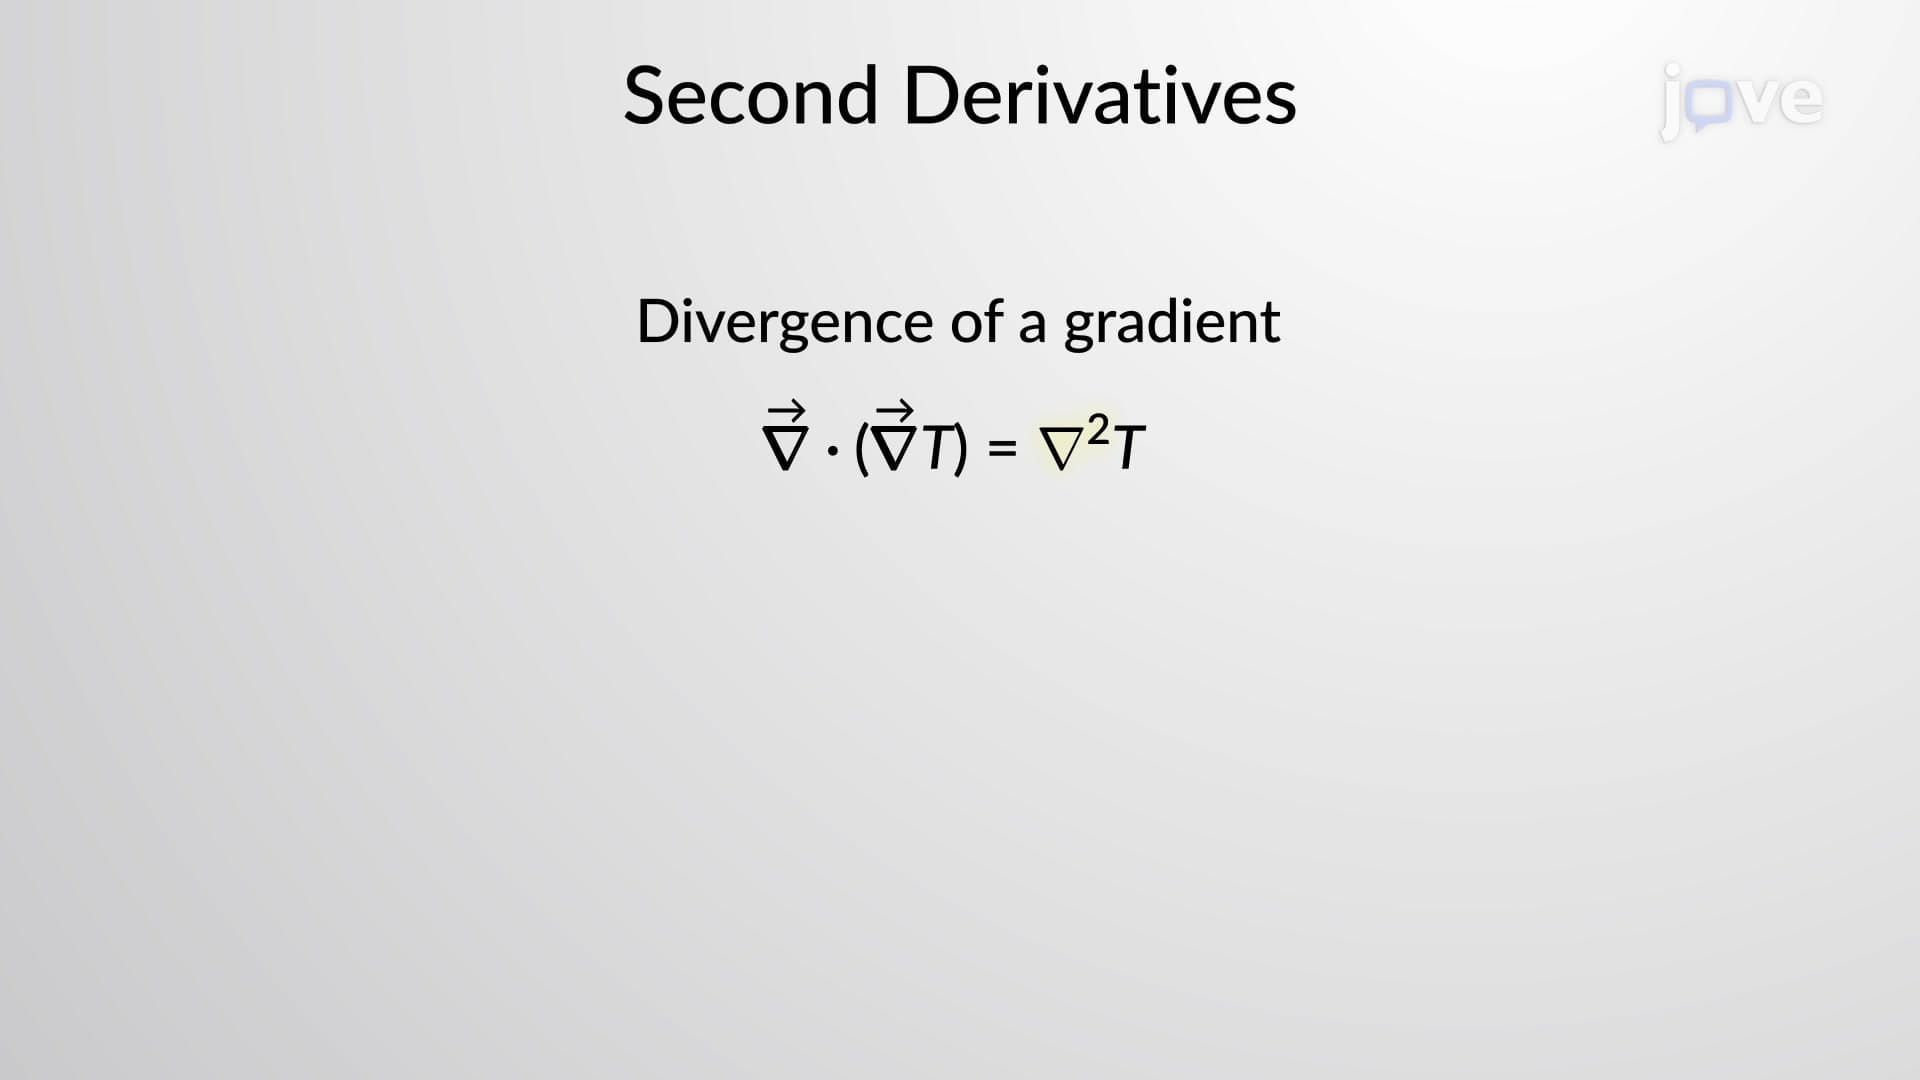
Second Derivatives and Laplace Operator
1.2K
The first order operators using the del operator include the gradient, divergence and curl. Certain combinations of first order operators on a scalar or vector function yield second order expressions. Second-order expressions play a very important role in mathematics and physics. Some second order expressions include the divergence and curl of a gradient function, the divergence and curl of a curl function, and the gradient of a divergence function.
Consider a scalar function. The curl of its...
Consider a scalar function. The curl of its...
1.2K
 01:11
Types of Responses of Series RLC Circuits
883
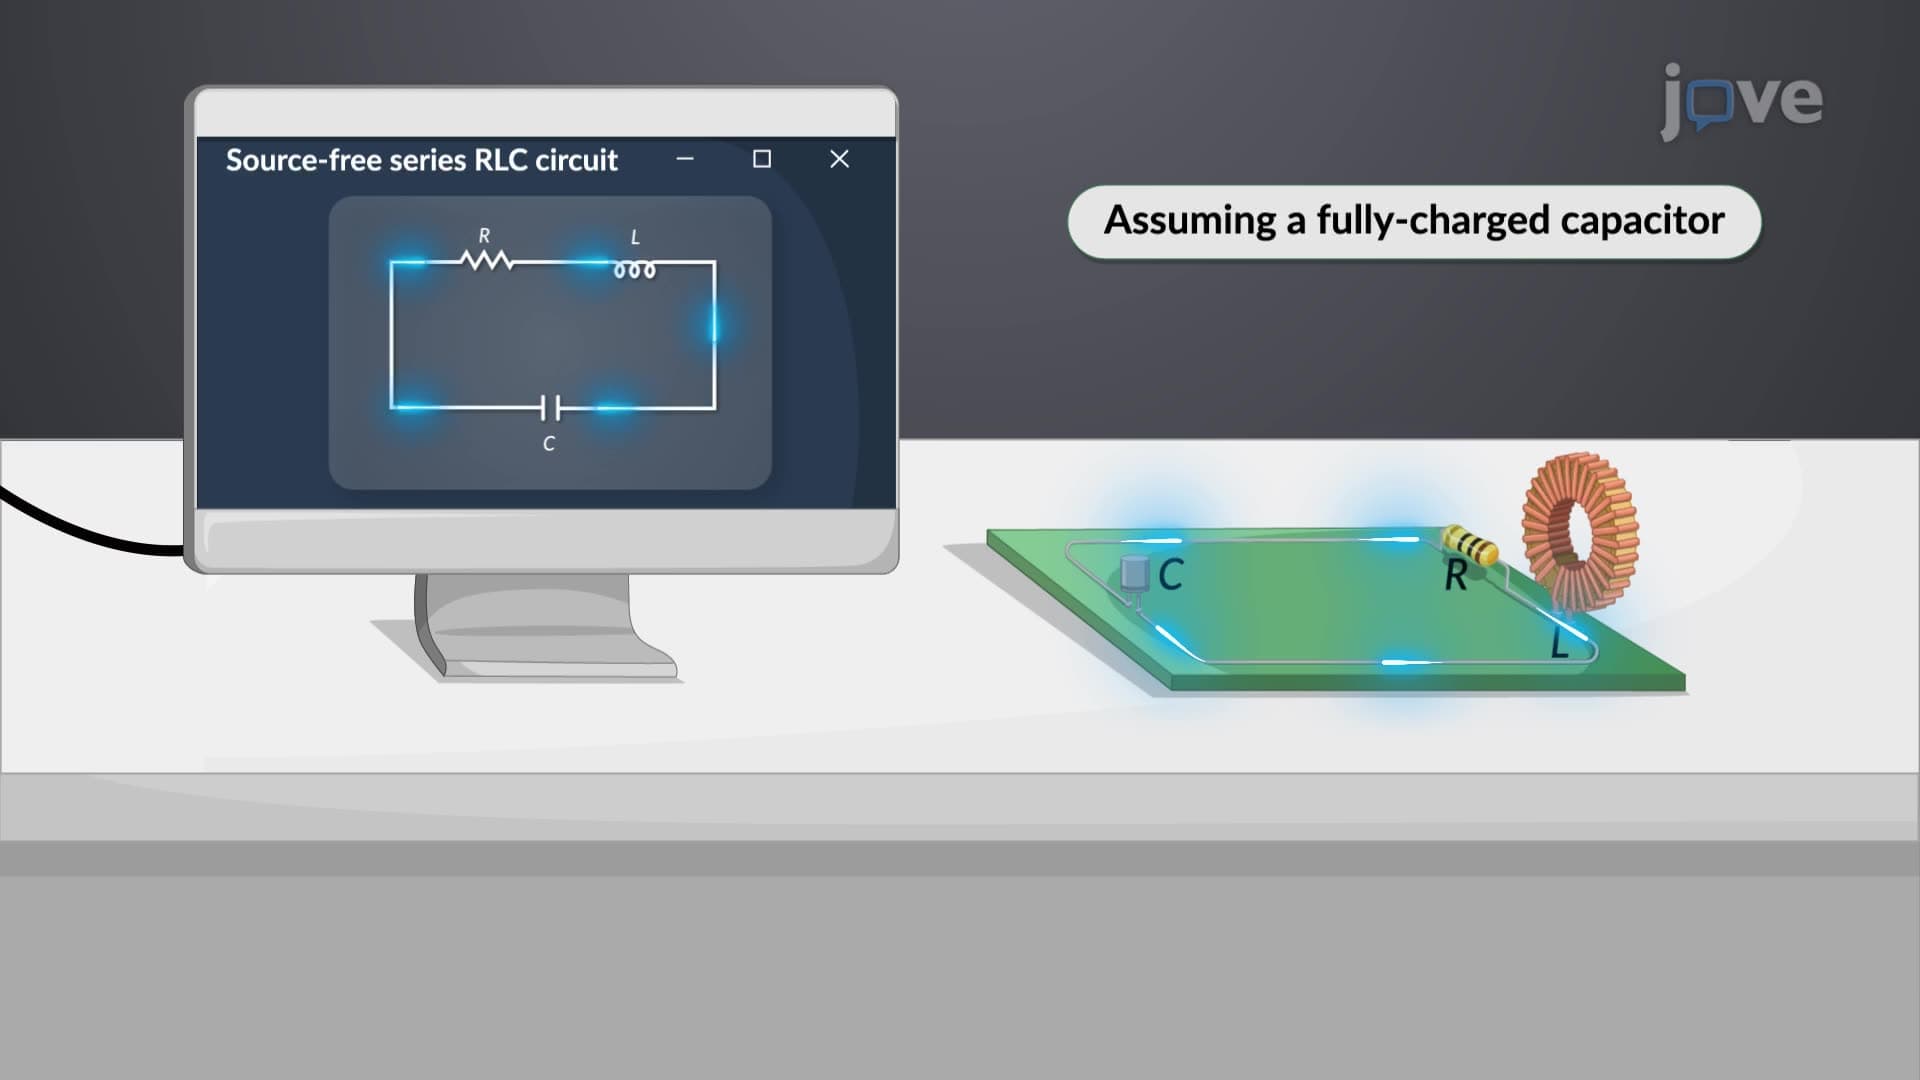
A second-order differential equation characterizes a source-free series RLC circuit, marking its distinct mathematical representation. The complete solution of this equation is a blend of two unique solutions, each linked to the circuit's roots expressed in terms of the damping factor and resonant frequency.
883
 01:30
RLC Circuit as a Damped Oscillator
966
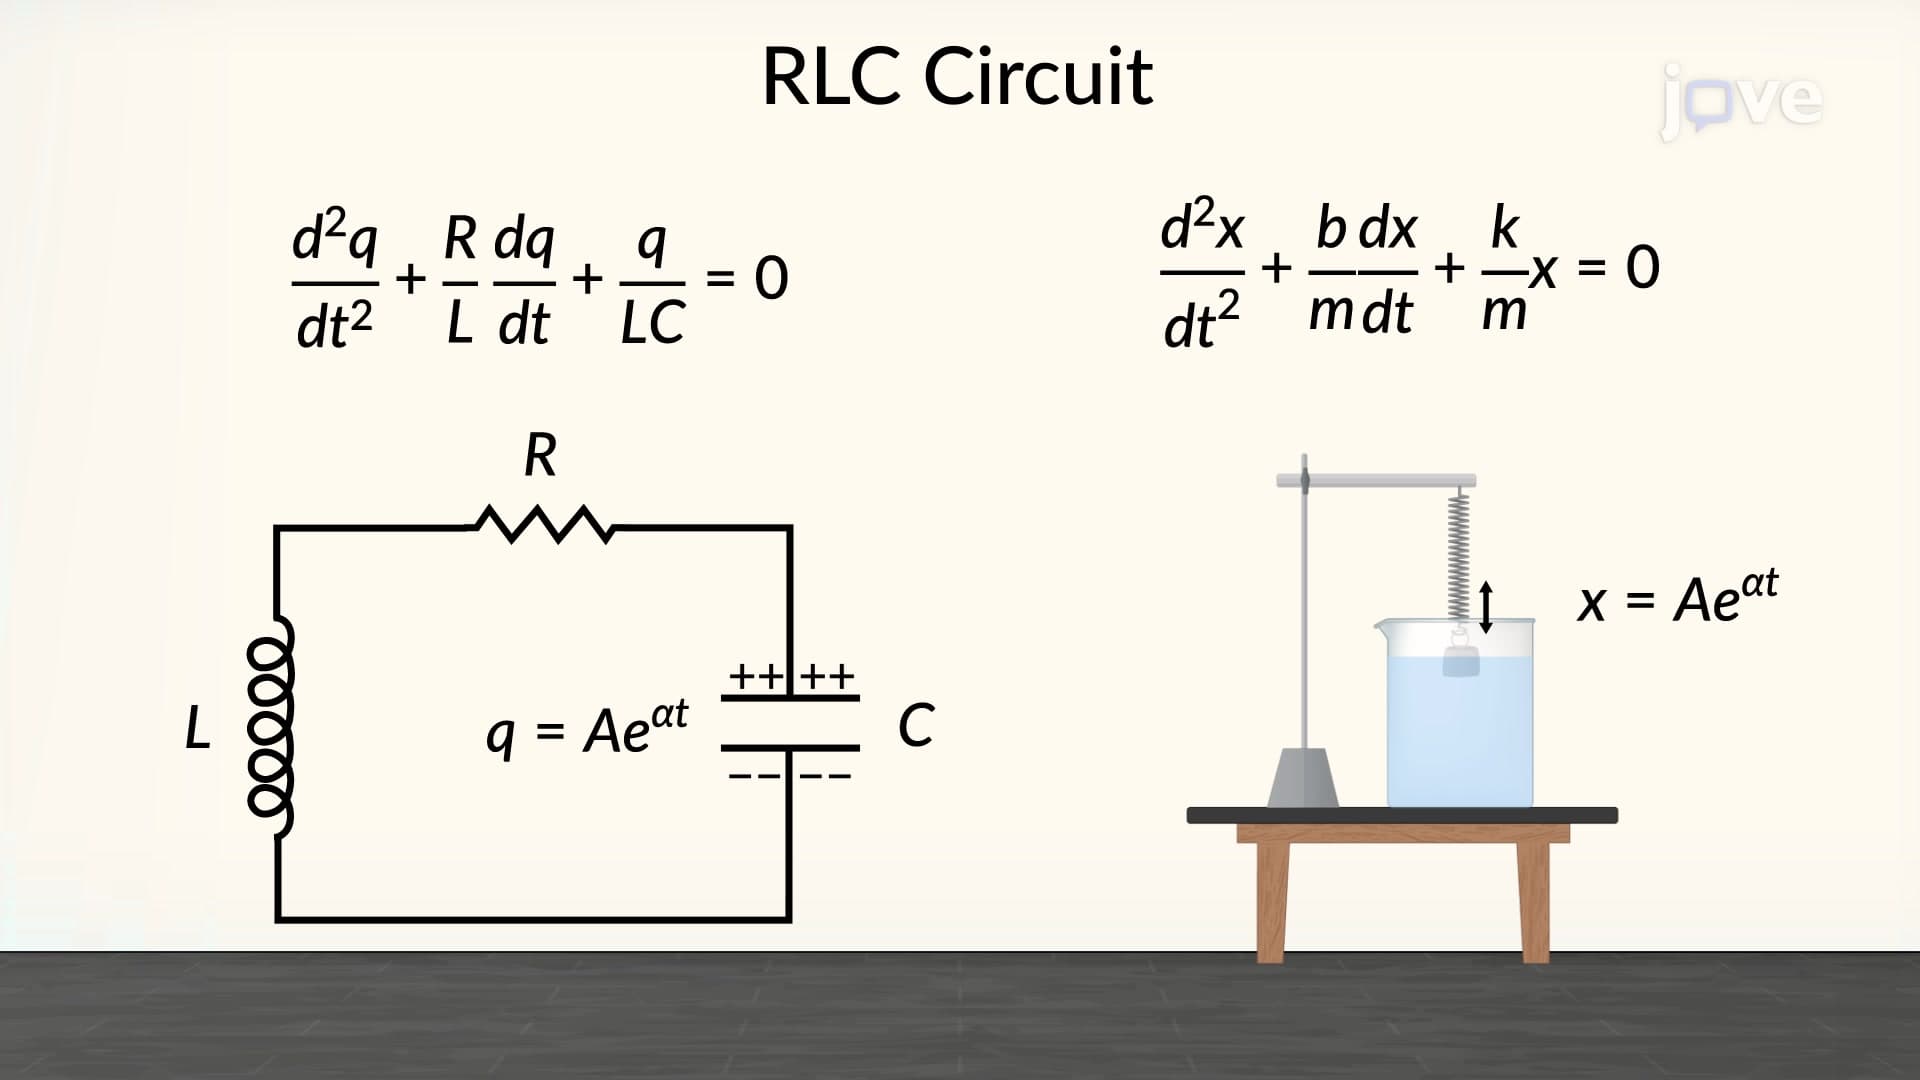
An RLC circuit combines a resistor, inductor, and capacitor, connected in a series or parallel combination.
Consider a series RLC circuit. Here, the presence of resistance in the circuit leads to energy loss due to joule heating in the resistance. Therefore, the total electromagnetic energy in the circuit is no longer constant and decreases with time. Since the magnitude of charge, current, and potential difference continuously decreases, their oscillations are said to be damped. This is...
Consider a series RLC circuit. Here, the presence of resistance in the circuit leads to energy loss due to joule heating in the resistance. Therefore, the total electromagnetic energy in the circuit is no longer constant and decreases with time. Since the magnitude of charge, current, and potential difference continuously decreases, their oscillations are said to be damped. This is...
966
 01:18
Second Order systems II
107
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
107
 01:26
Linear Approximation in Frequency Domain
89
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
89