相关实验视频
Updated: Jun 27, 2025

10:19

Studying the Neural Basis of Adaptive Locomotor Behavior in Insects
Published on: April 13, 2011
12.9K
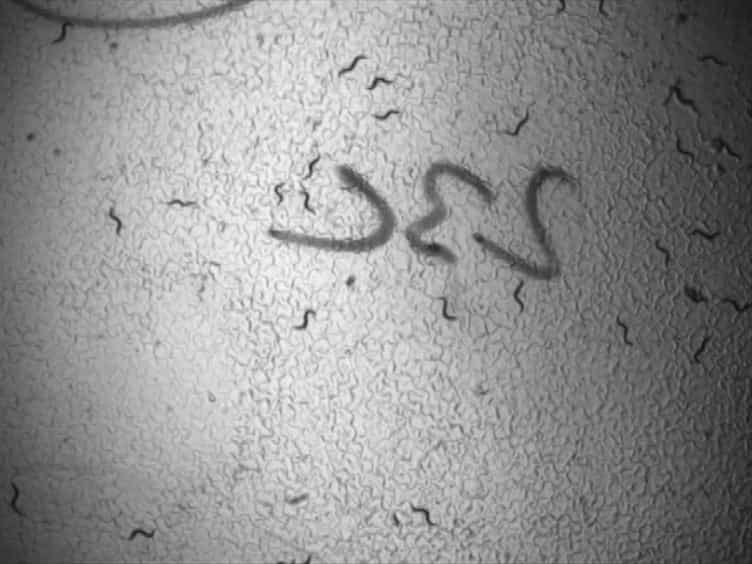
沙漠行走轨迹的几何多尺度曲折性
Harald Wolf1, Nina Baldy2, Sarah Elisabeth Pfeffer1
1Institute of Neurobiology, Ulm University, Albert-Einstein-Allee 11, 89081 Ulm, Germany.
The Journal of experimental biology
|May 1, 2024

概括
沙漠表现出复杂的导航模式,在他们的搜索行为中显示布朗运动,甚至在直接接近时. 经验完善了他们的路径,导致更直接的路线和更专注的目标附近的搜索.
科学领域:
- 动物行为 动物行为
- 昆虫的导航方式
- 运动分析 运动分析
背景情况:
- 沙漠以其复杂的导航能力而闻名.
- 了解昆虫的路径特征对于理解它们的搜索策略至关重要.
研究的目的:
- 分析沙漠的行走轨迹和不同长度尺度的方向变化.
- 为了调查布朗运动在导航中的存在和影响.
主要方法:
- 通过计算轨迹增量之间的角度 θ 来量化方向变化.
- 分析了跨多个长度尺度 (λ) 的路径特征.
- 在搜索和接近行为期间检查了与均角度分布的偏差.
主要成果:
- 在不同的长度尺度上观察到布朗运动特征,包括在所谓的线性方法中.
- 识别了与均角度分布的微小偏差,特别是在目标位置附近.
- 经验表明,与料和巢位置的经验导致更直接的方法和更专注的搜索.
结论:
- 沙漠的导航表现出无处不在的布朗运动特征,甚至在接近路径.
- 偏离目标附近的随机步行模式,表明有结构的搜索行为.
- 经验显著提高了导航策略的效率和直接性.

相关概念视频
 01:18
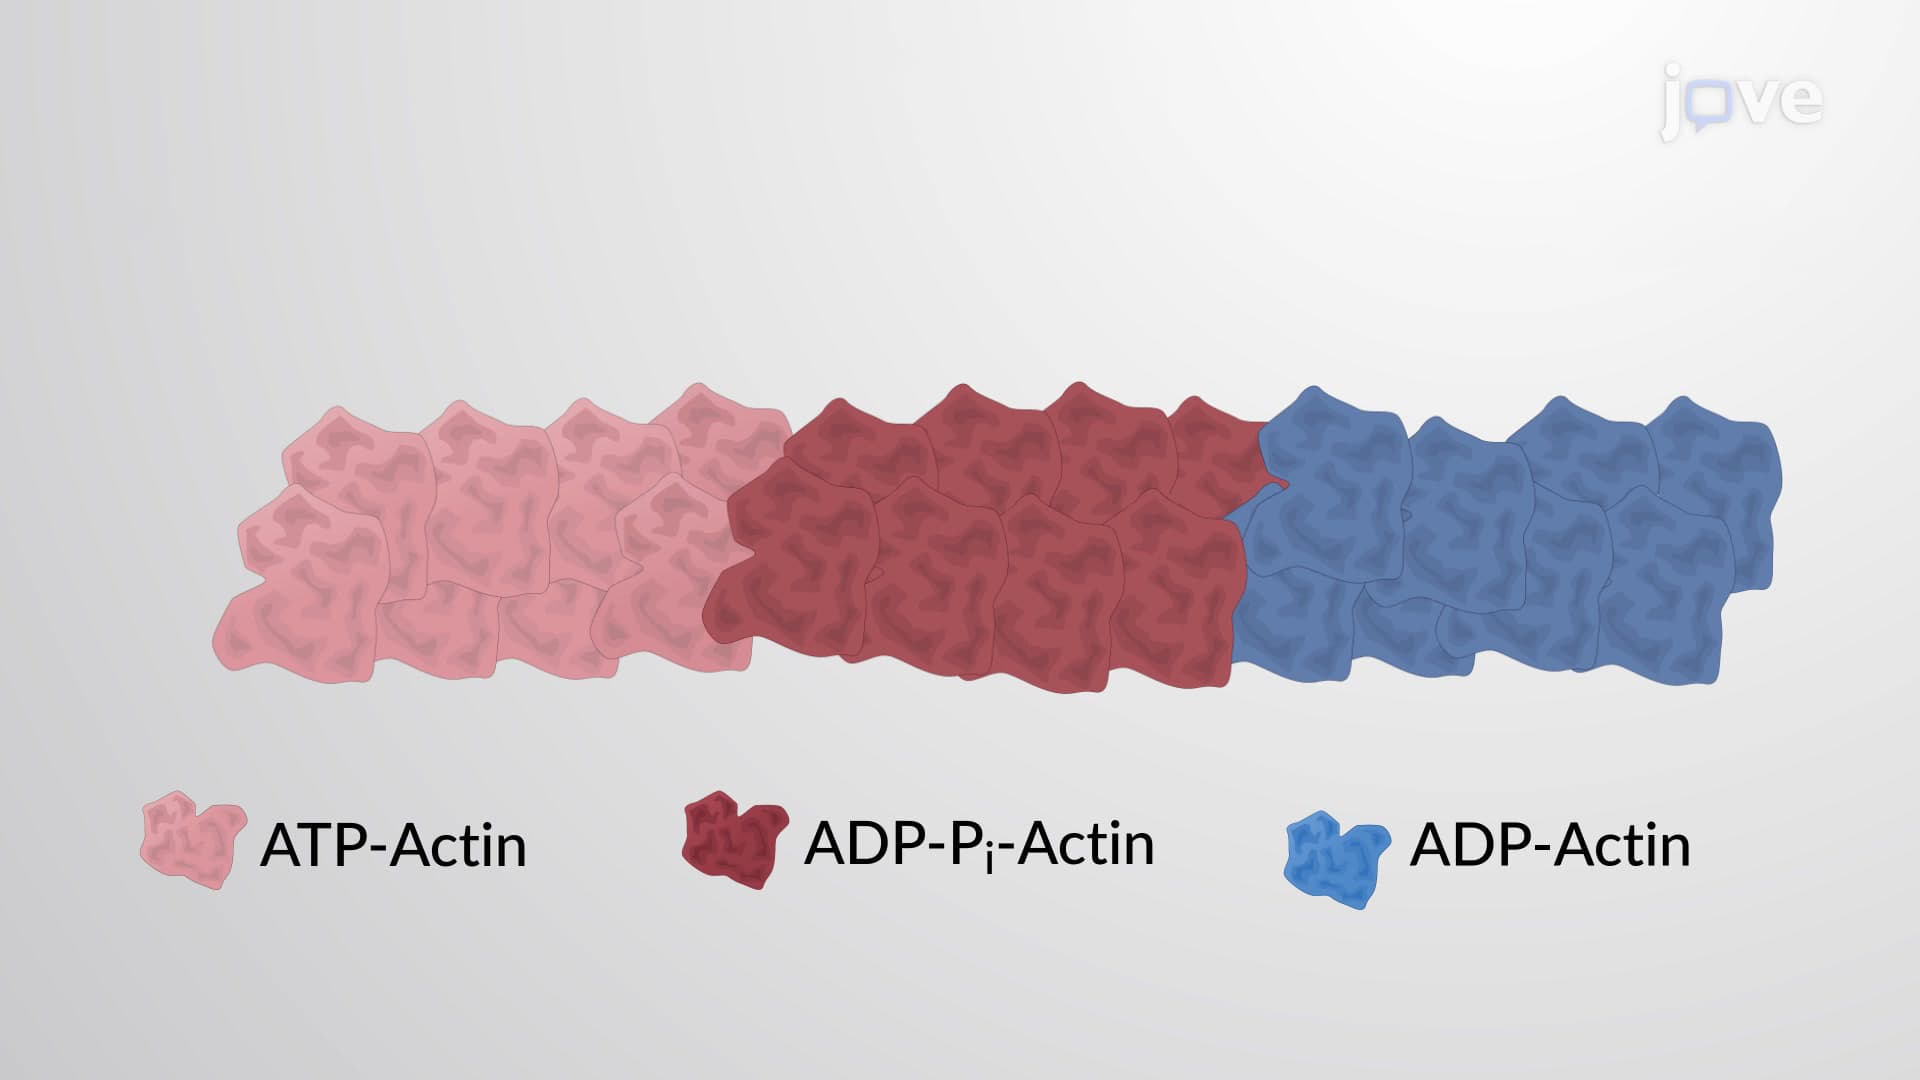
Actin Treadmilling
8.0K
Actin filaments undergo polymerization and depolymerization from either end. The polymerization and depolymerization rates depend on the cytosolic concentration of free G-actins. The polymerization rate is generally higher at the plus or barbed end, while the depolymerization rate is higher at the minus or pointed end. At a steady state, critical concentration describes the concentration of free G-actin monomers at which the polymerization rate at the plus end is equal to that of the...
8.0K
 01:25
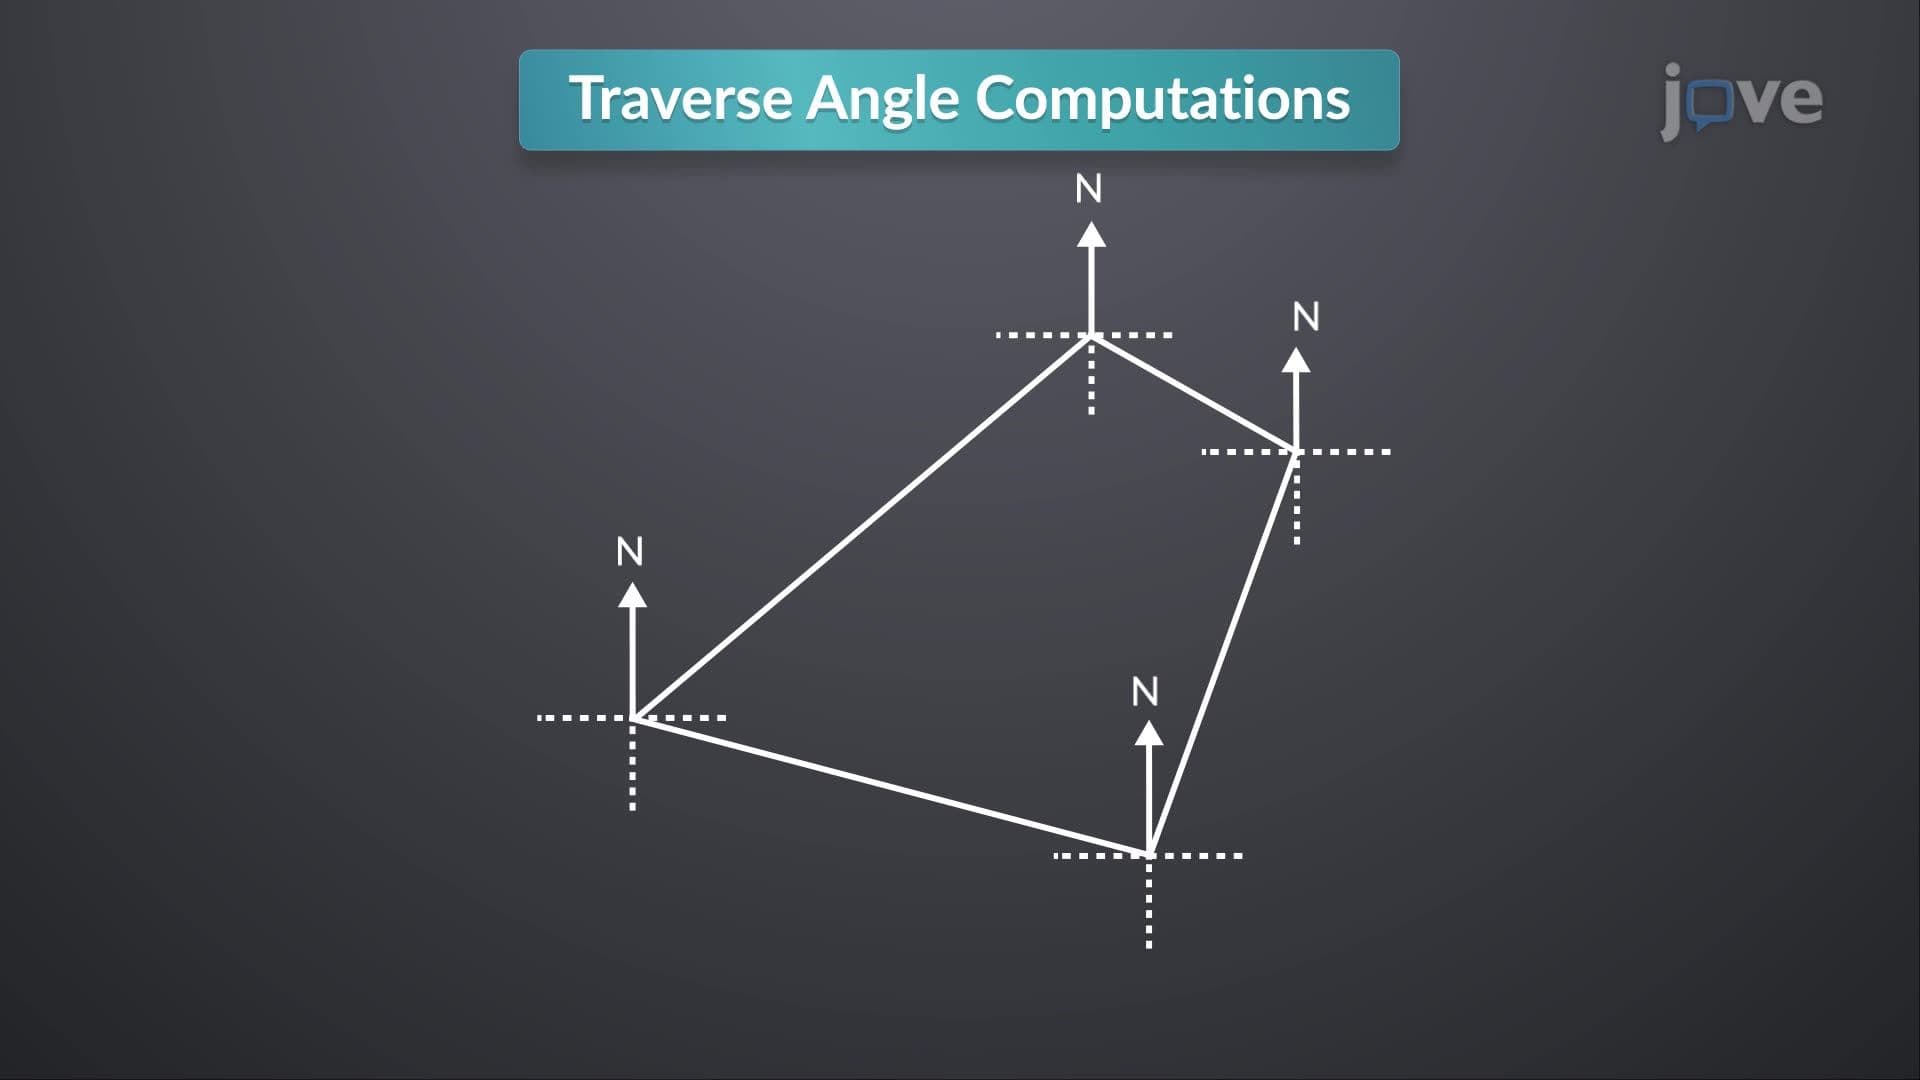
Design Example: Traverse Angle Computations
77
Traverse angle computations are a critical component of surveying, used to compute the internal angles within a closed traverse. A traverse consists of a series of connected lines forming a closed loop, often used for land boundary delineation or mapping. Calculating the internal angles ensures accuracy in the traverse geometry and is essential for checking survey data integrity.The process begins with known azimuths and bearings of the traverse sides. Internal angles at each vertex are...
77
 01:23
Curvilinear Motion: Rectangular Components
447
Curvilinear motion characterizes the movement of a particle or object along a curved path, notably evident when envisioning a car navigating a winding road. If the car starts at point A, its position vector is established within a fixed frame of reference, where the ratio of the position vector to its magnitude signifies the unit vector pointing in the position vector's direction.
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
447
 01:27
Curvilinear Motion: Normal and Tangential Components
395
When a car traverses a curved road, its motion can be elucidated by breaking it down into tangential and normal components. The car-centric coordinates attached to the vehicle move with it.
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
395
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
401
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
401
 01:25
Relative Motion Analysis using Rotating Axes
460
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
460