使用通用完整的同位素不变量加速材料属性预测
Jonathan Balasingham1, Viktor Zamaraev2, Vitaliy Kurlin2
1Department of Computer Science, University of Liverpool, Liverpool, L69 3BX, UK. jbalasin@liverpool.ac.uk.
Scientific reports
|May 2, 2024

概括
用于预测晶体属性的机器学习模型使用点向距离分布 (PDD) 表示方式更快,更准确. 这种新的方法有效地捕获了晶体结构,以改善材料发现.
科学领域:
- 材料科学 材料科学 材料科学
- 计算化学的计算化学
- 机器学习 机器学习
背景情况:
- 机器学习加速周期性材料和晶体属性预测,为经典模拟提供了有效的替代方案.
- 代表无边界周期性晶体具有挑战性,与有限的分子或蛋白质不同,需要机器学习算法的专业方法.
研究的目的:
- 适应点向距离分布 (PDD) 作为机器学习中周期晶体的强大表示.
- 开发和评估一个整合PDD的变压器模型,并将其与构成信息相结合,以便更好地预测晶体属性.
主要方法:
- 适应了点向距离分布 (PDD),一个连续和完整的等比不变,用于周期性晶体表示.
- 开发了一个变压器模型,其中包含了一个修改后的自我注意机制,将PDD与构成信息的空间编码相结合.
- 验证了材料项目和Jarvis-DFT数据库上的模型.
主要成果:
- 在剑桥结构数据库中,PDD成功区分了超过66万个周期性晶体,仅仅基于它们的结构.
- 开发的变压器模型的准确性与水晶性质预测任务的最先进方法相美.
- 基于PDD的模型显示,与现有方法相比,训练和预测时间显著更快.
结论:
- 点向距离分布 (PDD) 在机器学习中为周期晶体提供了有效和计算效率高的表示.
- 这种方法提高了晶体属性预测的速度和准确性,促进了更快的材料发现和设计.
相关概念视频
 01:22
Generalized Hooke's Law
909
The generalized Hooke's Law is a broadened version of Hooke's Law, which extends to all types of stress and in every direction. Consider an isotropic material shaped into a cube subjected to multiaxial loading. In this scenario, normal stresses are exerted along the three coordinate axes. As a result of these stresses, the cubic shape deforms into a rectangular parallelepiped. Despite this deformation, the new shape maintains equal sides, and there is a normal strain in the direction of the...
909
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
333
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
333
 01:15
Kinematic Equations: Problem Solving
12.4K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
12.4K
 01:10
Relative Motion Analysis - Acceleration
349
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
349
 01:18
Kinematic Equations - III
7.6K
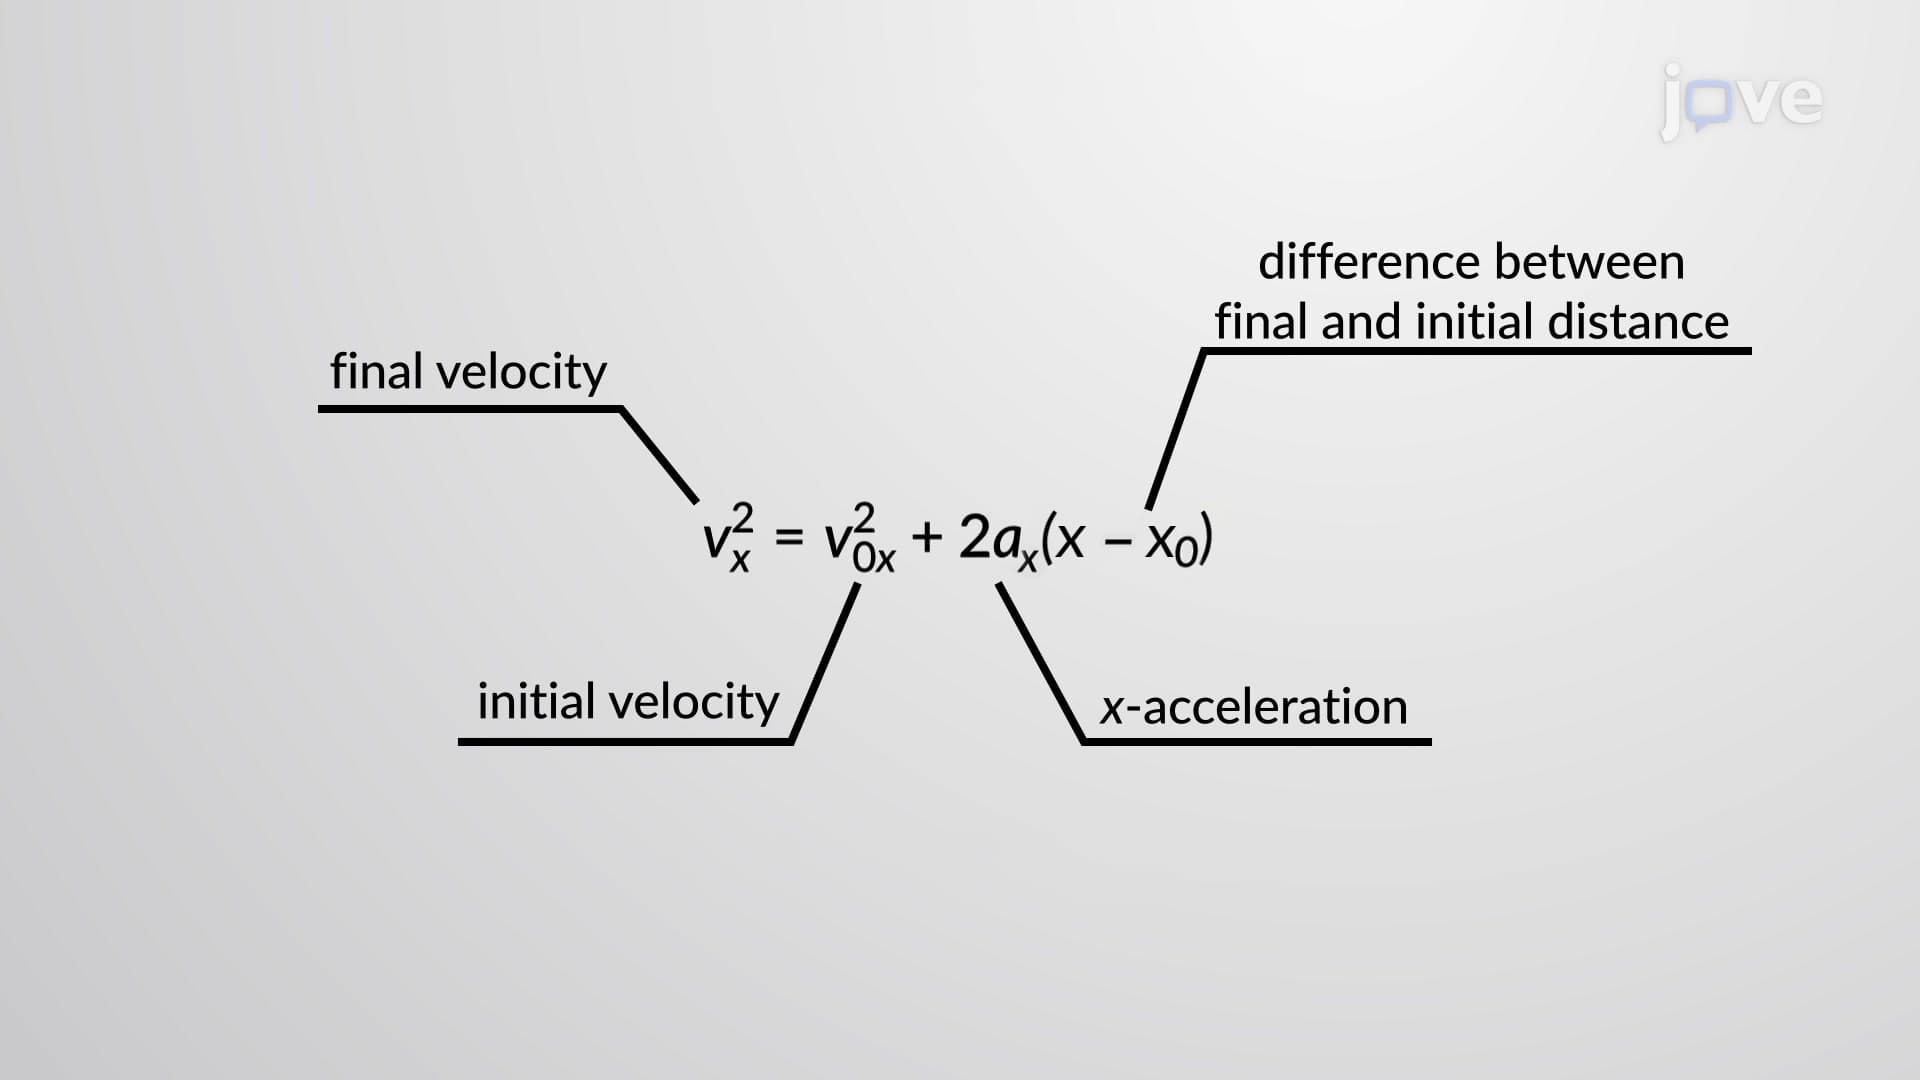
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
7.6K
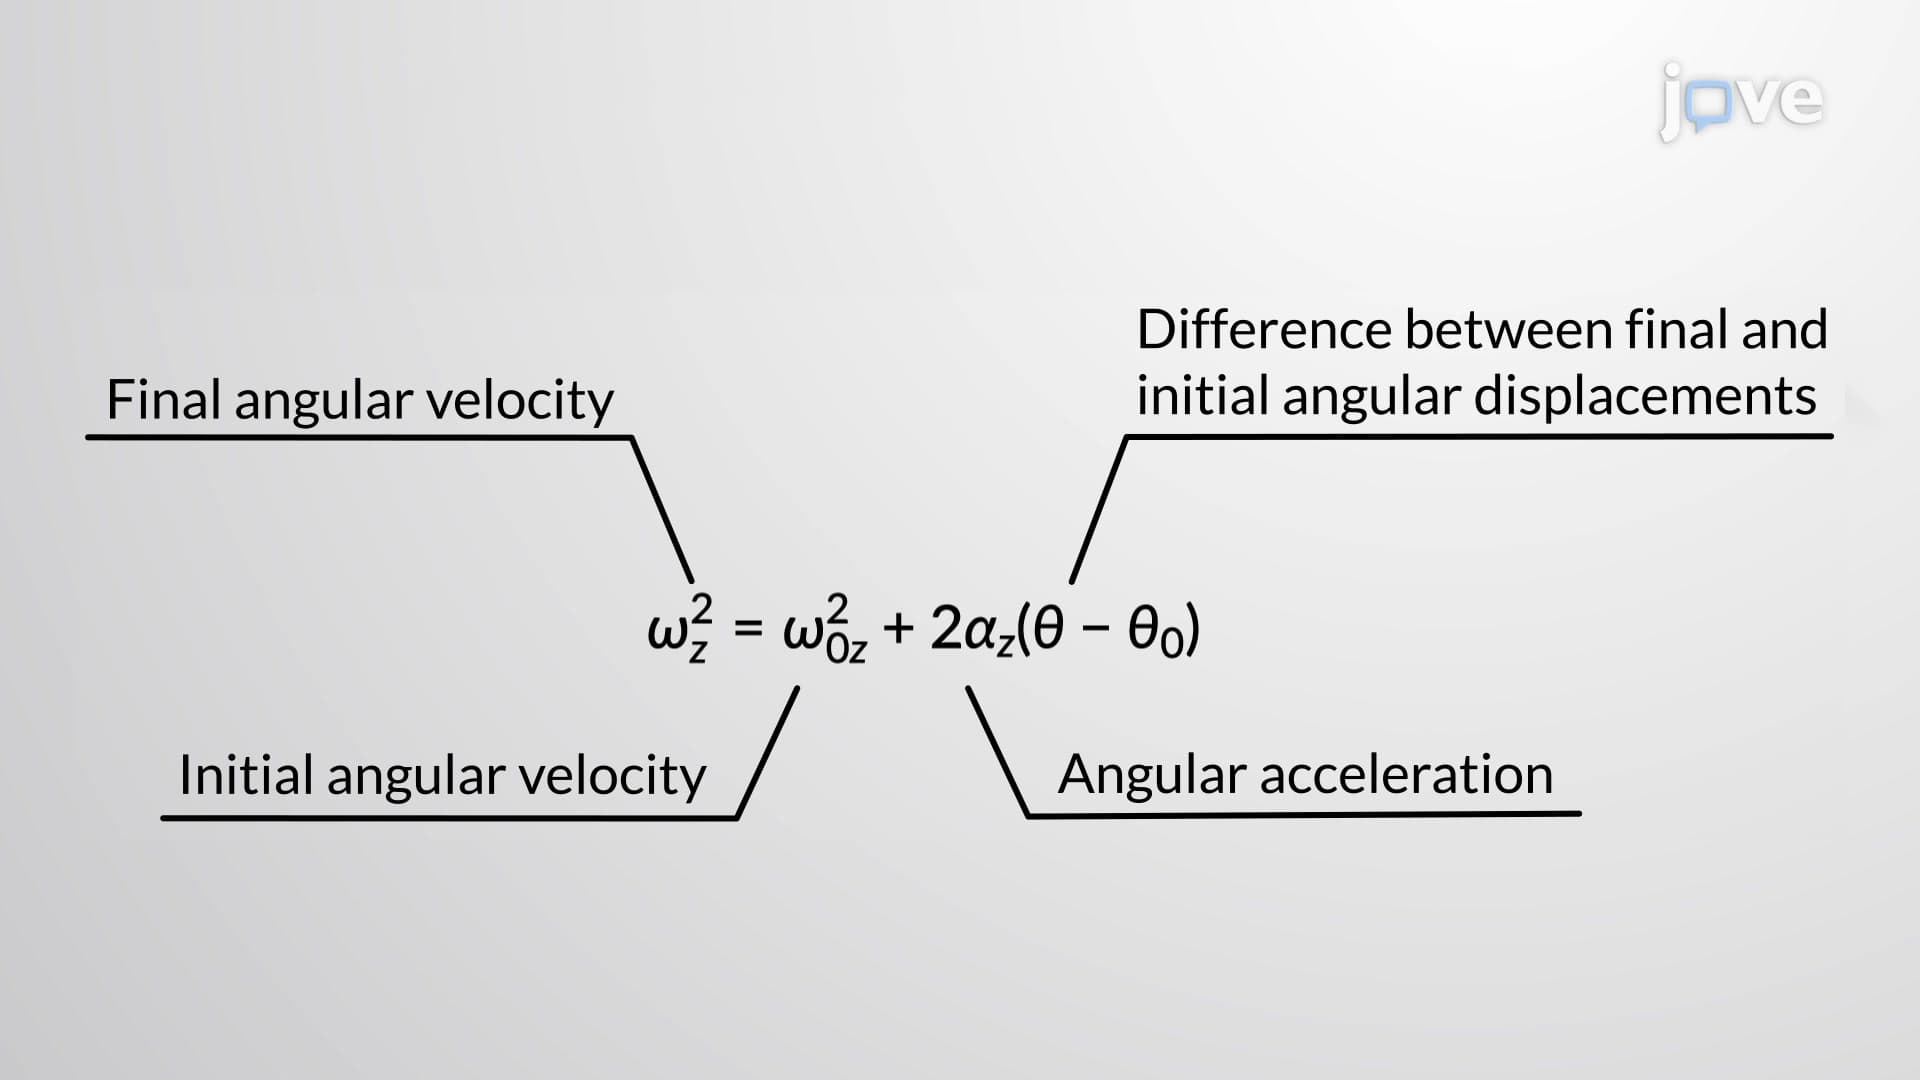 01:16
Rotation with Constant Angular Acceleration - II
6.0K
Kinematics is the description of motion. The kinematics of rotational motion discusses the relationships between rotation angle, angular velocity, angular acceleration, and time. One can describe many things with great precision using kinematics, but kinematics does not consider causes. For example, a large angular acceleration describes a very rapid change in angular velocity without any consideration of its cause. Thus, rotational kinematics does not represent the laws of nature.
The first...
The first...
6.0K