相关实验视频
Updated: Jul 6, 2026

08:12
Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
9.5K
在不扰乱和扰乱的步态中,脚位控制策略的概括性
Chang Liu1, Francisco J Valero-Cuevas1,2,3, James M Finley1,2,3
1Department of Biomedical Engineering, University of Southern California, Los Angeles, CA, USA.
Royal Society open science
|May 3, 2024

概括
在行走过程中控制脚部位置并不是单一的线性映射. 人类平衡控制不同地适应前向和后向扰动,这表明使用不同的策略来防止跌倒.
科学领域:
- 生物力学 生物力学
- 人类运动控制器
- 机器人技术 机器人技术 机器人技术
背景情况:
- 脚的位置对于在走路时保持平衡至关重要.
- 在平稳状态行走时,脚的位置跟着质量中心 (CoM) 状态的线性关系.
- 这种映射对乱行走的概括性,特别是在潜在跌倒后恢复期间,仍然不清楚.
研究的目的:
- 调查是否从质量中心 (CoM) 状态对脚部位置的线性映射可以概括为扰乱行走.
- 评估控制策略是否对于前向和后向扰动有所不同.
- 了解人类平衡控制对不同扰动方向的敏感性.
主要方法:
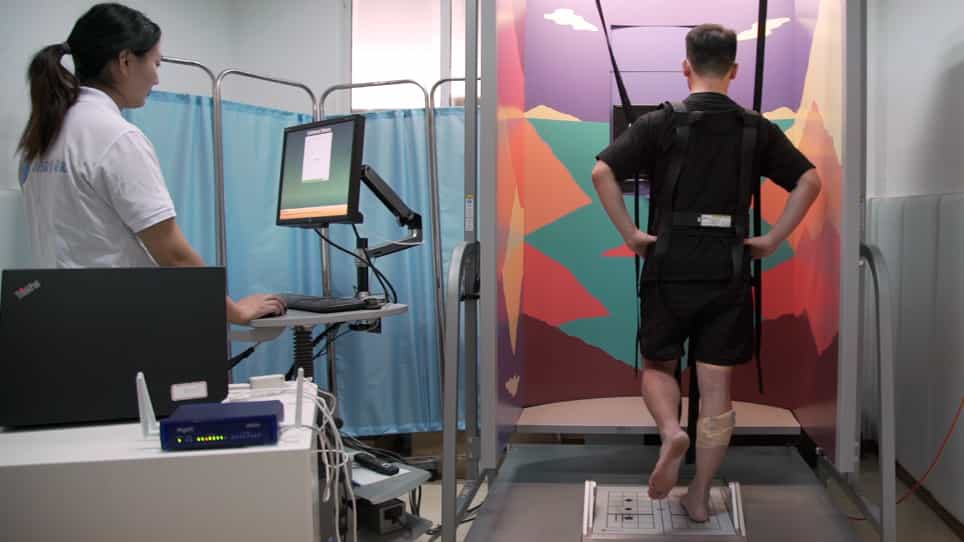
- 使用不可预测的跑步机带速度变化来诱导前后扰动.
- 分析了足部的位置,以应对这些扰动.
- 在映射矩阵中应用单数值分解来量化灵敏度.
主要成果:
- 脚部位置映射的概括很差,从不被打扰的步行到被打扰的步行.
- 控制策略在前向和后向扰动之间有显著差异.
- 人类对向后扰动的敏感性比向前扰动更强.
结论:
- 一个单一的线性映射不足以描述前后平衡损失期间的脚位控制.
- 人类平衡控制对不同的扰动方向采用不同的策略.
- 这些发现可以为了解神经运动障碍中的跌倒风险提供信息,并有助于设计平衡辅助设备.
相关概念视频
 01:18
Hierarchy of Motor Control
The hierarchy of motor control refers to the different levels of organization and processing involved in controlling movement in the body. These levels range from higher cortical areas involved in planning and decision-making to lower spinal cord reflexes that respond automatically to external stimuli.
 01:10
Control Systems
Control systems are everywhere in contemporary society, influencing diverse applications from aerospace to automated manufacturing. These systems can be found naturally within biological processes, such as blood sugar regulation and heart rate adjustment in response to stress, as well as in man-made systems like elevators and automated vehicles. A control system is essentially a network of subsystems and processes that collaboratively convert specific inputs into desired outputs.
At the heart...
At the heart...
 01:26
Feedback control systems
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:19
Root-Locus Method
A cruise control system in a car is designed to maintain a specified speed automatically by adjusting the gas pedal. The system continuously measures the vehicle's speed and makes fine adjustments to the pedal to achieve this goal. The root locus method is particularly useful for understanding how the cruise control system's behavior changes under varying conditions, such as when the car goes uphill, downhill, or faces strong wind resistance.
This system can be represented by a block diagram,...
This system can be represented by a block diagram,...
 01:22
Controller Configurations
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:07
Time-Domain Interpretation of PD Control
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...