
关于混乱的Kosambi-Cartan-Chern视角:揭示非线性自主系统中隐藏的吸引力
Somnath Roy1, Anirban Ray2, A Roy Chowdhury1
1Department of Physics, Jadavpur University, Kolkata 700075, India.
Physical review. E
|May 17, 2024

概括
研究人员开发了一种新方法来预测非线性系统中隐藏的吸引力. 这种方法克服了在复杂动态中检测混乱行为的局限性.
科学领域:
- 非线性动力学是一种非线性动力学.
- 混沌理论是一个混乱理论.
- 动态系统是动态系统.
背景情况:
- 在非线性系统的隐藏吸引子中调查混乱是具有挑战性的,因为缺乏既定的分析和数值方法.
- 吸引的盆地不接触不稳定的分流器,防止直接数值检测隐藏的吸引器,需要专门的策略.
研究的目的:
- 提出一种替代方法,用于预测非线性三维自主系统中与隐藏的吸引器相关的吸引流域.
- 克服隐藏吸引力的检测和分析现有的局限性.
主要方法:
- 使用Kosambi-Cartan-Chern理论进行全面的理论分析.
- 评估几何不变数和不稳定指数,以划分混乱和周期区.
主要成果:
- 拟议的方法成功地预测了隐藏吸引物的吸引流域.
- 来自Kosambi-Cartan-Chern理论的分析预测是通过数值结果验证的.
- 该研究划出了系统内混乱和周期性行为的区域.
结论:
- 提出的方法为分析非线性系统中隐藏的吸引力提供了一个可行的替代方案.
- 科桑比-卡顿-切尔恩理论为理解复杂的动态和预测混乱行为提供了一个强大的框架.
- 这项工作推进了在具有隐藏吸引力的系统中探索混乱的方法.
相关概念视频
 01:21
Linear Approximation in Time Domain
81
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
81
 01:26
Classification of Systems-I
180
Linearity is a system property characterized by a direct input-output relationship, combining homogeneity and additivity.
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
180
 01:27
State Space Representation
203
The frequency-domain technique, commonly used in analyzing and designing feedback control systems, is effective for linear, time-invariant systems. However, it falls short when dealing with nonlinear, time-varying, and multiple-input multiple-output systems. The time-domain or state-space approach addresses these limitations by utilizing state variables to construct simultaneous, first-order differential equations, known as state equations, for an nth-order system.
Consider an RLC circuit, a...
Consider an RLC circuit, a...
203
 01:28
Stability
108
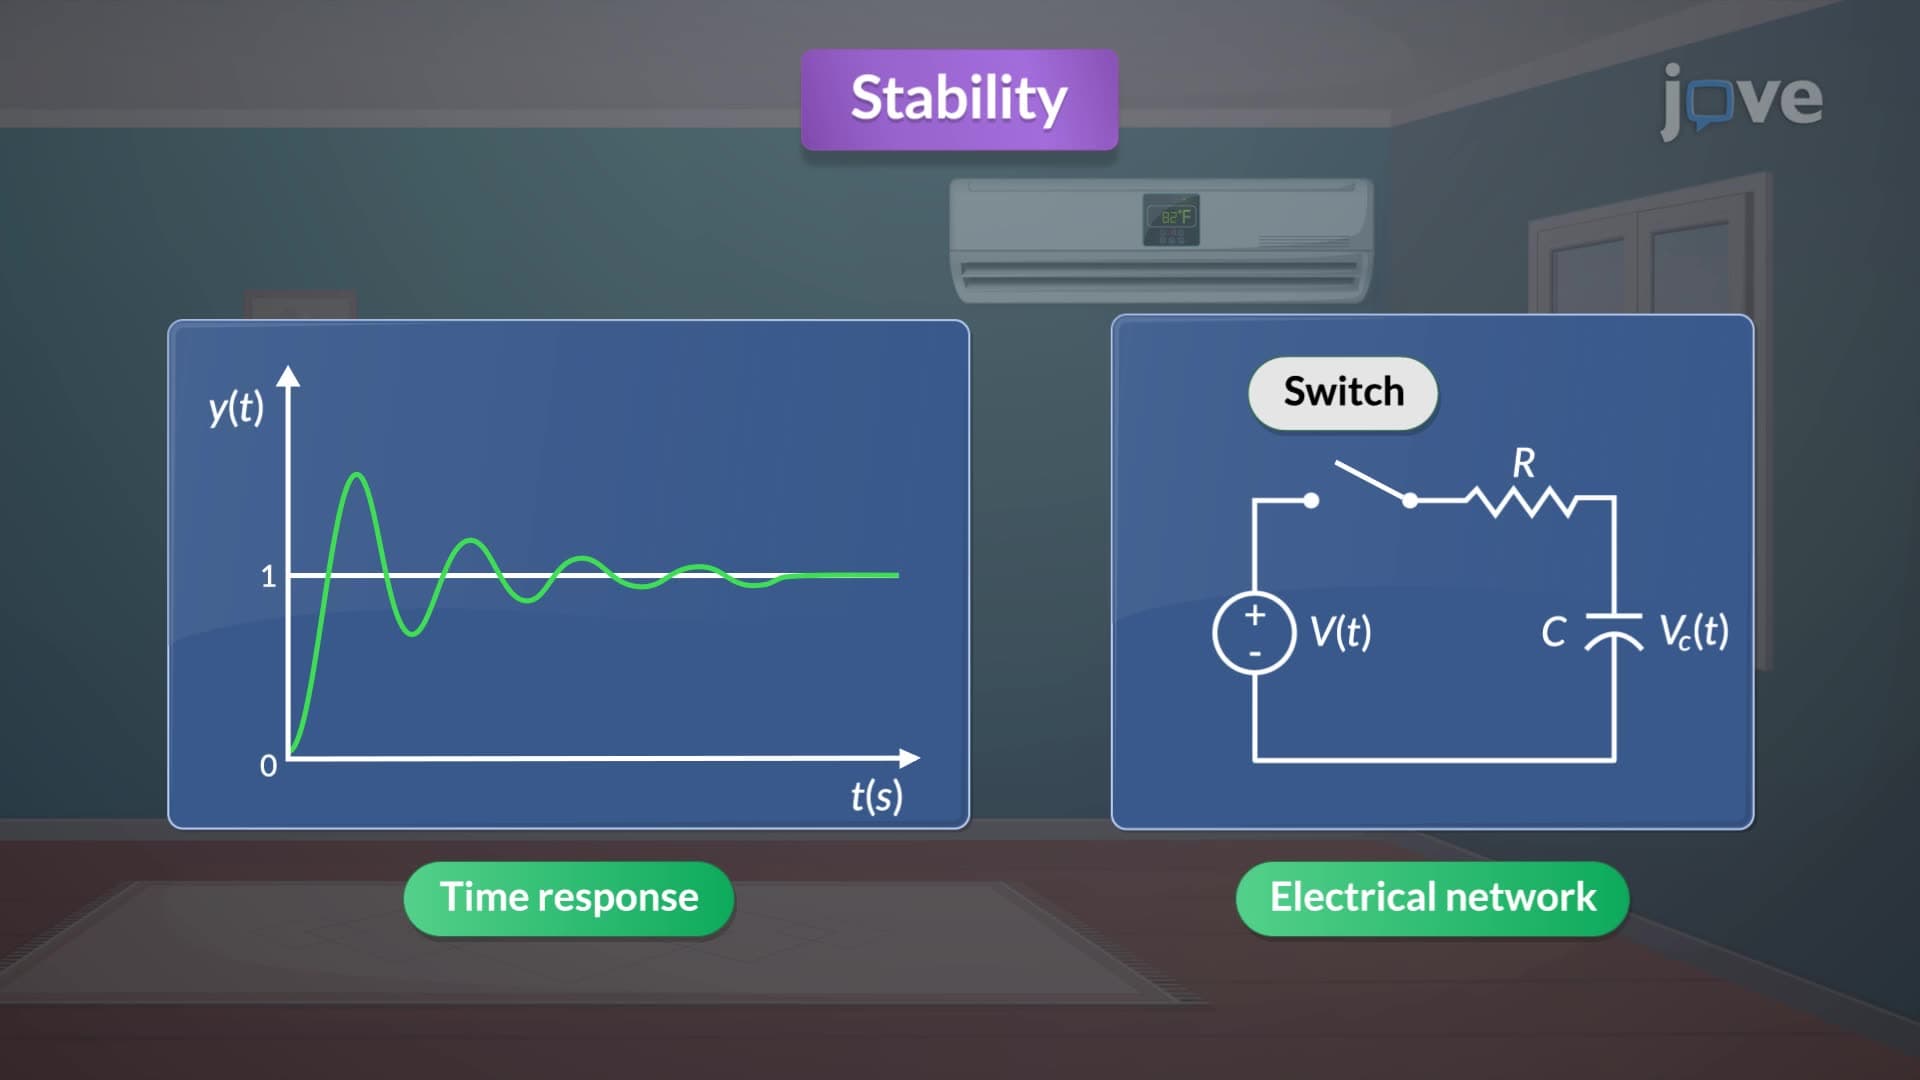
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
108
 01:23
Stability of Equilibrium Configuration
446
Understanding the stability of equilibrium configurations is a fundamental part of mechanical engineering. In any system, there are three distinct types of equilibrium: stable, neutral, and unstable.
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
446
 01:26
Linear Approximation in Frequency Domain
89
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
89