
在远跳起飞时,摇摆腿制动是否重要? 基于精英运动员的3D动力学分析
Zhiyong Jin1, Gongju Liu2, Houwei Zhu3
1Harbin Sport University, Haerbin, China.
Heliyon
|May 30, 2024

概括
精英长跃者通过延迟摇摆腿制动到足最大曲,从而获得更好的结果. 这种技术增强了支腿的延伸速度,并在关键的起飞阶段改善了平衡.
科学领域:
- 生物力学 生物力学
- 运动科学 运动科学 运动科学
- 竞技表现运动员的表现
背景情况:
- 远跳起飞是一个复杂的行动,需要精确协调多个身体部分.
- 了解摇摆腿和支腿之间的相互作用对于优化跳跃性能至关重要.
研究的目的:
- 为了研究在起飞期间精英男性长跳摇摆腿的制动机制.
- 为了确定摇摆腿制动,支腿延伸速度和平衡之间的关系.
主要方法:
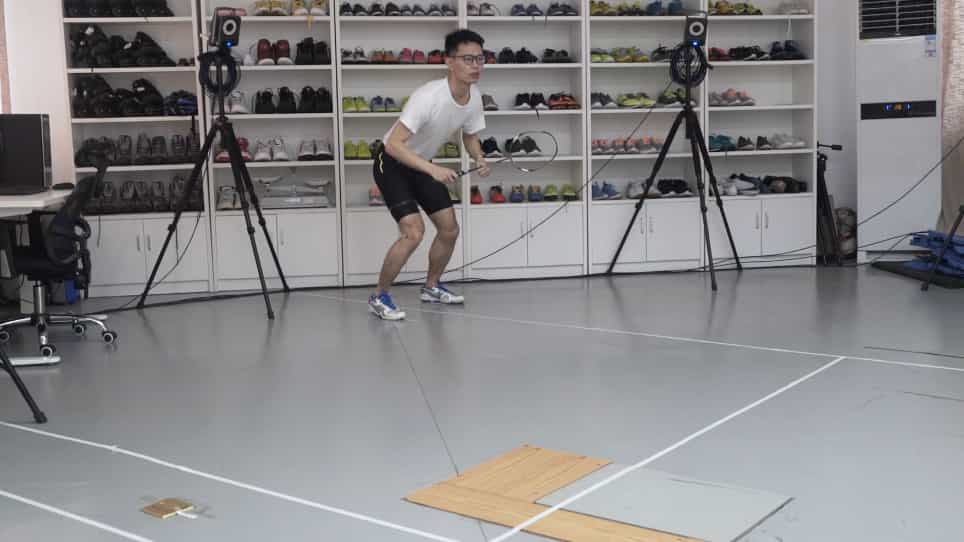
- 在国家比赛期间利用8名精英男子长跳运动员的3D运动分析.
- 使用两个高速摄像头记录起飞技术.
主要成果:
- 发现快速摆动腿部制动可以增加支腿部延伸速度.
- 当摇摆腿制动始于最大支腿脚曲,而不是最大膝盖曲时,就能达到最佳性能.
- 在前进摆动期间,中度的向内摆动腿部运动与更好的平衡维持有显著的相关性 (r = -0.50,P = 0.004).
结论:
- 摇摆腿的延迟快速制动有利于增强支腿的延伸速度.
- 摇摆腿的适度向内移动有助于在起飞期间保持平衡.
- 优化摇摆腿制动时间和运动路径可以提高远跳起飞性能.
相关概念视频
 01:10
Relative Motion Analysis - Acceleration
347
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
347
 01:18
Kinematic Equations - III
7.6K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
7.6K
 01:24
Absolute Motion Analysis- General Plane Motion
219
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
219
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
330
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
330