
对于具有结构性扰动和由分数布朗运动驱动的时间变化的延迟的马尔科夫跳跃系统,集成的滑动模式控制和稳定性
Xia Zhou1, Xing Zhou2, Jun Cheng3
1School of Mathematics and Computing Science, Guangxi Colleges and Universities Key Laboratory of Data Analysis and Computation, Guilin University of Electronic Technology, Guilin 541004, China; Center for Applied Mathematics of Guangxi (Guilin University of Electronic Technology), Guilin 541002, China.
ISA transactions
|May 30, 2024

概括
本研究涉及时变延迟马尔科夫跳跃系统 (MJSs) 的稳定性和滑动模式控制 (SMC) 与分数布朗运动 (fBm) 扰动,确保系统轨迹达到有限时间的滑动表面.
科学领域:
- 控制理论 控制理论
- 随机系统 随机系统 随机系统
- 非线性动力学是一种非线性动力学.
背景情况:
- 马尔科夫跳跃系统 (MJS) 对于模拟具有突然变化的系统至关重要.
- 时间变化的延迟和分数布朗运动 (fBm) 在稳定性分析中带来了显著的复杂性.
- 滑动模式控制 (SMC) 是一个强大的控制技术,用于系统的不确定性.
研究的目的:
- 调查稳定性,并为MJS开发一个SMC战略,以时间变化的延迟和fBm扰动.
- 对于这些复杂的系统来说,要推导出 pth 时刻指数稳定性条件.
- 设计一个完整的滑动模式表面 (SMS) 和控制规律,以实现有限时间的融合.
主要方法:
- 构建一个包含指数和双整数项的新型Lyapunov-Krasovskii函数 (LKF).
- 在稳定性分析中应用概括的分数Itoˆ公式和条件数学预期.
- 设计一个完整的滑动模式表面 (SMS) 和相应的SMC法,以适应时间变化的延迟.
主要成果:
- 该研究为所考虑的MJS推导了pth时刻指数稳定性条件.
- 实现了状态轨迹与设计的整体SMS的有限时间趋同.
- 数字实验验证了拟议的控制方法的有效性和可靠性.
结论:
- 开发的LKF和SMC战略有效地解决了MJS的稳定性和控制挑战,其中有不同的时间延迟和fBm.
- 拟议的方法确保了滑动表面的有限时间可达性,证明了其实际适用性.
- 这些发现有助于在不确定性下对复杂的随机系统进行强有力的控制.

相关概念视频
 01:24
BIBO stability of continuous and discrete -time systems
384
System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
384
 01:23
Linear time-invariant Systems
248
A system is linear if it displays the characteristics of homogeneity and additivity, together termed the superposition property. This principle is fundamental in all linear systems. Linear time-invariant (LTI) systems include systems with linear elements and constant parameters.
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
248
 01:21
Linear Approximation in Time Domain
81
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
81
 01:13
Linear Momentum in Control Volume
1.0K
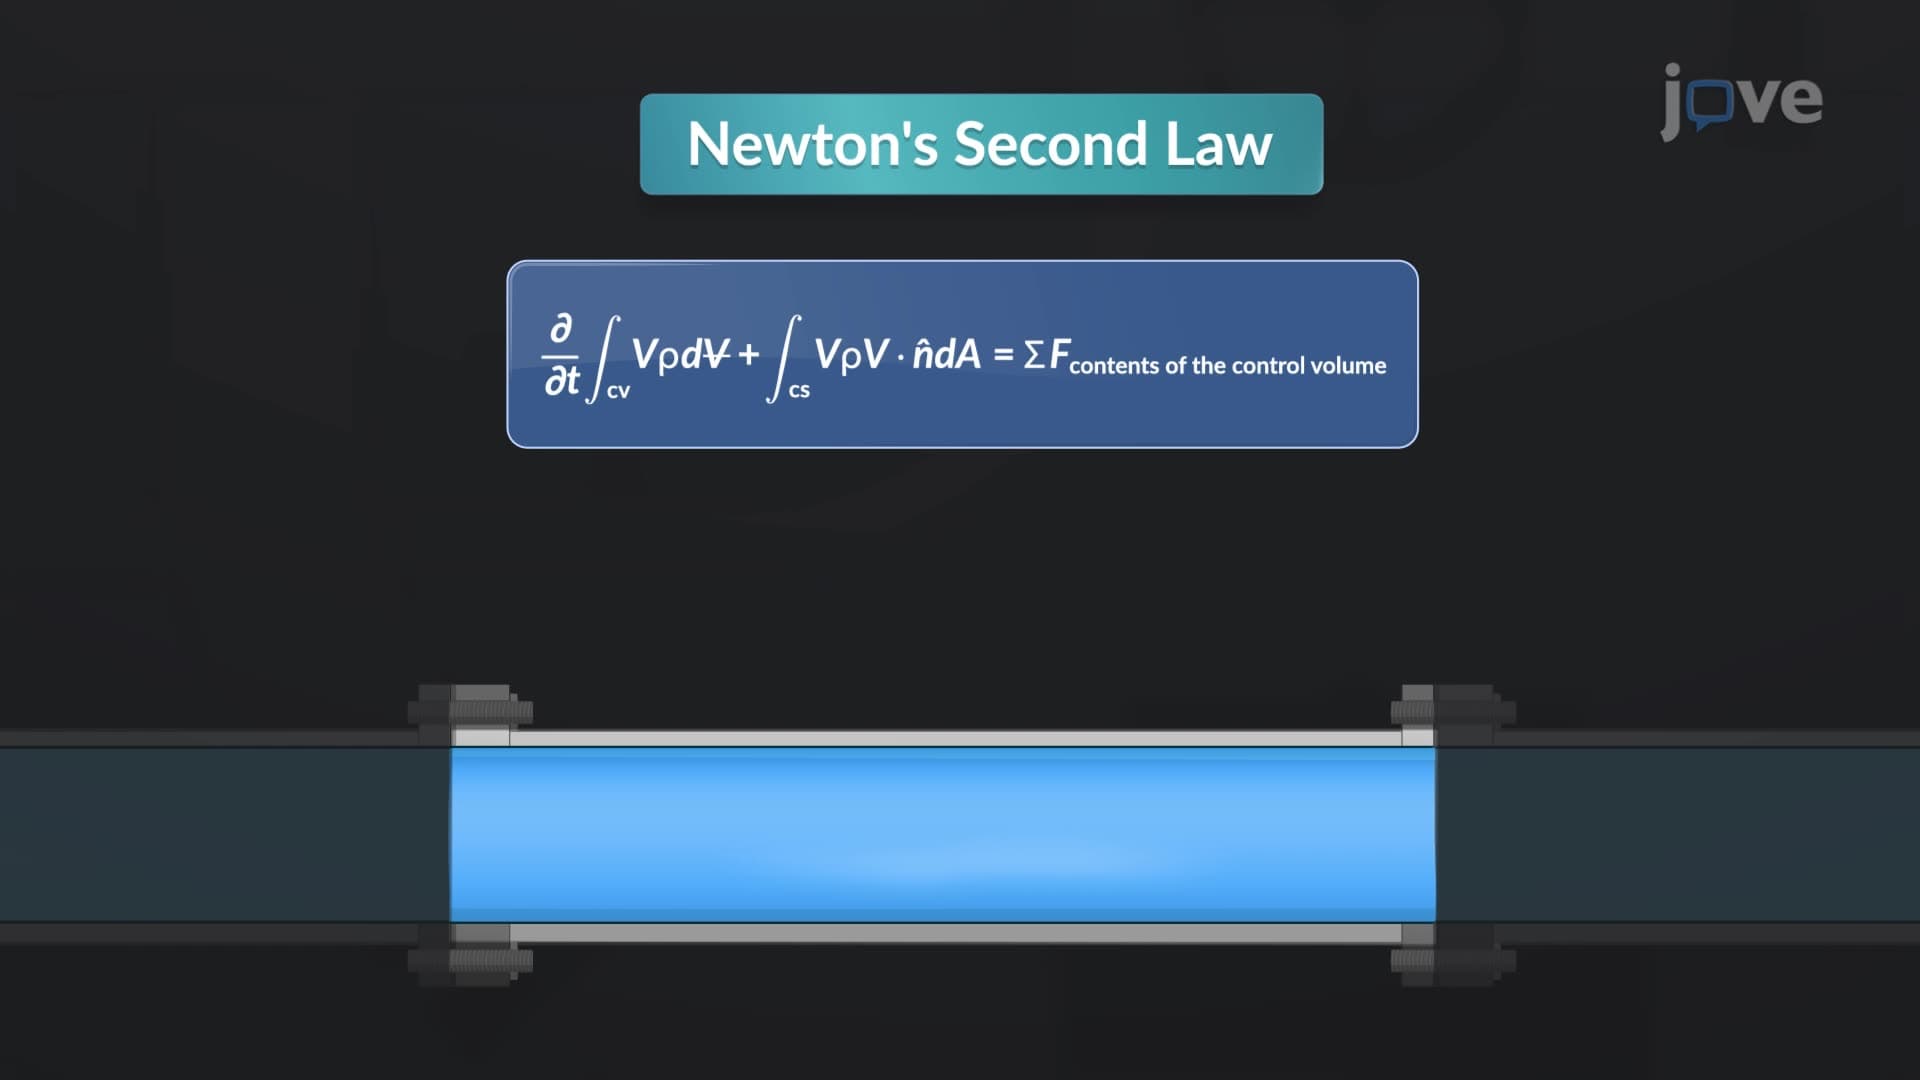
Newton's second law is applied to obtain the linear momentum in a control volume in a fluid system. According to this law, the rate of change of linear momentum is equal to the sum of external forces acting on the system. When a control volume matches the fluid system at a specific moment, the forces acting on both are identical. Reynolds transport theorem helps explain this by breaking down the system's linear momentum into two components: the rate of change of linear momentum within...
1.0K
 01:10
Relative Motion Analysis - Acceleration
347
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
347
 01:17
Open and closed-loop control systems
717
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
717