强大的故障检测和隔离不确定的中性时间延迟系统使用几何方法

Yandong Hou1, Zhiheng Zhang1, Jiayuan Yan1
1School of Artificial Intelligence, Henan University, Zhengzhou 450046, China.
ISA transactions
|May 31, 2024

概括
本研究引入了一种新的几何故障检测和隔离 (FDI) 方法,用于不确定的中性时间延迟系统 (UNTDS). 该方法有效地将故障隔离,将其划分为不可观察的子空间,提高系统的安全性和可靠性.
科学领域:
- 控制系统工程 控制系统工程
- 系统理论 系统理论
- 信号处理 信号处理
背景情况:
- 不确定的中性时间延迟系统 (UNTDS) 在故障检测和隔离 (FDI) 中带来了重大挑战.
- 现有的外国直接投资策略经常面临系统不确定性和时间延迟的问题.
- 系统状态和子空间的几何性质对于先进的外国直接投资至关重要.
研究的目的:
- 为不确定中性时间延迟系统 (UNTDS) 开发一种新的几何故障检测和隔离 (FDI) 策略.
- 提高在复杂的动态系统中隔离特定故障的能力.
- 提高外国直接投资的稳定性,以应对干扰和时间变化的延迟.
主要方法:
- 将不可观察性子空间概念扩展到UNTDS.
- 利用因子空间的几何性质和规范投影来进行断裂分区.
- 为故障隔离开发一个子空间构造算法.
- 分系统观察员的设计,以产生故障特定的结构化残留物.
- 应用H∞技术来抑制干扰和错误.
主要成果:
- 成功地将断层划分为不同的不可观察的子空间.
- 产生对特定故障敏感的结构残留物.
- 通过时间变化的延迟导致的干扰和错误的被证明的抑制.
- 通过模拟示例验证拟议的外国直接投资战略的有效性.
结论:
- 拟议的几何 FDI 策略对于不确定的中立时间延迟系统是有效的.
- 该方法提供了强大的故障隔离和干扰排斥.
- 这种方法为提高时间延迟系统的安全性和可靠性提供了一个有希望的方向.

相关概念视频
 01:18
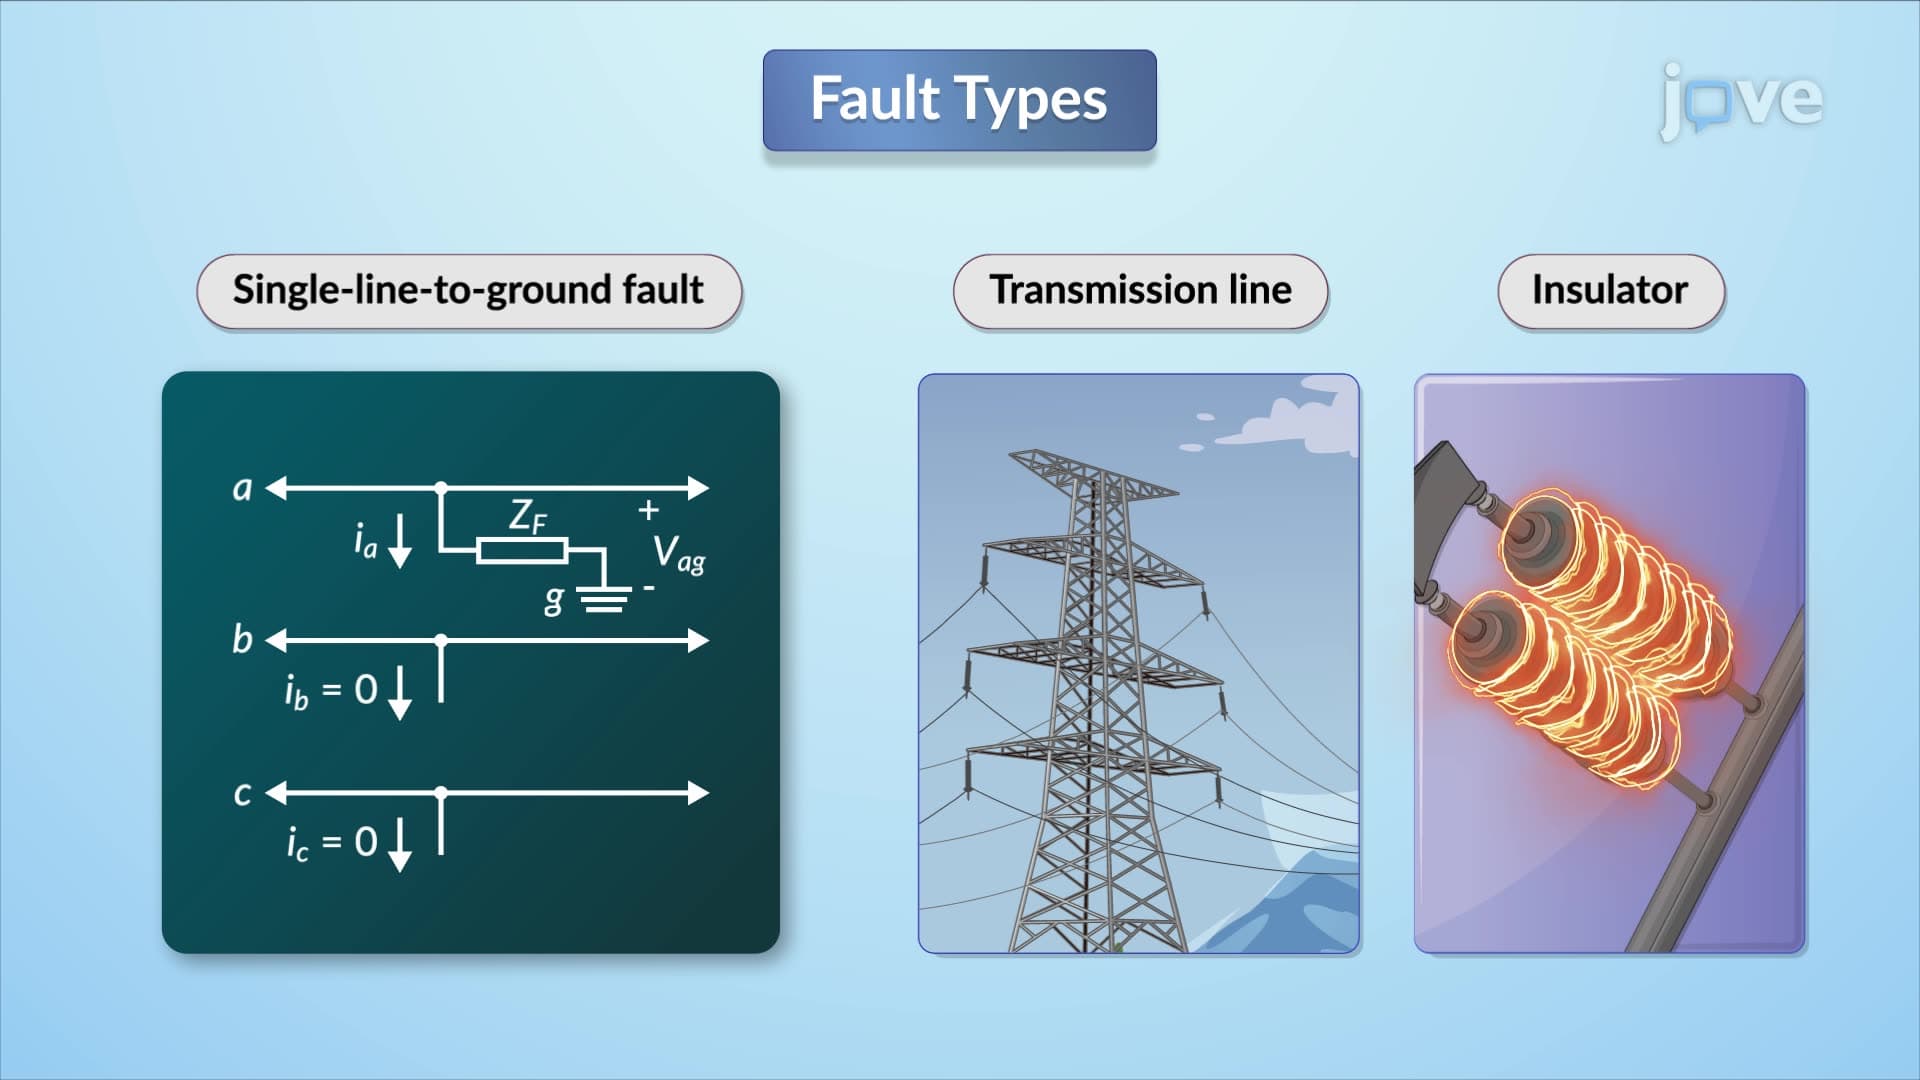
Fault Types
84
When analyzing a single line-to-ground fault from phase A to ground at a three-phase bus, it is important to consider the fault impedance. This impedance is zero for a bolted fault, equal to the arc impedance for an arcing fault, and represents the total fault impedance for a transmission-line insulator flashover. To derive sequence and phase currents, fault conditions are translated from the phase domain to the sequence domain.
For line-to-line faults occurring between phases B and C, the...
For line-to-line faults occurring between phases B and C, the...
84
 01:27
Line Protection with Impedance Relays
77
Coordinating time-delay overcurrent relays in complex radial systems and directional overcurrent relays in multi-source transmission loops can be challenging. Impedance relays address these issues by responding to the voltage-to-current ratio, specifically measuring the apparent impedance of a line. These relays become more sensitive during faults as current increases and voltage decreases, thereby reducing the apparent impedance.
Under normal conditions, low load currents keep the measured...
Under normal conditions, low load currents keep the measured...
77
 01:23
Radial System Protection
94
Radial systems employ time-delay overcurrent relays to reduce load interruptions. When a fault occurs, the nearest breaker opens first, while upstream breakers remain closed due to longer delay settings. This approach ensures minimal disruption to the rest of the system.
In a radial system with a fault downstream of the third breaker, ideally, only the third breaker will open, isolating the fault and interrupting the load connected beyond it. The second breaker has a longer delay setting,...
In a radial system with a fault downstream of the third breaker, ideally, only the third breaker will open, isolating the fault and interrupting the load connected beyond it. The second breaker has a longer delay setting,...
94
 01:23
Linear time-invariant Systems
248
A system is linear if it displays the characteristics of homogeneity and additivity, together termed the superposition property. This principle is fundamental in all linear systems. Linear time-invariant (LTI) systems include systems with linear elements and constant parameters.
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
248
 01:07
Time-Domain Interpretation of PD Control
94
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
94
 01:19
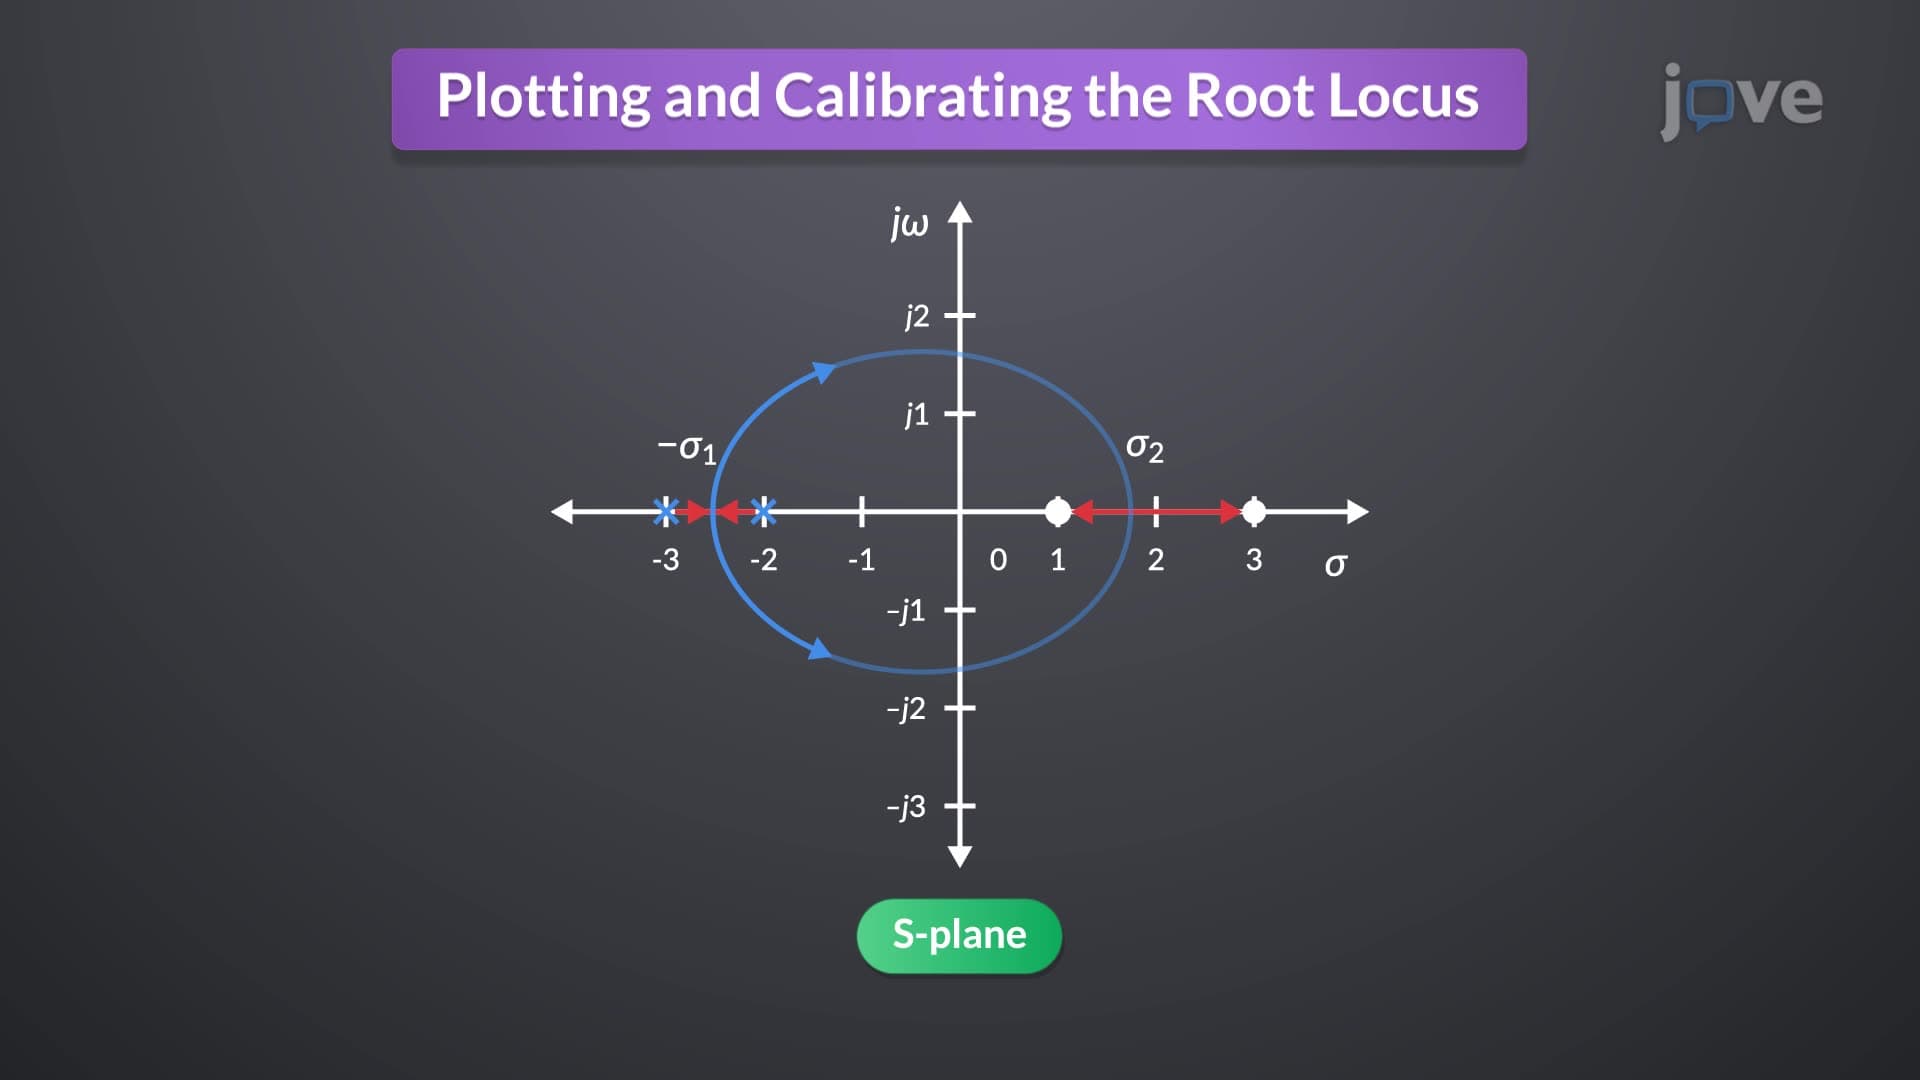
Plotting and Calibrating the Root Locus
110
Root loci often diverge as system poles shift from the real axis to the complex plane. Key points in this transition are the breakaway and break-in points, indicating where the root locus leaves and reenters the real axis. The branches of the root locus form an angle of 180/n degrees with the real axis, where n is the number of branches at a breakaway or break-in point.
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
110