数据和差距特征对机动活动期间运动的非线性计算的影响
Arash Mohammadzadeh Gonabadi1, Thad W Buster1, Guilherme M Cesar2
1Rehabilitation Engineering Center, Institute for Rehabilitation Science and Engineering, Madonna Rehabilitation Hospitals, Lincoln, NE, USA.
Journal of applied biomechanics
|June 6, 2024

概括
人类动力学数据中的差距显著增加了Lyapunov指数 (LyE) 计算中的错误. 立方斜线插值可以减轻一些错误,但仔细报告数据差距和长度对于准确的运动变化分析至关重要.
科学领域:
- 生物力学 生物力学
- 动态系统分析 动态系统分析
- 人类运动中的数据科学
背景情况:
- 人类运动的可变性通常使用利亚普诺夫指数 (LyE) 来量化.
- LyE计算的准确性可能会受到数据质量的影响,包括数据序列长度和时间差距.
- 了解这些影响对于可靠的运动动态表征至关重要.
研究的目的:
- 调查数据序列长度和差距持续时间对莱普诺夫指数 (LyE) 计算准确性的影响.
- 为了比较这些因素的影响,有和没有立方脊柱插值.
- 为准确的人类运动变化性分析提供数据处理指南.
主要方法:
- 人类动力学数据被操纵,以创建不同的数据序列长度 (28%和100%的原始) 和间隙持续时间 (0.050.20秒).
- 对操纵的数据进行了立方线插值计算,并没有对操纵的数据进行立方线插值.
- 使用Lyapunov指数百分比误差 (%误差) 来量化准确性影响.
主要成果:
- 较长的间隙显著增加了所有平面的非互插数据中的 LyE% 误差.
- 立方斜线插值减少了LyE%的误差,前面平面数据中只有0.20s的差距显示出明显的误差增加.
- 数据序列长度没有显著影响非插入的LyE%误差,但较短的序列长度增加了插入时的斜边平面LyE%误差.
结论:
- 忽略数据缺口的插值可能会导致错误的高LyE值,错误地表示运动变化.
- 特定的条件,如长的正面平面间隙 (0.20秒) 或短的斜面平面系列 (1000点) 与插曲,仍然可以产生不准确的LyE.
- 准确报告差距持续时间,数据序列长度和插值方法对于可靠的人类运动变异性分析至关重要.
相关概念视频
 01:10
Relative Motion Analysis - Acceleration
347
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
347
 01:15
Kinematic Equations: Problem Solving
12.4K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
12.4K
 01:17
Kinematic Equations - II
9.5K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
9.5K
 01:18
Kinematic Equations - III
7.6K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
7.6K
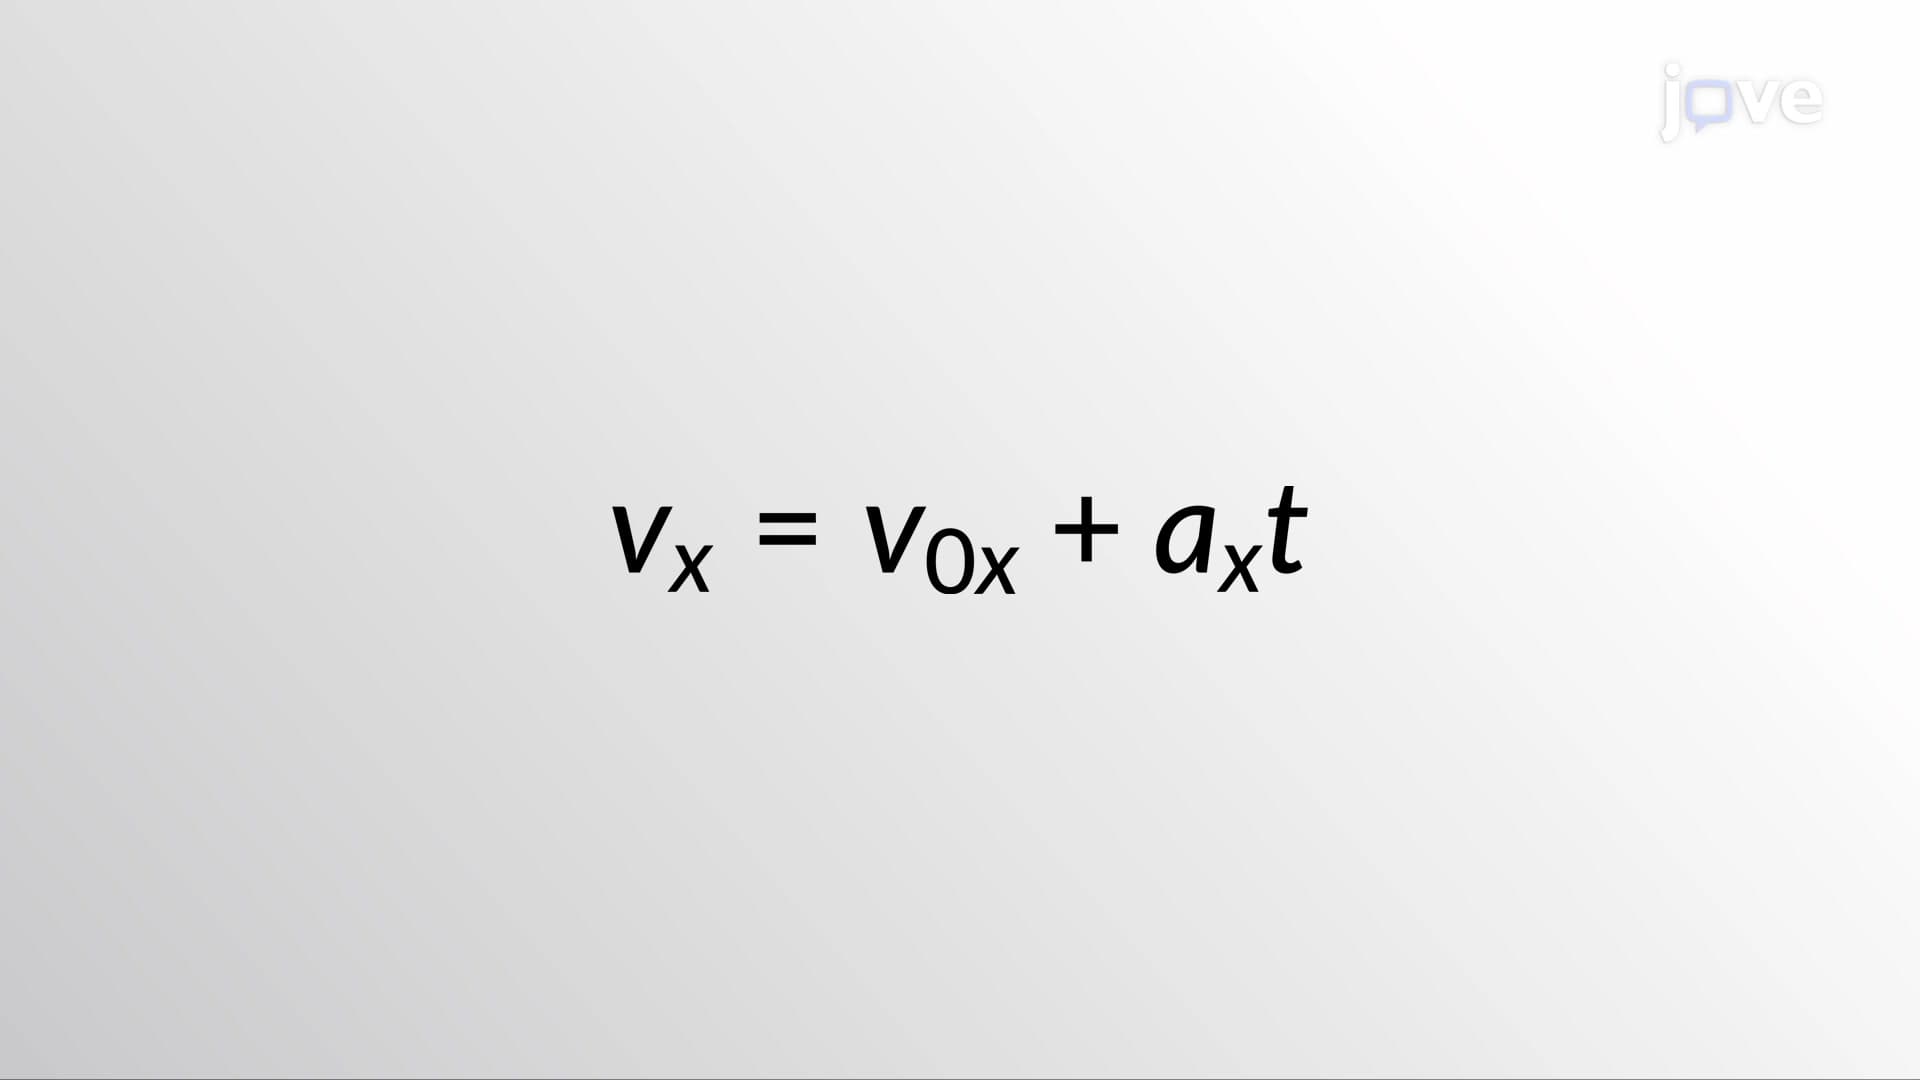 01:26
Kinematic Equations - I
10.5K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
10.5K