
不可缩小的笛卡尔张量分解:一种计算方法
1Departement of Chemistry, Theoretical Chemistry Laboratory, Unit of Theoretical and Structural Physical Chemistry, Namur Institute of Structured Matter, University of Namur, Rue de Bruxelles 61, 5000 Namur, Belgium.
The Journal of chemical physics
|June 10, 2024

概括
本研究介绍了不可归还的卡尔特斯张量 (ICT) 分解的计算方法,简化了物理学和化学中的对称性分析. 这种方法成功地将张量分解到排名5的张量,从而推进了分子性质计算.
科学领域:
- 物理和化学 物理和化学
- 量子力学就是量子力学.
- 计算化学的计算化学
背景情况:
- 笛卡尔张量在描述诸如分子谱学和响应性质之类的物理现象方面具有根本性的作用.
- 将笛卡儿张量分解为不可减小的部分对于理解它们的内在对称性至关重要.
研究的目的:
- 开发和介绍一种计算方法,用于对通用卡特西安张量进行不可简化的卡特西安张量 (ICT) 分解.
- 将这种方法应用于排名5的张量显式分解.
主要方法:
- 该研究回顾了ICT分解的矩阵公式,并与旋转平均计算进行了平行.
- 使用使用缩小行等级形式 (rref) 算法的计算方法.
- 该协议以计算机代码实现.
主要成果:
- 计算方法成功地重新推导出已知的ICT分解,用于2至4等级的张量.
- 首次实现了排列5的笛卡尔张量显式ICT分解.
- 该方法提供了一种系统的方式来识别张量子空间之间的线性独立映射.
结论:
- 基于rref的计算方法为ICT分解提供了一种高效且易于使用的协议.
- 这项工作将ICT分解的适用性扩展到更高等级的张量,有助于高级光谱学和分子性质研究.
相关概念视频
 01:26
Cartesian Form for Vector Formulation
627
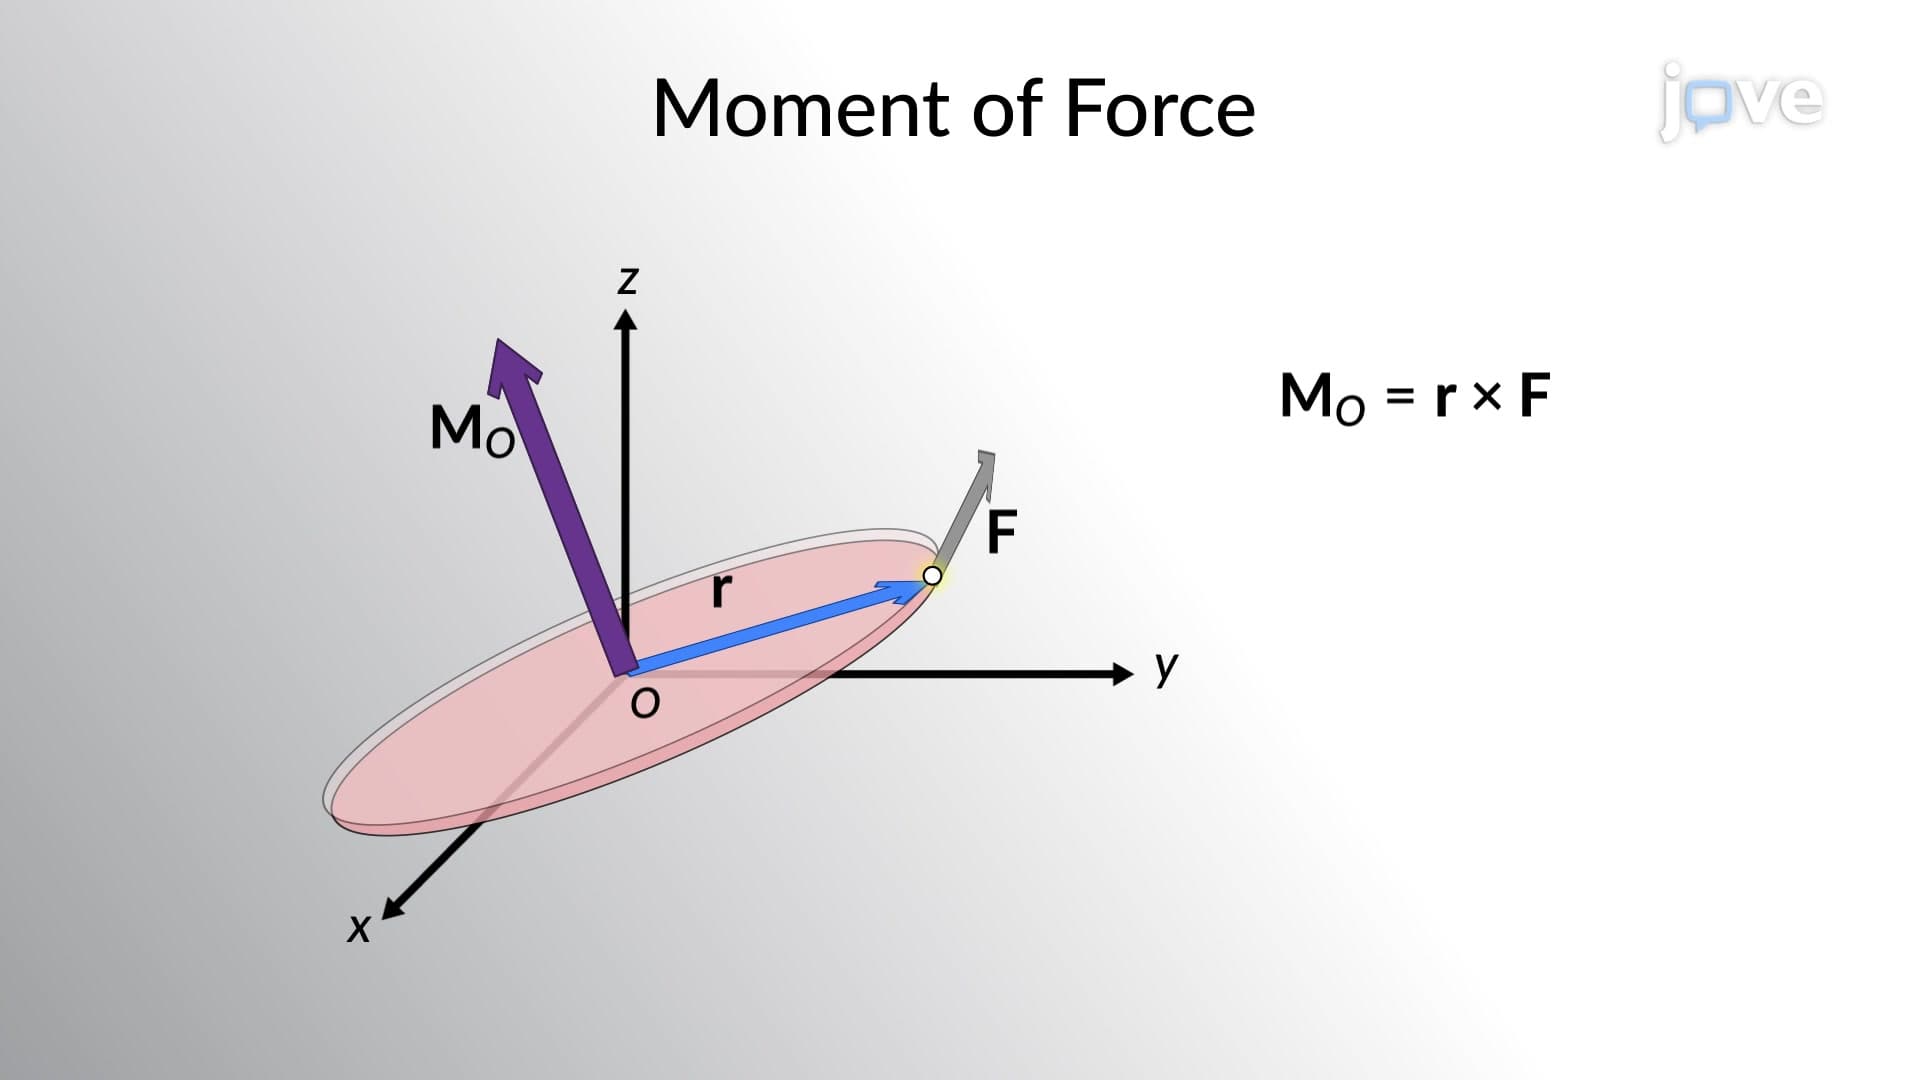
The Cartesian form for vector formulation is a process to calculate the moment of force using the position and force vectors. The moment of force is defined as the cross-product of these vectors, making it a vector quantity. The Cartesian form of the position and force vectors involves unit vectors, which can be used to express the cross-product in determinant form.
627
 01:08
Vector Algebra: Method of Components
13.9K
It is cumbersome to find the magnitudes of vectors using the parallelogram rule or using the graphical method to perform mathematical operations like addition, subtraction, and multiplication. There are two ways to circumvent this algebraic complexity. One way is to draw the vectors to scale, as in navigation, and read approximate vector lengths and angles (directions) from the graphs. The other way is to use the method of components.
In many applications, the magnitudes and directions of...
In many applications, the magnitudes and directions of...
13.9K
 01:28
Cartesian Vector Notation
762
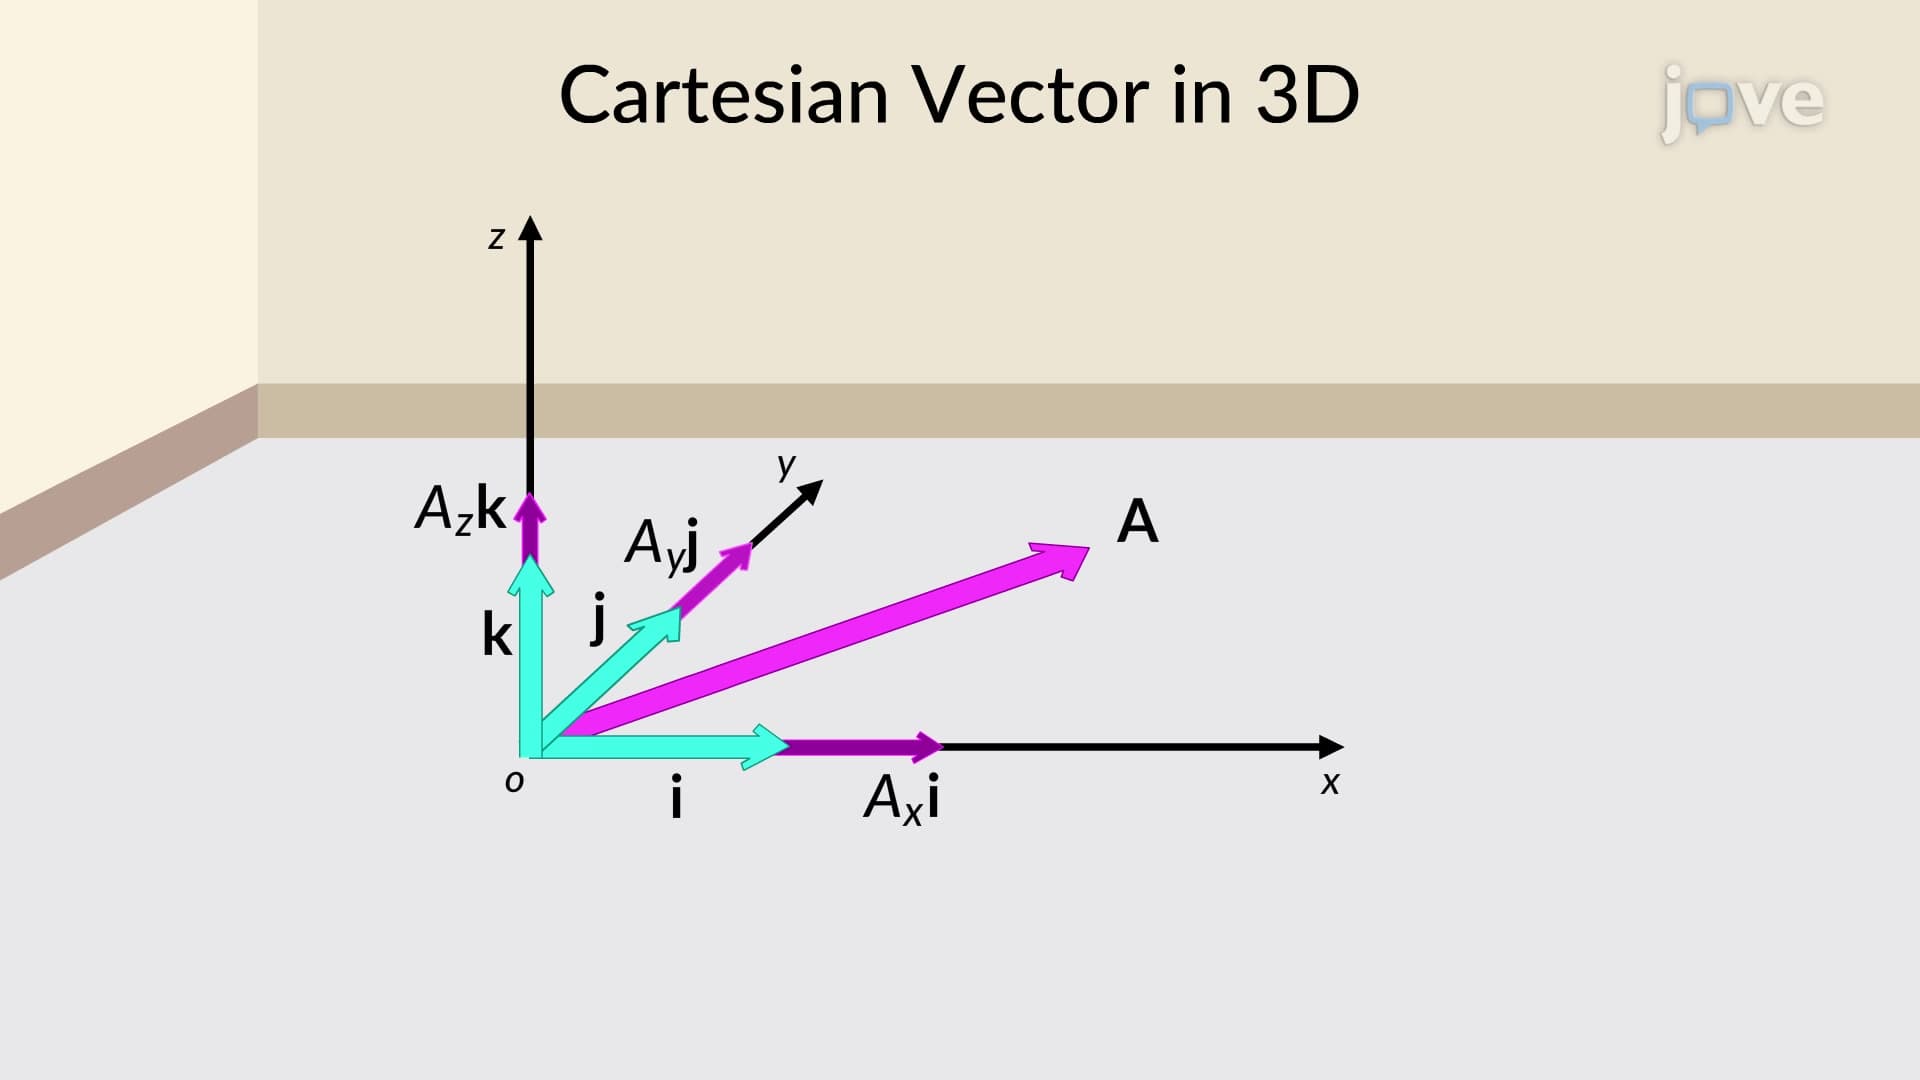
Cartesian vector notation is a valuable tool in mechanical engineering for representing vectors in three-dimensional space, performing vector operations such as determining the gradient, divergence, and curl, and expressing physical quantities such as the displacement, velocity, acceleration, and force. By using Cartesian vector notation, engineers can more easily analyze and solve problems in various areas of mechanical engineering, including dynamics, kinematics, and fluid mechanics. This...
762
 01:24
Inertia Tensor
449
The concept of the inertia tensor is employed to depict the mass distribution and rotational inertia of a solid or rigid object. This tensor is expressed through a three-by-three matrix. Each component within this matrix corresponds to varying moments of inertia about specific axes.
The diagonal components of the inertia tensor matrix represent the moments of inertia concerning the principal axes of the object. These primary axes are defined as the axes where the object experiences the least...
The diagonal components of the inertia tensor matrix represent the moments of inertia concerning the principal axes of the object. These primary axes are defined as the axes where the object experiences the least...
449
 01:29
Vector Components in the Cartesian Coordinate System
19.6K
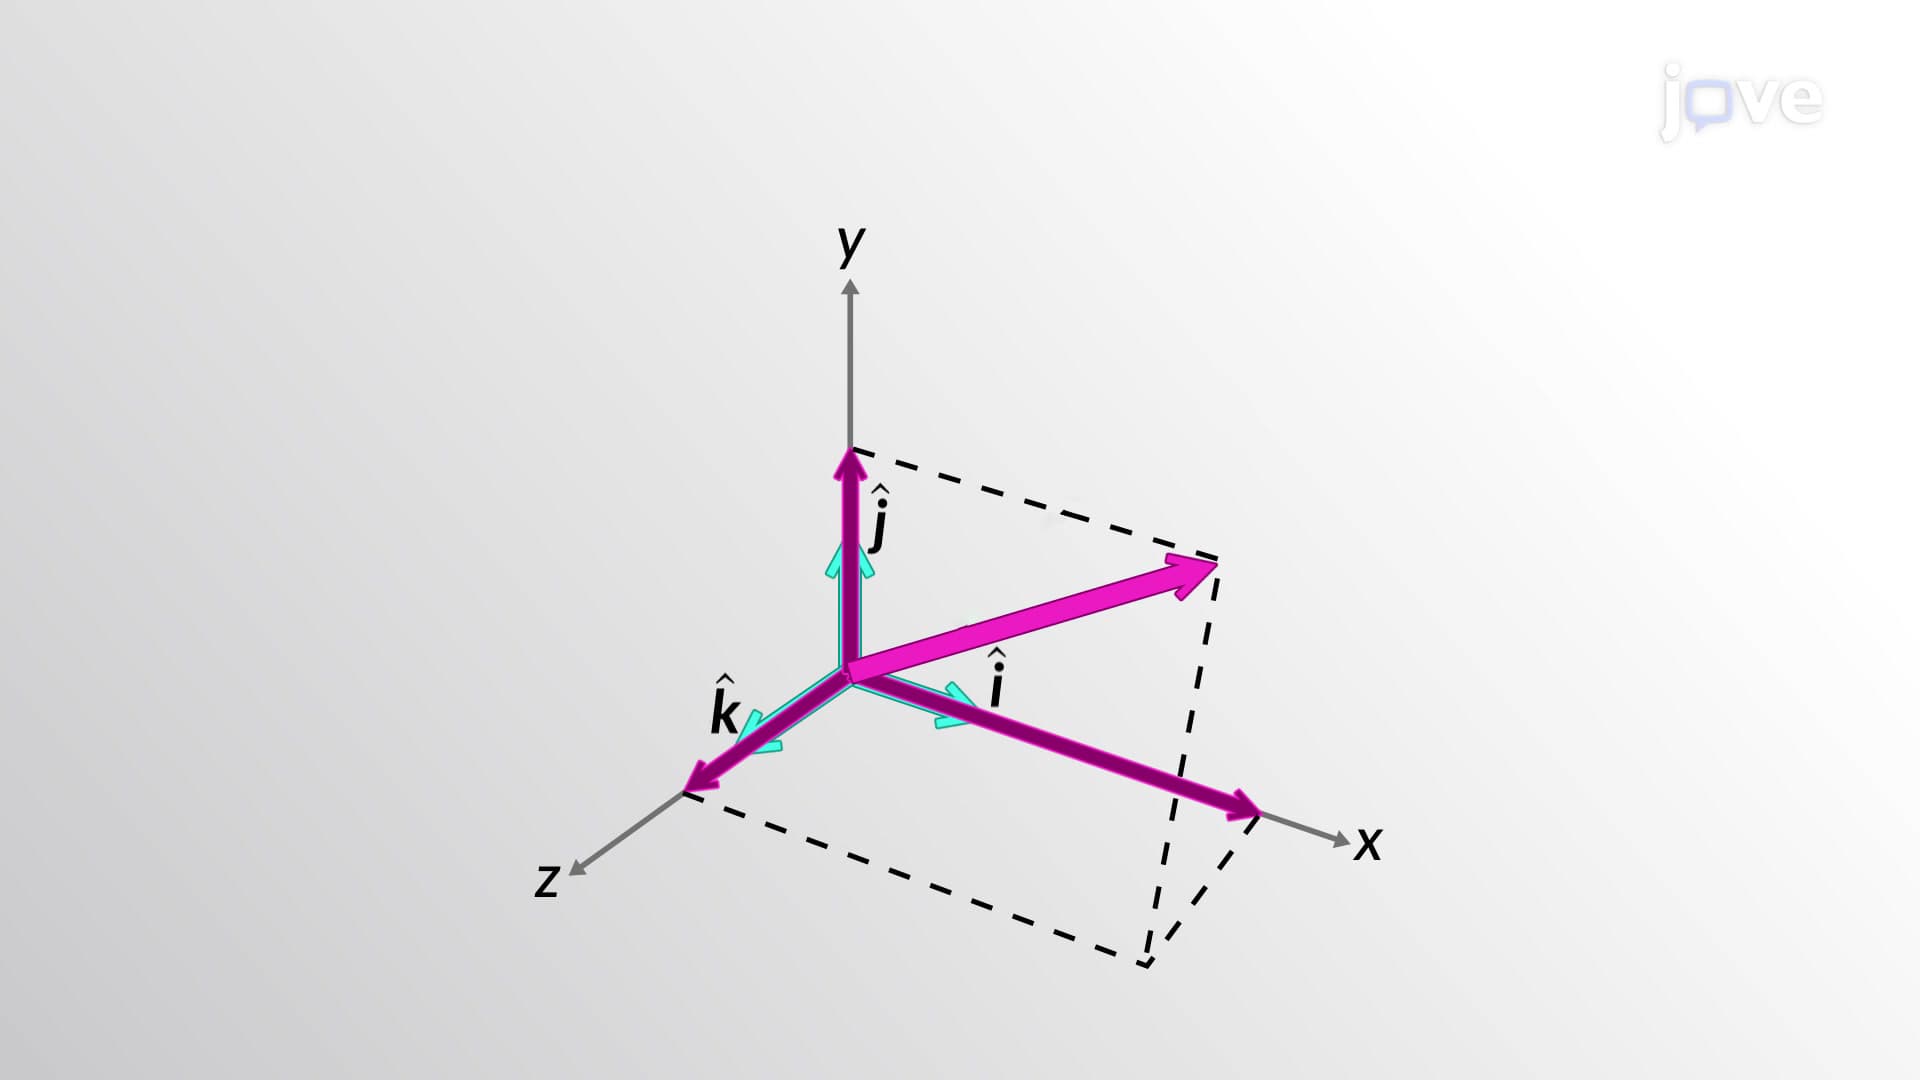
Vectors are usually described in terms of their components in a coordinate system. Even in everyday life, we naturally invoke the concept of orthogonal projections in a rectangular coordinate system. For example, if someone gives you directions for a particular location, you will be told to go a few km in a direction like east, west, north, or south, along with the angle in which you are supposed to move. In a rectangular (Cartesian) xy-coordinate system in a plane, a point in a plane is...
19.6K
 01:10
Vector Algebra: Graphical Method
12.1K
Vectors can be multiplied by scalars, added to other vectors, or subtracted from other vectors. The vector sum of two (or more) vectors is called the resultant vector or, for short, the resultant.
We use the laws of geometry to construct resultant vectors, followed by trigonometry to find vector magnitudes and directions. For a geometric construction of the sum of two vectors in a plane, we follow the parallelogram rule. Suppose two vectors are at arbitrary positions. Translate either one of...
We use the laws of geometry to construct resultant vectors, followed by trigonometry to find vector magnitudes and directions. For a geometric construction of the sum of two vectors in a plane, we follow the parallelogram rule. Suppose two vectors are at arbitrary positions. Translate either one of...
12.1K