通过非标准波段对长序列的控制微分方程进行控制
Sourav Pal1, Zhanpeng Zeng1, Sathya N Ravi2
1University of Wisconsin-Madison.
Proceedings of machine learning research
|June 17, 2024

概括
神经控制微分方程 (NCDEs) 用整数转换和波形分解来改进长序列. 这种简化增强了回归,分类和合微分方程的建模.
科学领域:
- 机器学习 机器学习
- 动态系统 动态系统
- 信号处理 信号处理
背景情况:
- 神经控制微分方程 (NCDEs) 模拟复杂的时间动态,但与长序列作斗争.
- 使用日志签名的现有方法缺乏可逆性,限制了重建和生成建模等应用.
研究的目的:
- 为固定长度时间序列开发一个高效的NDE的简化.
- 增强NCDE可解决问题的范围,包括需要模型可逆性的问题.
主要方法:
- 将回归/分类任务重新定义为积分变换.
- 限制操作员类,以便使用非标准波形小组进行分解.
- 开发一个神经变体的简化操作员学习方法.
主要成果:
- 通过现有的NCDE方法解决的各种使用案例,表现出一致的改进.
- 成功地应用了新的方法来建模涉及合微分方程的任务.
- 简化从根本上减少了学习操作员的复杂性.
结论:
- 拟议的整体转换和基于波形的简化为固定长度序列上的NDE提供了高效和有效的替代方案.
- 这种方法扩大了NDE的适用性,特别是对于需要模型可逆性的任务和对合系统的建模.
相关概念视频
 01:26
Transmission-Line Differential Equations
270
Transmission lines are essential components of electrical power systems. They are characterized by the distributed nature of resistance (R), inductance (L), and capacitance (C) per unit length. To analyze these lines, differential equations are employed to model the variations in voltage and current along the line.
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...
270
 01:21
Linear Approximation in Time Domain
81
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
81
 01:24
Difference Equation Solution using z-Transform
289
The z-transform is a powerful tool for analyzing practical discrete-time systems, often represented by linear difference equations. Solving a higher-order difference equation requires knowledge of the input signal and the initial conditions up to one term less than the order of the equation.
The z-transform facilitates handling delayed signals by shifting the signal in the z-domain, which corresponds to delaying the signal in the time domain, and advancing signals by similarly shifting in the...
The z-transform facilitates handling delayed signals by shifting the signal in the z-domain, which corresponds to delaying the signal in the time domain, and advancing signals by similarly shifting in the...
289
 01:16
Basic Discrete Time Signals
204
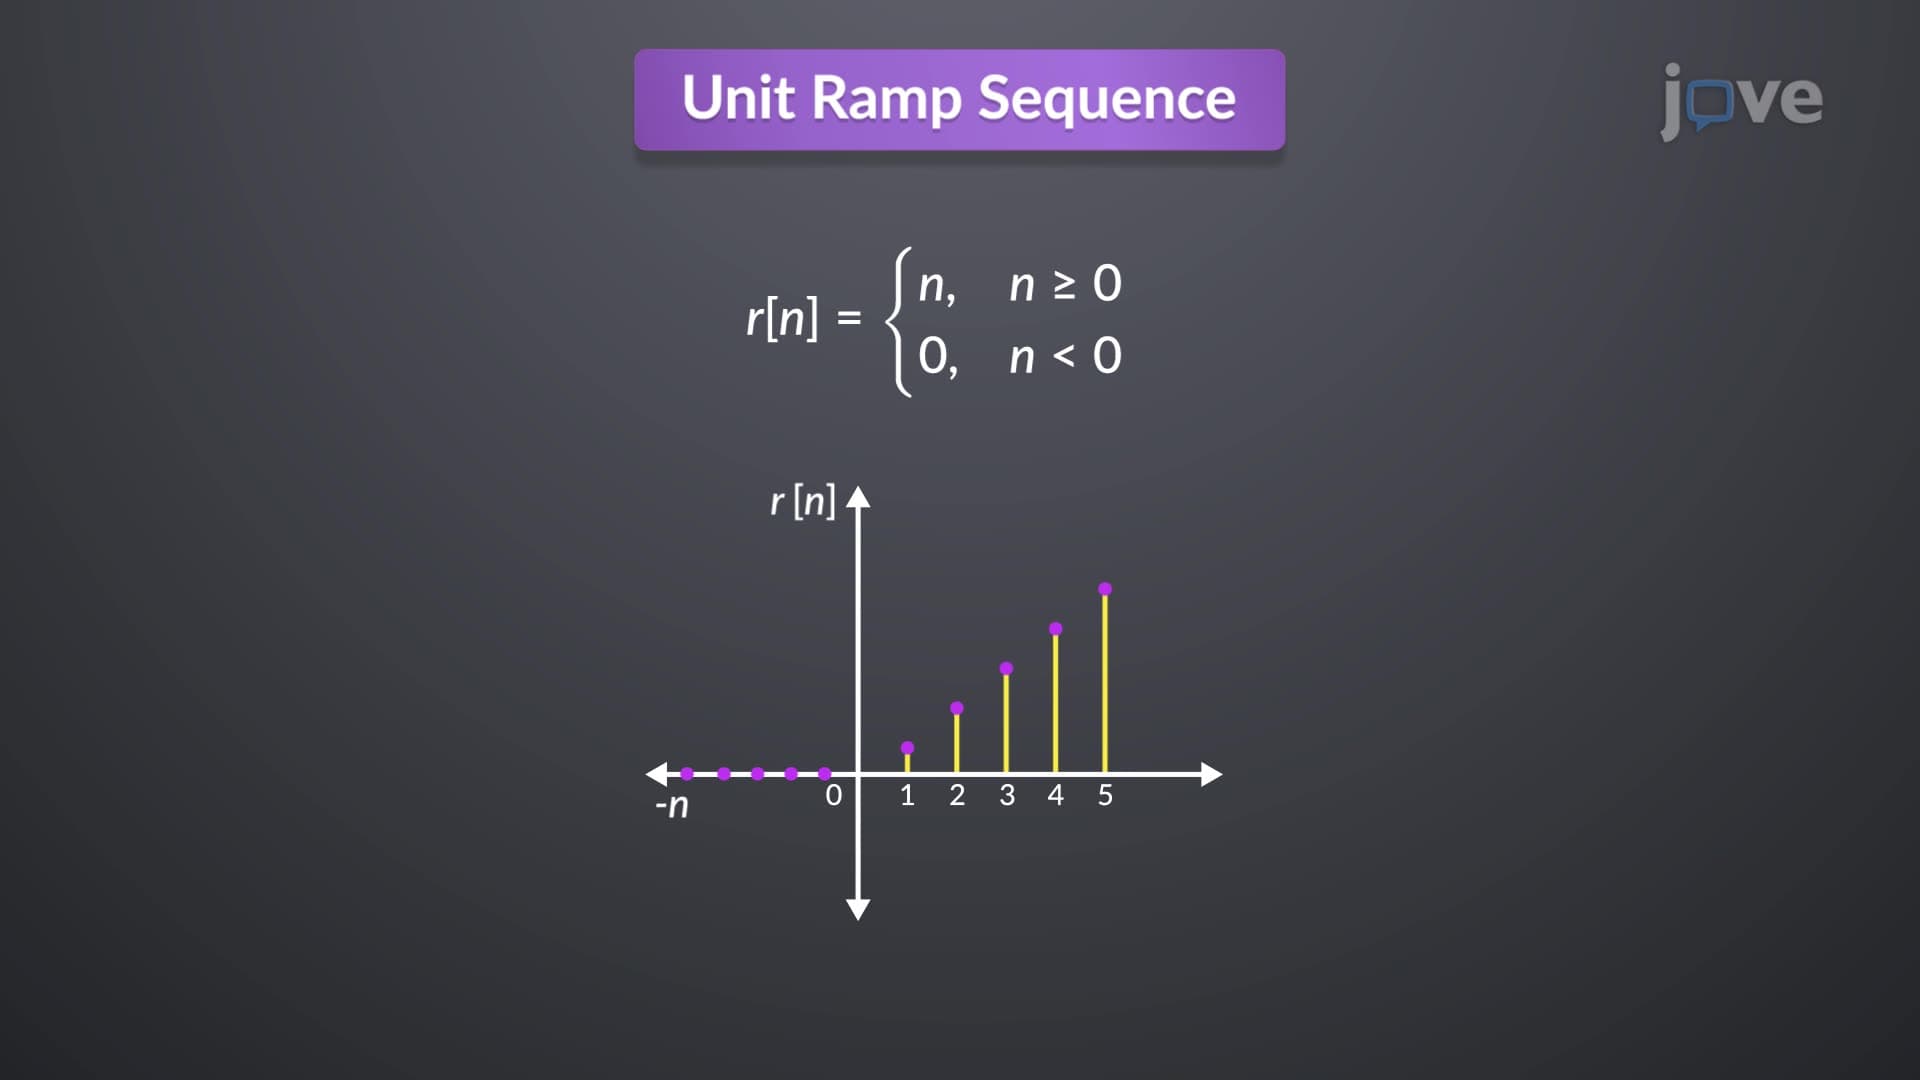
The unit step sequence is defined as 1 for zero and positive values of the integer n. This sequence can be graphically displayed using a set of eight sample points, showing a step function starting from n=0 and remaining constant thereafter.
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is...
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is...
204
 01:18
Second Order systems II
96
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
96
 01:26
Linear Approximation in Frequency Domain
89
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
89