传统驾驶习惯对操纵杆控制的自动驾驶汽车接管性能的影响:一个低速实地实验
Shijian He1, Xinyi Liu1, Jie Wang1
1School of Traffic and Transportation Engineering, Changsha University of Science & Technology, Changsha 410114, China.
Heliyon
|June 17, 2024

概括
传统的驾驶习惯会对自动驾驶汽车的被动接管性能产生负面影响. 经验丰富的司机需要更长时间才能恢复控制,这凸显了为自动驾驶过渡提供量身定制培训的必要性.
科学领域:
- 人与计算机的互动.
- 自动驾驶安全自动驾驶的安全性
- 驾驶员行为研究研究的研究.
背景情况:
- 自动驾驶系统依赖于安全的人类驾驶员的接管.
- 传统的驾驶习惯可能会影响新型自动驾驶汽车接口的性能.
- 了解这些影响对于开发有效的人机界面和培训至关重要.
研究的目的:
- 调查传统驾驶习惯对操纵杆控制的自动驾驶汽车的接管性能的影响.
- 为了比较不同级别的驾驶经验的接管性能 (没有驾驶执照/没有经验,没有驾驶执照/没有经验,有驾驶执照/经验).
主要方法:
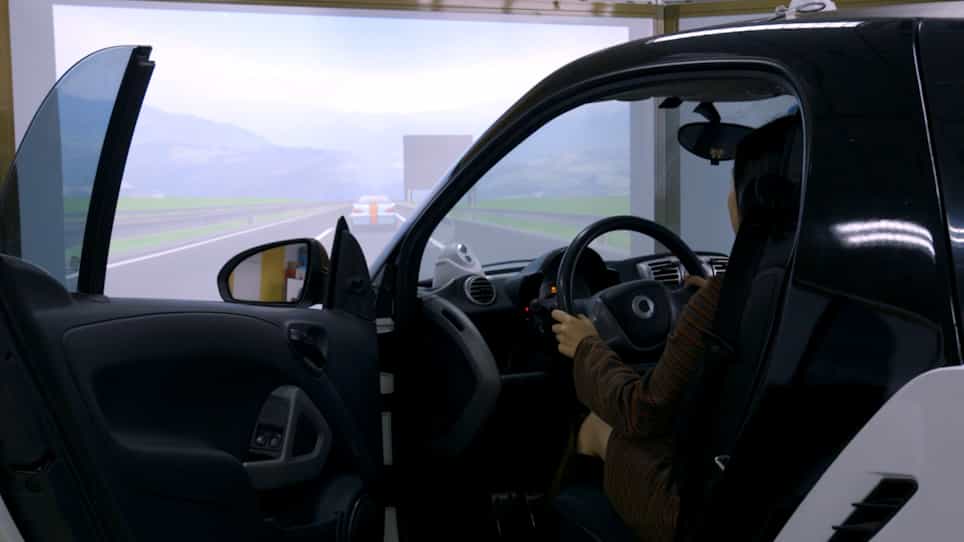
- 在低速校园环境中,使用操纵杆控制的东风共享-VAN自动驾驶车辆进行了一项实验.
- 参与者根据驾驶经验分为三个组 (NN,HN,HH).
- 执行了被动和积极的接管任务,以接管时间和质量为关键指标.
主要成果:
- 传统的驾驶习惯显著损害了被动接管性能.
- 经验丰富的司机 (HH组) 比新手组 (NN组) 需要2.65秒的时间,持驾照但没有经验的司机 (HN组) 比新手组 (NN组) 需要3.78秒的时间.
- 驾驶习惯在测试的低速环境中没有显著影响主动接收制动性能.
结论:
- 传统的驾驶习惯对通过操纵杆控制的自动驾驶汽车的被动接管性能构成重大挑战.
- 接管的初始阶段受到先前驾驶经验的影响最大.
- 调查结果强调需要专门的培训计划,以弥合向自动驾驶过渡的司机的差距.

相关概念视频
 01:18
Hierarchy of Motor Control
2.6K
The hierarchy of motor control refers to the different levels of organization and processing involved in controlling movement in the body. These levels range from higher cortical areas involved in planning and decision-making to lower spinal cord reflexes that respond automatically to external stimuli.
2.6K
 01:22
Controller Configurations
94
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
94
 01:26
PD Controller: Design
218
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
218
 01:26
Feedback control systems
304
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
304
 01:27
Drive-Reduction Theory: Push Theory of Motivation
348
Clark Hull's drive-reduction theory, introduced in the 1940s and 1950s and often termed the "push theory" of motivation, provides a framework for understanding how biological and learned drives influence behavior. Hull suggested that motivation originates from the need to alleviate physiological tension caused by unmet biological necessities. The theory proposes that when a basic need, such as hunger or sleep, goes unfulfilled, it creates an internal imbalance. This imbalance, or...
348
 01:17
Rolling Resistance: Problem Solving
321
Rolling resistance, also known as rolling friction, is the force that resists the motion of a rolling object, such as a wheel, tire, or ball, when it moves over a surface. It is caused by the deformation of the object and the surface in contact with each other, as well as other factors like internal friction, hysteresis, and energy losses within the materials. Rolling resistance opposes the object's motion, requiring additional energy to overcome it and maintain movement. In practical...
321