

积极离散时间系统的成员关系多项式模糊控制:符号传输技术
Xiaomiao Li1, Jundong Zhao1, Fucai Liu1
1School of Electrical Engineering, Yanshan University, Qinghuangdao, Hebei 066004, China.
ISA transactions
|June 18, 2024

概括
这项研究引入了一种新的模糊的共同正的多项式Lyapunov-Krasovskii函数,用于稳定正系统. 拟议的方法通过结合积极性属性和模糊逻辑来增强稳定性分析,从而产生多项式模糊控制器.
科学领域:
- 控制理论 控制理论
- 模糊系统 (Fuzzy Systems) 是一个模糊系统.
- 系统工程 系统工程
背景情况:
- 传统的稳定性分析方法因缺乏积极性属性和会员功能而与积极系统作斗争.
- 现有的技术对于需要正面性和模糊逻辑集成的系统可能不是最佳的.
研究的目的:
- 开发一种新的方法来实现正系的多项式模糊稳定.
- 提出一个新的Lyapunov函数,它结合了积极性和模糊逻辑.
- 为增强系统稳定性设计一个多项式模糊控制器.
主要方法:
- 使用不完美的前提匹配 (IPM) 方法引入一个模糊的共同正的多项式Lyapunov-Krasovskii (FCPL) 函数.
- 应用一种符号转移技术,利用模糊的会员知识来放松稳定性条件.
- 通过对会员函数时刻和模糊模型/控制器会员函数的限制来减少符号数量.
主要成果:
- 提出了一种新的FCPL函数,考虑到对正系统至关重要的正性属性.
- 符号转移技术通过使用模糊的成员信息有效地放松了稳定性条件.
- 一个具有减少符号复杂性的多项式模糊控制器被成功导出.
结论:
- 拟议的FCPL函数和符号传输技术为正数系统的多项式模糊稳定提供了有效的框架.
- 与传统方法相比,开发的方法提供了改进的稳定性分析和控制器设计.
- 通过两个实例进行验证,证实了拟议的稳定技术的有效性.

相关概念视频
 01:24
Pole and System Stability
277
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
277
 01:24
BIBO stability of continuous and discrete -time systems
382
System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
382
 01:21
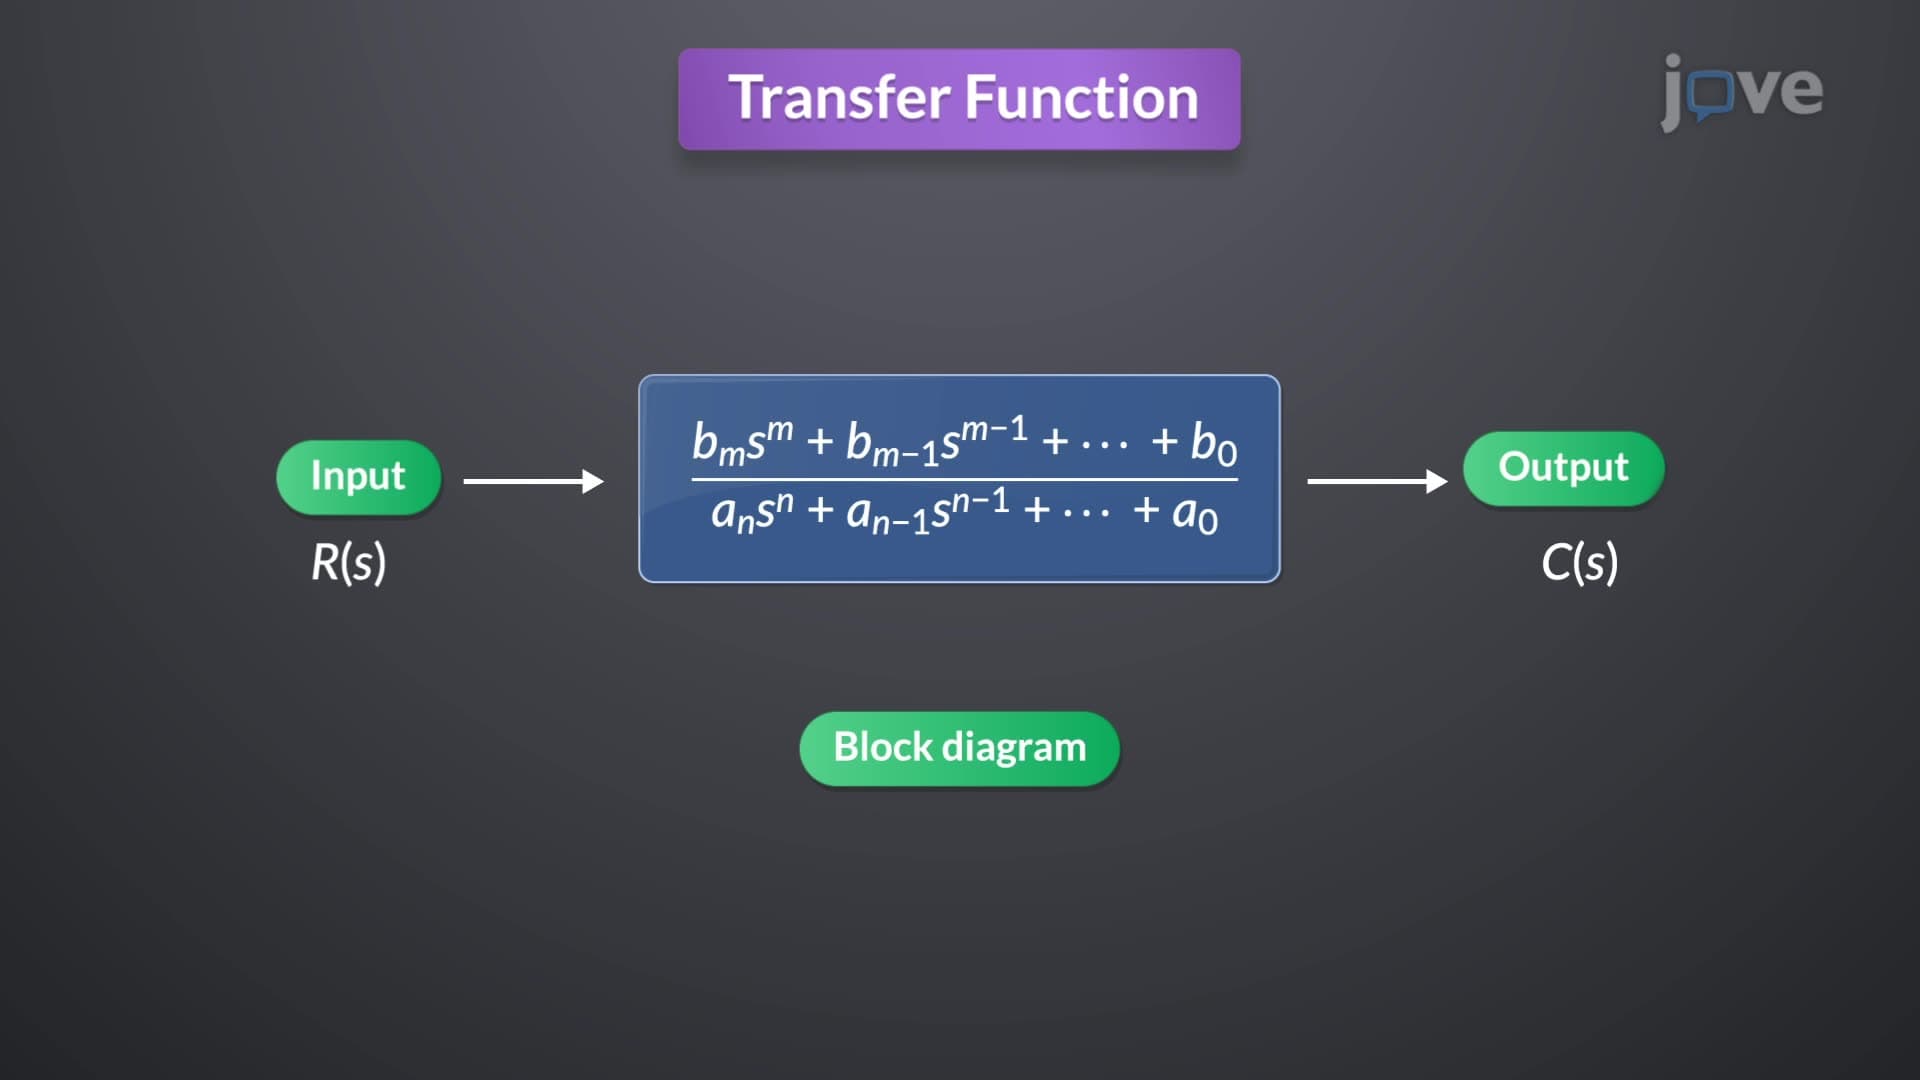
Transfer Function in Control Systems
450
The transfer function is a fundamental concept in the analysis and design of linear time-invariant (LTI) systems. It offers a concise way to understand how a system responds to different inputs in the frequency domain. It serves as a bridge between the time-domain differential equations that describe system dynamics and the frequency-domain representation that facilitates easier manipulation and analysis.
To derive the transfer function, consider a general nth-order linear time-invariant...
To derive the transfer function, consider a general nth-order linear time-invariant...
450
 01:07
Time-Domain Interpretation of PD Control
92
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
92
 01:27
Time and frequency -Domain Interpretation of PI Control
117
Proportional-Integral (PI) controllers are essential in many control systems to improve stability and performance. They are commonly used in everyday devices like thermostats to enhance system damping and reduce steady-state error. When the zero in the controller's transfer function is optimally placed, the system benefits significantly in terms of stability and accuracy.
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
117
 01:21
State Space to Transfer Function
197
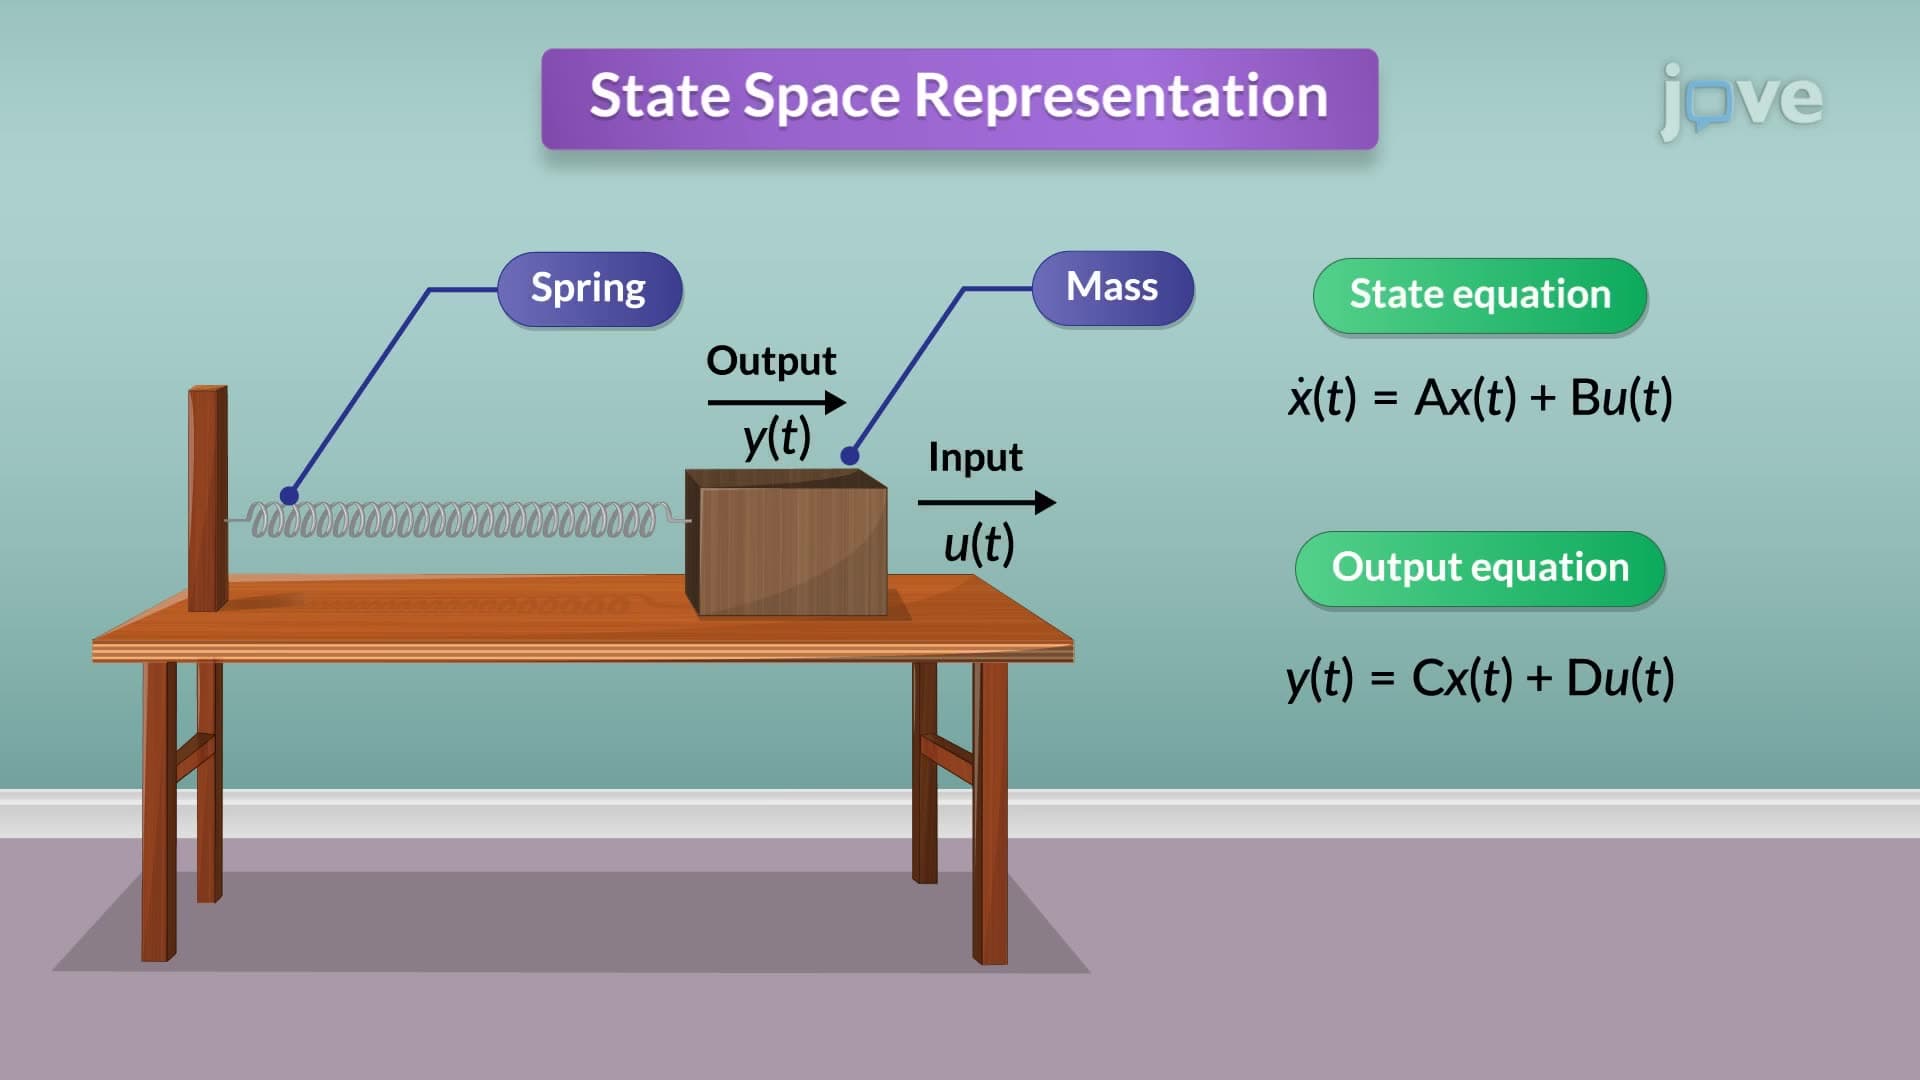
The conversion of state-space representation to a transfer function is a fundamental process in system analysis. It provides a method for transitioning from a time-domain description to a frequency-domain representation, which is crucial for simplifying the analysis and design of control systems.
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
197