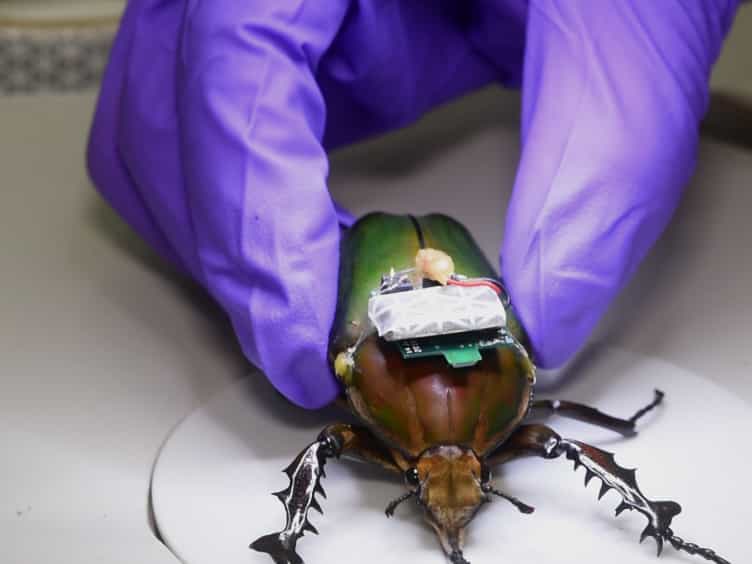

在自然和机器人昆虫中对水和陆地跳跃的比较
Je-Sung Koh1, Sang-Min Baek2,3, Baekgyeom Kim1
1Department of Mechanical Engineering, Ajou University, Gyeonggi-do, Republic of Korea.
Annals of the New York Academy of Sciences
|June 19, 2024

概括
昆虫规模跳跃者,自然和机器人,使用独特的功率放大机制来实现高速. 这些策略管理加速,力和起飞时间,克服尺寸限制以实现高效的机动.
科学领域:
- 生物力学和机器人技术
- 运动和功率放大功率.
背景情况:
- 在小规模 (昆虫大小) 的高速机车运动受到低输出功率的限制.
- 生物和机器人使用专门的机制来放大跳跃的力量.
- 半水中跳跃器利用水的反应力来提高性能.
研究的目的:
- 审查和比较自然和机器人昆虫的跳跃机制.
- 分析基于陆地和水上跳的尺度的性能差异.
- 确定在物理约束下最大化跳跃速度的共同趋势.
主要方法:
- 在自然和机器人昆虫中跳跃机制的文献综述.
- 在不同尺度上对运动策略的比较分析.
- 检查功率放大技术及其有效性.
主要成果:
- 昆虫规模跳跃器采用多种多样的,巧妙的功率放大方案.
- 半水中跳者使用专门的技术来利用水的相互作用.
- 一个普遍的趋势是通过控制加速,力和起飞时间来最大限度地提高跳跃速度.
结论:
- 跳跃性能受到大小,形状和基板相互作用的显著影响.
- 有效的动力释放对于克服尺度依赖的移动速度限制至关重要.
- 了解这些机制可以为先进的生物灵感机器人的设计提供信息.

相关概念视频
 01:29
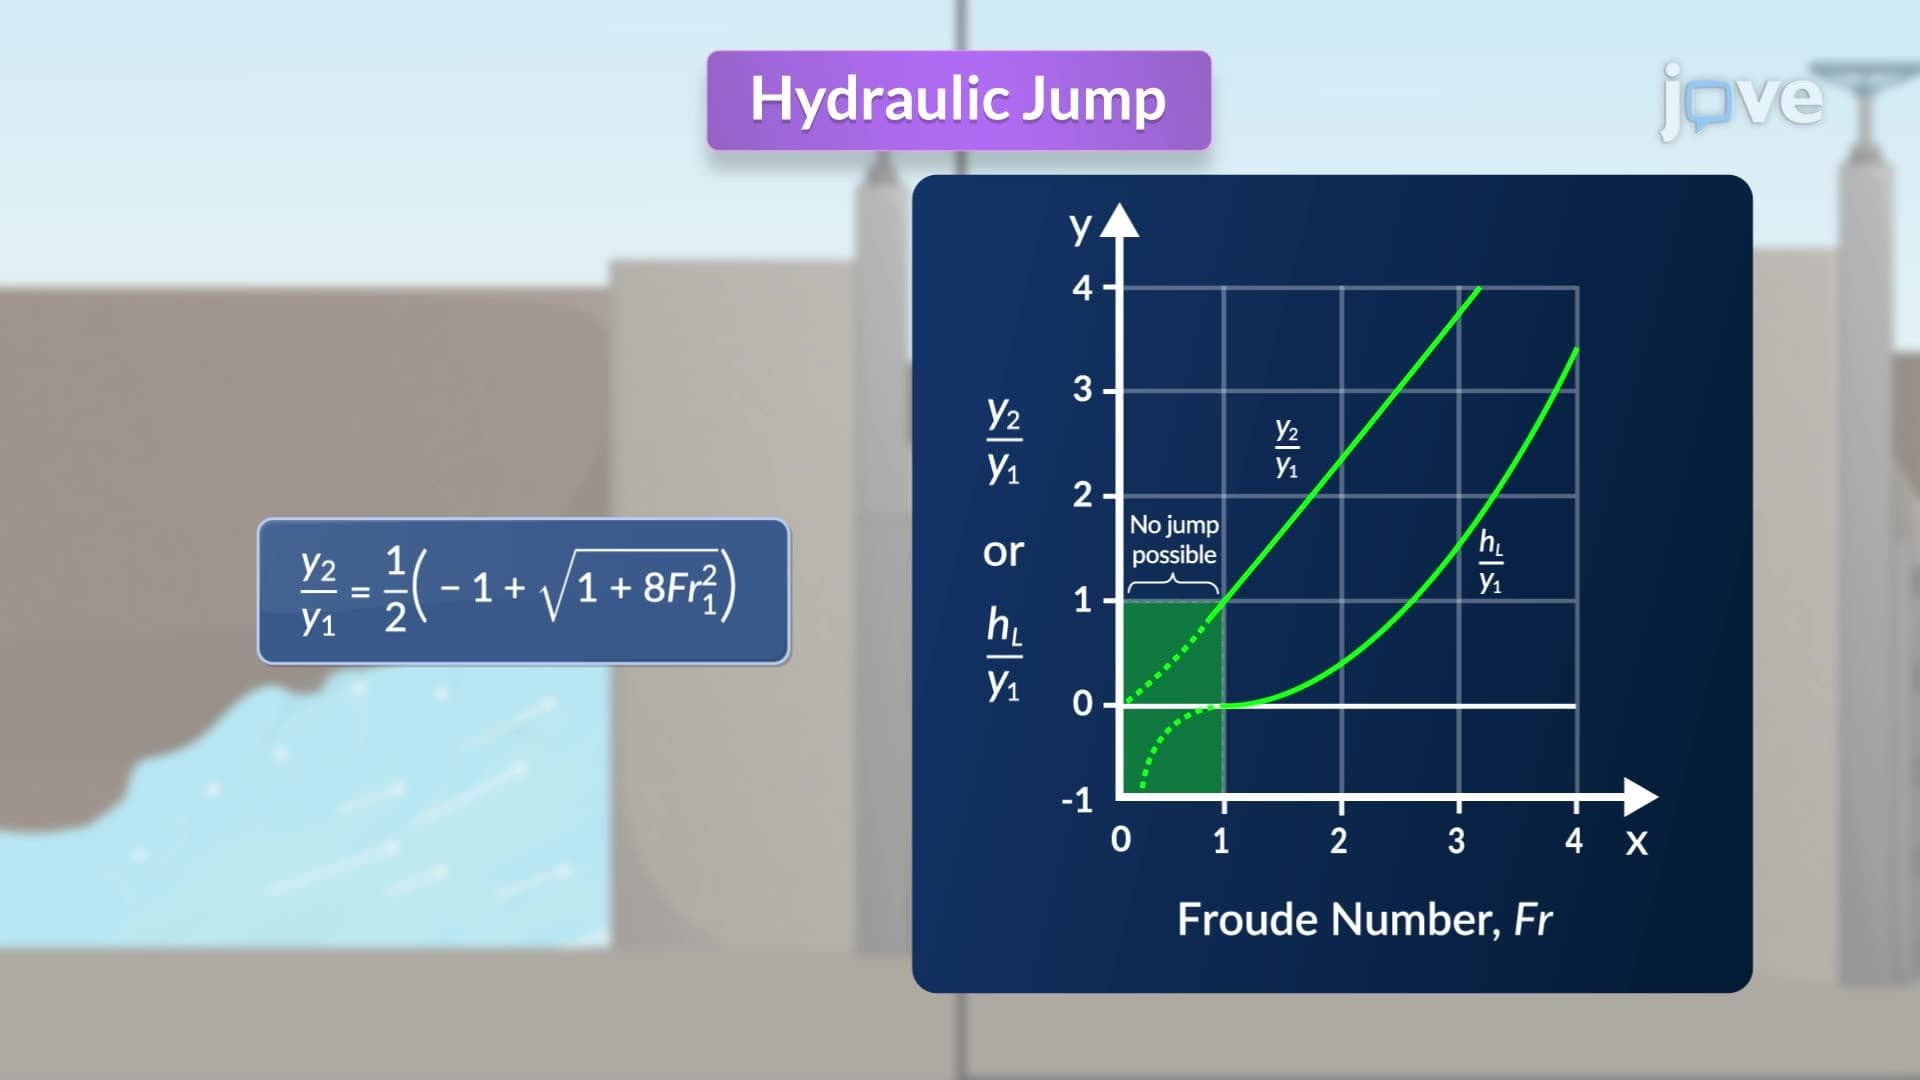
Hydraulic Jump
70
A hydraulic jump is a sudden rise in fluid depth in open channels, occurring when high-velocity (supercritical) flow transitions to low-velocity (subcritical) flow. This phenomenon requires an upstream Froude number greater than 1, as flows with Fr1<1 remain subcritical, making a hydraulic jump impossible due to the need for negative head loss, which violates thermodynamic principles.The characteristics of a hydraulic jump depend on the upstream Froude number and are classified as...
70
 01:54
Convergent Evolution
27.7K
Evolution shapes the features of organisms over time, ensuring that they are suited for the environments in which they live. Sometimes, selection pressure leads to the rise of similar but unrelated adaptations in organisms with no recent common ancestors, a process known as convergent evolution.
27.7K
 01:47
Osmoregulation in Insects
16.2K
Malpighian tubules are specialized structures found in the digestive systems of many arthropods, including most insects, that handle excretion and osmoregulation. The tubules are typically arranged in pairs and have a convoluted structure that increases their surface area.
16.2K