相关实验视频
Updated: Jun 23, 2025
07:51

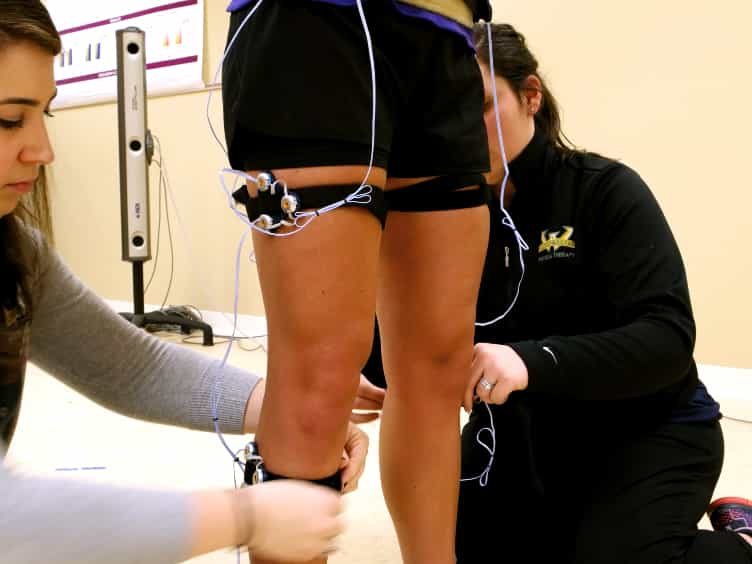
Video Movement Analysis Using Smartphones ViMAS: A Pilot Study
Published on: March 14, 2017
16.8K
通过智能手机视频和IMU数据的动态优化,实现可穿戴和便携的脊柱运动分析
IEEE journal of biomedical and health informatics
|June 26, 2024

概括
这项研究引入了一种新的方法,用于使用智能手机视频和惯性测量单位 (IMU) 追踪脊柱运动. 这种综合方法提高了脊椎间关节运动分析的准确性,用于脊柱健康评估.
科学领域:
- 生物力学 生物力学
- 可穿戴技术可穿戴技术
- 动作捕捉是一种动作捕捉技术.
背景情况:
- 准确的脊柱动力学监测对于疾病评估和人体工程学至关重要.
- 由于小的脊椎和高度的自由度,在非侵入性估计中存在挑战.
研究的目的:
- 为可穿戴脊柱运动跟踪在脊椎间关节层面开发一个动态优化框架.
- 将智能手机视频和惯性测量单元 (IMU) 与胸脊柱模型集成.
主要方法:
- 创建了一个动态优化框架,集成智能手机视频和IMU.
- 验证使用了来自10名健康男性的运动数据,将结果与基于光学标记器的测量结果进行比较.
- 计算机视觉 (OpenCap) 用于从视频中估计姿势.
主要成果:
- 优化方法与脊椎间旋转范围的参考数据密切匹配.
- 在3D旋转中发现了高相关性 (高达0.94).
- 时间序列的关节角度变化与光学标记数据保持一致.
结论:
- 集成IMU和计算机视觉的动态优化超越了脊柱运动跟踪的单模式方法.
- 这种无标记的3D脊柱运动捕捉方法对大规模,现实世界的脊柱健康评估具有前景.

相关概念视频
 01:25
Relative Motion Analysis using Rotating Axes
456
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
456
 01:02
Gyroscope
2.9K
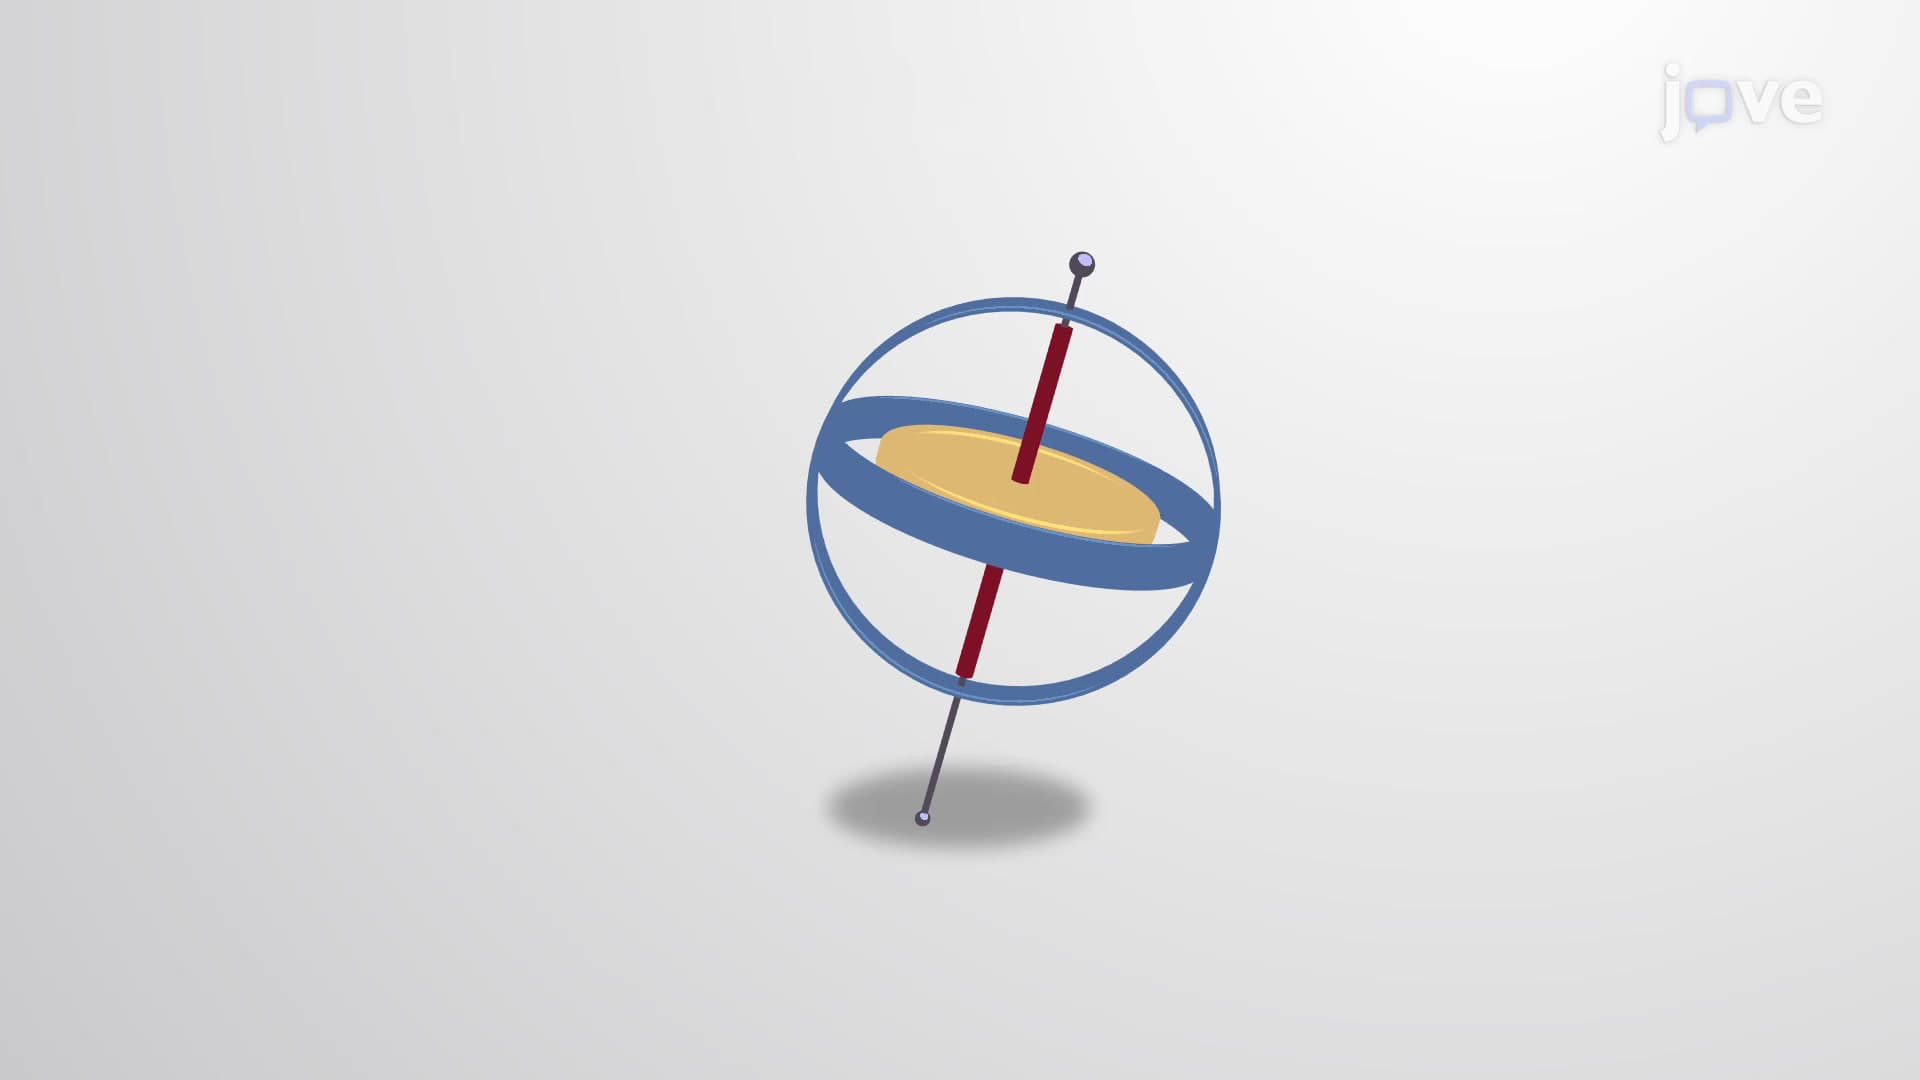
A gyroscope is defined as a spinning disk in which the axis of rotation is free to assume any orientation. When spinning, the orientation of the spin axis is unaffected by the orientation of the body that encloses it. The body or vehicle enclosing the gyroscope can be moved from place to place, while the orientation of the spin axis remains the same. This makes gyroscopes very useful in navigation, especially where magnetic compasses cannot be used, such as in crewed and crewless spacecraft,...
2.9K
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
329
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
329