在以地球为中心的惯性坐标系中,SINS及其错误的运动模型在SE(3) 组上
Ke Fang1, Tijing Cai1, Bo Wang2
1School of Instrument Science and Engineering, Southeast University, Nanjing 210096, China.
Sensors (Basel, Switzerland)
|June 27, 2024

概括
这项研究建立了SE(3) 组上Strapdown惯性导航系统 (SINS) 的新动力模型. 这些模型提高了立场估计的准确性和稳定性,特别是在较大的初始失调角度.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 导航系统 导航系统
- 惯性导航 惯性导航 惯性导航
背景情况:
- 紧式惯性导航系统 (SINS) 对于准确的定位和态度确定至关重要.
- 传统的SINS模型面临着高机动性和参考框架不一致性的挑战.
- 在SE(3) 组提供了一个强大的数学框架来表示刚性身体运动和错误.
研究的目的:
- 在SE(3) 组框架内建立SINS及其错误的高级动力学模型.
- 为了解决和减轻因参考坐标系不一致而产生的错误.
- 引入一种新的态度错误定义,以改善错误来源的脱.
主要方法:
- 使用SE(3) 组来共同表示态度和速度.
- 应用高阶贝克-坎贝尔-豪斯多夫扩展来补偿非交换性运动错误.
- 导出左和右不变误差的动力学,无论是n-frame还是b-frame.
- 引入一种新的态度错误定义,以分离影响因素.
主要成果:
- 在以地球为中心的惯性 (ECI) 框架中开发了SINS及其错误在SE(3) 组上的动力模型.
- 在高机动性期间成功补偿了非交换性运动错误.
- 证明了更好的姿态估计,特别是在转角度的准确性,即使有很大的初始错位.
- 通过转盘和车载实地实验验证了模型的有效性.
结论:
- 拟议的SE(3) 基于组的动力学模型提高了SINS态度估计的准确性和稳定性.
- 新的错误定义有效地分离了影响n-frame和b-frame动态的因素.
- 与传统的SE(3) 基于组的方法相比,这些模型提供了更高的性能,特别是在具有挑战性的动态场景中.

相关概念视频
 01:30
Kinematic Equations for Rotation
320
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
320
 01:18
Kinematic Equations - III
7.6K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
7.6K
 01:17
Kinematic Equations - II
9.5K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
9.5K
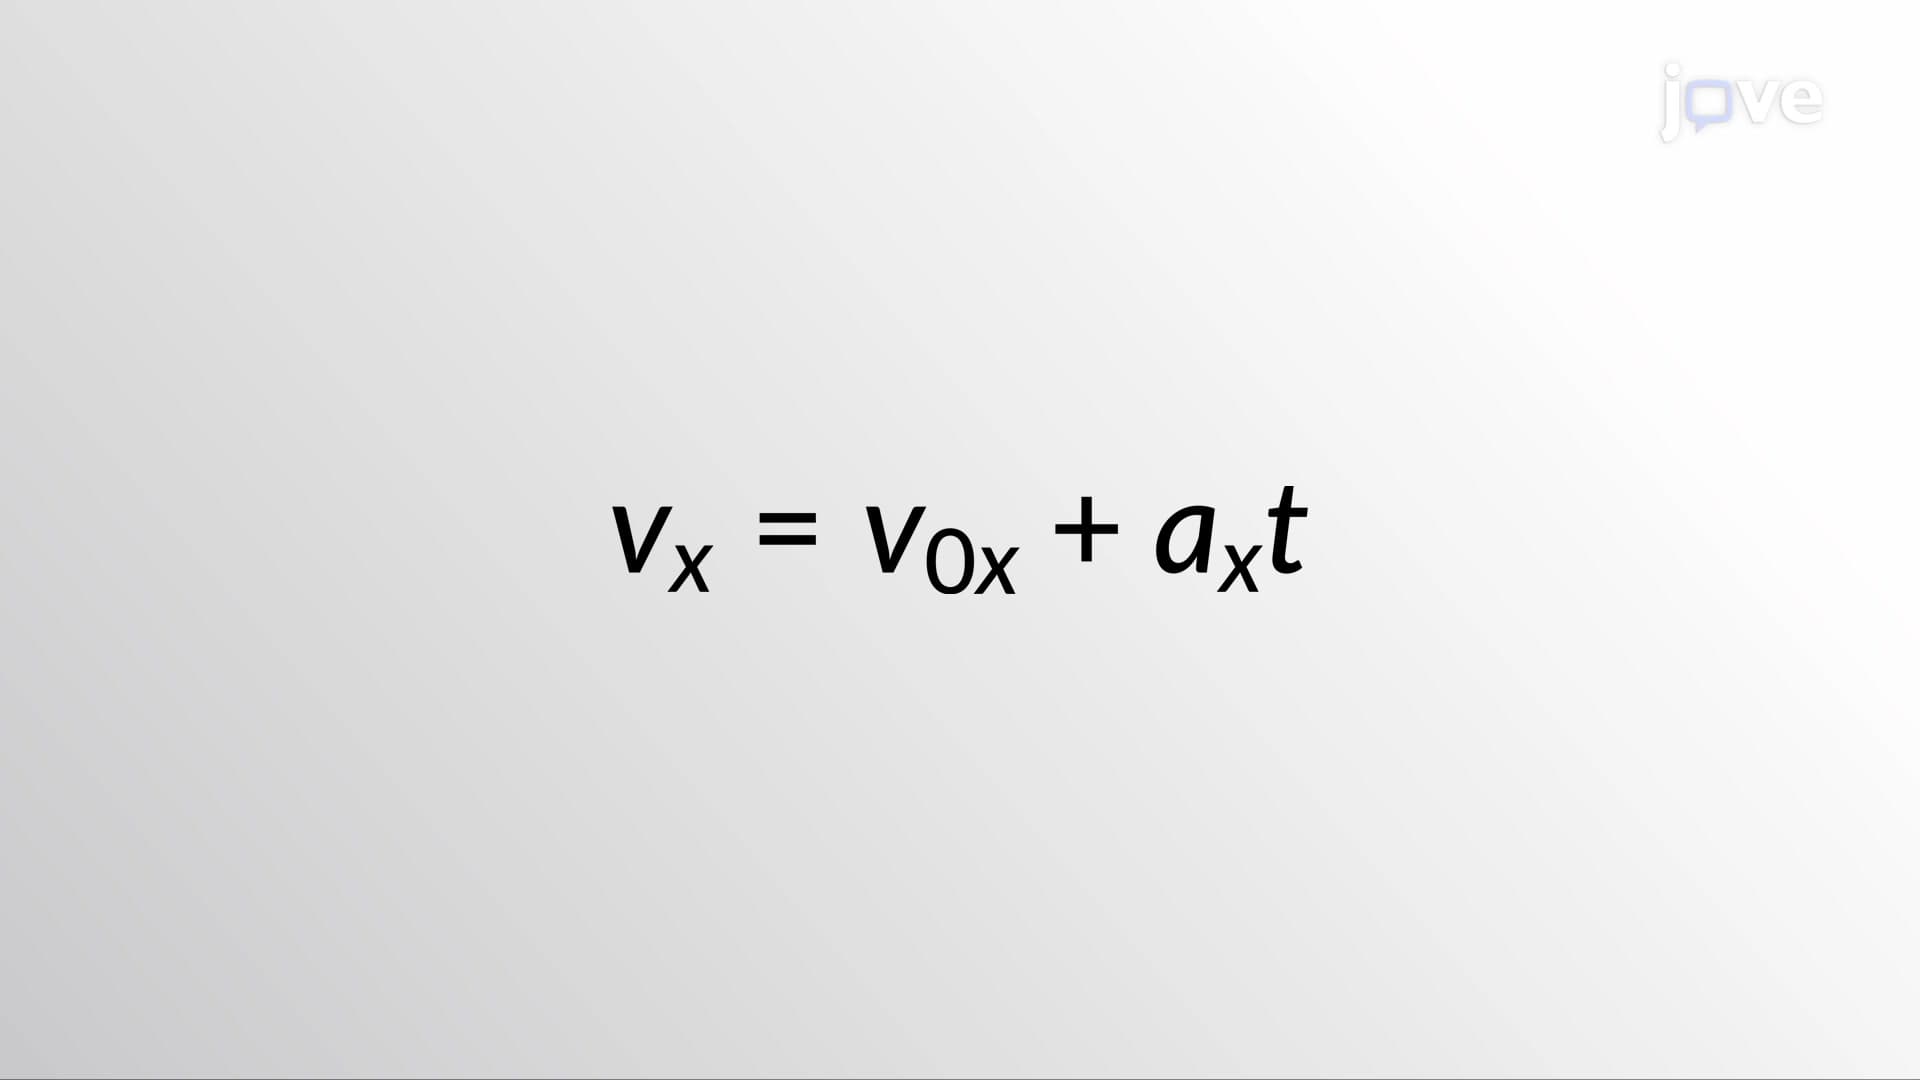 01:26
Kinematic Equations - I
10.5K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
10.5K
 01:19
Euler Equations of Motion
209
Imagine a rigid body that is rotating at an angular velocity of ω within an inertial frame of reference. Along with this, picture a second rotating frame that is attached to the body itself. This frame moves along with the body and possesses an angular velocity of Ω. The total moment about the center of mass is calculated by adding the rate of change of angular momentum about the center of mass in relation to the rotating frame and the cross-product of the body's angular velocity...
209
 01:21
Equations of Motion: Rectangular Coordinates and Cylindrical Coordinates
307
Understanding the motion of particles is a fundamental aspect of classical mechanics, and the choice of the coordinate system plays a pivotal role in unraveling the complexities of their dynamics.
When a particle moves relative to an inertial frame, the equations of motion can be expressed using rectangular components. If the motion is confined to the x-y plane, the equations having the x and y coordinates only can be used to simplify the mathematical representation.
However, when particles...
307