相关实验视频
Updated: Aug 17, 2026
07:51

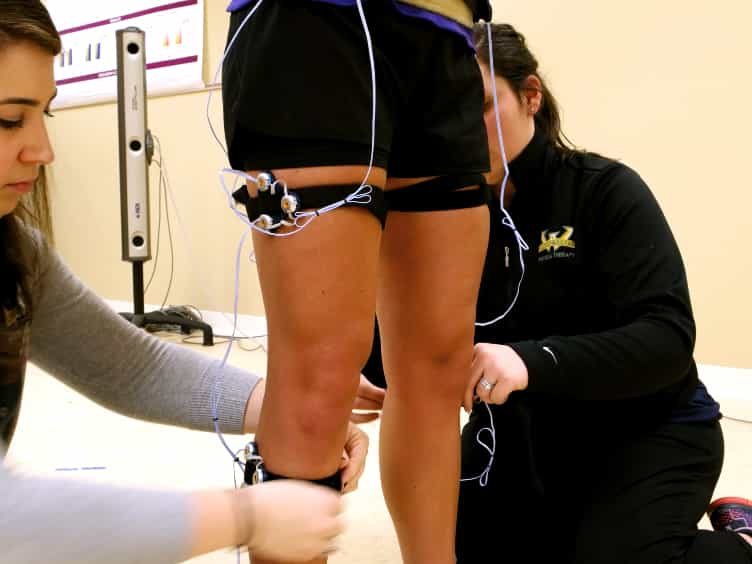
Video Movement Analysis Using Smartphones ViMAS: A Pilot Study
Published on: March 14, 2017
16.8K
动力调整比机械调整更好地恢复原生形跟踪模式
Yong Deok Kim1,2, Dohyung Lim3, Dai-Soon Kwak4
1Joint Replacement Center, Eunpyeong St. Mary's Hospital, Seoul, Republic of Korea.

概括
动力对齐 (KA) 与机械对齐 (MA) 相比,在全膝关节整形术 (TKA) 后更好地恢复本源形跟踪. KA导致了更多的手术后跟踪模式,类似于手术前的本地膝盖模式.
科学领域:
- 整形外科手术 整形外科手术
- 生物机械分析分析
- 关节塑形研究研究
背景情况:
- 在全膝关节整形术 (TKA) 后恢复自然膝关节功能对于患者的治疗结果至关重要.
- 骨跟踪,膝盖在曲过程中的运动,显著影响TKA的成功.
- 了解对齐技术对骨机械的影响对于外科创新至关重要.
研究的目的:
- 为了比较动力对齐 (KA) 与机械对齐 (MA) 在恢复本地形跟踪模式方面的有效性.
- 使用集群算法客观分析和区分带状骨跟踪行为.
主要方法:
- 20个尸体 (40个膝盖) 接受了TKA,其中一个膝盖随机分配给KA,另一个膝盖分配给MA.
- 卡塔卡使用了经过校准验证的技术;马塔卡使用了测量切除技术.
- 使用运动分析测量了状骨跟踪,并使用基于密度的算法对数据进行了聚类.
主要成果:
- 与机械对齐 (MA) 相比,动力对齐 (KA) 显示出明显不同的形跟踪模式.
- 较高比例的KA膝盖在TKA前占主导地位的集群中表现出TKA后的骨跟踪模式.
- KA比MA (p < 0.05) 更接近地复制了原生膝盖形跟踪模式.
结论:
- 在全膝关节整形术后恢复自然的骨跟踪方面,动力对齐 (KA) 优于机械对齐 (MA).
- 这项研究提供了支持KA的生物力学证据,用于改善TKA的骨力学.

相关概念视频
 01:24
Gyroscope: Precession
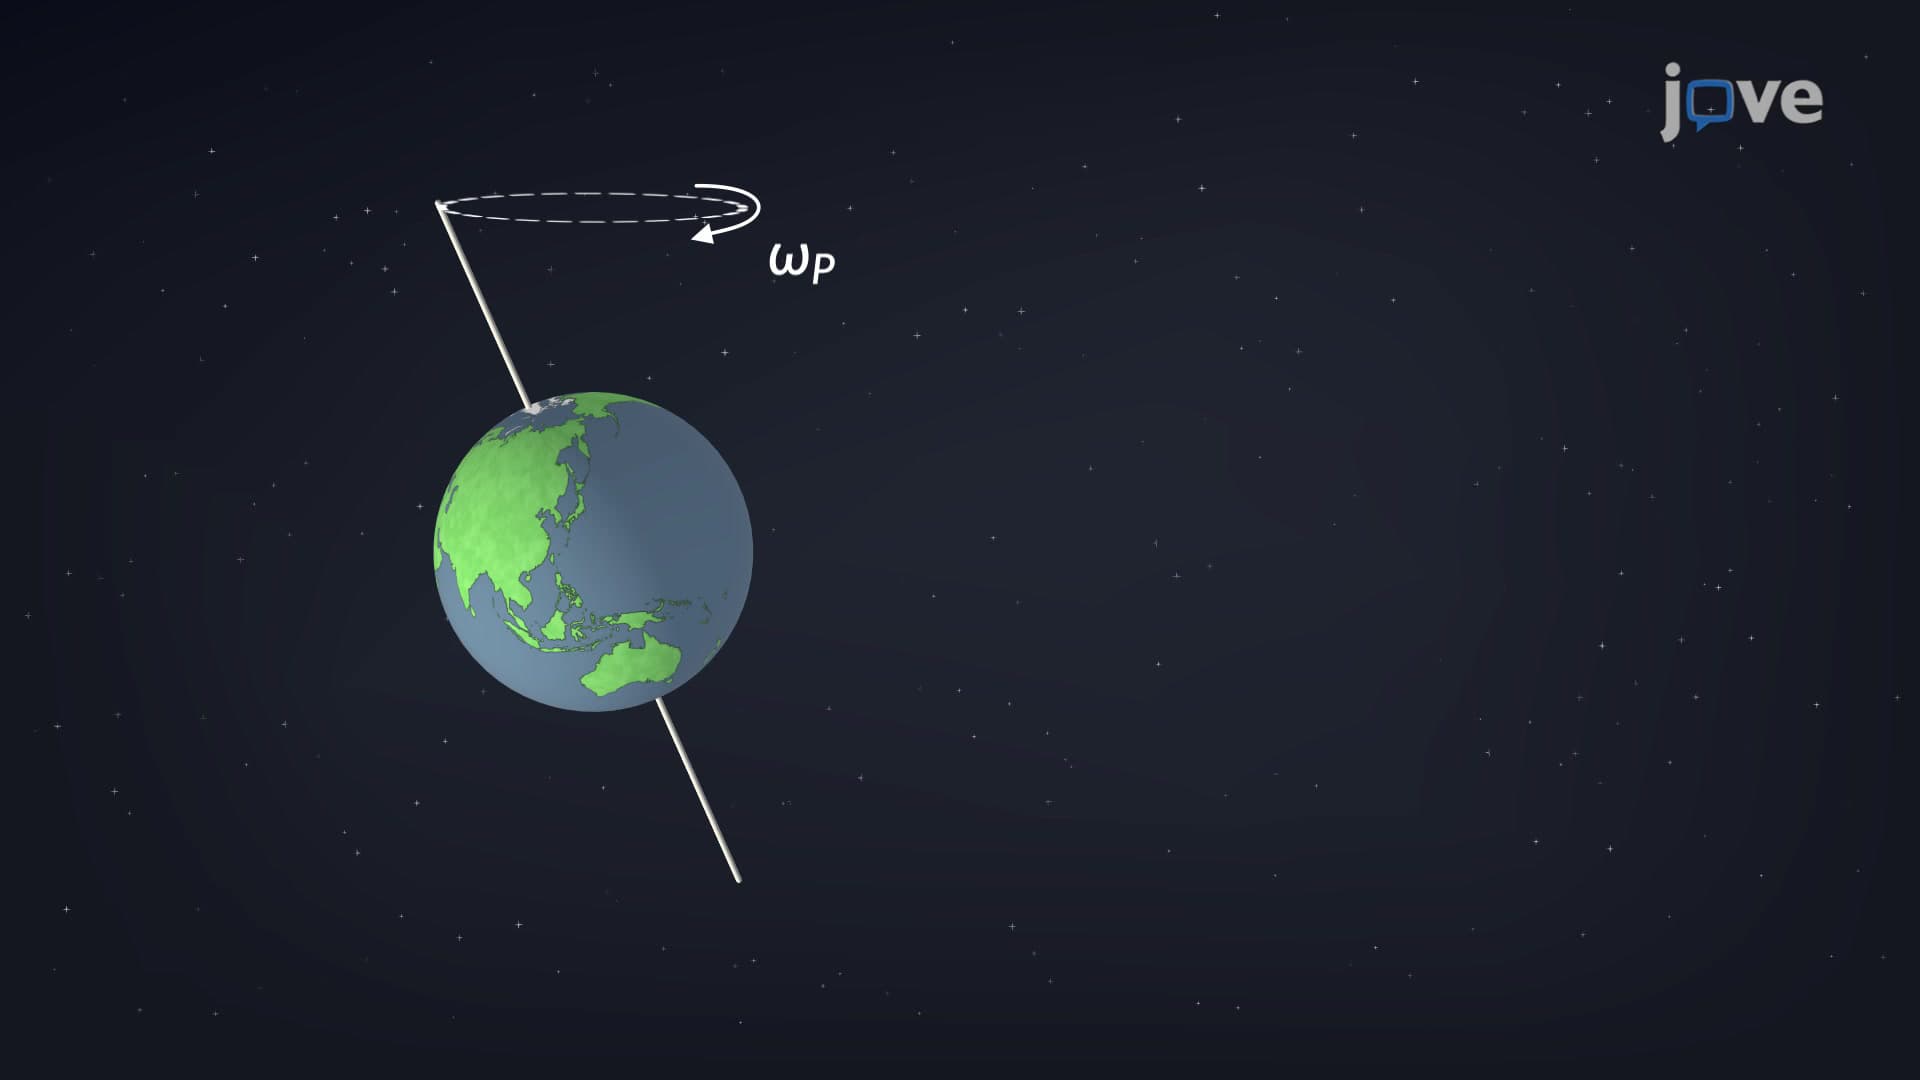
Precession can be demonstrated effectively through a spinning top. If a spinning top is placed on a flat surface near the surface of the Earth at a vertical angle and is not spinning, it will fall over due to the force of gravity producing a torque acting on its center of mass. However, if the top is spinning on its axis, it precesses about the vertical direction, rather than topple over due to this torque. Precessional motion is a combination of a steady circular motion of the axis and the...
 01:24
One-Degree-of-Freedom System
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:15
Torque Free Motion
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...
 01:10
Deformation in a Circular Shaft
One of the distinctive characteristics of circular shafts is their ability to maintain their cross-sectional integrity under torsion. In other words, each cross-section continues to exist as a flat, unaltered entity, simply rotating like a solid, rigid slab. To understand the distribution of shearing stress within such a shaft, consider a cylindrical section inside this circular shaft. This section has a length of L and a radius of R, with one end fixed. The radius of the cylindrical section is...
 01:22
Controller Configurations
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
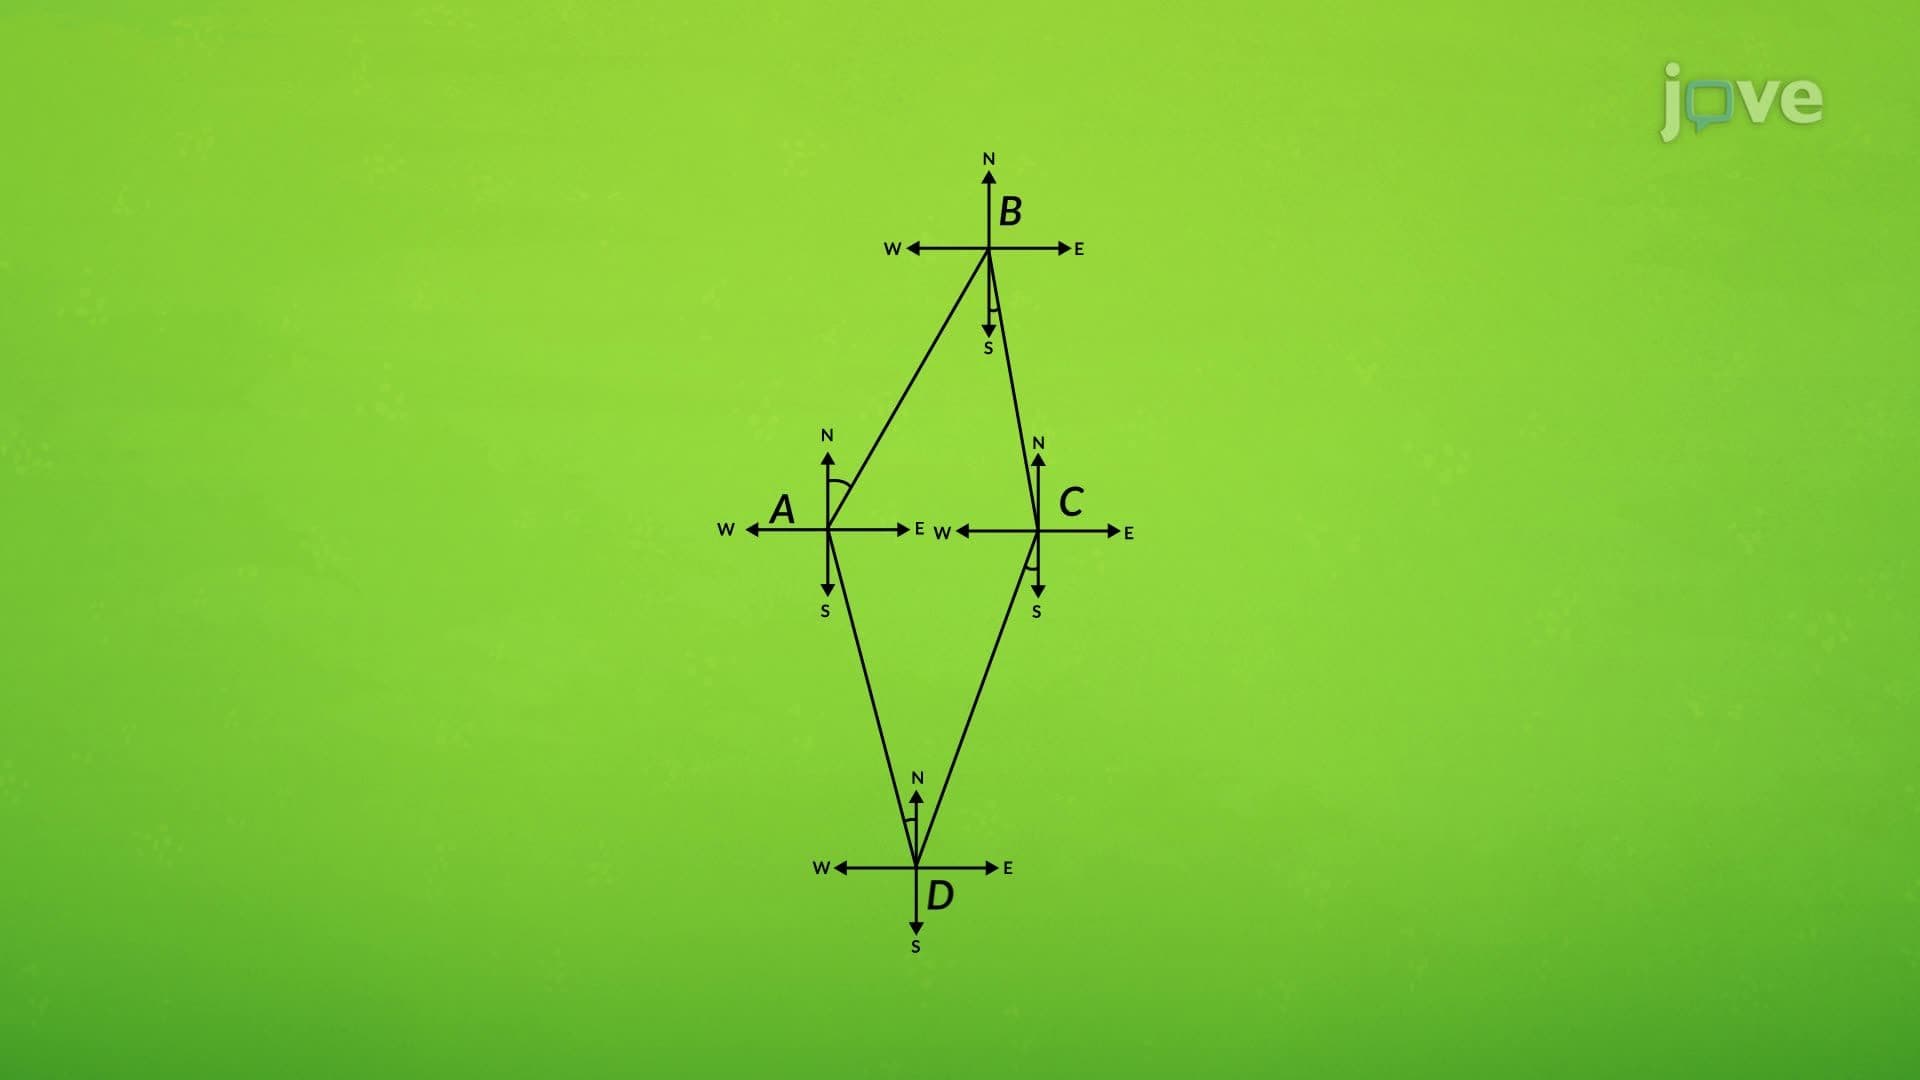 01:12
Adjusting a Traverse
In the site survey of a four-sided traverse, internal angles are essential to ensure geometric accuracy. The survey revealed that the sum of the measured internal angles was 359 degrees and 48 minutes, which is 12 minutes less than the expected 360 degrees. This discrepancy signals an error likely arising from measurement inaccuracies during the fieldwork.To rectify this error, the adjustment process involved distributing the 12-minute shortfall equally across the four internal angles. By...