对于场景一致性的正常重定向
相关实验视频
Updated: Jun 21, 2025
09:11
Controlled Rotation of Human Observers in a Virtual Reality Environment
Published on: April 21, 2022
2.5K
IEEE transactions on visualization and computer graphics
|July 16, 2024

概括
对于3D室内点云来说,生成一致的表面方向是具有挑战性的. 本研究引入了一个新的框架 (NRSC),它使用方向桥梁树 (OBT) 来实现室内场景的全球一致的正常方向.
科学领域:
- 计算机视觉 计算机视觉
- 3D重建的3D重建
- 几何处理 几何处理
背景情况:
- 3D扫描技术已经进步,导致更多的室内场景被捕获.
- 对于室内点云来说,生成与方向一致的正常值至关重要,但具有挑战性.
- 现有的方法专注于对象级目标,与真实扫描的室内数据作斗争.
研究的目的:
- 为了解决计算真实扫描室内点云的一致表面方向的困难.
- 为室内场景的一致性提出一个新的正常重定向框架.
- 在室内点云数据中实现全球一致的正常方向.
主要方法:
- 估计初始正常值,并从室内点云中提取连接区域.
- 为层次区域组织设计一个抽象的定向桥梁树 (OBT).
- 实施代导向传播和投票机制,以实现父子区域的一致性.
主要成果:
- 拟议的NRSC框架成功地产生了与本地定向一致的区域.
- 一个投票机制有效地纠正基于父节点的子节点定向.
- 实验结果表明室内点云的全球一致的方向生成.
结论:
- 该NRSC框架有效地克服了针对室内点云的指导标准的挑战.
- OBT和投票机制是实现全场定向一致性的关键组成部分.
- 该方法在合并和单视图室内场景上都显示出强大的性能.
相关概念视频
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
394
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
394
 01:25
Relative Motion Analysis using Rotating Axes
454
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
454
 01:12
Perceptual Constancy
379
Perceptual constancy is the ability to recognize that objects remain consistent and unchanged even when their appearance varies due to changes in sensory input. There are four main types of perceptual constancy: size constancy, shape constancy, color constancy, and brightness constancy.
Size constancy is the recognition that an object remains the same size, even when its image on the retina changes. For instance, a bus is perceived to be large enough to carry people, even if it looks tiny from...
Size constancy is the recognition that an object remains the same size, even when its image on the retina changes. For instance, a bus is perceived to be large enough to carry people, even if it looks tiny from...
379
 01:03
Inertial Frames of Reference
7.1K
Newton’s first law is usually considered to be a statement about reference frames. It provides a method for identifying a special type of reference frame: the inertial reference frame. In principle, we can make the net force on a body zero. If its velocity relative to a given frame is constant, then that frame is said to be inertial. So, by definition, an inertial reference frame is a reference frame where Newton's first law holds valid. Newton's first law applies to objects with...
7.1K
 01:27
Non-inertial Frames of Reference
5.9K
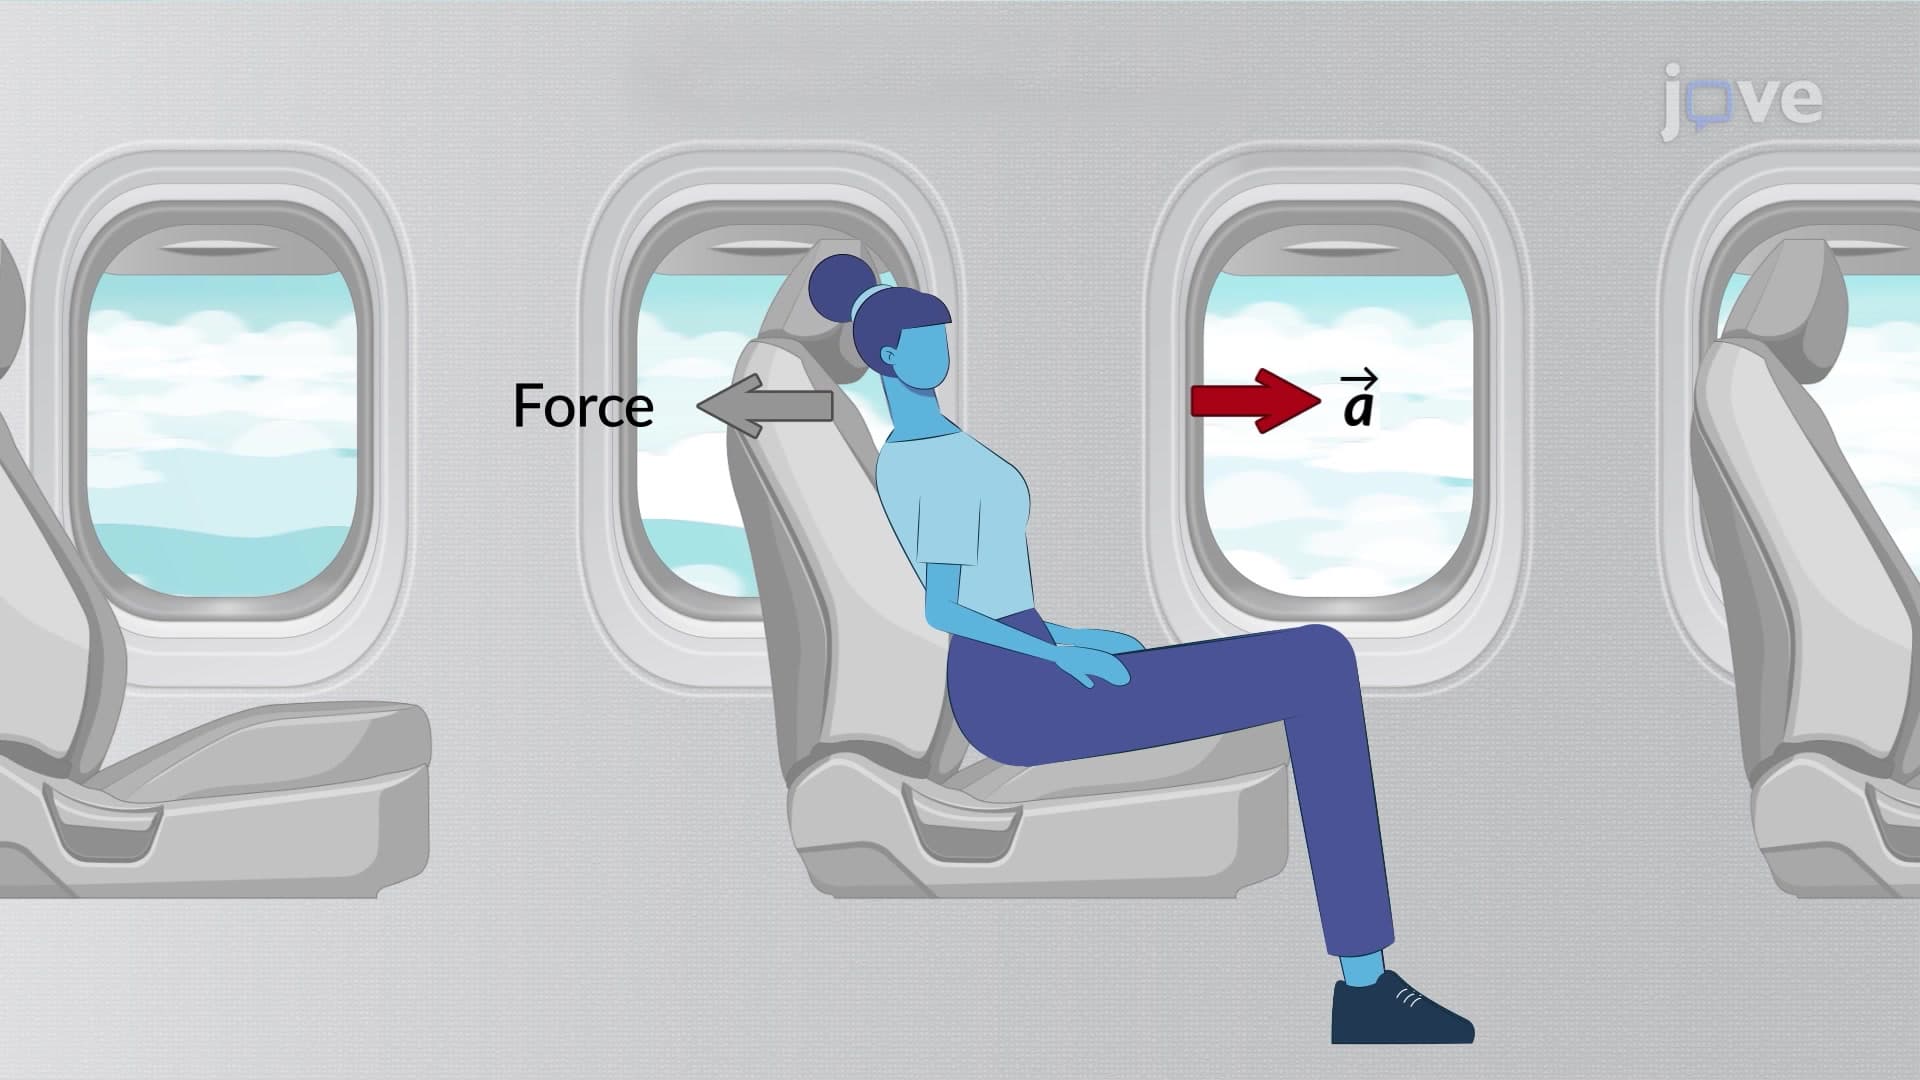
A reference frame accelerating or decelerating relative to an inertial frame is a non-inertial frame. To help understand this, consider what taking off in an airplane, turning a corner in a car, riding a merry-go-round, and the circular motion of a tropical cyclone all have in common. All these systems are accelerating, decelerating, or rotating relative to the Earth; hence, they all are non-inertial frames. All these systems exhibit inertial forces, which merely seem to arise from motion,...
5.9K
 01:11
Rotation of Asymmetric Top
882
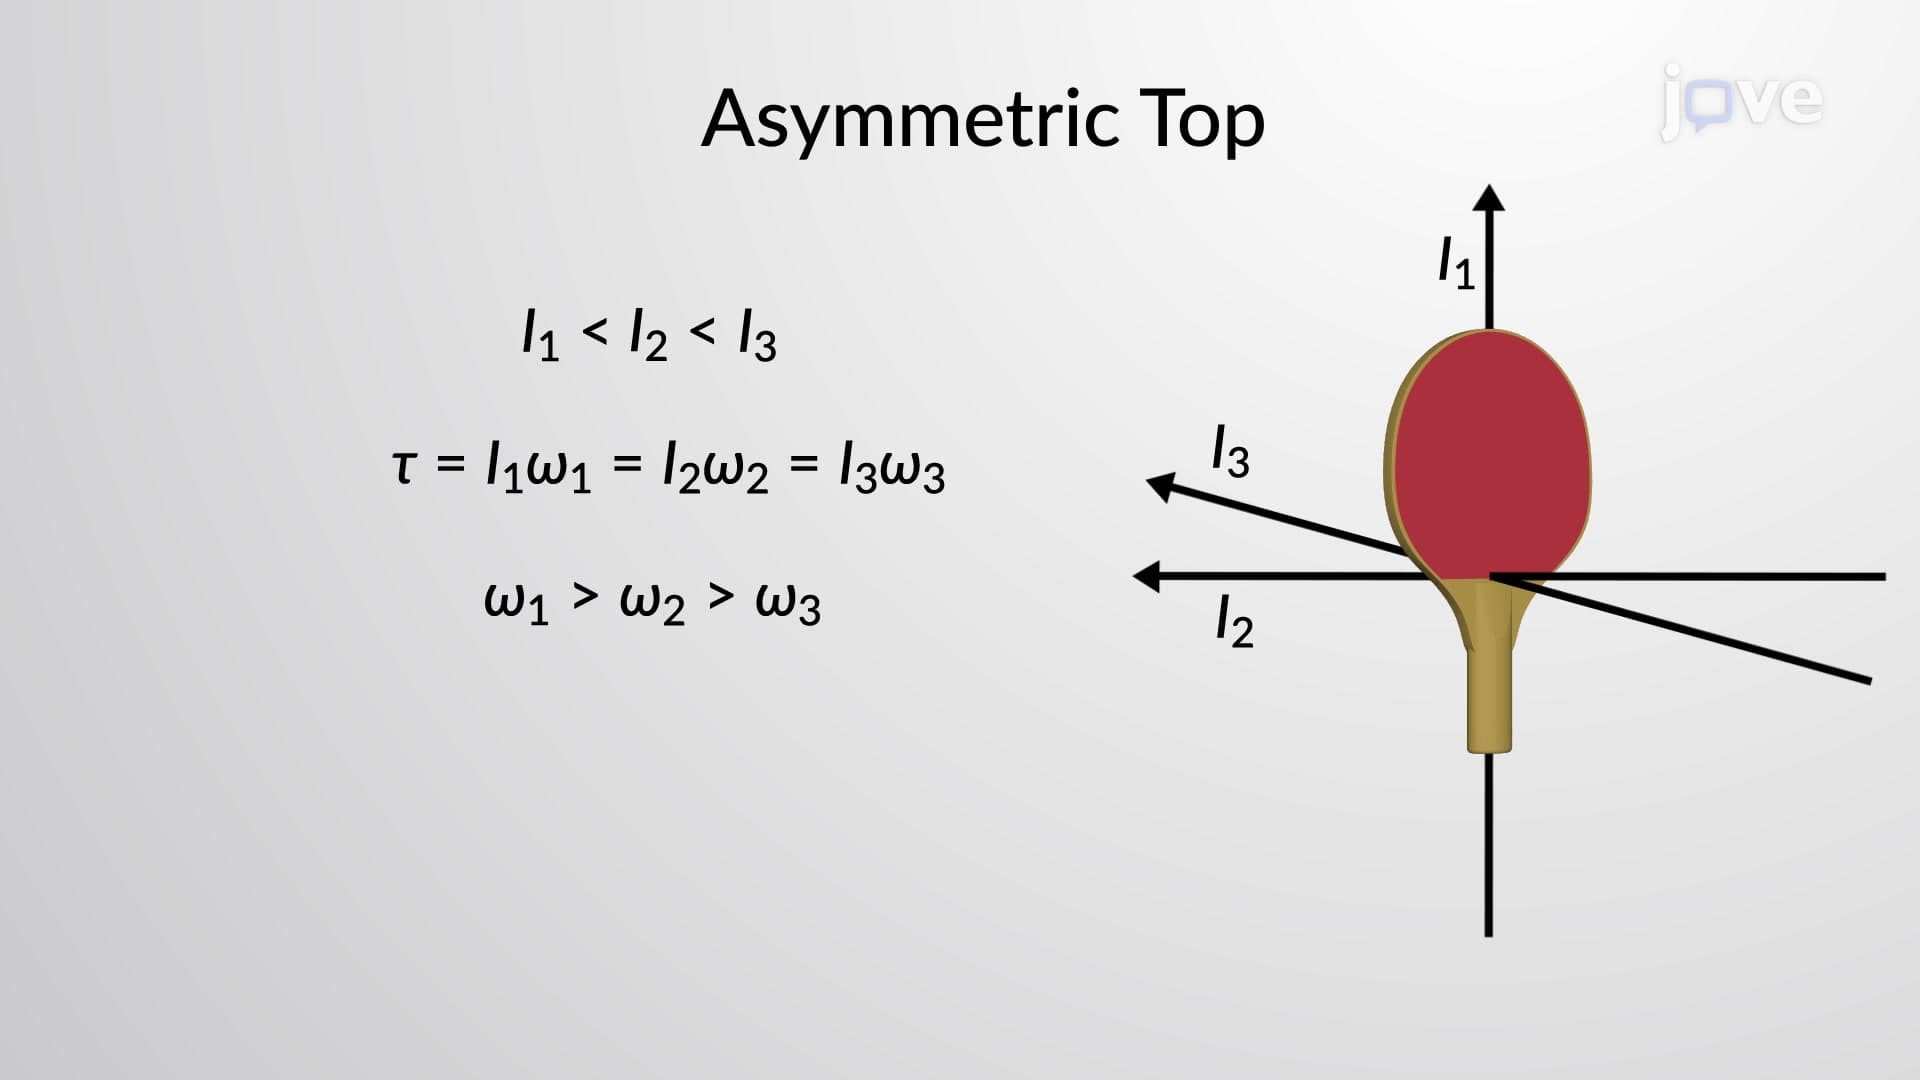
By definition, a spherically symmetric body has the same moment of inertia about any axis passing through its center of mass. This situation changes if there is no spherical symmetry. Since most rigid bodies are not spherically symmetric, these require special treatment.
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
882