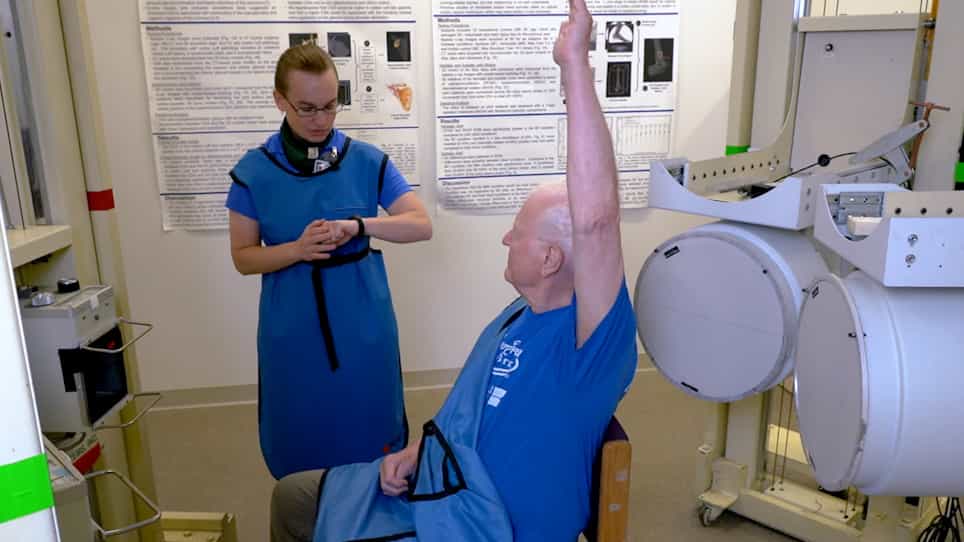
来自多个任意定向的表面的起源区域估计,使用来自运动的标记器引导结构
Philip Joris1, Ruben Moermans1, Els Jenar2
1Forentrics, Antwerp, Belgium; Department of Electrical Engineering, ESAT/PSI, KU Leuven, Leuven, Belgium; Medical Imaging Research Center, MIRC, KU Leuven, Leuven, Belgium.
Forensic science international
|July 18, 2024

概括
这项研究引入了一种新的血液污点模式分析方法,使用HemoVision软件和运动结构 (SfM) 来从二维照片中重建3D冲击模式. 经过验证的方法为复杂的多表面血迹提供了准确的法医分析.
科学领域:
- 法医科学 法医科学 法医科学
- 这是一种摄影计量技术 (photogrammetry).
- 计算机视觉 计算机视觉
背景情况:
- 在法医调查中,血迹模式分析至关重要.
- 在多个表面上分析撞击模式存在挑战.
- 现有的软件限制阻碍了复杂犯罪现场的分析.
研究的目的:
- 扩展HemoVision软件,用于分析多个任意定向表面上的撞击模式.
- 验证一种新的方法,将HemoVision与运动结构 (SfM) 技术相结合.
- 为了使2D照片中的血迹图案能够3D重建.
主要方法:
- 将HemoVision的基于标记器的系统与SfM集成.
- 从2D照片中重建撞击模式的3D几何.
- 控制实验以验证重建的准确性和错误分析.
主要成果:
- 实现了强大的3D重建精度,中位翻译误差<3mm和角误差<0.2°.
- 估计图案来源的平均总误差为8.12厘米,垂直维度是主要的错误来源.
- 在不同的成像设备和分辨率中,准确性是一致的.
结论:
- 用SfM增强的HemoVision可以有效地分析复杂的,多表面撞击模式,仅使用2D照片.
- 经过验证的方法为法医专家提供了一种高效且易于使用的工具.
- 这一进步有助于调查复杂的犯罪现场,涉及复杂的血迹分布.

相关概念视频
 01:24
Absolute Motion Analysis- General Plane Motion
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:25
Relative Motion Analysis using Rotating Axes
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Oriented Surfaces
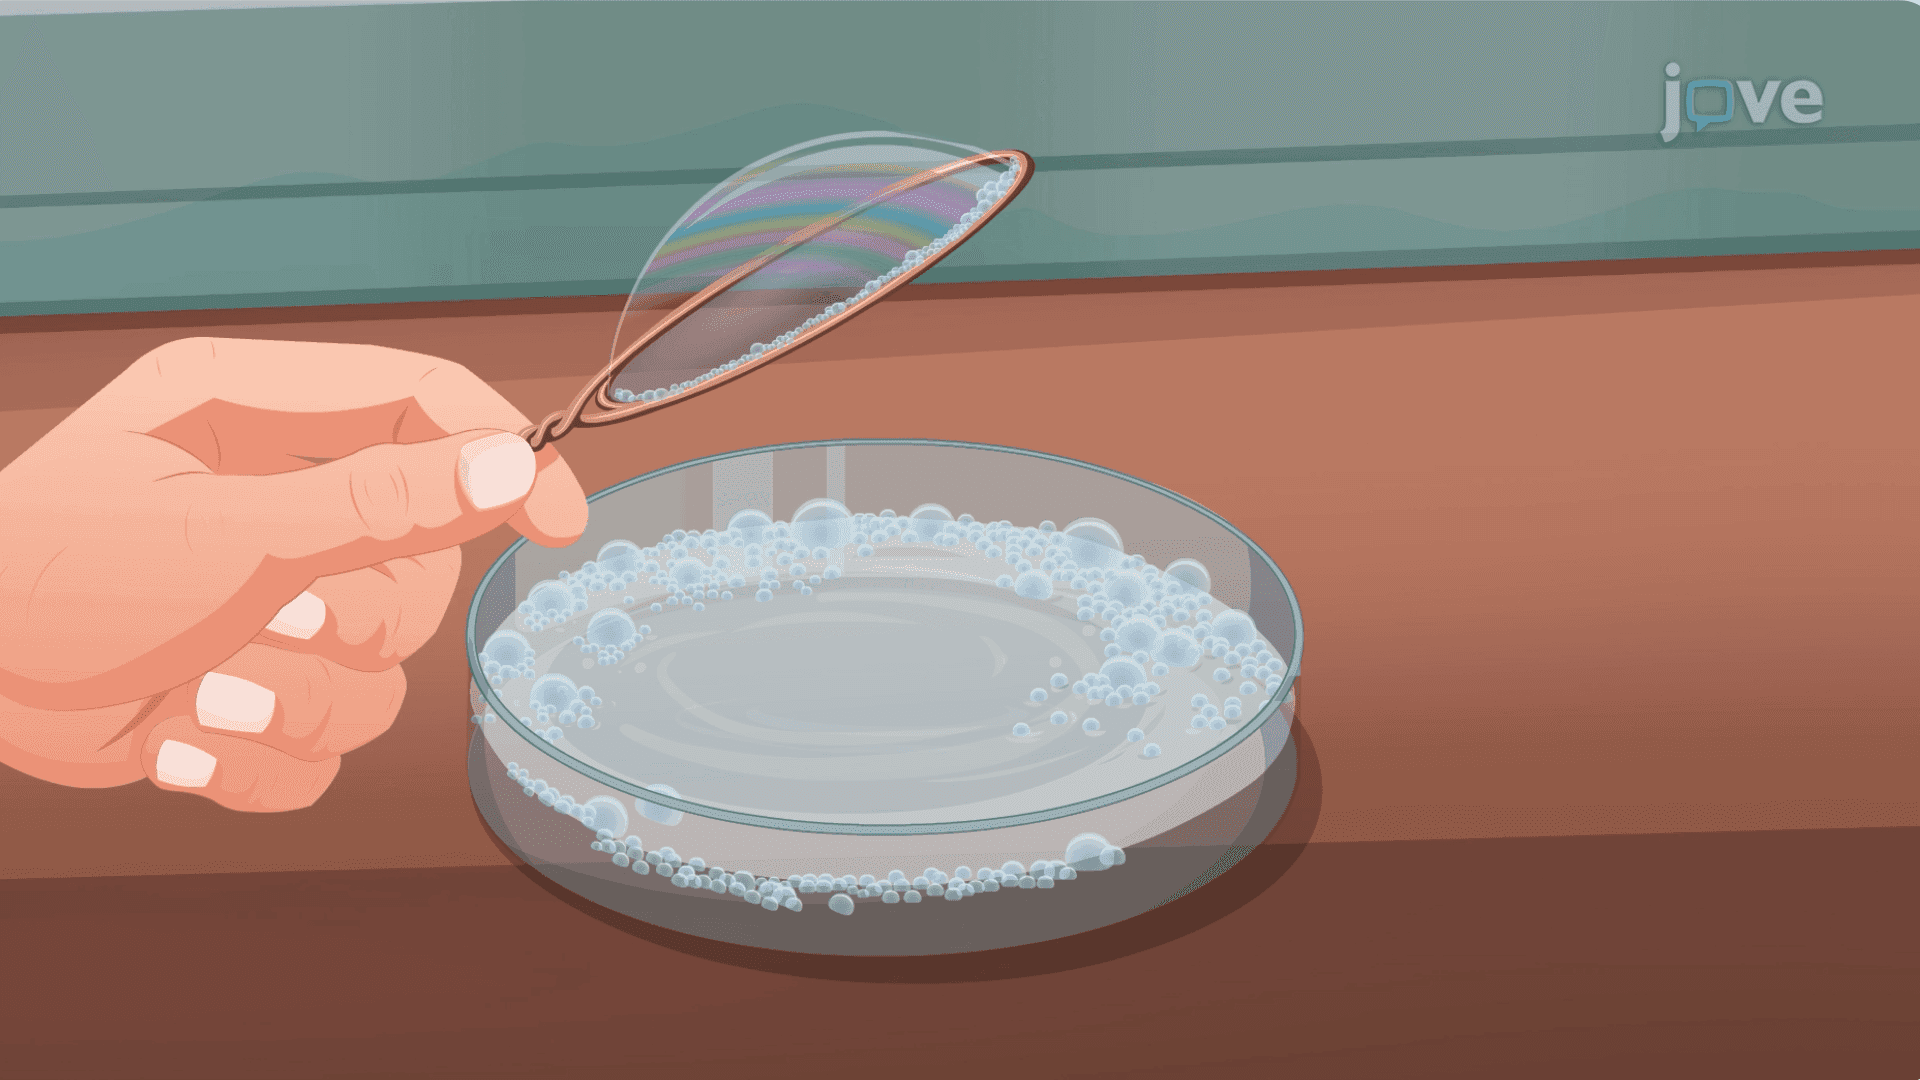
A surface is called orientable if a consistent choice of unit normal vector can be made at every point on the surface. A thin soap film stretched across a wire loop provides a familiar example. The film separates the air on one side from the air on the other, so one side can be selected as positive and the opposite side as negative. Once this choice is made, a unit normal vector can be assigned smoothly across the entire surface.At each point on the soap film, a unit normal vector points...