

概率神经传递函数估计与贝叶斯系统识别贝叶斯系统识别
Nan Wu1,2, Isabel Valera1, Fabian Sinz3
1Department of Computer Science, Saarland University, Saarbrücken, Germany.
PLoS computational biology
|July 31, 2024

概括
这项研究引入了贝叶斯系统识别方法,用于神经反应预测. 该方法在有限的数据中高效地模拟神经网络,提供不确定性估计,以改进神经属性和刺激的分析.
科学领域:
- 计算神经科学是一种神经科学.
- 系统神经科学 系统神经科学
- 机器学习 机器学习
背景情况:
- 神经群体的反应与物理刺激有关,传统上以受感场为特征.
- 现有的神经系统识别模型需要大量的数据,由于实验记录时间有限,这带来了挑战.
- 深度神经网络擅长预测,但往往缺乏对神经表征的不确定性量化和像最令人兴奋的输入 (MEI) 这样的衍生统计数据.
研究的目的:
- 开发一种贝叶斯系统识别方法,用于预测神经对视觉刺激的反应.
- 研究模拟网络重量变量的好处,以确定神经反应特性.
- 为神经表示和衍生统计提供不确定性估计,增强模型评估和特征解释.
主要方法:
- 采用变异推理来估计从训练数据中模型权重的后部分布.
- 开发了贝叶斯系统识别框架,以预测神经反应和量化不确定性.
- 利用由变量方法生成的有效无限集合来导出最令人兴奋的输入 (MEI).
主要成果:
- 与蒙特卡洛脱落和传统点估计模型相比,贝叶斯式方法实现了更高或可比的神经预测性能,并显著提高了数据效率.
- 该方法生成了一组模型,使刺激-响应函数不确定性的可靠估计成为可能,这与预测性能的负相关.
- 在Silico实验中表明,在数据有限的条件下,该模型产生的刺激驱动神经元活动比传统模型更有效.
结论:
- 贝叶斯式系统识别与变异推理为神经反应预测和系统表征提供了一种数据效率高的方法.
- 显式建模网络重量变化提供了关键的不确定性估计,有助于评估和解释神经模型及其推断性质.
- 该方法有助于识别具有意义的神经响应属性与可信的间隔,推进在数据有限的场景感官系统的理解.

相关概念视频
 01:10
Propagation of Uncertainty from Systematic Error
496
The atomic mass of an element varies due to the relative ratio of its isotopes. A sample's relative proportion of oxygen isotopes influences its average atomic mass. For instance, if we were to measure the atomic mass of oxygen from a sample, the mass would be a weighted average of the isotopic masses of oxygen in that sample. Since a single sample is not likely to perfectly reflect the true atomic mass of oxygen for all the molecules of oxygen on Earth, the mass we obtain from this...
496
 01:22
Multi-input and Multi-variable systems
105
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
In the absence...
105
 01:21
Transfer Function in Control Systems
430
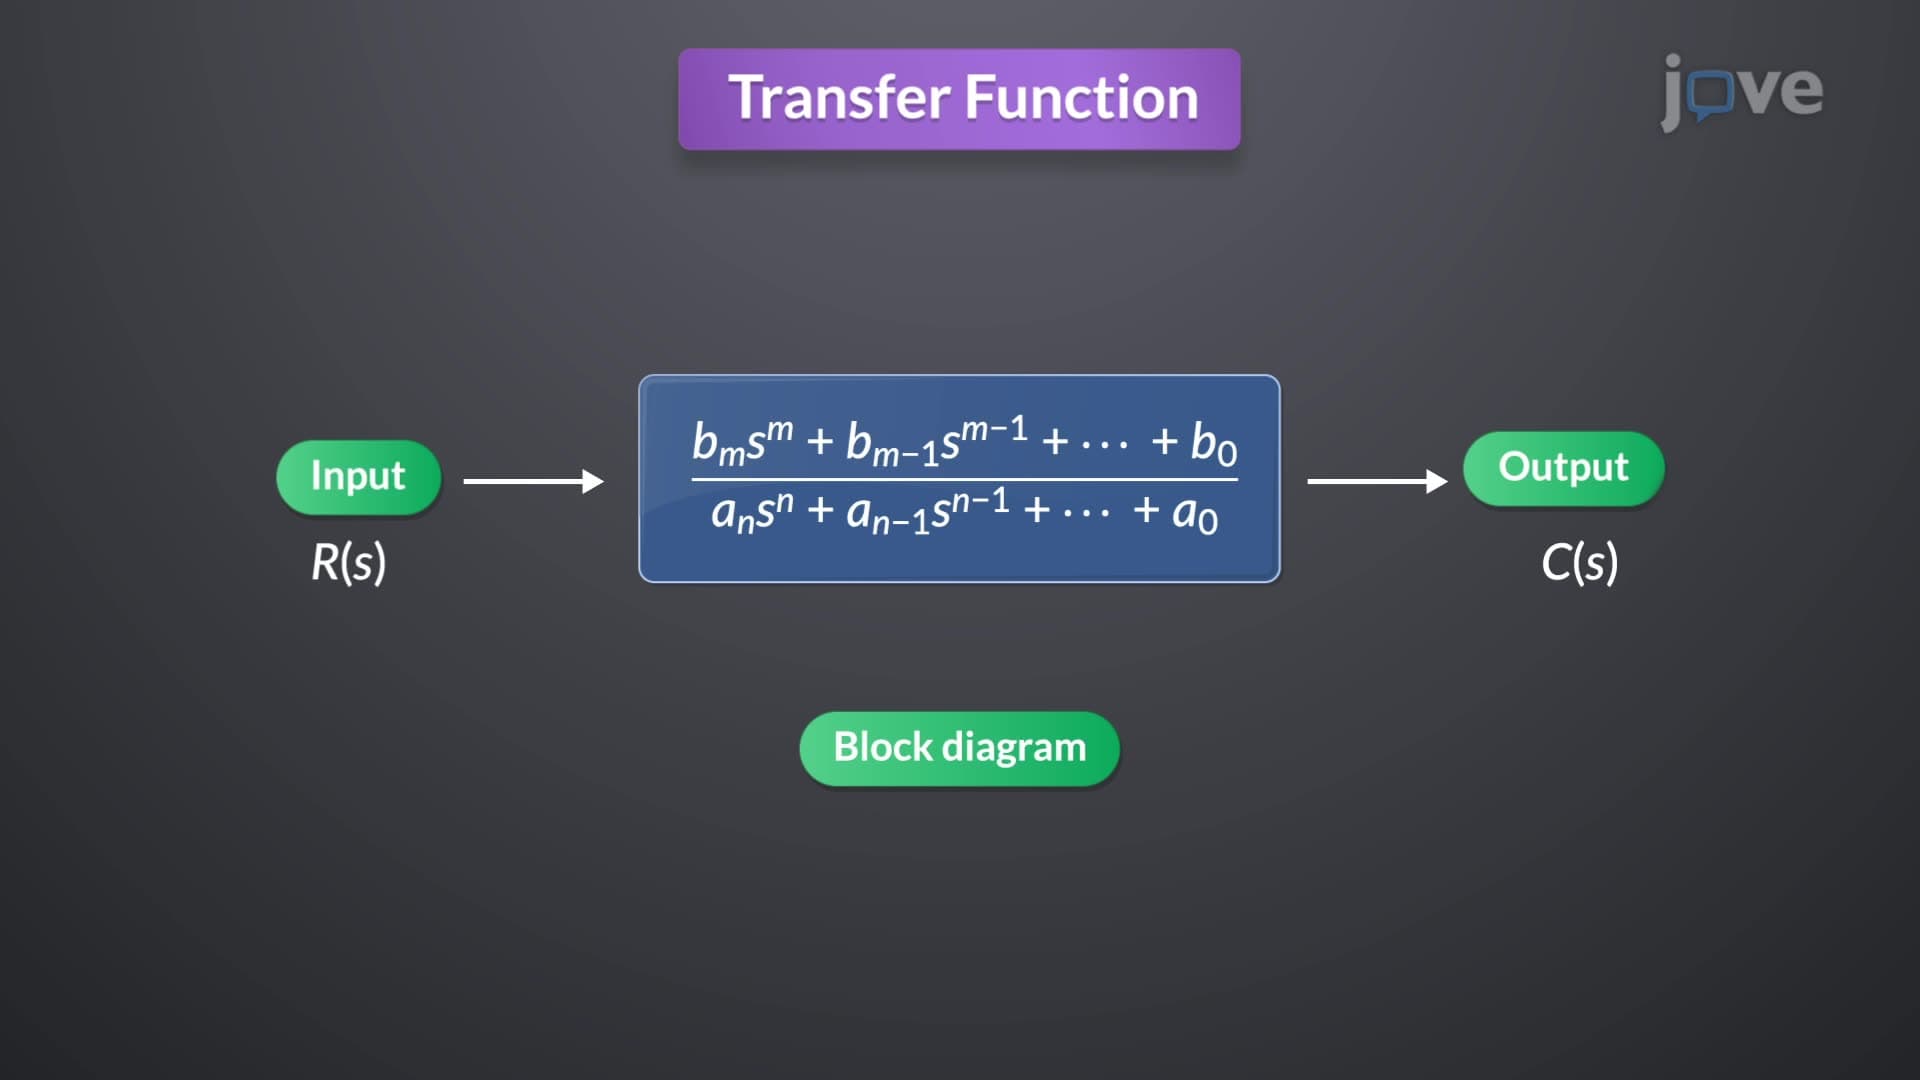
The transfer function is a fundamental concept in the analysis and design of linear time-invariant (LTI) systems. It offers a concise way to understand how a system responds to different inputs in the frequency domain. It serves as a bridge between the time-domain differential equations that describe system dynamics and the frequency-domain representation that facilitates easier manipulation and analysis.
To derive the transfer function, consider a general nth-order linear time-invariant...
To derive the transfer function, consider a general nth-order linear time-invariant...
430
 00:59
Propagation of Uncertainty from Random Error
661
An experiment often consists of more than a single step. In this case, measurements at each step give rise to uncertainty. Because the measurements occur in successive steps, the uncertainty in one step necessarily contributes to that in the subsequent step. As we perform statistical analysis on these types of experiments, we must learn to account for the propagation of uncertainty from one step to the next. The propagation of uncertainty depends on the type of arithmetic operation performed on...
661
 01:24
One-Compartment Open Model: Wagner-Nelson and Loo Riegelman Method for ka Estimation
448
This lesson introduces two critical methods in pharmacokinetics, the Wagner-Nelson and Loo-Riegelman methods, used for estimating the absorption rate constant (ka) for drugs administered via non-intravenous routes. The Wagner-Nelson method relates ka to the plasma concentration derived from the slope of a semilog percent unabsorbed time plot. However, it is limited to drugs with one-compartment kinetics and can be impacted by factors like gastrointestinal motility or enzymatic degradation.
On...
On...
448
 01:26
Linear Approximation in Frequency Domain
88
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
88