纵向动力学AAV5矢量集成配置文件和评价的克隆扩张在小鼠的纵向动力学
Ashrafali Mohamed Ismail1, Evan Witt1, Taren Bouwman1
1BioMarin Pharmaceutical Inc., Novato, CA 94949, USA.
Molecular therapy. Methods & clinical development
|August 6, 2024

概括
腺相关病毒 (AAV) 基因疗法载体主要保持为插曲,罕见,稳定整合. 这项研究在小鼠模型中没有发现来自AAV5矢量集成的瘤发生或纤维化的证据.
科学领域:
- 分子生物学分子生物学
- 基因治疗 基因治疗
- 病毒学 病毒学
背景情况:
- 基因转移中广泛使用的基因相关病毒 (AAV) 基因载体,主要以异染色体发作形式持续存在.
- 一小部分AAV载体基因组可以整合到宿主基因组中,这引发了对依赖载体调节元素的瘤发生的理论担忧.
研究的目的:
- 为了研究腺相关病毒血清型5 (AAV5) 载体的整合概况.
- 评估使用Sf和HEK293细胞生成的AAV载体的安全性和整合特性,模仿血友病A基因治疗的valoctocogene roxaparvovec.
主要方法:
- 用小鼠模型分析了AAV5矢量的集成概况.
- 综合频率,时间,分布和与基因表达和宿主细胞增殖的关联被使用深度测序来评估.
主要成果:
- 大多数载体基因组 (95%) 是环节性,在Sf和HEK293产生的载体中观察到的集成频率低 (1.792.70集成/1,000个细胞).
- 整合发生迅速 (在1周内),保持稳定,多克隆,随机分布,并显示在高度表达的肝脏基因转录起点附近的丰富.
- 没有检测到载体生产平台的差异,克隆扩张,瘤发生或纤维化.
结论:
- AAV5 矢量集成发生在低频率,随着时间的推移是稳定的,并且似乎与瘤发生或纤维化等不良事件无关.
- 这些发现通过表征载体基因组整合模式,支持基于AAV5的基因疗法的安全性,包括valoctocogene roxaparvovec.
相关概念视频
 00:57
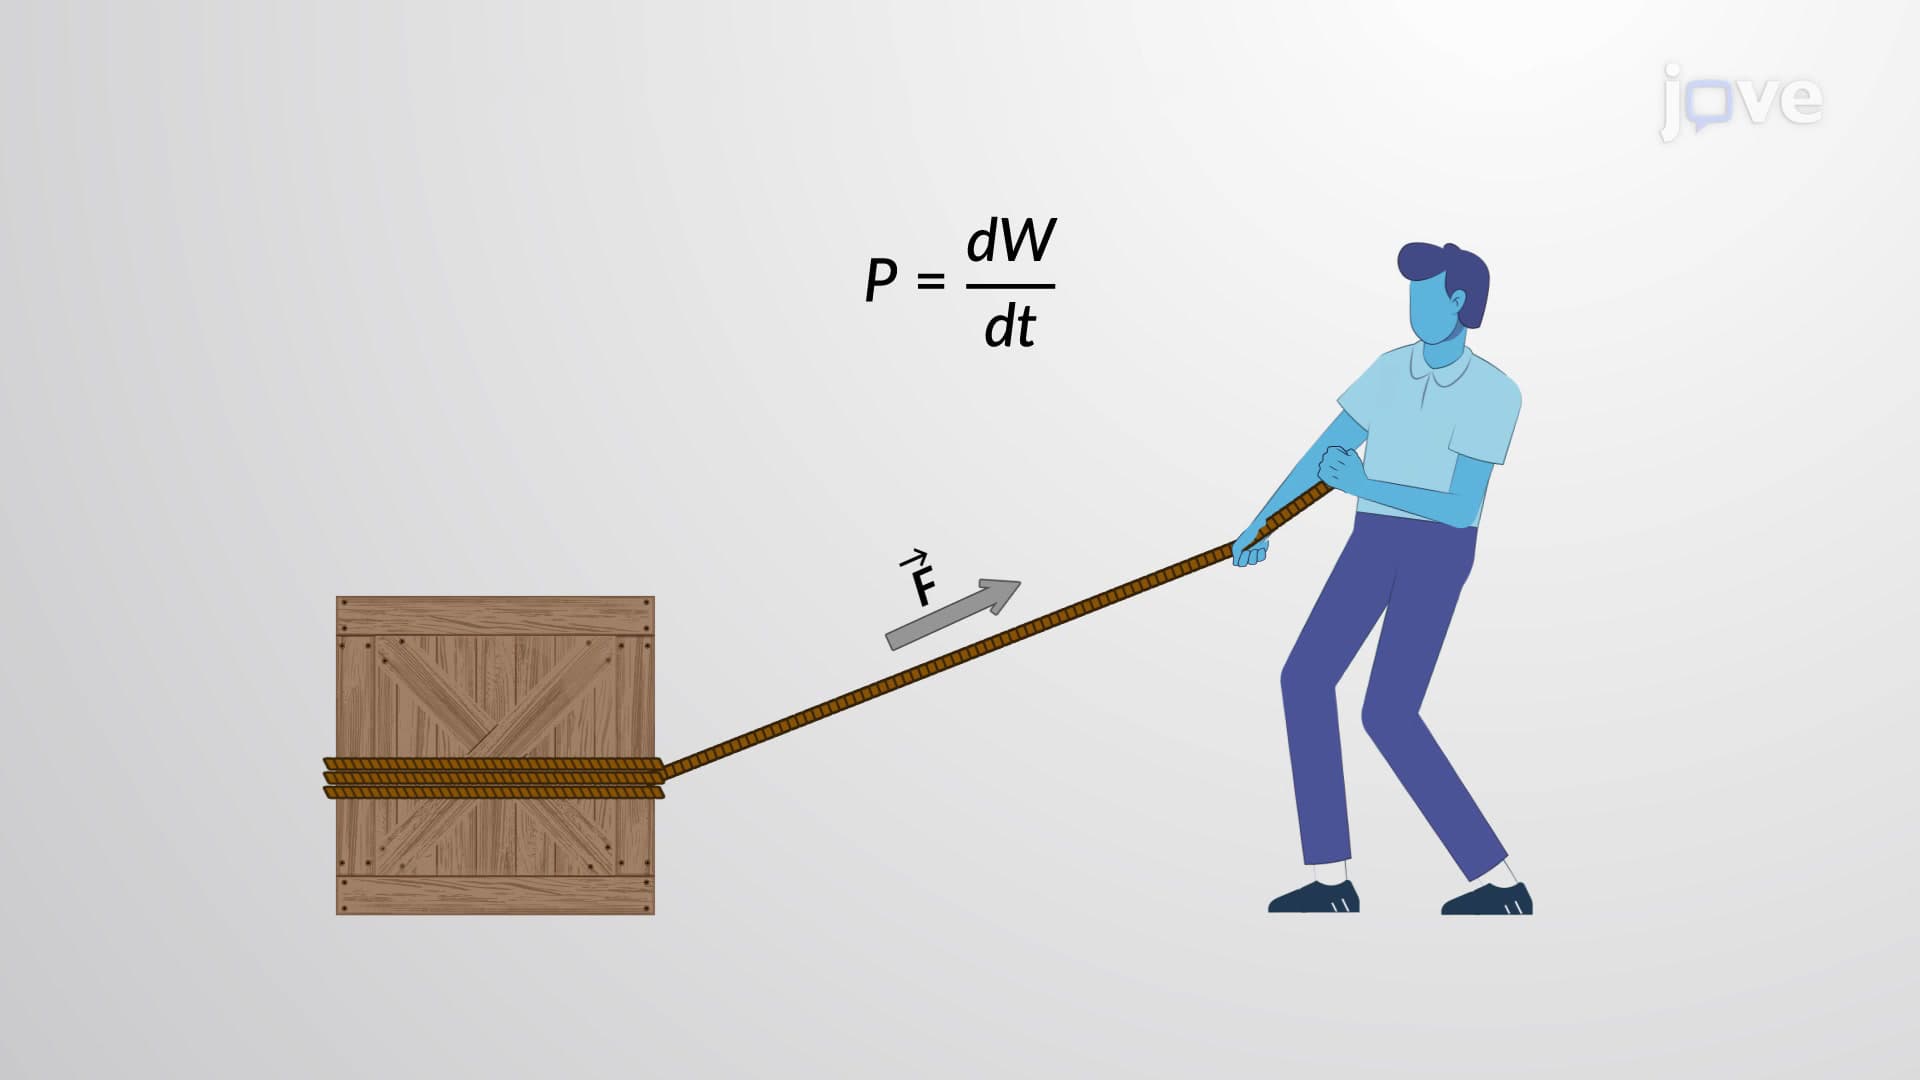
Power Expended by a Constant Force
The relationship between work done and the time taken to do it can be explained using the concept of power. For example, several sprinters in a race may have the same velocity when they reach the finish line, therefore doing the same amount of work, but the winner does it in the least amount of time. Thus, power is defined as the rate of doing work. Since work can vary as a function of time, the average power is defined as the work done during a time interval, divided by the time interval.
 01:23
Vector Addition of Forces
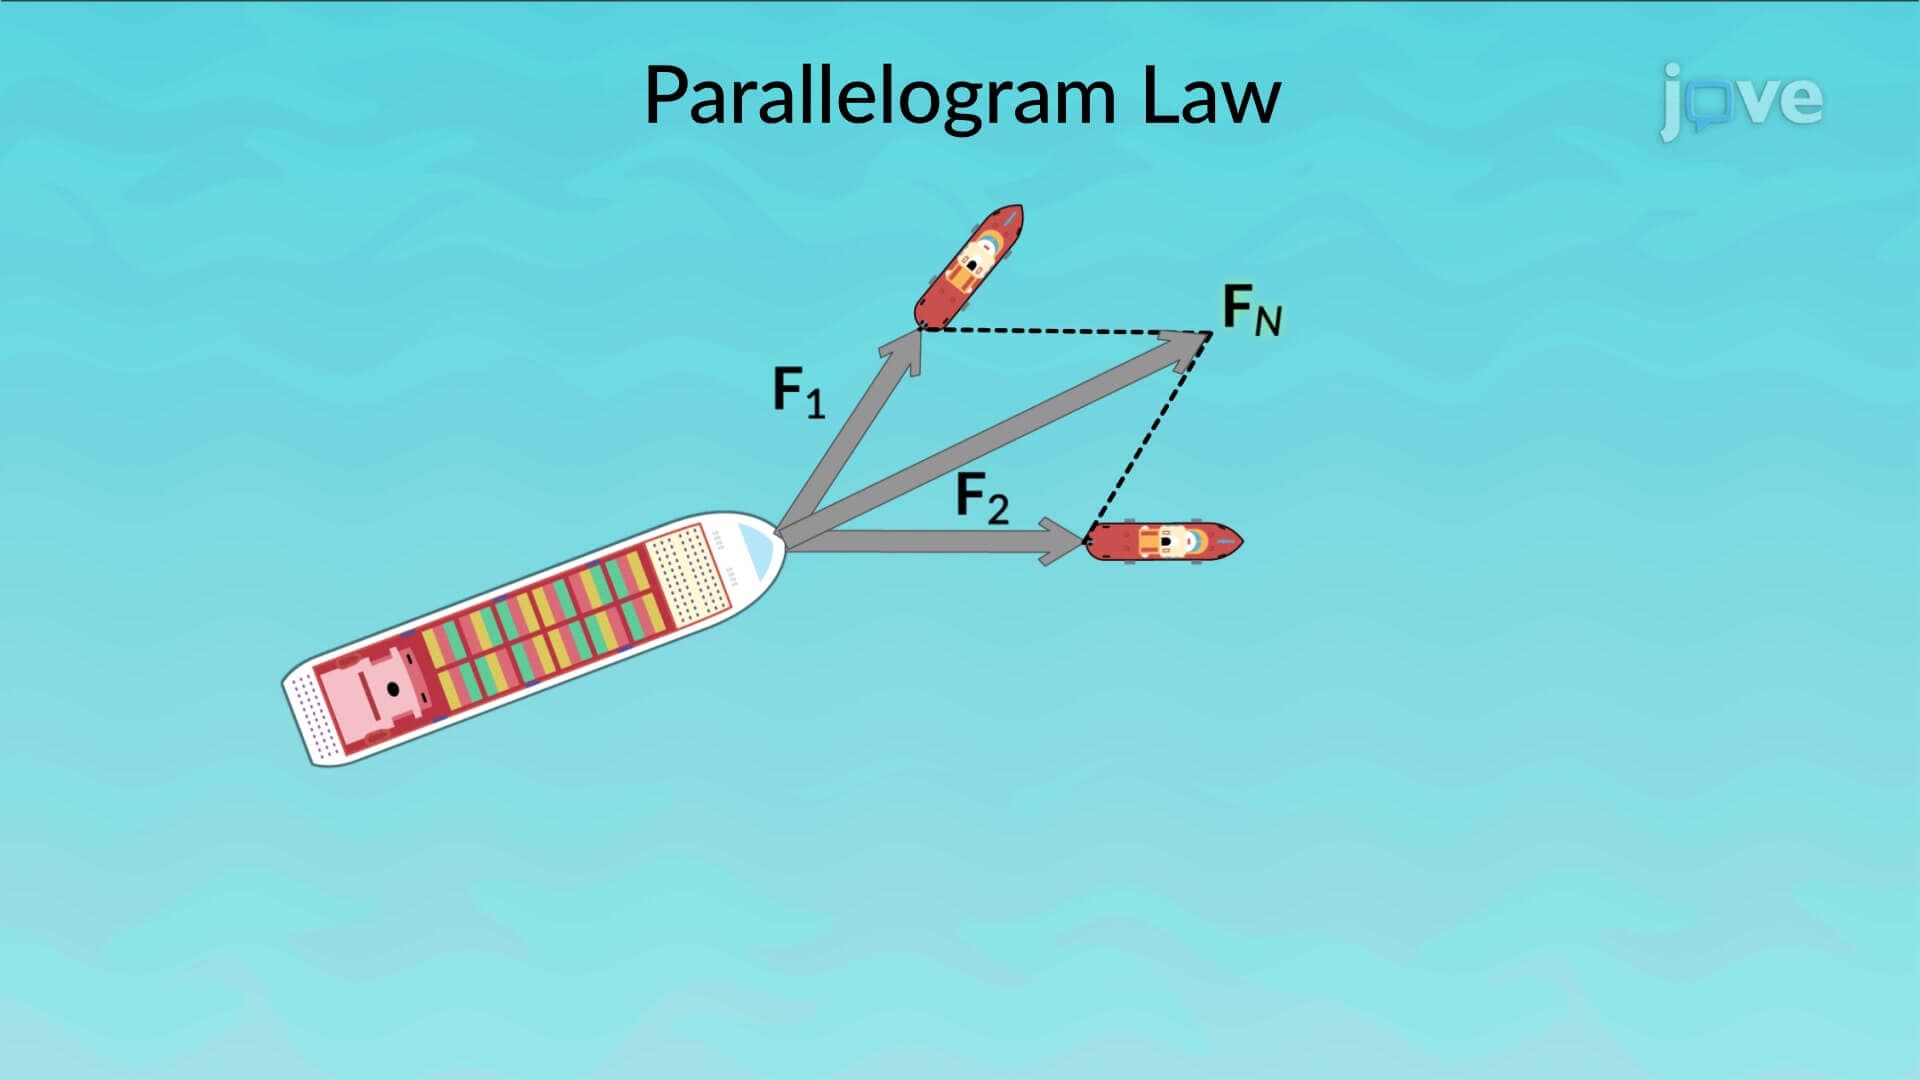
When understanding the effects of multiple forces acting on an object, vector addition is a crucial concept to grasp. This mathematical concept can be used to calculate the net force acting on an object when two or more forces are involved.
To understand the concept of vector addition, consider the scenario of a ship being pulled by two small tugboats. The two forces, F1 and F2, act concurrently on the ship in different directions. The parallelogram law can be used to calculate the net force...
To understand the concept of vector addition, consider the scenario of a ship being pulled by two small tugboats. The two forces, F1 and F2, act concurrently on the ship in different directions. The parallelogram law can be used to calculate the net force...
 01:20
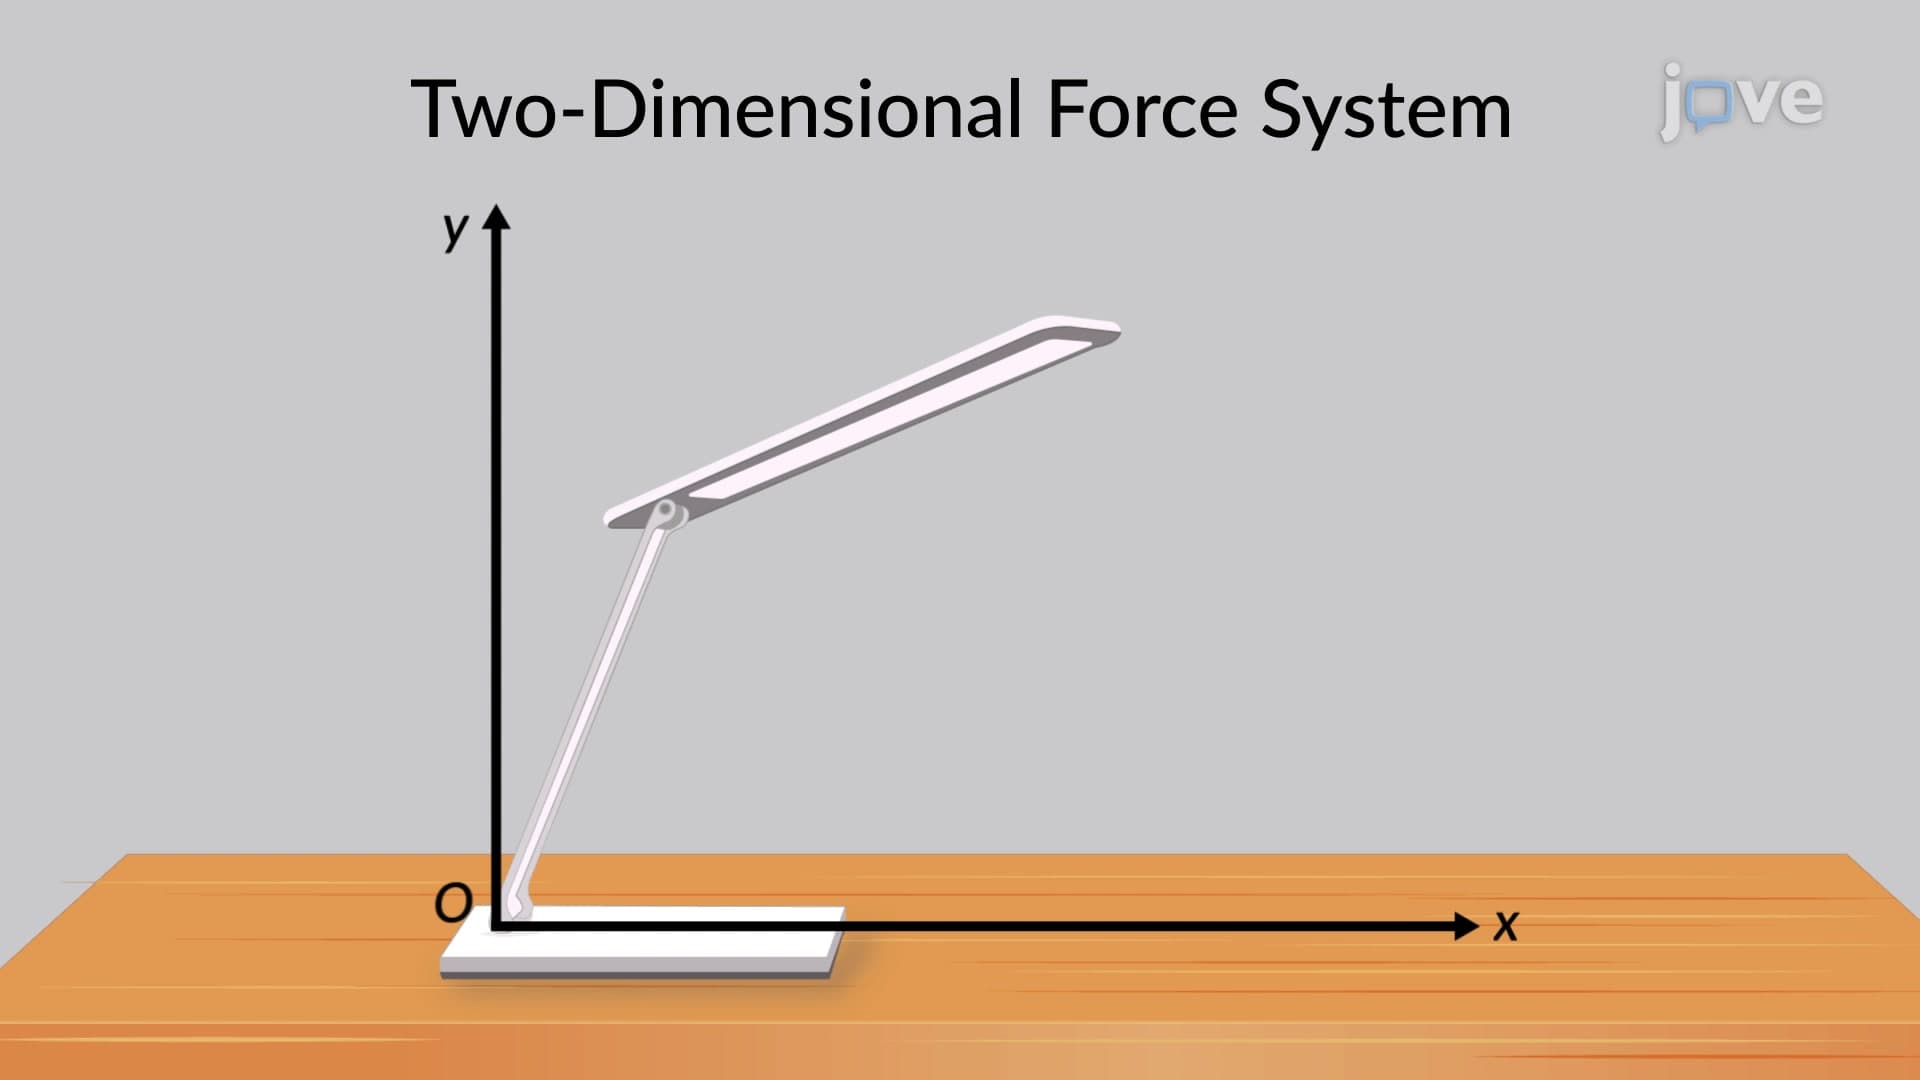
Two-Dimensional Force System
A two-dimensional system in mechanical engineering involves the analysis of motion and forces in a plane. A two-dimensional force vector can be resolved into its components as:
 01:30
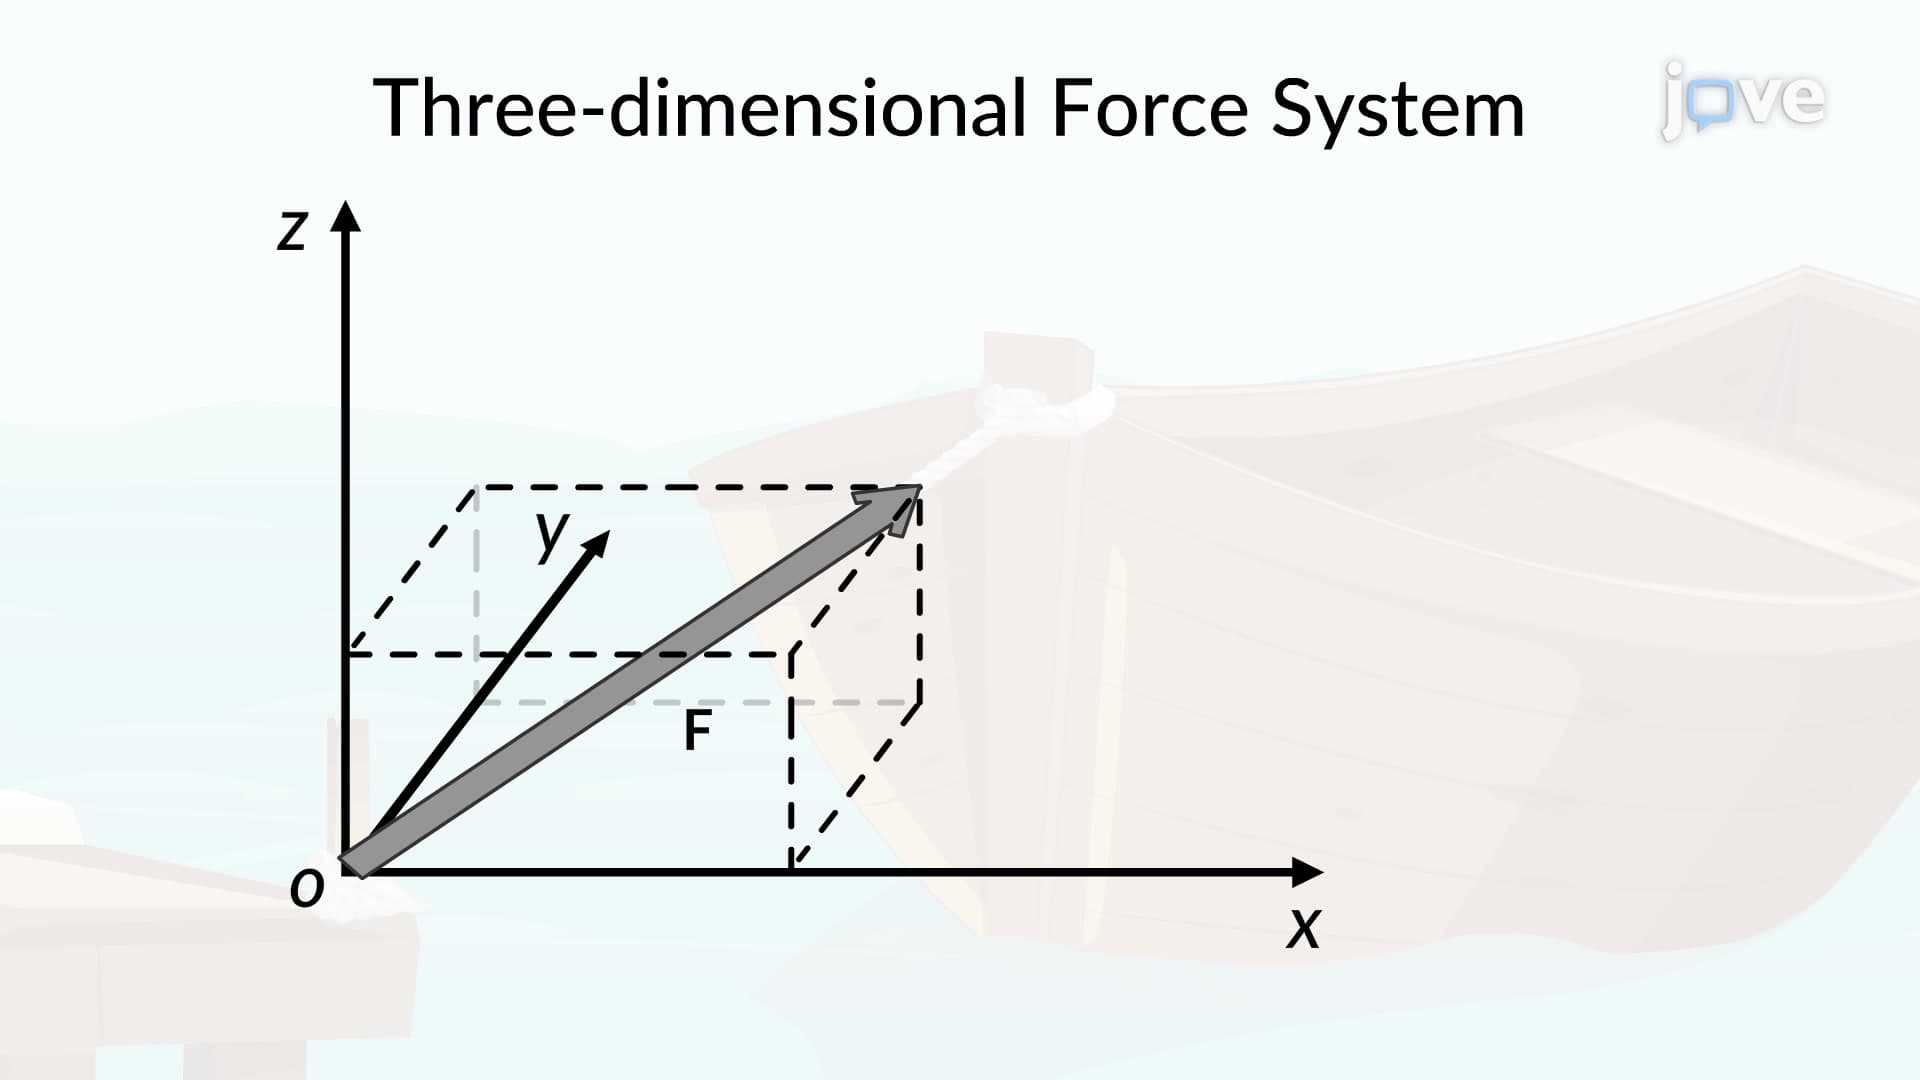
Three-Dimensional Force System
In mechanical engineering, a three-dimensional force system is a system of forces acting in three dimensions, with forces applied along the x, y, and z coordinate axes. The three-dimensional force system is an important concept in mechanical engineering, as it allows engineers to understand and analyze the behavior of objects and structures in three dimensions. By understanding the forces acting on a system, engineers can design more efficient and effective mechanical systems that can withstand...
 01:30
Three-Dimensional Force System:Problem Solving
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Vector Functions and Motion: Problem Solving
Accurate position tracking is fundamental to the safe and effective operation of unmanned aerial vehicles (UAVs), particularly during precision maneuvers near complex structures. In this scenario, a drone is programmed to perform a high-precision inspection of a vertical structure, starting at position ((x, y, z) = (3, 0, 0)), with an initial velocity oriented in the positive z-direction. The trajectory of the drone is governed by a time-dependent acceleration function a(t), which is predefined...