相关实验视频
Updated: Jun 17, 2025

10:09

Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
6.6K
混合定向和定位协作运动生成方案,用于通过循环神经网络合成的多个移动冗余操纵系统
IEEE transactions on cybernetics
|August 6, 2024

概括
本研究介绍了多个移动操纵系统的新型运动生成方案,增强了协作任务的稳定性和安全性. 这种方法将方向和位置协调与实际应用的物理限制相结合.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 人工智能的人工智能
- 控制系统 控制系统
背景情况:
- 分布式多个移动操纵系统需要强大的协调,以实现安全和稳定的协作任务.
- 现有的方案往往忽视了导向协调和物理限制,影响了现实世界的适用性.
研究的目的:
- 为分布式多个移动操纵器系统开发运动生成方案,确保位置和方向协调.
- 将物理限制纳入运动生成过程中,以提高系统的实用性.
- 提高多个移动操纵器执行的协作任务的稳定性和安全性.
主要方法:
- 一个分布式循环神经网络被用来建模方向和位置协调约束.
- 使用二次编程来建立运动生成方案,并结合了合变量.
- 基于分布式线性变异不平等的原始双元神经网络被构建来解决方案并生成运动轨迹.
主要成果:
- 拟议的混合定向和位置协作运动生成方案有效解决了协调问题.
- 与其他方法相比,分布式计算结构显著提高了系统稳定性.
- 整合方向协调和物理边界增加了系统的整体实用性.
结论:
- 开发的运动生成方案为分布式多个移动操纵系统提供了稳定和安全的解决方案.
- 导向协调和物理边界的整合代表了实际机器人应用的重大进步.
- 分布式神经网络方法为复杂的机器人协调任务提供了有效的计算方法.


相关概念视频
 01:27
Support Reactions in Three Dimensions
948
Support reactions in three dimensions help maintain the stability and equilibrium of various structures and systems. These reactions prevent the system from translating and rotating, ensuring the design can withstand external forces and perform its intended function efficiently and safely. Some of the supports providing support reactions in three dimensions are discussed below:
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
948
 01:24
One-Degree-of-Freedom System
476
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
476
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
394
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
394
 01:25
Relative Motion Analysis using Rotating Axes
452
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
452
 01:23
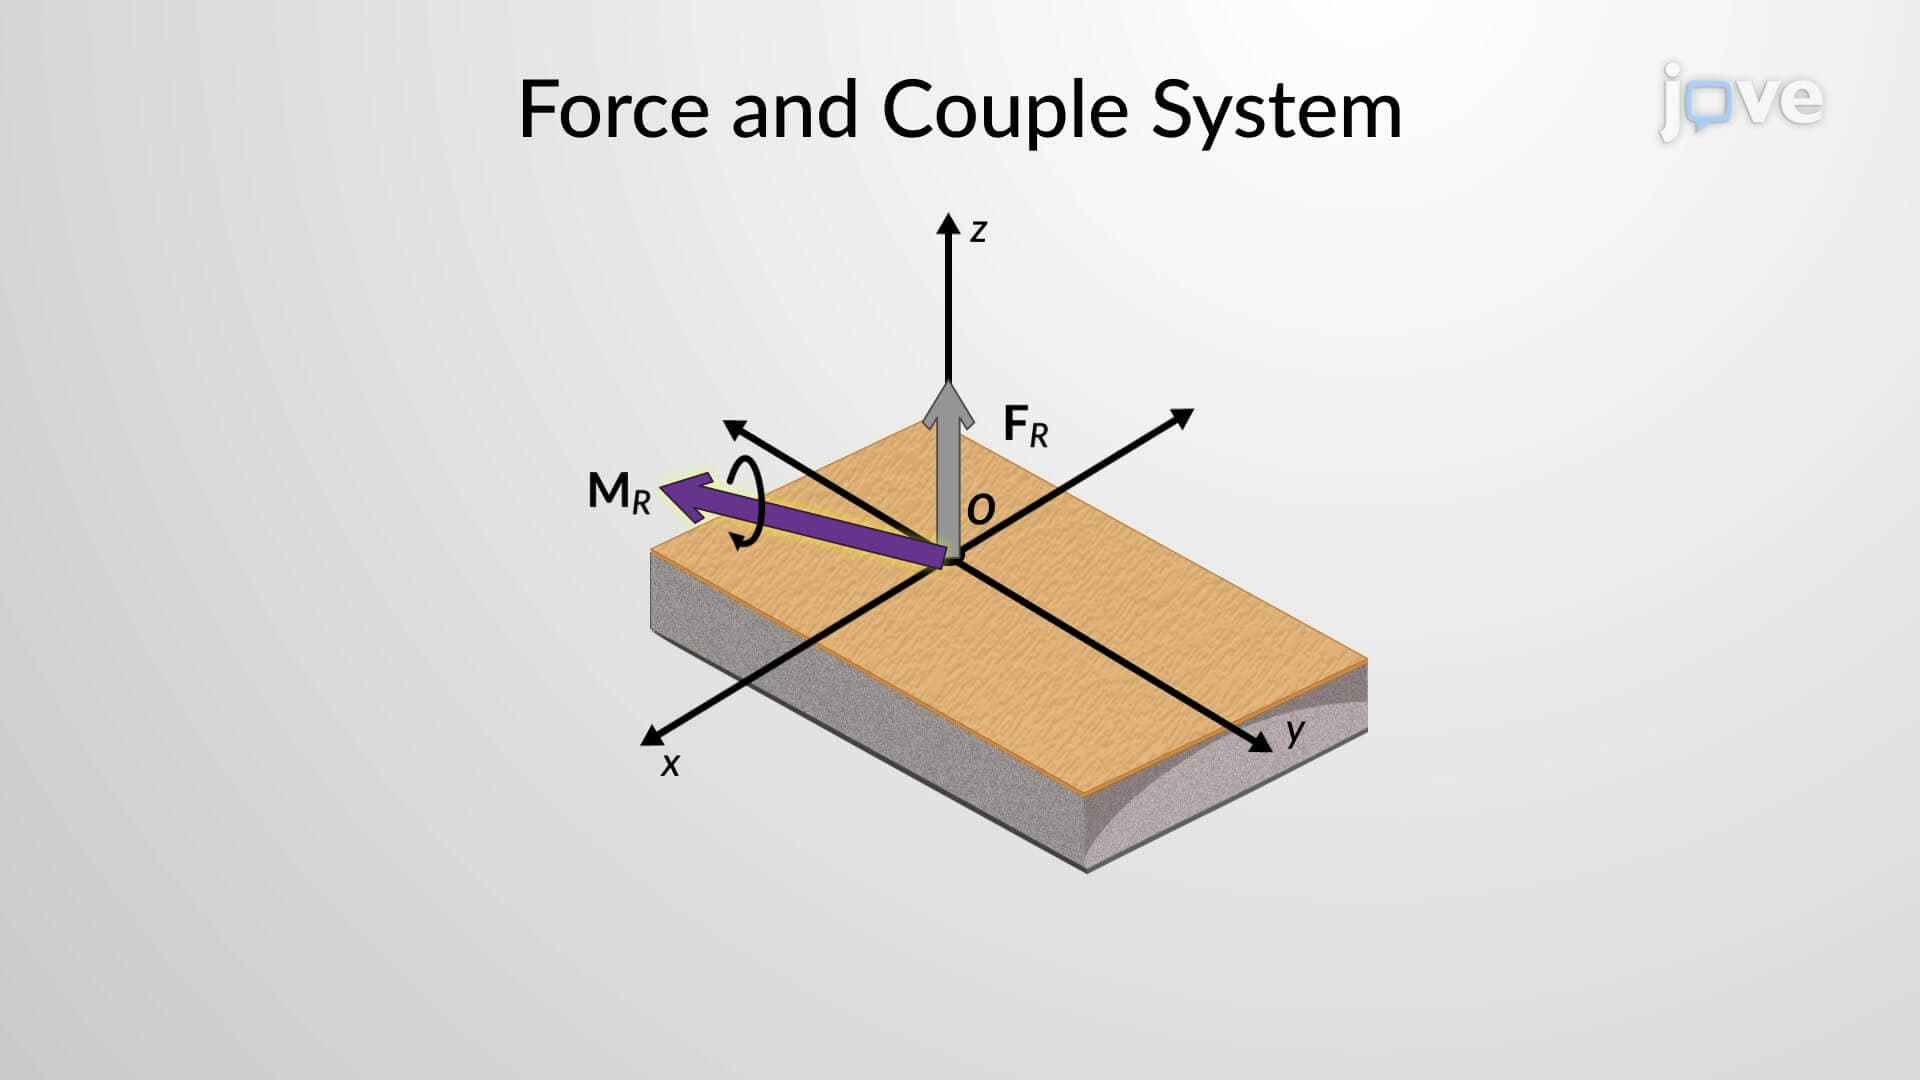
Simplification of a Force and Couple System: II
277
In a three-dimensional system, multiple forces can act on an object. These forces can be combined into a single equivalent force, known as the resultant force. Similarly, the moments generated by these forces can be combined into a single equivalent moment, the resultant couple moment. In certain situations, these two entities may not be mutually perpendicular, meaning they do not have a 90-degree angle between them. This unique condition requires a deeper understanding of the interplay between...
277
 01:06
Virtual Work for a System of Connected Rigid Bodies
375
Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
Next,...
375