

停车场交通预测基于多面空间-时间特征的融合
Lechuan Zhang1, Bin Wang1, Qian Zhang1
1College of Information, Mechanical and Electrical Engineering, Shanghai Normal University, Shanghai 201400, China.
Sensors (Basel, Switzerland)
|August 10, 2024

概括
准确的停车场交通预测对于管理城市拥堵至关重要. 本研究引入了一种新型模型,该模型有效地将复杂的空间和时间数据与外部因素集成在一起,以改进流量预测.
科学领域:
- 城市规划和智能交通系统.
- 数据科学和机器学习应用.
- 时间空间数据分析.
背景情况:
- 快速的城市化和车辆数量的增加加剧了交通拥堵.
- 有效的停车指导和信息系统 (PGI) 对城市流动至关重要.
- 准确的停车交通预测对于提高效率和减少拥堵至关重要.
研究的目的:
- 解决模拟复杂的时空停车数据和外部影响的挑战.
- 提出一种用于预测停车场交通流量的新型模型.
- 提高停车交通预测的准确性和有效性.
主要方法:
- 开发了一个多面的时空特征融合图形卷积网络 (MFF-STGCN) 模型.
- 集成的外部功能,如假日,景点 (POI) 和天气使用功能嵌入模块.
- 采用时空注意力机制和图形卷积与封闭的递归单元用于特征提取.
主要成果:
- 多年框架-STGCN模型有效地捕捉了复杂的空间关系和时间依赖.
- 该模型准确地纳入了影响停车交通的外部因素.
- 在真实世界数据集上的实验结果证实了增强的预测性能.
结论:
- 拟议的MFF-STGCN模型为停车场交通预测提供了一个强大的解决方案.
- 准确的交通流量预测可以显著缓解城市交通拥堵.
- 这种方法为智能运输系统的开发提供了宝贵的工具.


相关概念视频
 01:17
Probability Histograms
11.1K
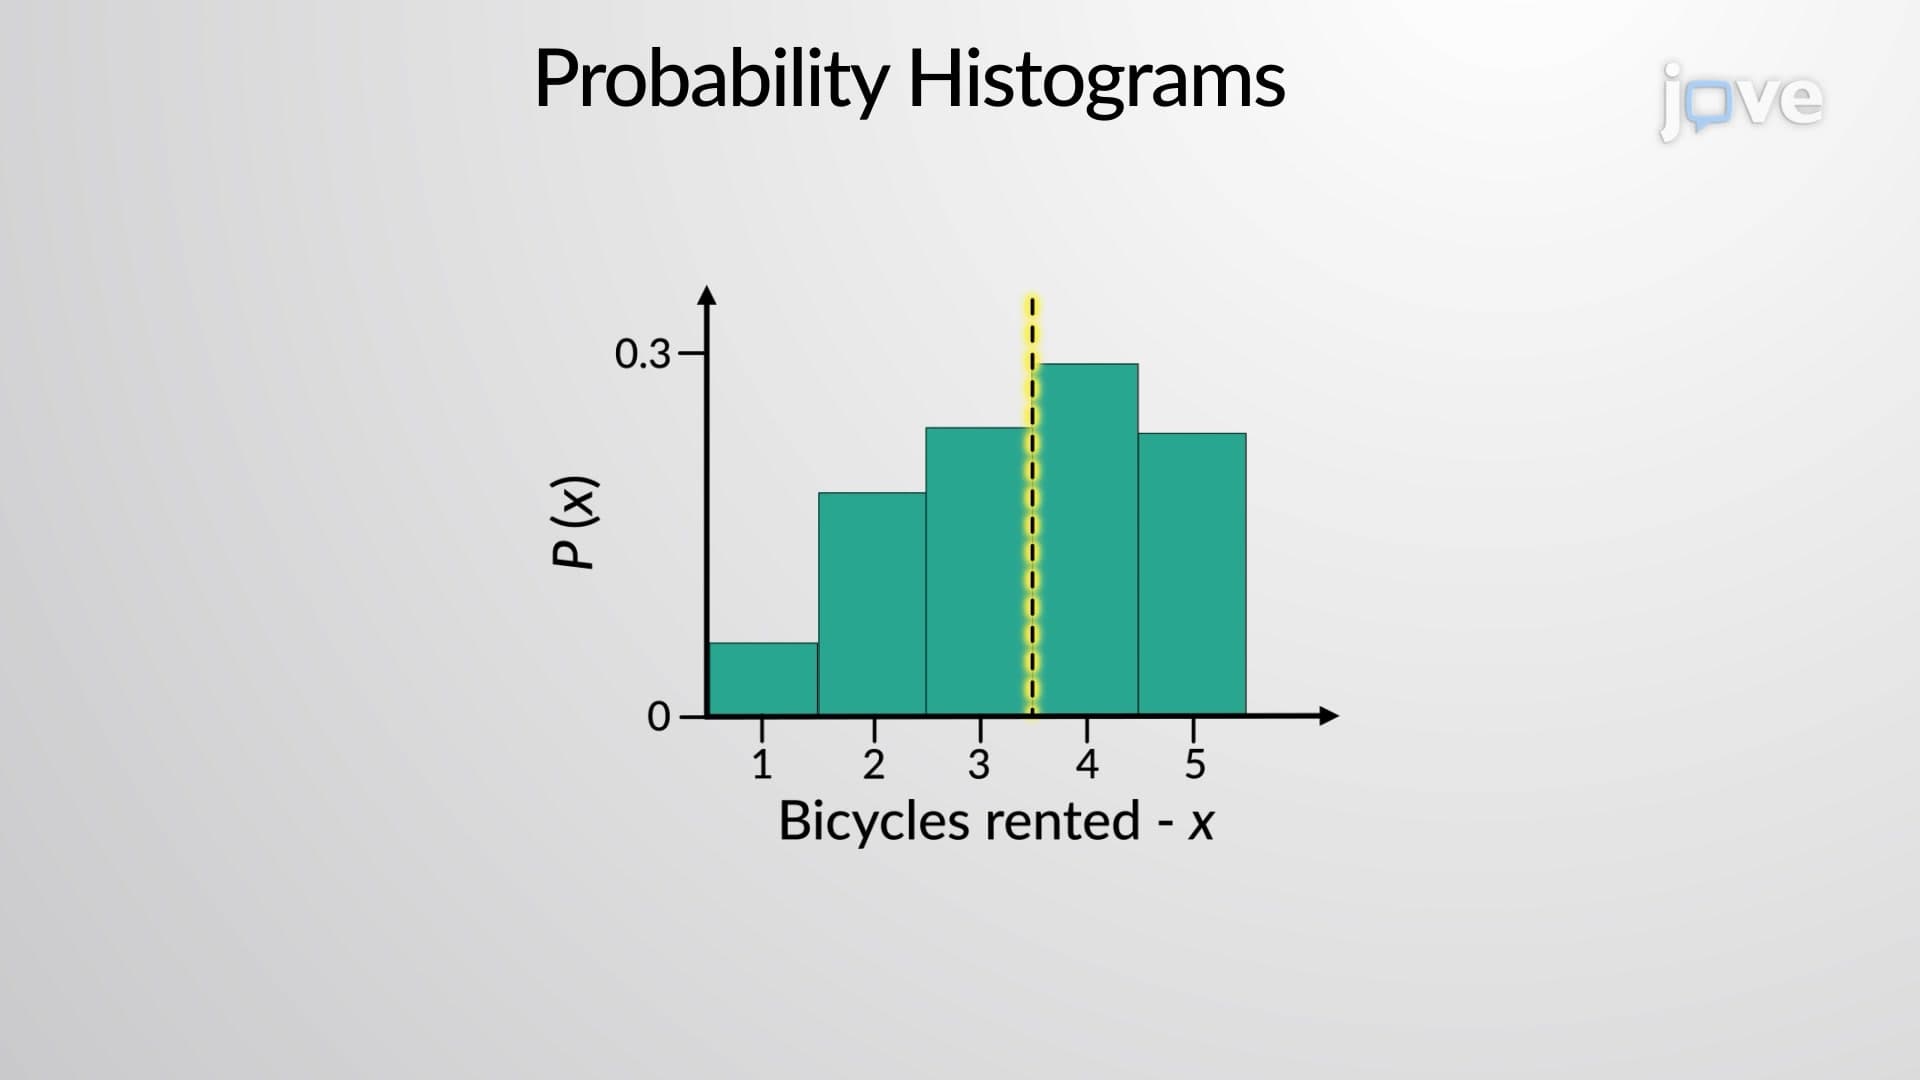
A probability histogram is a visual representation of a probability distribution. Similar a typical histogram, the probability histogram consists of contiguous (adjoining) boxes. It has both a horizontal axis and a vertical axis. The horizontal axis is labeled with what the data represents. The vertical axis is labeled with probability. Each rectangular bar in the histogram is 1 unit wide, which suggests that the area under each bar equals the probability, P(x), where x is 1, 2, 3, and so on.
11.1K
 01:21
Manipulation and Analysis
23
GIS manipulation and analysis functions are vital for decision-making and planning. These activities range from data retrieval tasks, such as selecting information based on specific criteria, to advanced analytical techniques that address complex spatial problems.One critical GIS analysis method is overlaying, which combines multiple data layers to examine impacts. For example, overlaying a river-dammed lake boundary with road networks can identify affected infrastructure. Another common...
23
 01:07
End Point Prediction: Gran Plot
305
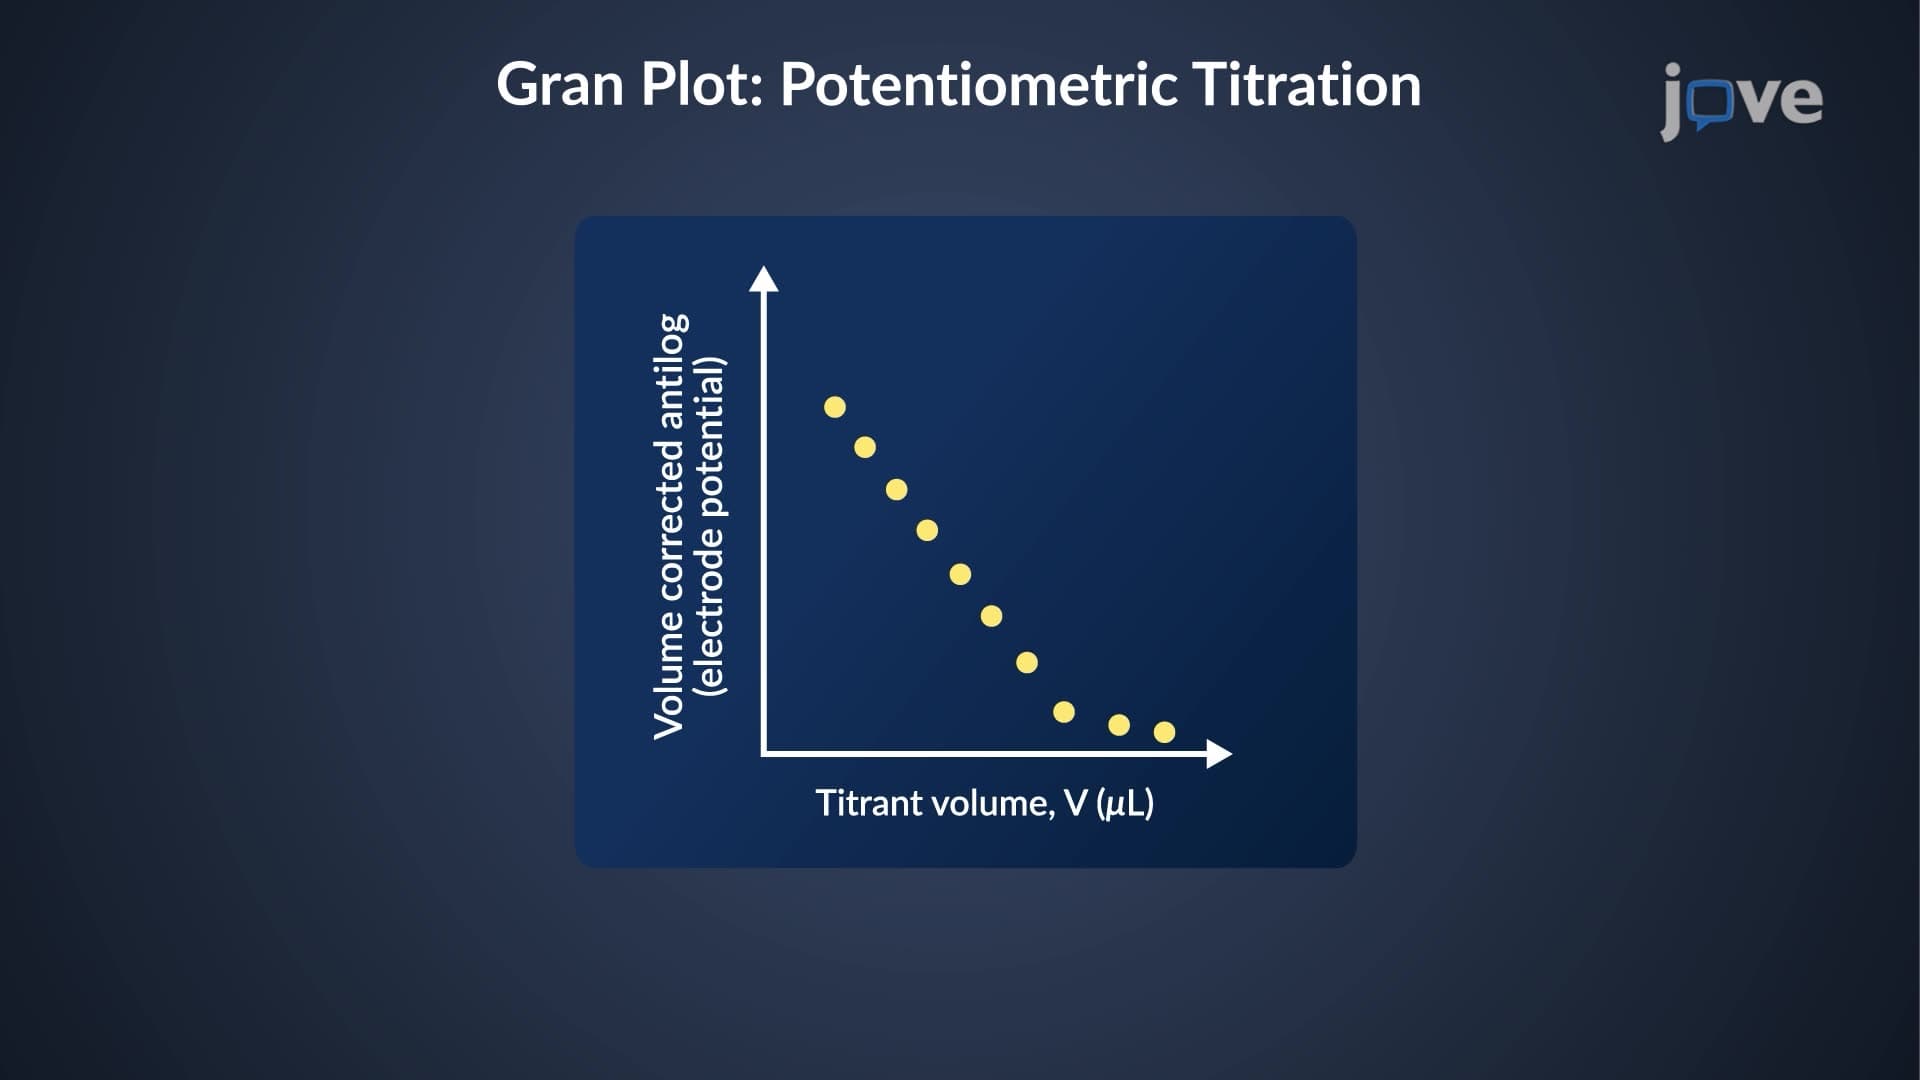
A Gran plot is used to predict the equivalence volume or endpoint of a potentiometric or acid-base titration without reaching the endpoint. Typically, titration data is collected as a function of the titrant's volume up to a point less than the equivalence volume and then transformed into a linear format. The straight line is extended to the x-axis, indicating the necessary titrant volume to achieve the equivalence point.
For potentiometric titration, the Gran plot is created by plotting...
For potentiometric titration, the Gran plot is created by plotting...
305
 01:11
Residuals and Least-Squares Property
7.3K
The vertical distance between the actual value of y and the estimated value of y. In other words, it measures the vertical distance between the actual data point and the predicted point on the line
If the observed data point lies above the line, the residual is positive, and the line underestimates the actual data value for y. If the observed data point lies below the line, the residual is negative, and the line overestimates the actual data value for y.
The process of fitting the best-fit...
If the observed data point lies above the line, the residual is positive, and the line underestimates the actual data value for y. If the observed data point lies below the line, the residual is negative, and the line overestimates the actual data value for y.
The process of fitting the best-fit...
7.3K
 01:03
Prediction Intervals
2.2K
The interval estimate of any variable is known as the prediction interval. It helps decide if a point estimate is dependable.
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.
2.2K
 01:25
Selected Data About Geographic Locations
27
Geographic Information Systems (GIS) rely on two core types of data: spatial data and attribute data.Spatial DataSpatial data defines the physical location of features within a coordinate system, typically expressed in terms of latitude and longitude. It provides precise positioning for elements like roads, rivers, or buildings.Attribute DataAttribute data complements spatial data by adding descriptive information about these features. For example, a road's spatial data includes its start and...
27