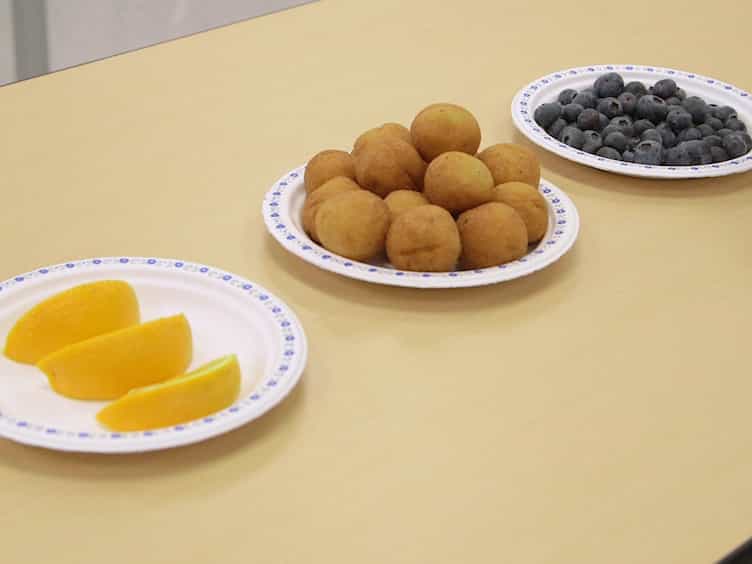

数字关闭速度和手运输加速之间的时间独立关系,在达到-抓取运动期间
Enzo Mastinu1, Anna Coletti1, Carlo Preziuso1
1Artificial Hands Area, BioRobotics Institute, Scuola Superiore Sant'Anna, Pisa, Italy.
Journal of biomechanics
|August 15, 2024

概括
研究人员探索了灵长类动物的伸手抓住行动,发现手部运输和抓住调整之间存在一致的联系. 这一发现表明,数字的移动可以从手的加速中预测,独立于时间或物体属性.
科学领域:
- 神经科学是一个神经科学.
- 生物力学 生物力学
- 灵长类动力控制器
背景情况:
- 灵长类动物的掌握运动涉及手臂的运输和握握的调整.
- 之前的研究分析了这些组成部分随着时间的推移而分开分析.
- 这些组件之间的潜在的时间独立关系仍然未被探索.
研究的目的:
- 调查手动运输和抓调整在伸展到抓动作期间之间是否存在时间独立,一对一的关系.
- 为了制定这种潜在的关系.
- 评估这种关系与对象属性的弹性.
主要方法:
- 对灵长类动物的伸手抓住动作的分析.
- 检查动力学数据用于手运输和数字调整.
- 线下和实时数据处理以确定关系.
主要成果:
- 证据表明,手部运输和握柄调整之间存在一个独立于时间的,一对一的关系.
- 这种关系在各种物体大小,形状和位置上似乎是稳定的.
- 数字动力学可能是从手的加速在达到时可预测的.
结论:
- 在灵长类捕捉中,手部运输和握柄调节之间存在着一个基本的,时间独立的合.
- 这种合对物体特征不变,简化了电机控制模型.
- 了解这种关系可以从手动数据中预测数字动力学.

相关概念视频
 01:10
Relative Motion Analysis - Acceleration
343
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
343
 01:11
Angular Velocity and Acceleration
9.2K
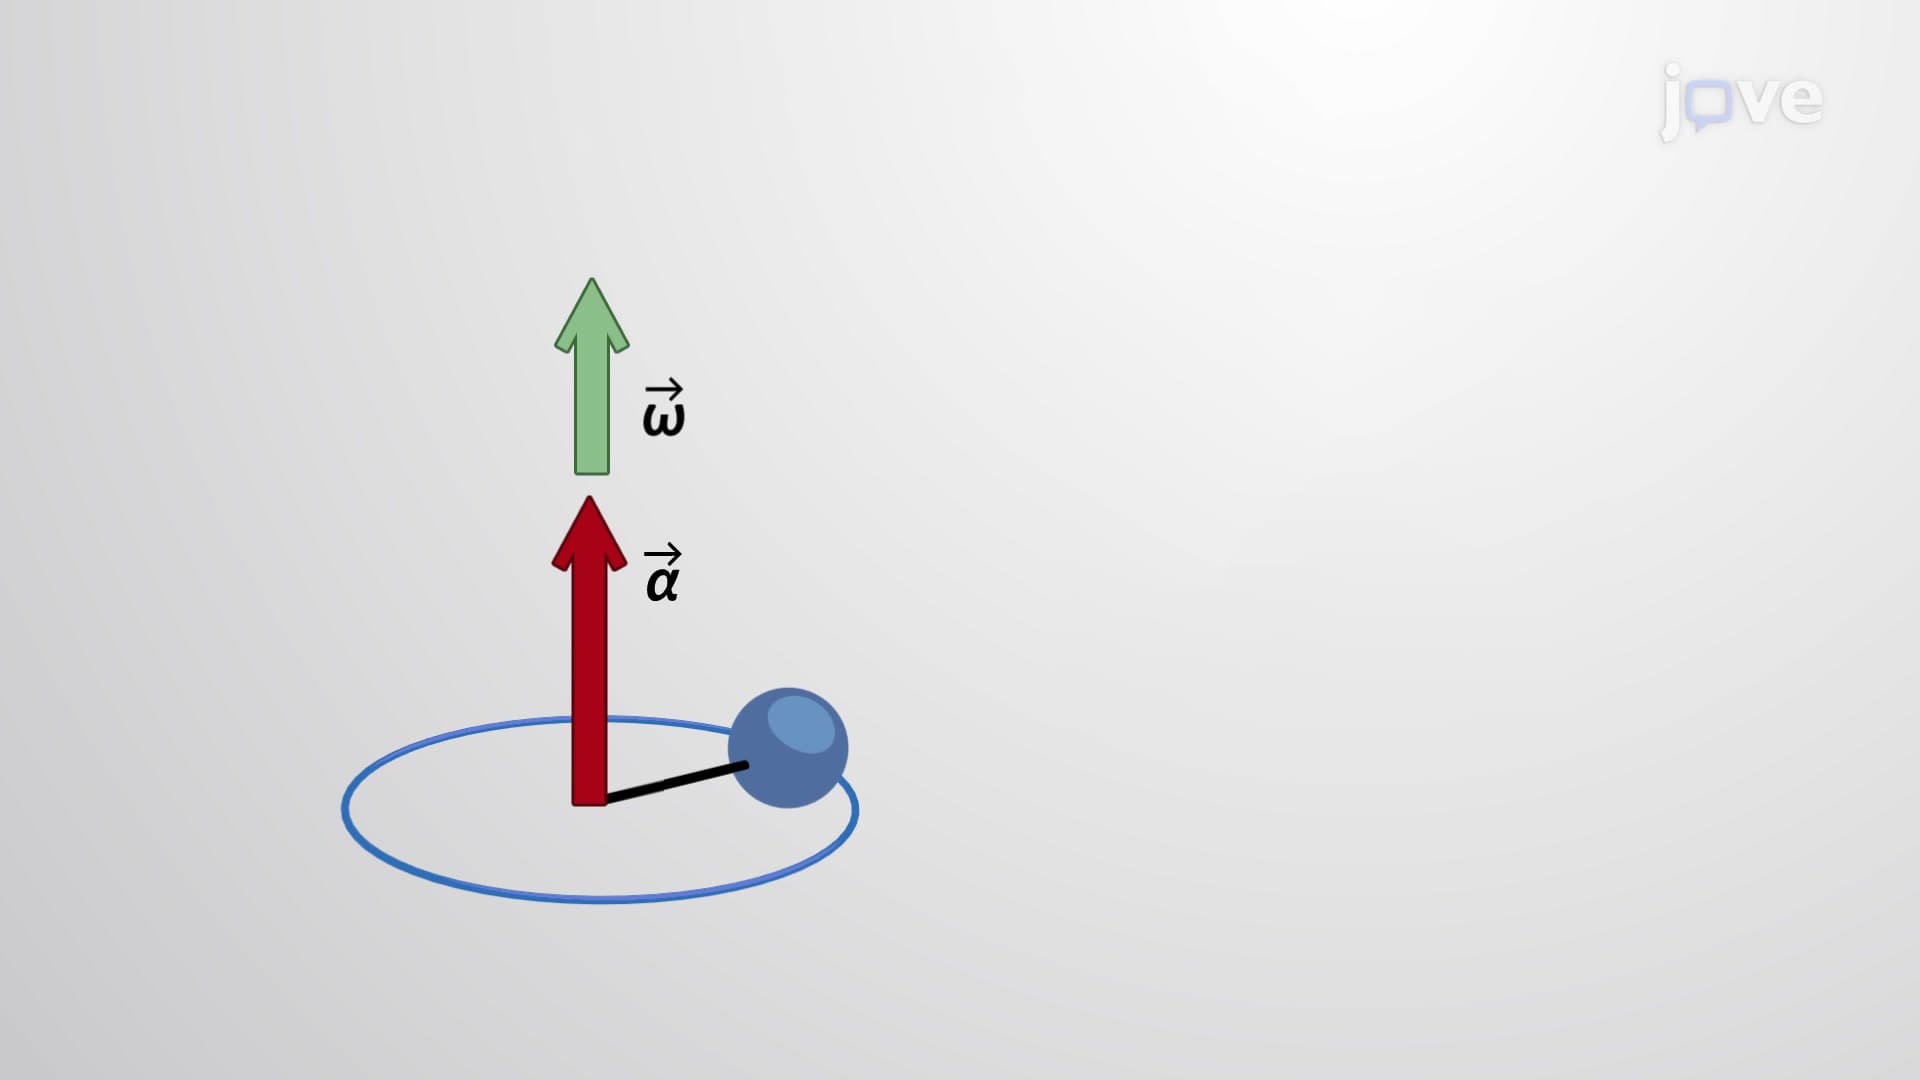
We previously discussed angular velocity for uniform circular motion, however not all motion is uniform. Envision an ice skater spinning with their arms outstretched; when they pull their arms inward, their angular velocity increases. Additionally, think about a computer's hard disk slowing to a halt as the angular velocity decreases. The faster the change in angular velocity, the greater the angular acceleration. The instantaneous angular acceleration is defined as the derivative of...
9.2K
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
394
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
394
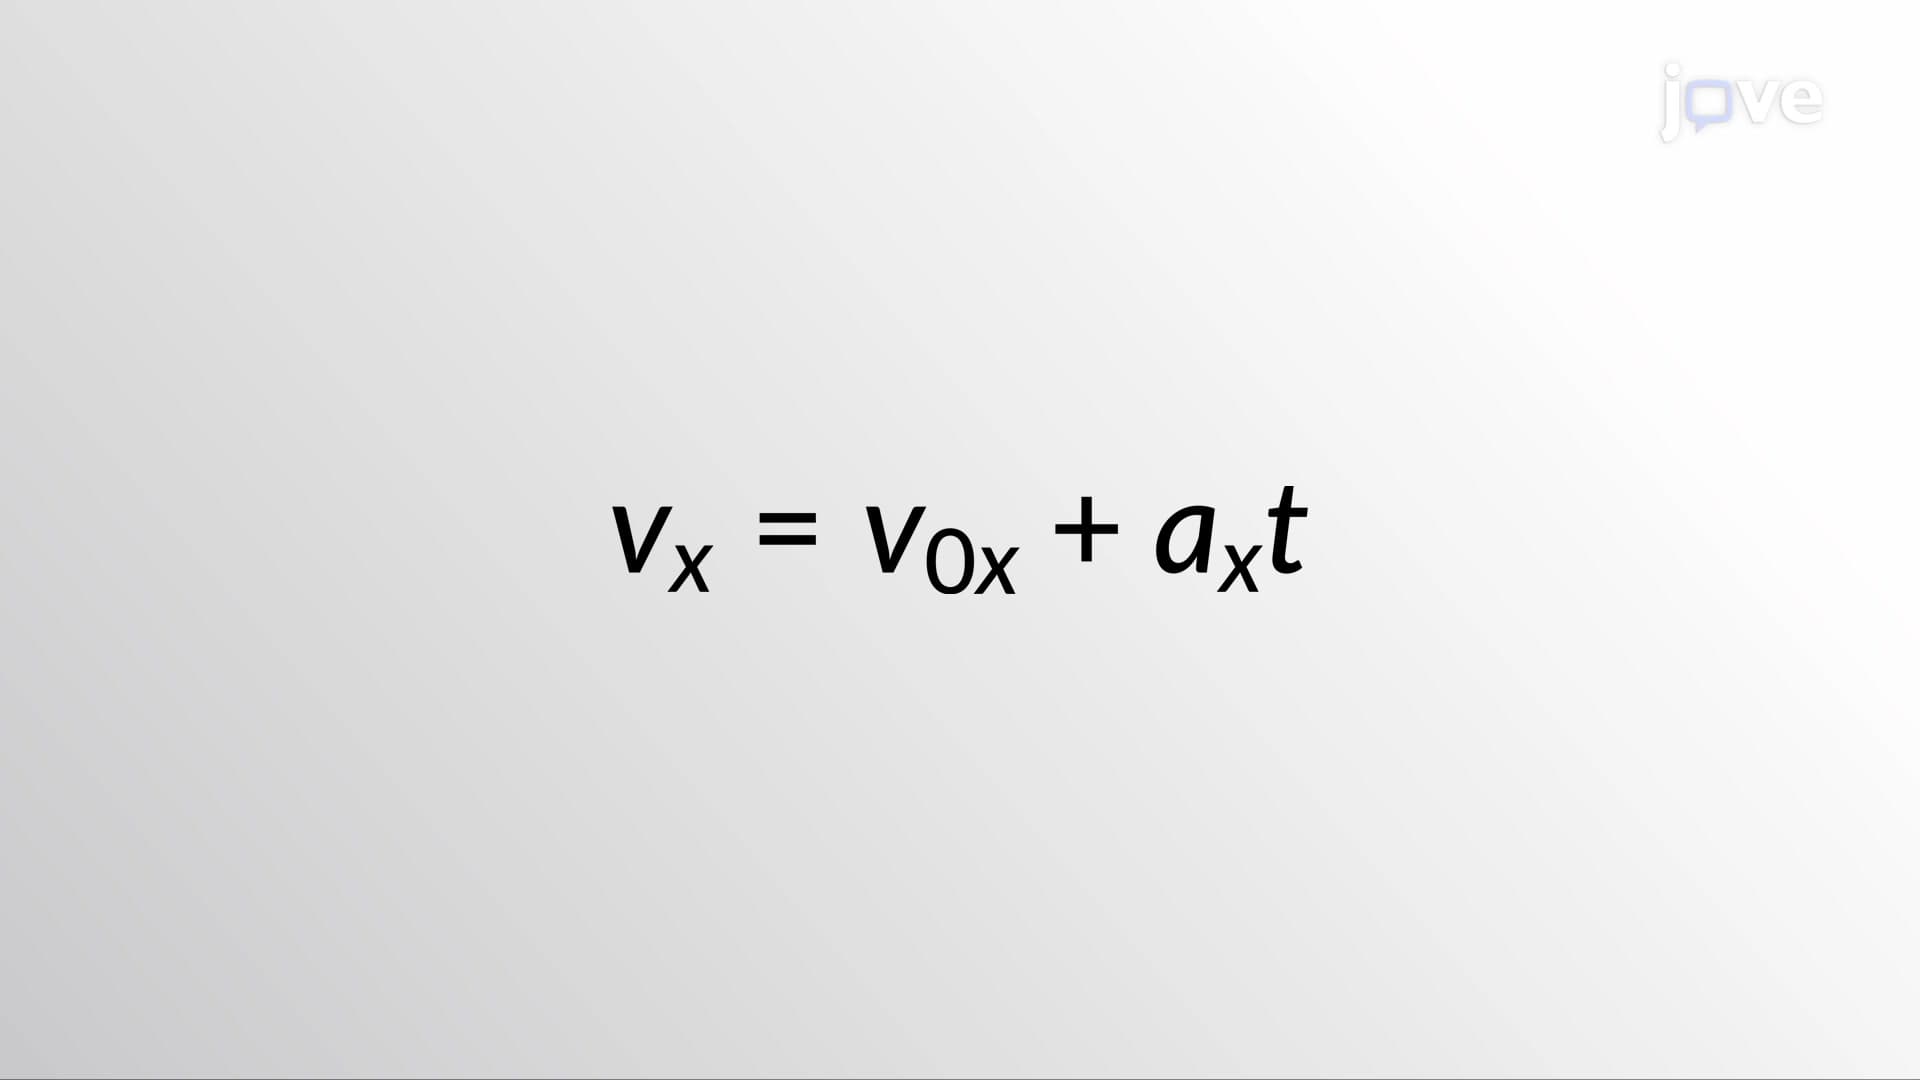 01:26
Kinematic Equations - I
10.5K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
10.5K
 01:30
Acceleration Vectors
8.0K
In everyday conversation, accelerating means speeding up. Acceleration is a vector in the same direction as the change in velocity, Δv, therefore the greater the acceleration, the greater the change in velocity over a given time. Since velocity is a vector, it can change in magnitude, direction, or both. Thus acceleration is a change in speed or direction, or both. For example, if a runner traveling at 10 km/h due east slows to a stop, reverses direction, and continues their run at 10 km/h...
8.0K
 01:34
Velocity and Position by Graphical Method
7.4K
Velocity and position can be calculated from the known function of acceleration as a function of time. The total area under the acceleration-time graph and the velocity-time graph gives the change in velocity and position, respectively. In the case of an airplane, its acceleration is tracked using the inertial navigation system. The pilot provides the input of the airplane's initial position and velocity before takeoff. The inertial navigation system then uses the acceleration data to...
7.4K