
软纤维注射器架构用于灵活机器人系统的无电无机控制
Chi Cong Nguyen1, Trung Thien Hoang1, James Davies1
1Graduate School of Biomedical Engineering, Faculty of Engineering and Tyree Institute of Health Engineering (IHealthE), UNSW Sydney, Kensington Campus, Sydney, NSW, 2052, Australia.
Advanced science (Weinheim, Baden-Wurttemberg, Germany)
|August 19, 2024

概括
本研究介绍了一种新的软纤维注射器架构 (SFSA),用于在灵活的机器人系统 (FRS) 和可穿戴用户界面 (WUIs) 中无电,无机动的执行和传感. SFSA为先进的人机交互提供了具有成本效益和适应性的解决方案.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 材料科学 材料科学 材料科学
- 人与机器的互动 人与机器的互动
背景情况:
- 灵活的机器人系统 (FRS) 和可穿戴的用户界面 (WUIs) 在医学中至关重要,提高了安全性和恢复.
- 软执行器,特别是液压执行器,提供优势,但受到复杂,昂贵的组件的限制.
- 现有的系统往往需要重的电机,和硬的部件,阻碍了适应性,增加了开支.
研究的目的:
- 引入一种新的软纤维注射器架构 (SFSA),用于无电动的驱动和无电机控制.
- 展示SFSA在灵活的机器人系统和可穿戴用户界面方面的能力.
- 探索SFSA在各种触觉应用中的综合传感能力.
主要方法:
- 开发一种新的软纤维注射器架构 (SFSA),使用液压连接的软人工肌肉.
- 在远程操作的柔性导管,电缆驱动的连续机器人手臂和可穿戴用户界面中对SFSA的实验验证.
- 评估SFSA的传感能力,包括被动/主动触摸,表面纹理和物体刚度检测.
主要成果:
- SFSA可实现无电动的驱动和无电机的控制,大大降低了系统的复杂性和成本.
- 证明了SFSA在各种机器人系统中的成功应用,包括柔性导管和连续臂.
- 经过验证的SFSA的传感能力用于检测触摸,纹理和刚度,增强人机交互.
结论:
- 开发的SFSA为FRS和WUI的无电流和无电机控制提供了一个高度可行的方法.
- SFSA的创新为机器人技术中的新传感和执行方法铺平了道路.
- 这项技术为灵活的机器人技术和可穿戴接口提供了更具适应性,成本效益和集成的解决方案.

相关概念视频
 01:15
Torque Free Motion
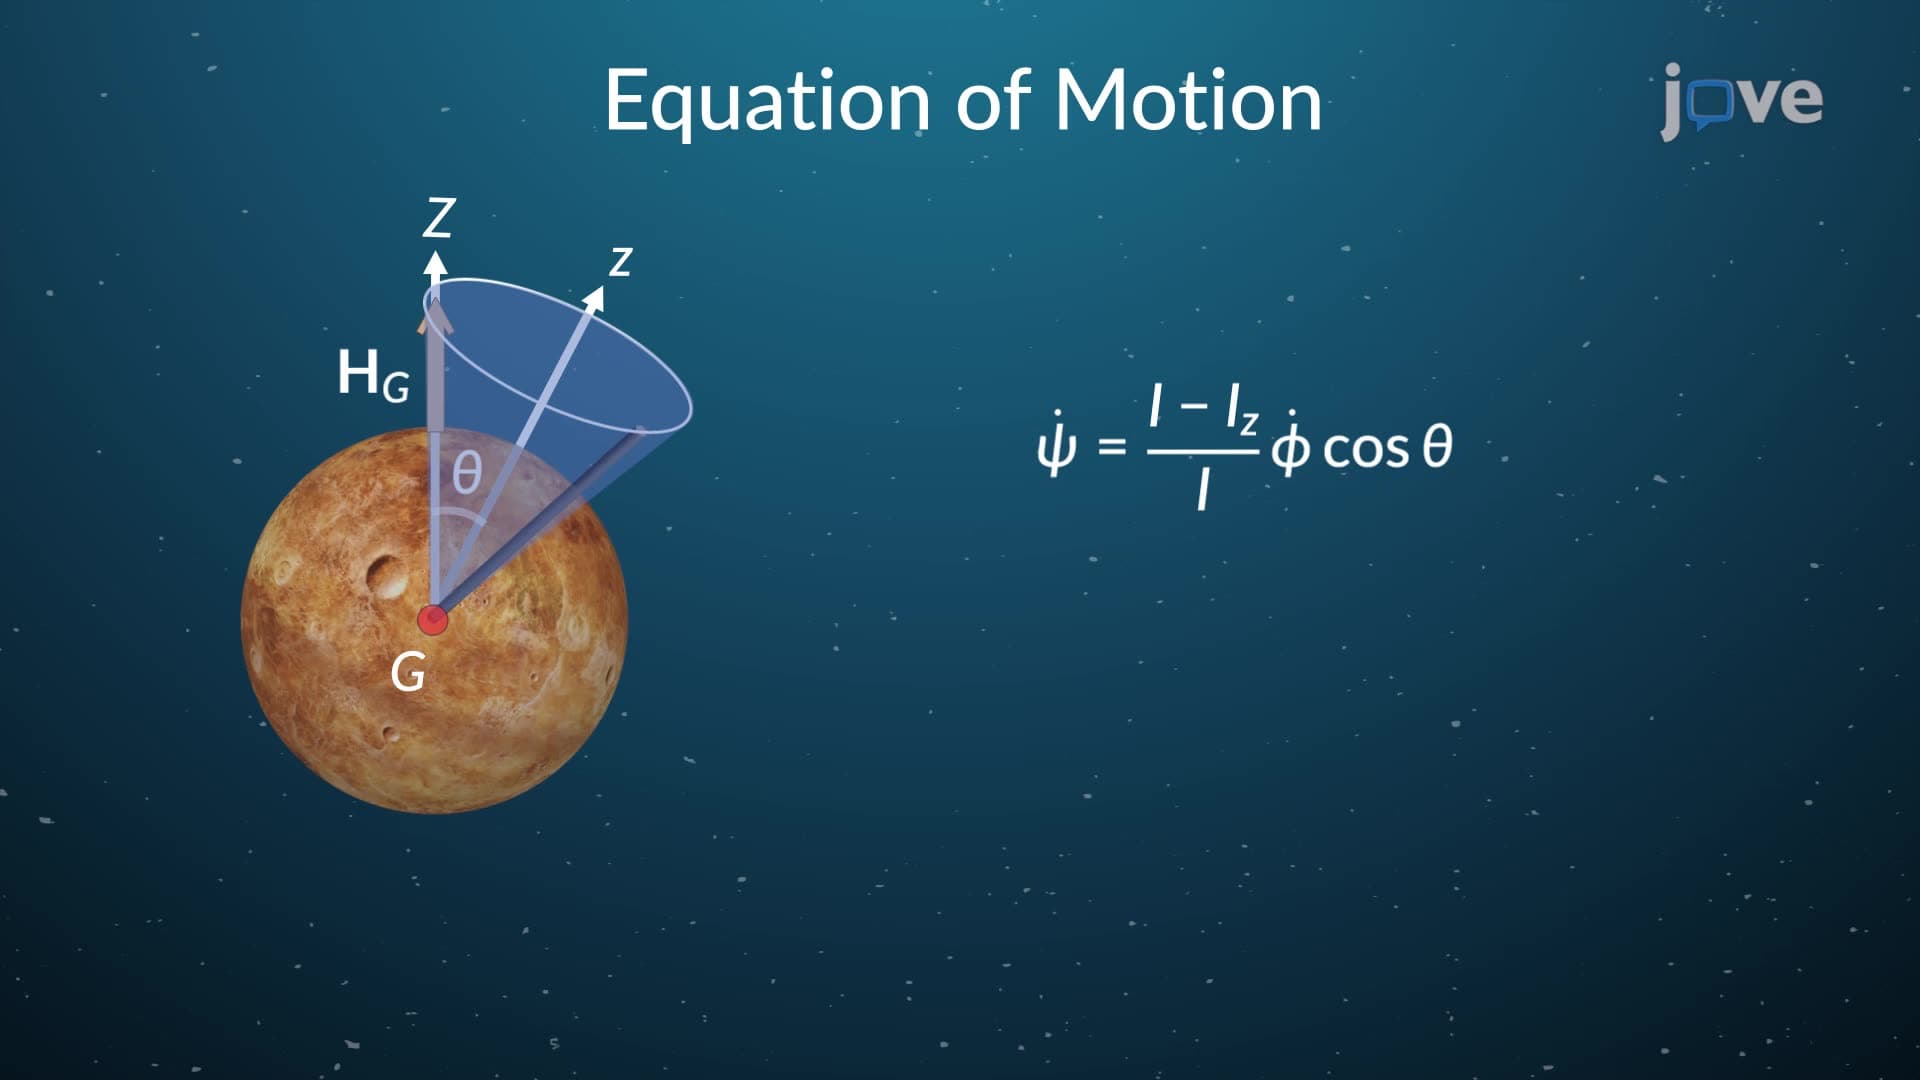
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...
 01:22
Mechanical Systems
Mechanical systems are analogous to to electrical networks where springs and masses play similar roles to inductors and capacitors, respectively. A viscous damper in mechanical systems functions similarly to a resistor in electrical networks, dissipating energy. The forces acting on a mass in such systems include an applied force in the direction of motion, counteracted by forces from the spring, a viscous damper, and the mass's acceleration. This interplay of forces is mathematically described...
 01:19
Electro-mechanical Systems
Electromechanical systems are intricate configurations that effectively combine electrical and mechanical elements to achieve a desired outcome. Central to many of these systems is the DC motor, a device that converts electrical energy into mechanical motion, enabling various applications ranging from simple fans to complex robotic mechanisms.
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...