

对于使用平衡的延迟方程的相位和振幅响应
R Nicks1, R Allen1, S Coombes1
1School of Mathematical Sciences, <a href="https://ror.org/01ee9ar58">University of Nottingham</a>, Nottingham NG7 2RD, United Kingdom.
Physical review. E
|August 20, 2024

概括
研究人员开发了一种新方法来分析延迟微分方程 (DDE) 中的振荡. 该框架使用平衡来构建相位和振幅响应函数,以理解在外部强迫下发生的DDE.
科学领域:
- 数学建模和动态系统的数学建模
- 非线性动力学和振荡.
- 应用数学和理论物理的应用数学.
背景情况:
- 延迟诱导的振荡在自然系统中很普遍,并且经常使用延迟微分方程 (DDE) 建模.
- 对于表现出极限周期振荡的普通微分方程,相振幅减小已被证明是成功的.
- 越来越需要对DDEs进行类似的减少技术,以分析它们在外部强迫下的行为.
研究的目的:
- 开发一个新的框架来构建DDEs的相位和振幅响应函数.
- 适应和扩展相振幅减小技术到延迟微分方程.
- 为了解DDEs对外部干扰的反应提供工具.
主要方法:
- 该研究使用平衡方法来构建响应函数.
- 拟议的框架将Floquet理论与和平衡相结合.
- 开发一种系统方法来减少DDEs的相位和幅度.
主要成果:
- 已经成功开发了一个强大的框架来构建DDEs的相位和振幅响应函数.
- 该方法可以更深入地了解DDEs如何应对外部强迫.
- 在减少DDE的背景下,证明平衡的实用性.
结论:
- 开发的框架为分析DDE振荡提供了一个强大的新工具.
- 这项工作将相幅度减小技术的适用性扩展到具有延迟的系统.
- 这些发现对于依赖DDEs来模拟自然现象的领域具有重要意义.

相关概念视频
 01:11
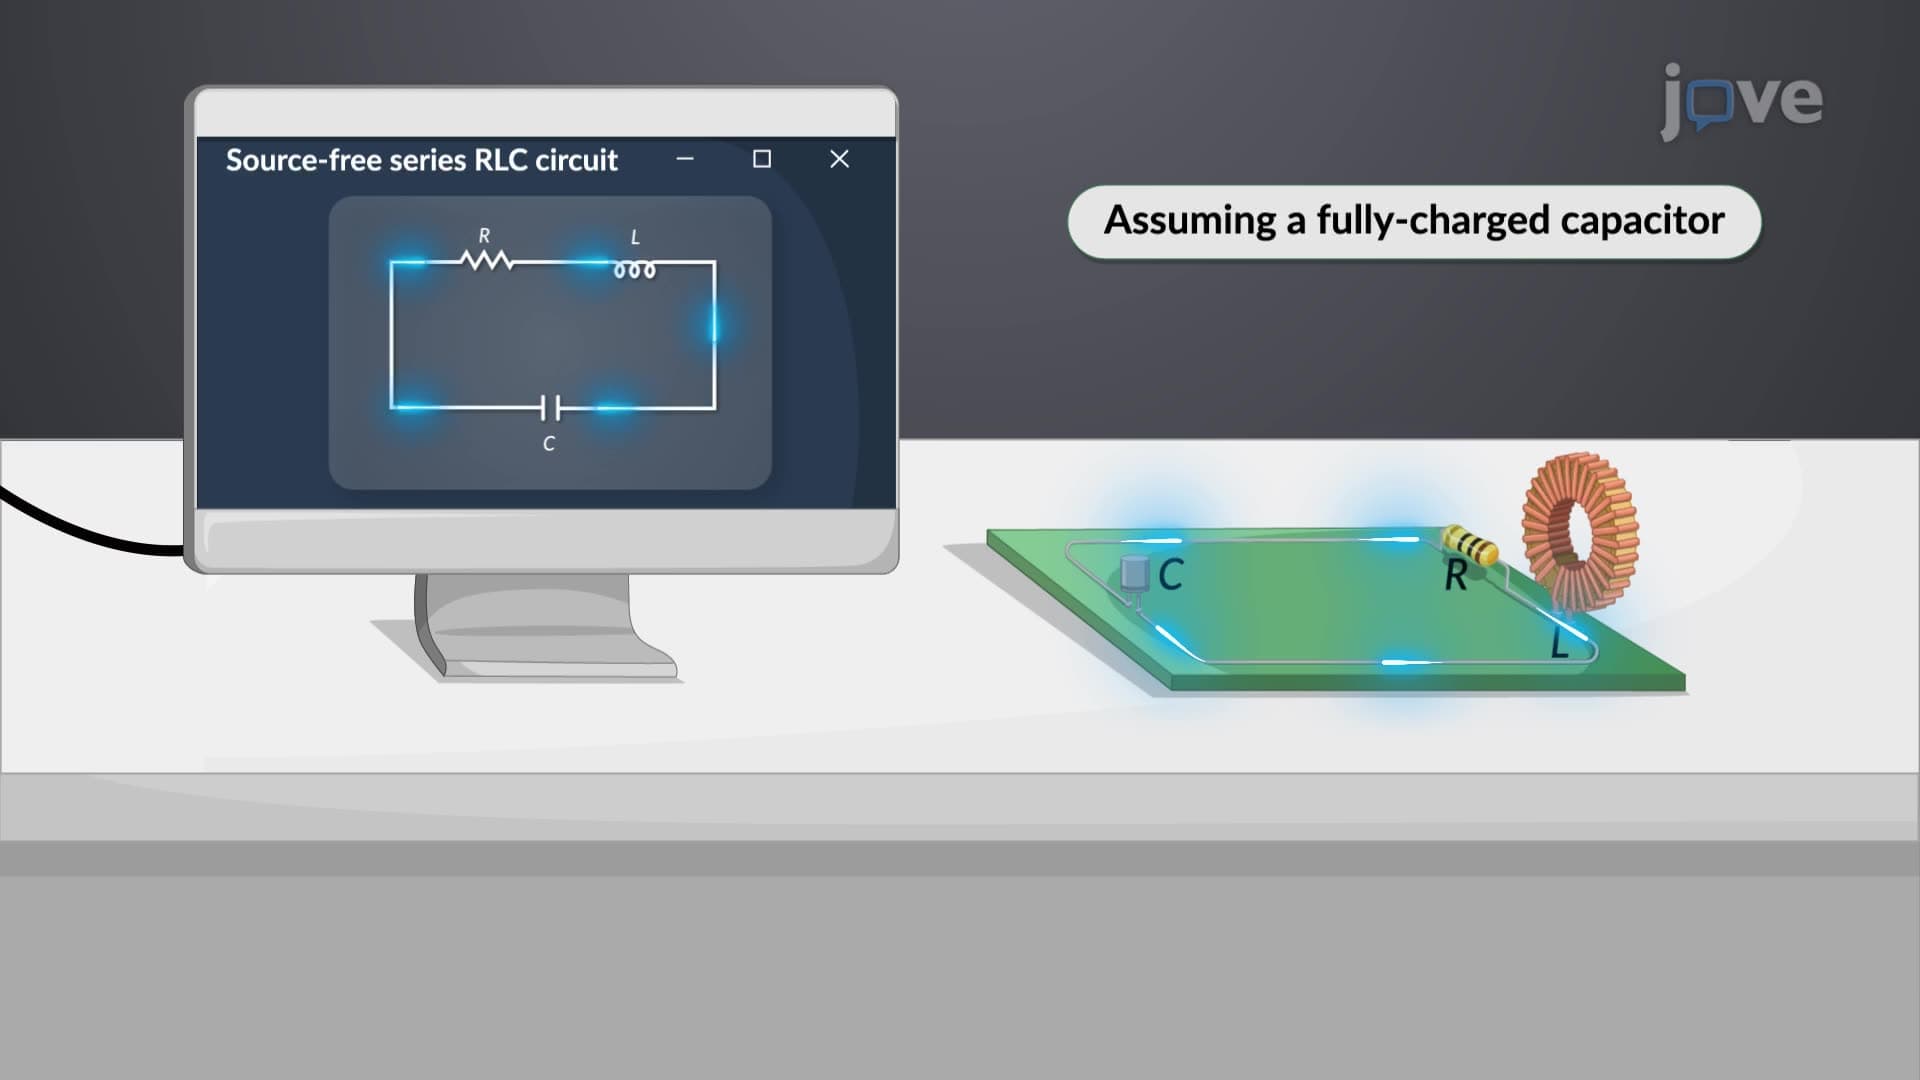
Types of Responses of Series RLC Circuits
864
A second-order differential equation characterizes a source-free series RLC circuit, marking its distinct mathematical representation. The complete solution of this equation is a blend of two unique solutions, each linked to the circuit's roots expressed in terms of the damping factor and resonant frequency.
864
 01:30
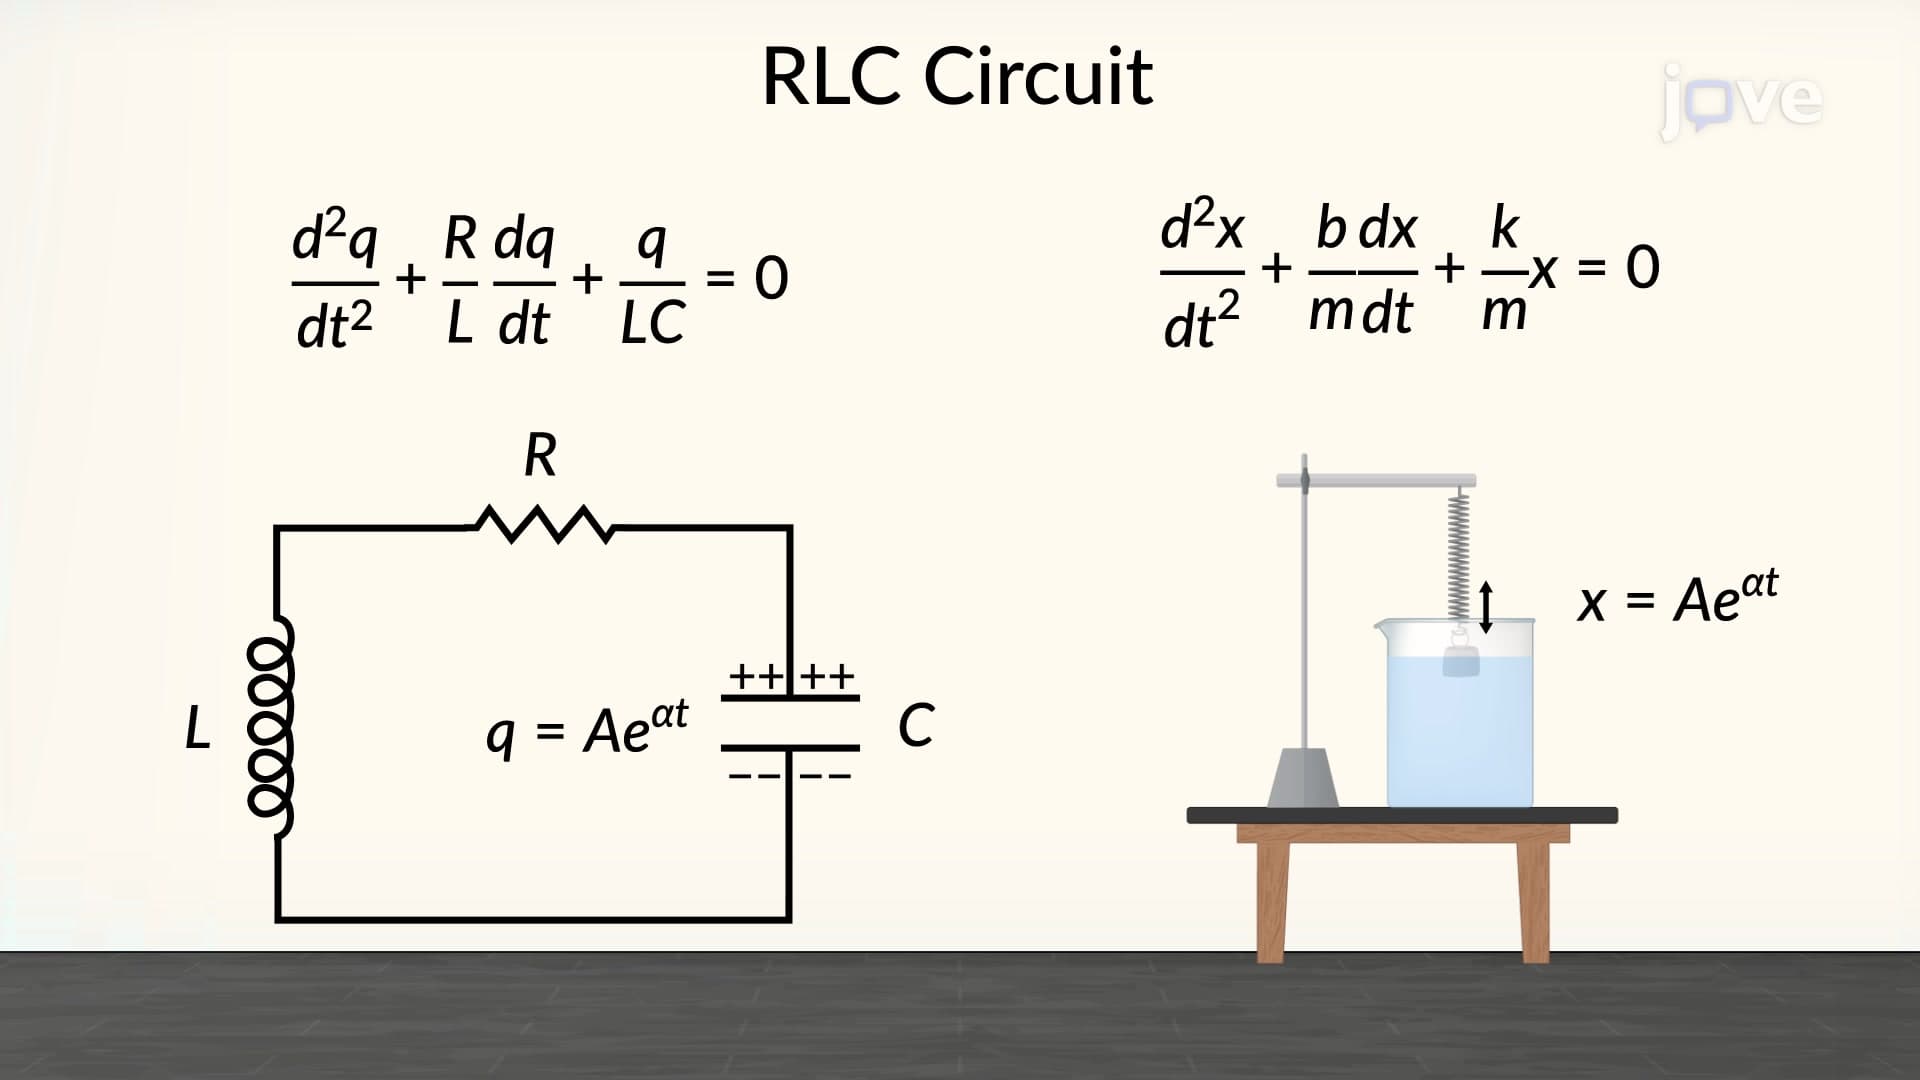
RLC Circuit as a Damped Oscillator
906
An RLC circuit combines a resistor, inductor, and capacitor, connected in a series or parallel combination.
Consider a series RLC circuit. Here, the presence of resistance in the circuit leads to energy loss due to joule heating in the resistance. Therefore, the total electromagnetic energy in the circuit is no longer constant and decreases with time. Since the magnitude of charge, current, and potential difference continuously decreases, their oscillations are said to be damped. This is...
Consider a series RLC circuit. Here, the presence of resistance in the circuit leads to energy loss due to joule heating in the resistance. Therefore, the total electromagnetic energy in the circuit is no longer constant and decreases with time. Since the magnitude of charge, current, and potential difference continuously decreases, their oscillations are said to be damped. This is...
906
 01:17
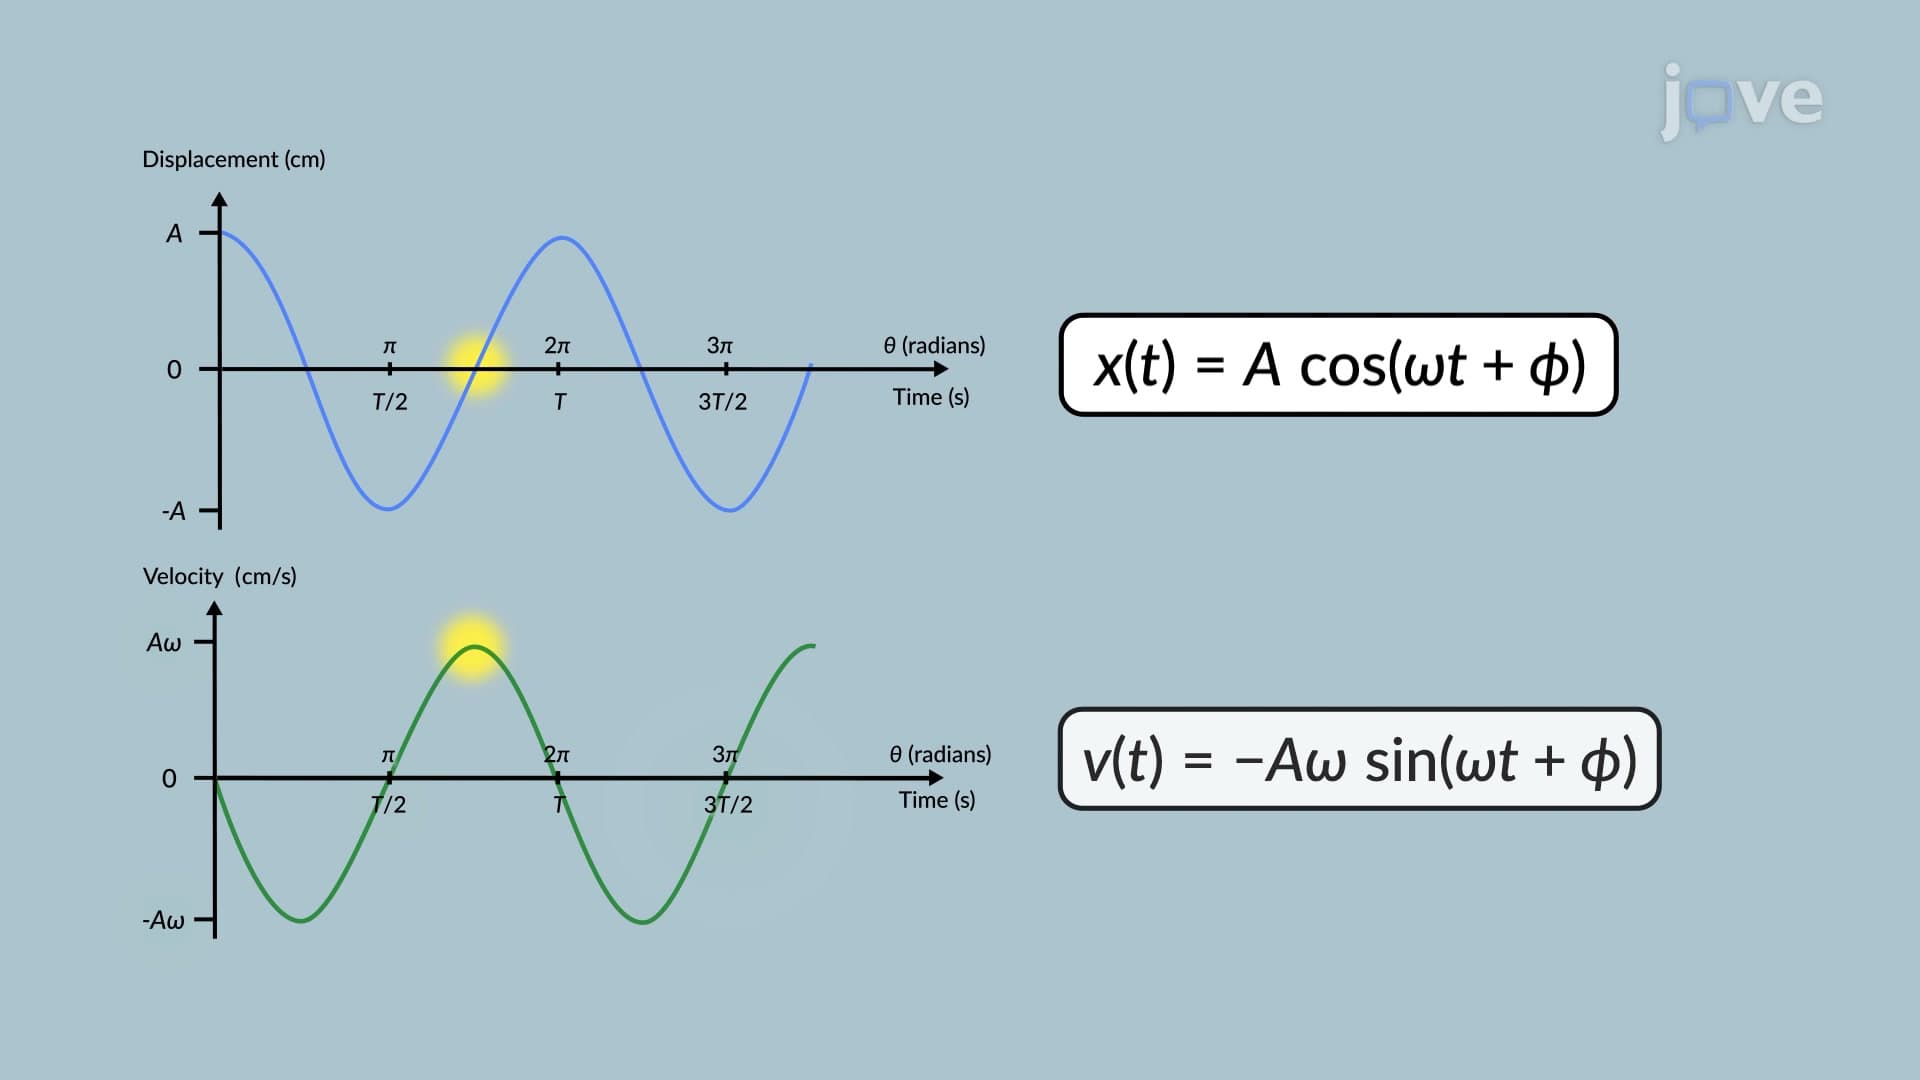
Characteristics of Simple Harmonic Motion
12.8K
The key characteristic of the simple harmonic motion is that the acceleration of the system and, therefore, the net force are proportional to the displacement and act in the opposite direction to the displacement. Additionally, the period and frequency of a simple harmonic oscillator are independent of its amplitude. For example, diving boards move faster or slower based on their thickness. A stiff, thick diving board has a large force constant, which causes it to have a smaller period, while a...
12.8K
 01:23
Transfer function and Bode Plots-II
318
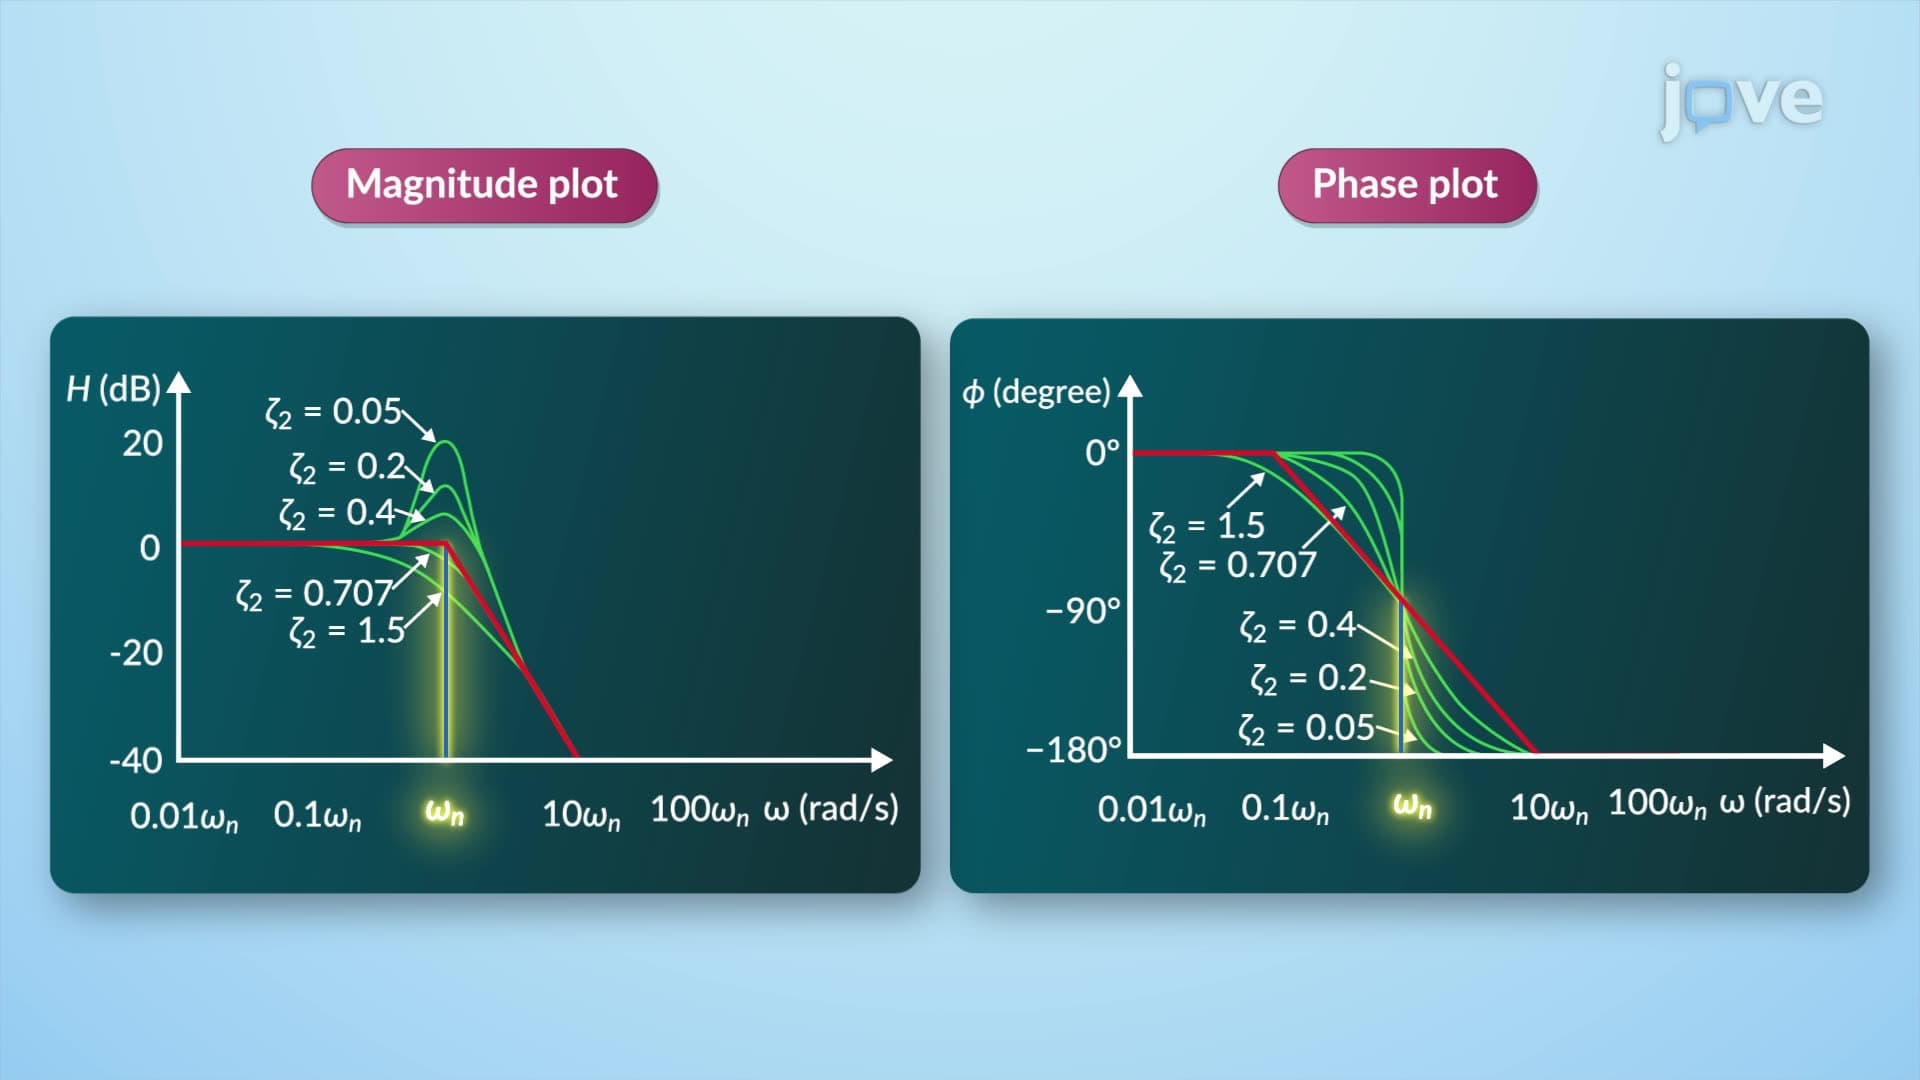
In the standard form, the transfer function is shown in constant gain, poles/zeros at origin, simple poles/zeros, and quadratic poles/zeros; each contributing uniquely to the system's overall response. The term represents the magnitude of the simple zero:
318
 01:19
Concept of Resonance and its Characteristics
5.0K
If a driven oscillator needs to resonate at a specific frequency, then very light damping is required. An example of light damping includes playing piano strings and many other musical instruments. Conversely, to achieve small-amplitude oscillations as in a car's suspension system, heavy damping is required. Heavy damping reduces the amplitude, but the tradeoff is that the system responds at more frequencies. Speed bumps and gravel roads prove that even a car's suspension system is not...
5.0K
 01:18
Second Order systems II
96
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
96