相关实验视频
Updated: Jun 16, 2025
08:02

Generation of Local CA1 γ Oscillations by Tetanic Stimulation
Published on: August 14, 2015
9.1K
在模糊驱动非线性系统的复杂网络中,混沌的共振式出现
Ricardo Chacón1, Pedro J Martínez2
1Departamento de Física Aplicada, E.I.I., <a href="https://ror.org/0174shg90">Universidad de Extremadura</a>, Apartado Postal 382, E-06006 Badajoz, Spain and Instituto de Computación Científica Avanzada (ICCAEx), <a href="https://ror.org/0174shg90">Universidad de Extremadura</a>, E-06006 Badajoz, Spain.
Physical review. E
|August 20, 2024

概括
我们解决了如何在复杂的非线性振荡器网络中出现时空混乱,即使在弱合的情况下. 我们的发现揭示了神经和生态网络等多种系统中混乱控制的机制.
科学领域:
- 非线性科学 非线性科学
- 复杂的网络 复杂的网络
- 混沌理论 混沌理论
背景情况:
- 了解复杂网络中的混乱动态对于神经工程和生态学等领域至关重要.
- 一个关键的挑战是解释弱合振荡器中的混乱,这些振荡器在未合时是规律的.
研究的目的:
- 解决空间时空混乱的出现和持久性问题,在模糊驱动非线性振荡器的复杂网络中.
- 揭示混沌背后的物理机制,无论是星状网络还是无尺度网络.
主要方法:
- 使用标准分析方法开发了一个全面的理论.
- 利用低维有效模型的层次结构.
- 进行了广泛的数值模拟.
主要成果:
- 在弱合体制中出现和持久的时空混乱的特征.
- 确定了混乱的异质性诱导和冲动诱导机制.
- 在特定的网络结构中证明了混乱抑制和增强.
结论:
- 该研究提供了对复杂的振荡网络中驱动混乱的机制的基本见解.
- 这些发现适用于控制工程和自然系统中的混乱行为.
相关概念视频
 01:06
Forced Oscillations
6.5K
When an oscillator is forced with a periodic driving force, the motion may seem chaotic. The motions of such oscillators are known as transients. After the transients die out, the oscillator reaches a steady state, where the motion is periodic, and the displacement is determined.
6.5K
 01:07
Damped Oscillations
5.7K
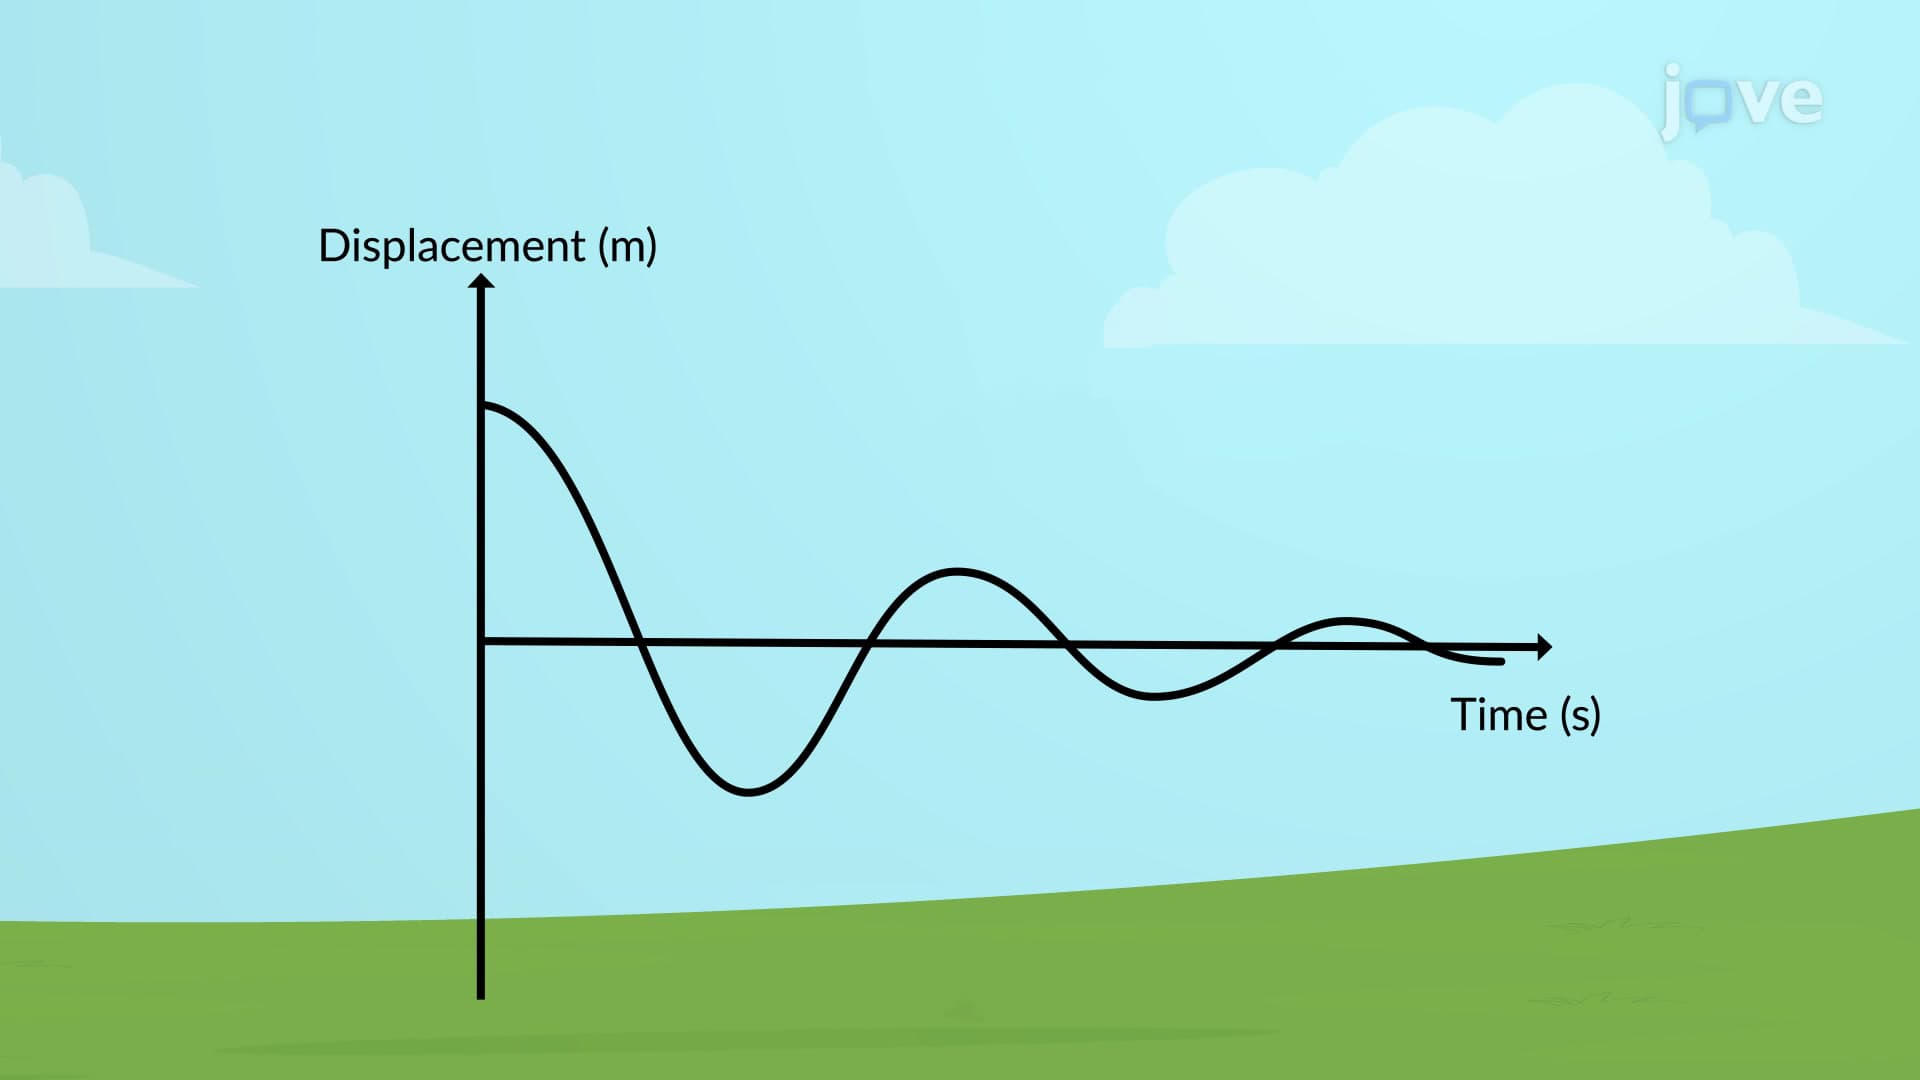
In the real world, oscillations seldom follow true simple harmonic motion. A system that continues its motion indefinitely without losing its amplitude is termed undamped. However, friction of some sort usually dampens the motion, so it fades away or needs more force to continue. For example, a guitar string stops oscillating a few seconds after being plucked. Similarly, one must continually push a swing to keep a child swinging on a playground.
Although friction and other non-conservative...
Although friction and other non-conservative...
5.7K
 01:20
Types of Damping
6.4K
If the amount of damping in a system is gradually increased, the period and frequency start to become affected because damping opposes, and hence slows, the back and forth motion (the net force is smaller in both directions). If there is a very large amount of damping, the system does not even oscillate; instead, it slowly moves toward equilibrium. In brief, an overdamped system moves slowly towards equilibrium, whereas an underdamped system moves quickly to equilibrium but will oscillate about...
6.4K
 01:18
Second Order systems II
96
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
96
 01:21
Linear Approximation in Time Domain
75
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
75
 01:10
Entropy Change in Reversible Processes
2.5K
In the Carnot engine, which achieves the maximum efficiency between two reservoirs of fixed temperatures, the total change in entropy is zero. The observation can be generalized by considering any reversible cyclic process consisting of many Carnot cycles. Thus, it can be stated that the total entropy change of any ideal reversible cycle is zero.
The statement can be further generalized to prove that entropy is a state function. Take a cyclic process between any two points on a p-V diagram.
The statement can be further generalized to prove that entropy is a state function. Take a cyclic process between any two points on a p-V diagram.
2.5K