

结合Lyapunov函数的方法用于分析中性Cohen-Grossberg神经网络的稳定性,具有多次延迟
Ozlem Faydasicok1, Sabri Arik2
1Department of Mathematics, Faculty of Science Istanbul University, Vezneciler, Istanbul, Turkey.

概括
本研究为具有时间和中性延迟的科恩-格罗斯伯格神经网络引入了新的稳定性标准. 这些发现为这些复杂的神经系统的全球稳定提供了改善的,与延迟无关的条件.
科学领域:
- 计算神经科学是一种神经科学.
- 动态系统理论 动态系统理论
- 人工智能的人工智能
背景情况:
- 科恩-格罗斯伯格神经网络是计算神经科学的基本模型.
- 分析这些网络的稳定性对于理解它们的行为和应用至关重要.
- 现有的方法经常与具有恒定时间和中性延迟的网络扎.
研究的目的:
- 为科恩-格罗斯伯格神经网络的概括类开发新的稳定性标准.
- 解决包含常量时间和中性延迟参数的网络.
- 为了建立独立于延迟的稳定性条件.
主要方法:
- 应用联合利亚普诺夫函数的方法.
- 系统地结合了各种利亚普诺夫函数的组合.
- 分析具有利普希茨连续激活函数的网络.
主要成果:
- 新的标准确保了Cohen-Grossberg神经网络模型的全球稳定性.
- 稳定性条件独立于时间和中性延迟参数.
- 导出条件的特点仅仅是网络的常数参数.
结论:
- 拟议的稳定性标准比现有方法提供了显著的进步.
- 这些结果为网络稳定性分析提供了替代性和可能更适用的条件.
- 一个数值示例表明了新发现的实际实用性.
相关概念视频
 01:26
Linear Approximation in Frequency Domain
88
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
88
 01:25
Multimachine Stability
150
Multimachine stability analysis is crucial for understanding the dynamics and stability of power systems with multiple synchronous machines. The objective is to solve the swing equations for a network of M machines connected to an N-bus power system.
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
150
 01:24
Pole and System Stability
262
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
262
 01:21
Control System Problem
110
In an open-loop system, such as a basic thermostat, the poles of the transfer function influence the system's response but do not determine its stability. However, when feedback is introduced to form a closed-loop system, such as an advanced thermostat that adjusts heating based on room temperature, stability is governed by the new poles of the closed-loop transfer function.
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
110
 01:19
Plotting and Calibrating the Root Locus
105
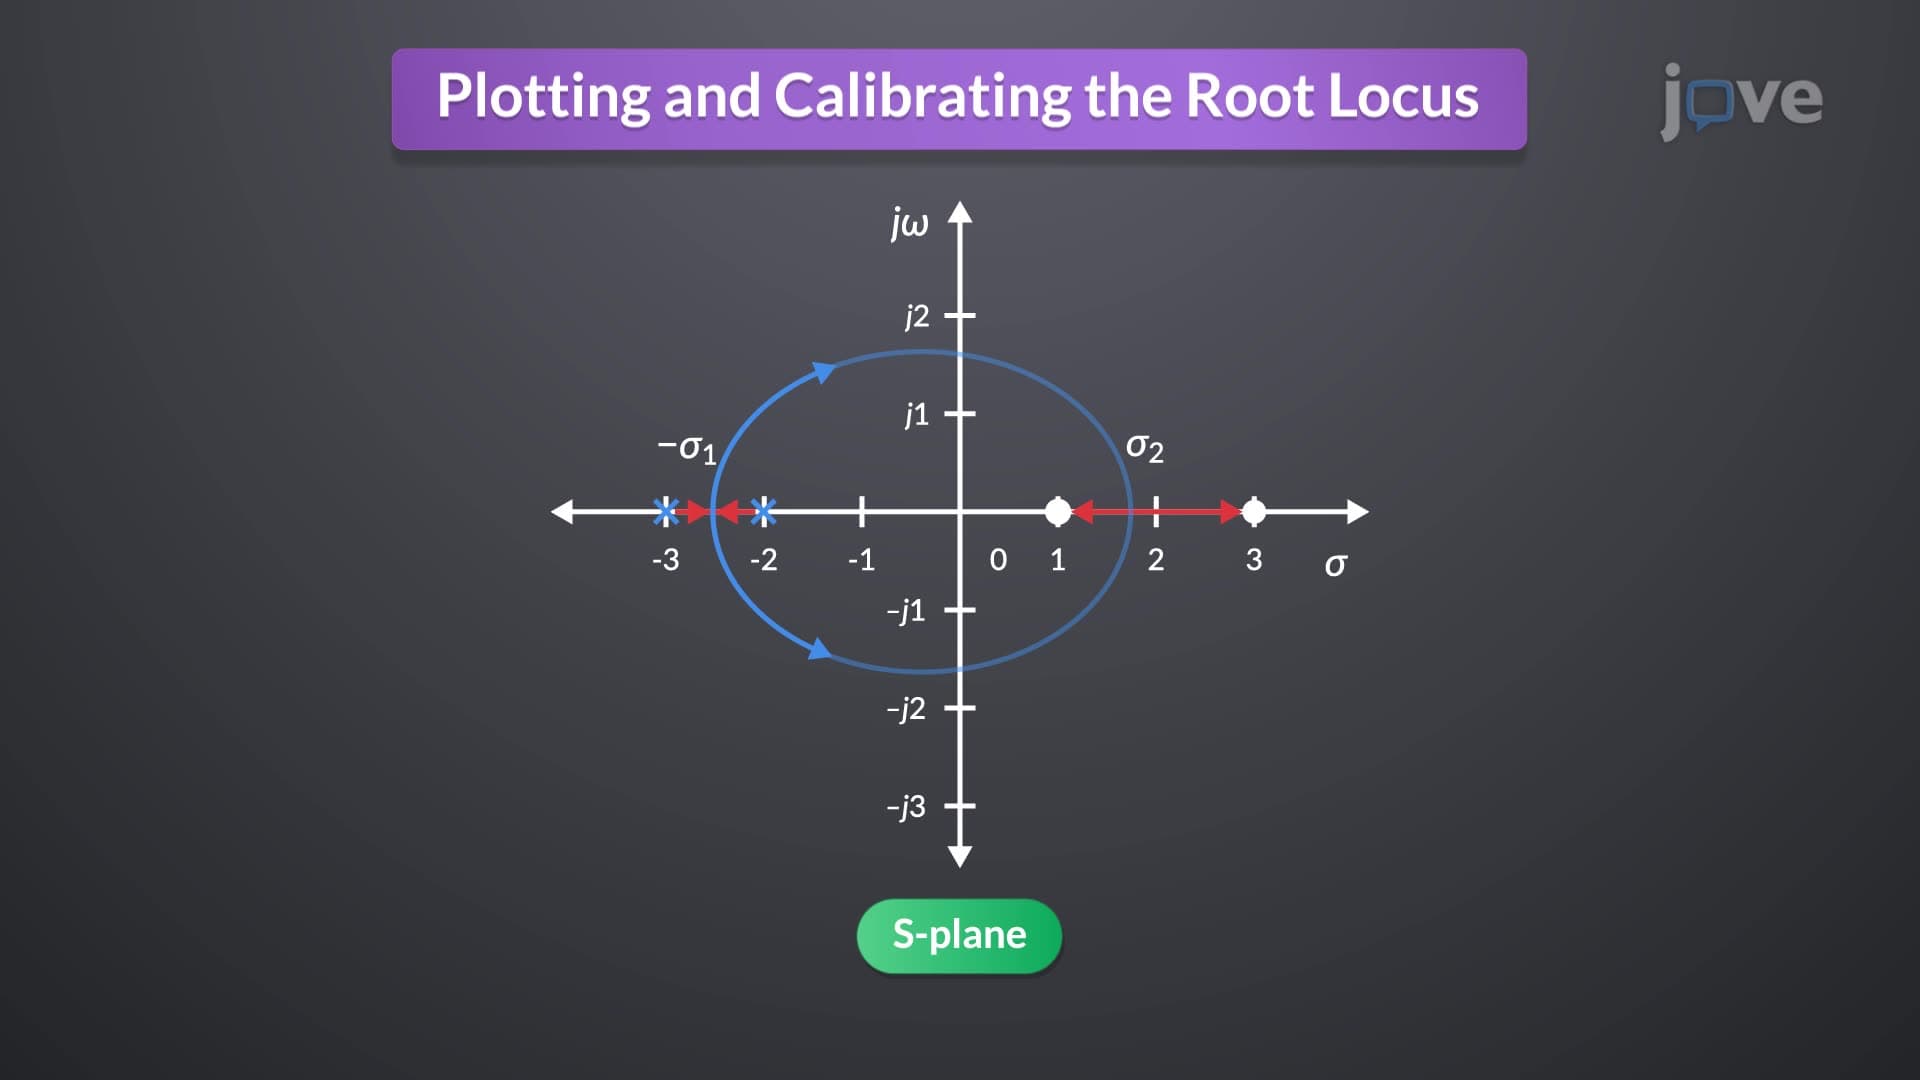
Root loci often diverge as system poles shift from the real axis to the complex plane. Key points in this transition are the breakaway and break-in points, indicating where the root locus leaves and reenters the real axis. The branches of the root locus form an angle of 180/n degrees with the real axis, where n is the number of branches at a breakaway or break-in point.
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
105
 01:21
Linear Approximation in Time Domain
72
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
72