相关实验视频
Updated: Jun 15, 2025
09:11
Controlled Rotation of Human Observers in a Virtual Reality Environment
Published on: April 21, 2022
2.5K
通过扩展的伺服导航来实现运行时运动和第一阶段的闪光控制
Malte Riedel1, Thomas Ulrich1, Klaas P Pruessmann1
1Institute for Biomedical Engineering, ETH Zurich and University of Zurich, Switzerland.
Magnetic resonance in medicine
|August 27, 2024

概括
本研究介绍了一种基于导航器的方法,用于精确的实时运动和渐变闪现场校正3D脑成像. 该技术提供快速处理和最小校准,提高幻影和体内扫描的图像质量.
科学领域:
- 医疗成像医学成像
- 磁共振成像 (MRI) 物理 物理
背景情况:
- 运动和磁场波动显著降低了3D大脑MRI的质量.
- 精确的校正方法对于高分辨率的神经成像至关重要.
研究的目的:
- 开发基于导航器的系统,用于实时,高精度的运动和第一阶梯度闪光场校正,用于3D人脑成像.
- 以最小的校准,采集时间和快速处理来实现这一目标.
主要方法:
- 使用轨道导航器扩展了一个复杂值的线性扰动模型,并使用反控制来估计和纠正梯度闪光场.
- 提出了两种方法:使用额外的导航器和基于投影的近似的有限差异.
- 集成的噪声对应,以减少参数偏差.
主要成果:
- 实现了强大的运动和梯度闪光校正,在幻影和体内实验中显著提高了图像质量.
- 成功纠正了磁漂移,梯度场扰动和瓶子幻象移动.
- 在体内扫描中证明了干运动效应的缓解和头部运动的稳定性,具有高精度.
结论:
- 基于导航器的方法提供了准确的,高精度的,实时的运动和场校正.
- 该技术对MRI序列的影响最小,校准要求低.

相关概念视频
 01:24
One-Degree-of-Freedom System
473
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
473
 01:15
Torque Free Motion
467
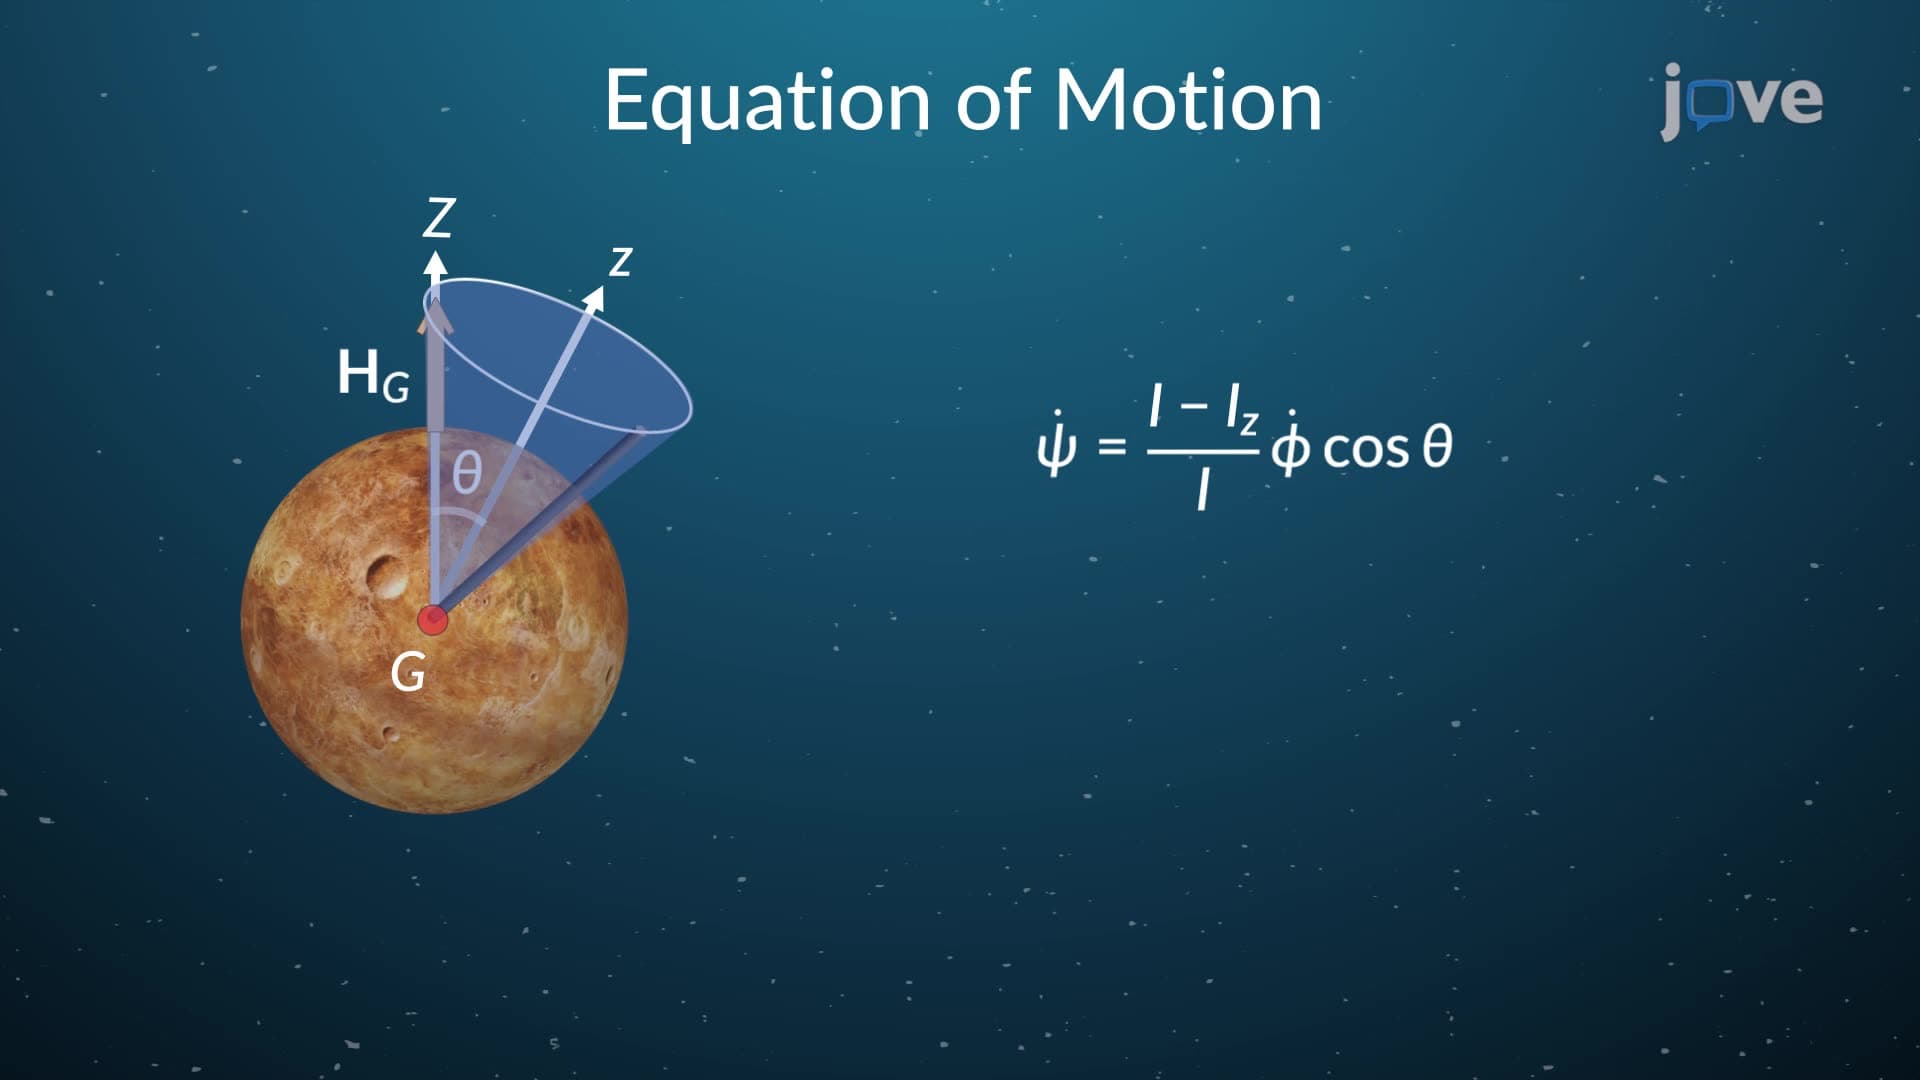
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...
467
 01:25
Relative Motion Analysis using Rotating Axes
452
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
452
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
394
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
394
 01:17
Open and closed-loop control systems
686
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
686
 01:24
Absolute Motion Analysis- General Plane Motion
218
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
218