一个柔软的两Voxel类型的四肢机器人,基于原始灵活球的罗姆比克十二方体的原始灵活球
1School of Mechanical and Material Engineering, North China University of Technology, Beijing 100144, China.
Biomimetics (Basel, Switzerland)
|August 28, 2024

概括
这项研究介绍了一种由原始灵活球制成的新型软两机器人. 这种机器人可以在陆地和水下移动,展示了软机器人的新方法.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 材料科学 材料科学 材料科学
- 机械工程 机械工程
背景情况:
- 软机器人在适应性和安全性方面比刚性机器人提供了优势.
- 开发能够在陆地和水下环境之间无过渡的两机器人仍然是一个挑战.
- 灵感来自于Origami的结构为机器人应用提供了独特的机械性能.
研究的目的:
- 为了介绍一款新的voxel类型软两机器人.
- 从理论上建模原木弹性球的变形机制.
- 展示机器人在各种环境中的能力.
主要方法:
- 理论建模原木弹性球的几何和弹性.
- 使用软弹性材料的3D打印制造了一个四足机器人.
- 实验验证机器人在水上和陆地上运动的验证.
主要成果:
- 建立了原始弹性球的几何和弹性构成模型.
- 揭示了柔性球的零能量存储和准零刚性特征.
- 展示了一种14球灵活的四足机器人,能够在平坦,沙和水下地形上行走/爬行.
- 突出了机器人因其空洞结构而适应水静压和电流的适应性.
结论:
- 原始弹性球因其独特的机械性能而适用于软机器人元件.
- 沃克塞尔型软两机器人展示了多功能性和易于制造的性能.
- 该机器人显示出在海洋和陆地环境中各种应用的潜力.


相关概念视频
 01:30
Three-Dimensional Force System
3.0K
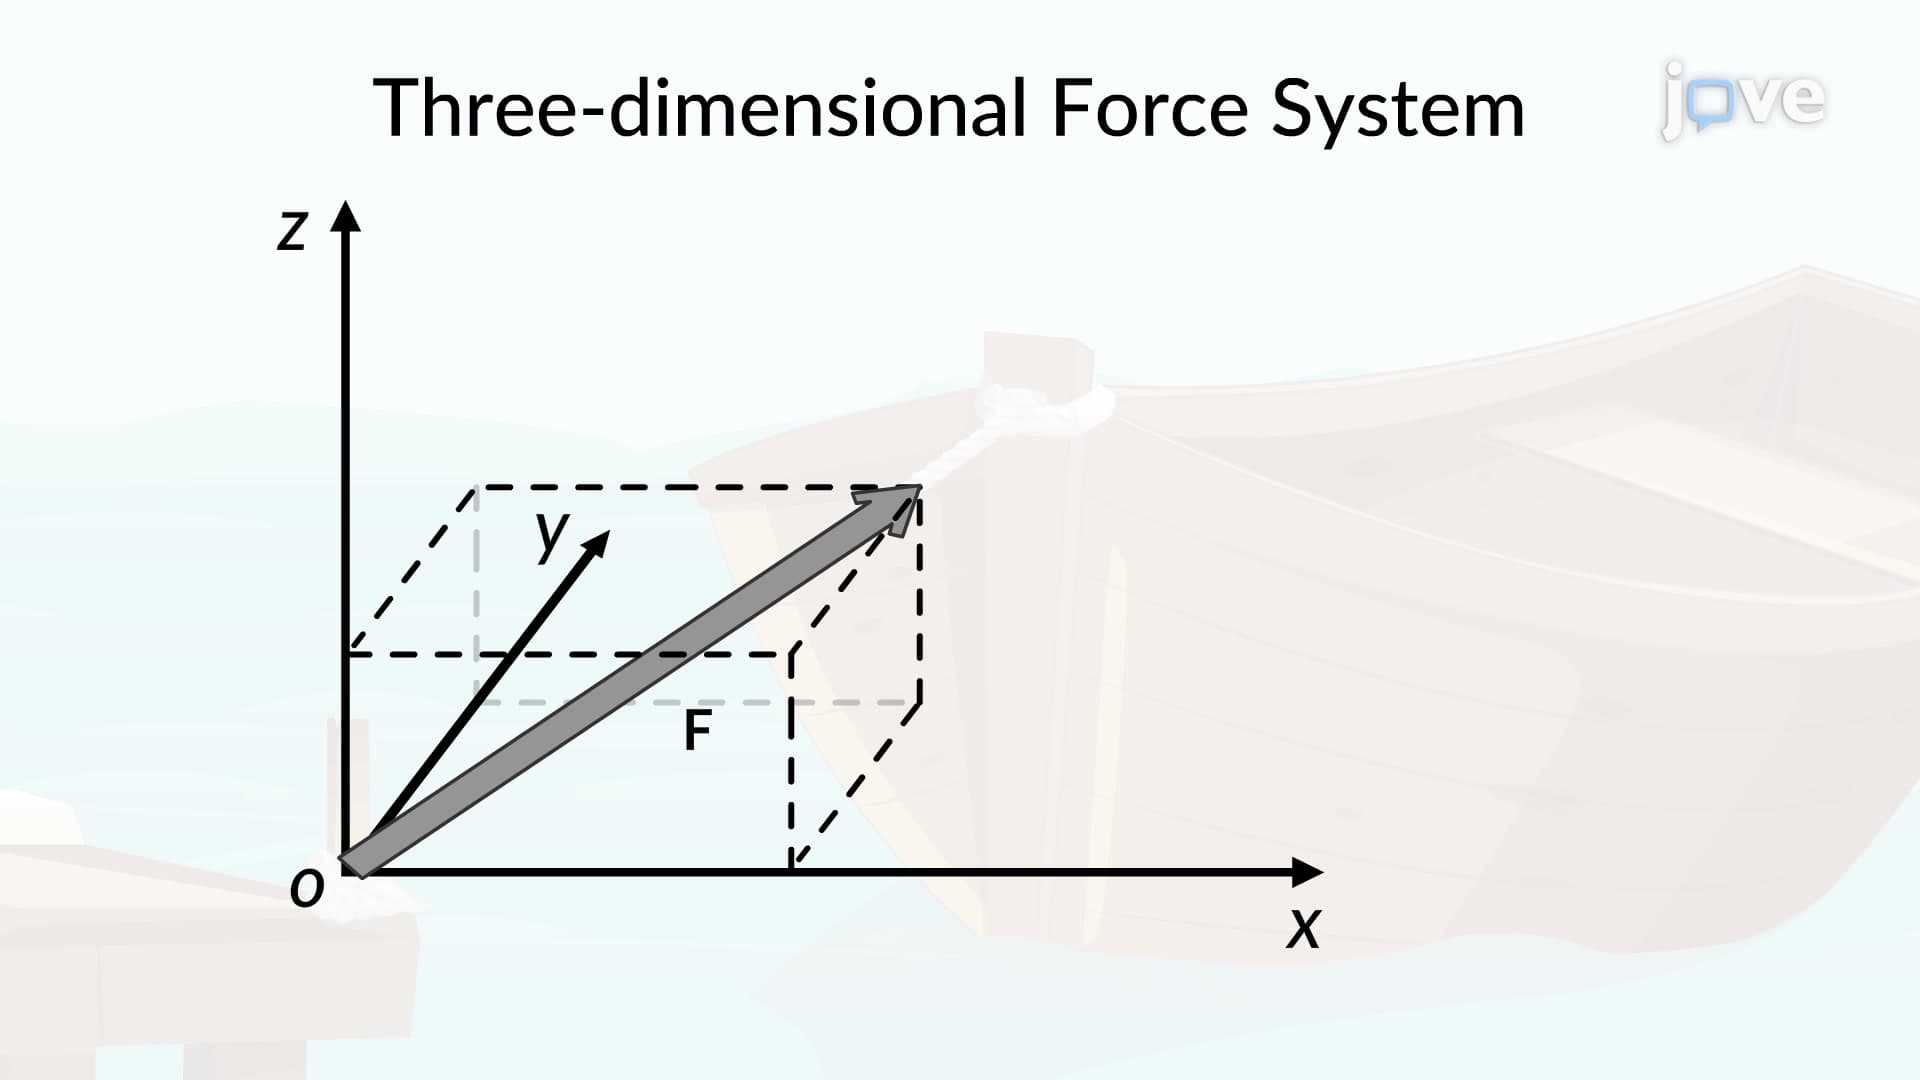
In mechanical engineering, a three-dimensional force system is a system of forces acting in three dimensions, with forces applied along the x, y, and z coordinate axes. The three-dimensional force system is an important concept in mechanical engineering, as it allows engineers to understand and analyze the behavior of objects and structures in three dimensions. By understanding the forces acting on a system, engineers can design more efficient and effective mechanical systems that can withstand...
3.0K
 01:30
Three-Dimensional Force System:Problem Solving
1.5K
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
1.5K
 01:06
Virtual Work for a System of Connected Rigid Bodies
856
Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
Next,...
856
 01:14
Design Example: Frog Muscle Response
741
A student is tasked to work on an intriguing experiment involving an RL (Resistor-Inductor) circuit to study the muscle response of a frog's leg to electrical stimulation. The RL circuit plays a crucial role in this experiment, providing the means to control and measure the electrical impulses that trigger muscle contraction.
When the switch connecting the RL circuit is closed, a brief muscle contraction is observed. This is because, at a steady state, the inductor acts like a short...
When the switch connecting the RL circuit is closed, a brief muscle contraction is observed. This is because, at a steady state, the inductor acts like a short...
741
 01:18
Unsymmetric Bending
967
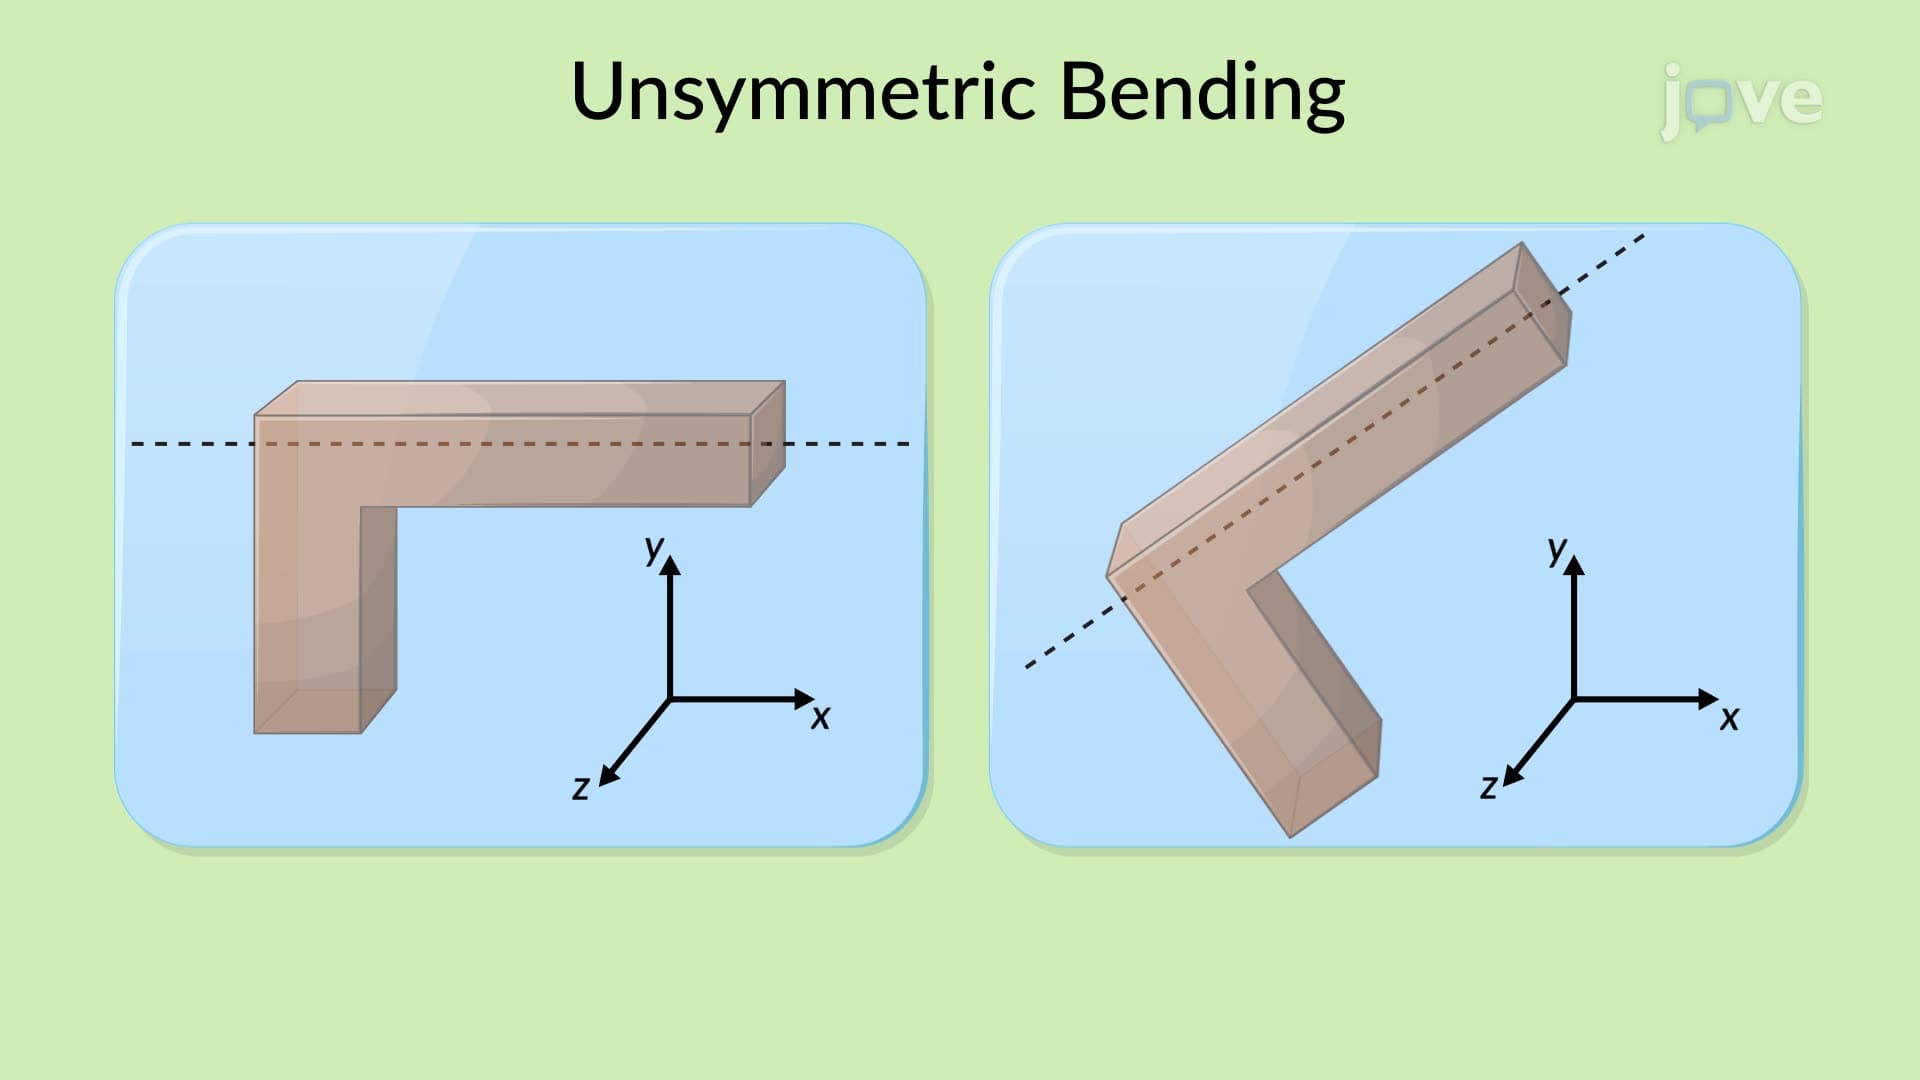
Unsymmetrical bending occurs when the bending moment applied to a structural member does not align with its principal axis. This misalignment leads to complex stress distributions and deflection patterns that differ from those in symmetrical bending, and are essential for designing structures to withstand different loading conditions. In unsymmetrical bending, the neutral axis—where stress is zero—does not necessarily align with the geometric axes of the cross-section. The...
967
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
4.5K
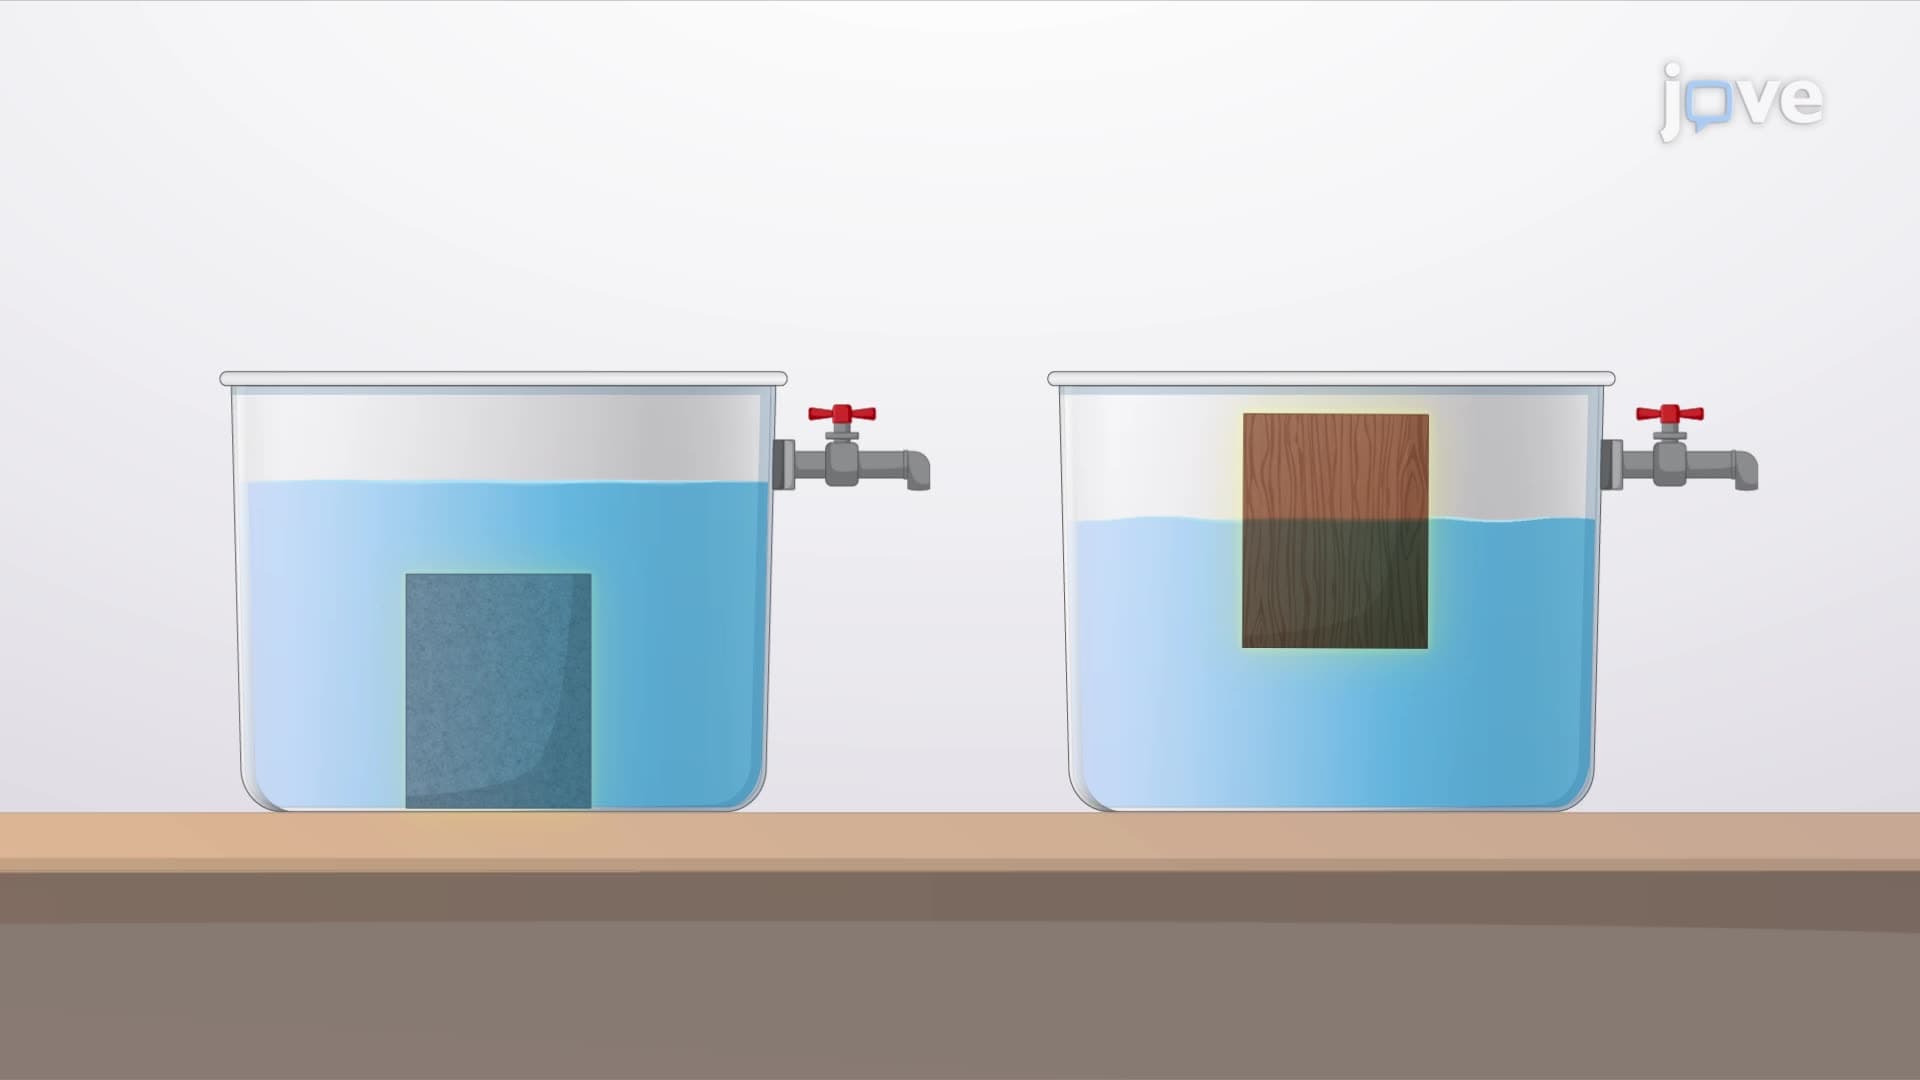
In fluid mechanics, buoyancy and stability are key concepts for understanding the behavior of submerged and floating bodies. When a stationary body is fully or partially submerged in a fluid, the fluid exerts a force on the body known as the buoyant force. This force acts vertically upward through a point called the center of buoyancy, which is the center of the displaced fluid volume. According to Archimedes' principle, the magnitude of the buoyant force is equal to the weight of the fluid...
4.5K