

机器人SDF:用于机器人手臂的隐式形态建模
Yusheng Yang1,2, Jiajia Liu1,2, Hongpeng Zhou3
1School of Mechatronic Engineering and Automation, Shanghai University, Shanghai 200444, China.

机器人SDF使用集成的关节模型精确地模拟任何姿势中的机器人手臂形状. 这种隐式方法改善了动态形状表示,以更好地规划运动和避免碰撞.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 计算机视觉 计算机视觉
- 计算几何学的计算几何学
背景情况:
- 准确的机器人手臂形态对于运动规划和避免碰撞至关重要.
- 传统的方法在计算成本和动态形状的细节之间的权衡中扎.
- 签名距离功能提供了优势,但面临着无限机器人姿势的挑战.
研究的目的:
- 介绍RobotSDF,一种隐式建模方法,用于在任意姿势中精确地表达机器人形态.
- 解决现有代表动态机器人形状的方法的局限性.
- 提高机器人运动规划和避免碰撞的效率和准确性.
主要方法:
- 机器人SDF模型将机器人形态作为由关节配置驱动的集成隐性关节模型.
- 动态形状变化是通过联合坐标系统中的查询点的坐标转换来处理的.
- 使用一种隐性,姿势意识的方法,避免对每个姿势进行独立建模.
主要成果:
- 机器人SDF准确地描绘了不同姿势的机器人形状,直至毫米级.
- 与神经-JSDF和配置空间距离场算法相比,分别实现了38.65%和66.24%的改进.
- 在模拟和现实世界的人机器人协作中证明了有效的避免碰撞.
结论:
- 机器人SDF为隐式机器人形态建模提供了精确有效的方法.
- 该方法有效地处理动态形状变化和任意机器人姿势.
- 机器人SDF显著提升了机器人运动规划和安全的人机交互的能力.
更多相关视频
 11:06
Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
 07:46
Author Spotlight: Revolutionizing Remote Surgery with Augmented Reality and Robotics for Enhanced Precision and Accessibility
Published on: August 9, 2024
相关概念视频
 01:20
Plastic Deformation in Circular Shafts
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
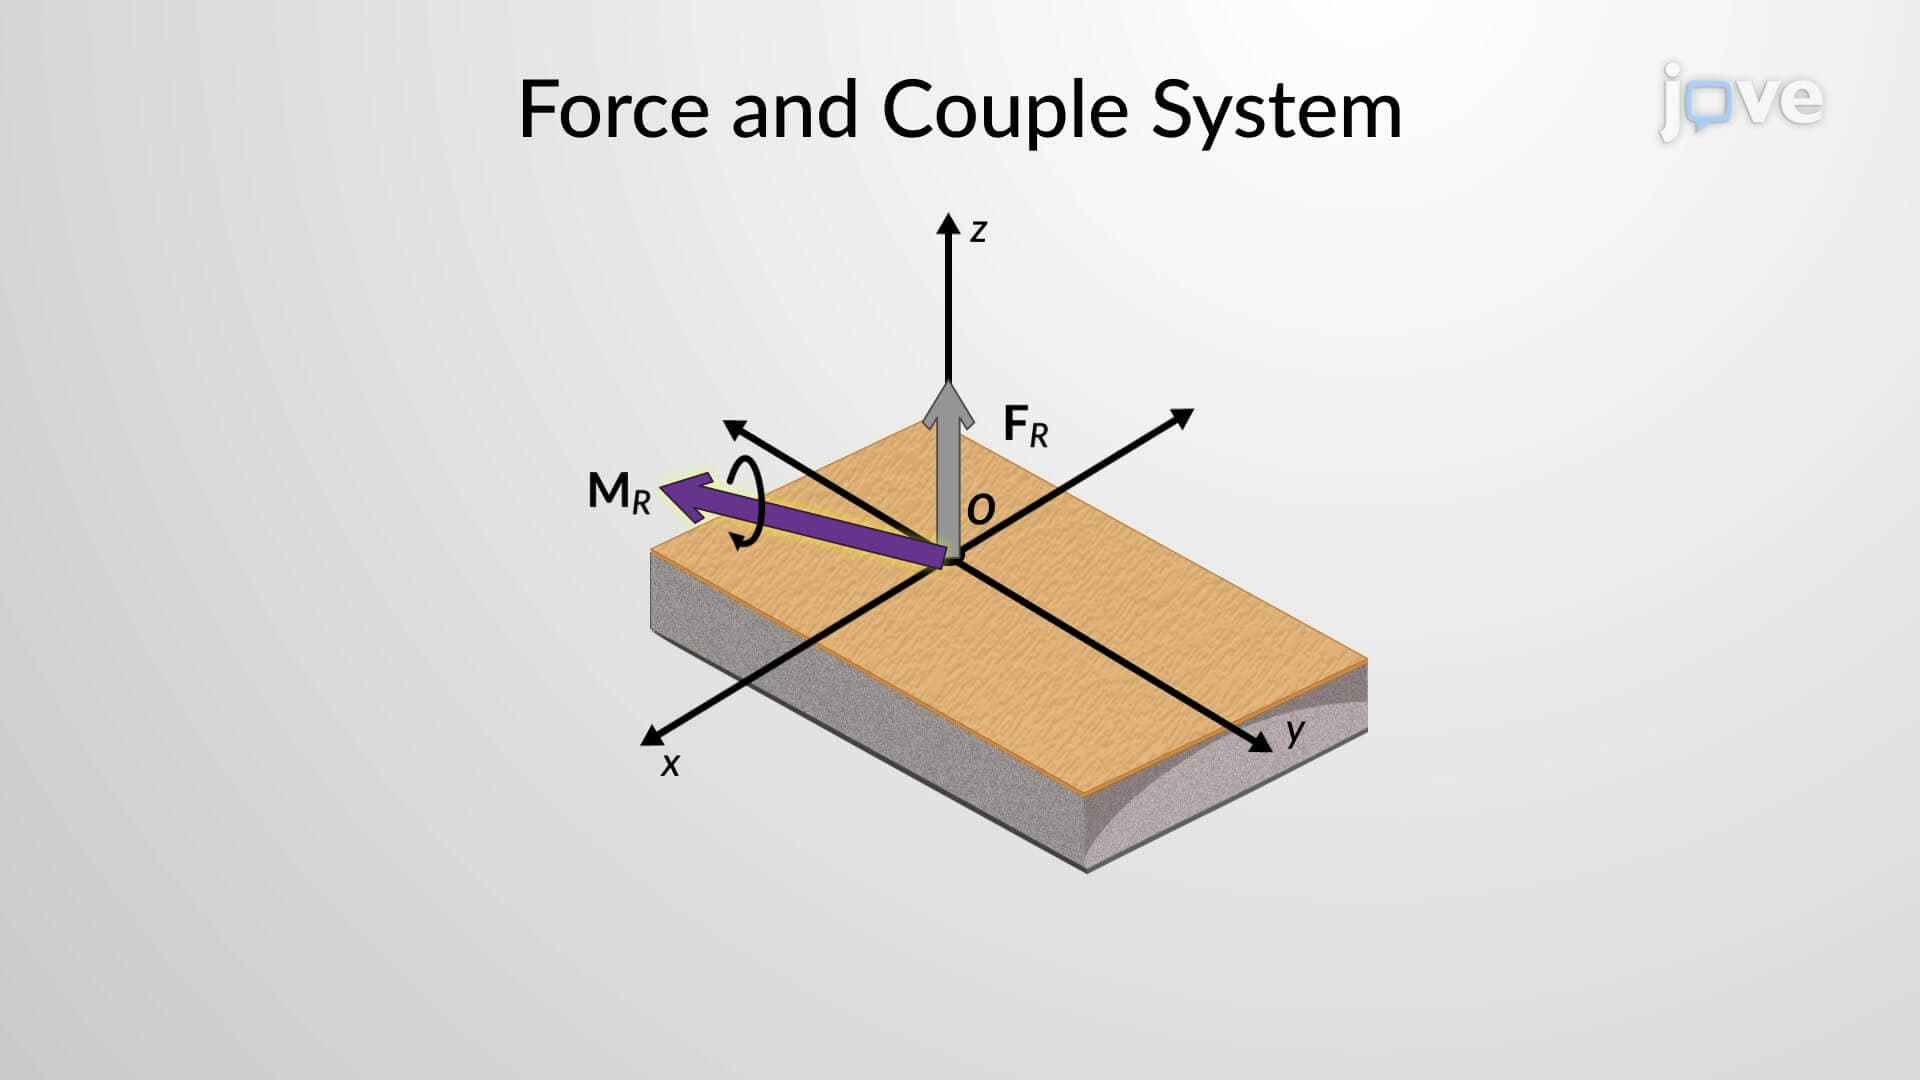 01:23
Simplification of a Force and Couple System: II
 01:11
Deformation of Member under Multiple Loadings
In the case of a member with a variable cross-section, the strain is not constant but depends on the position. The deformation of an...