强大的协作视觉惯性SLAM用于移动增强现实
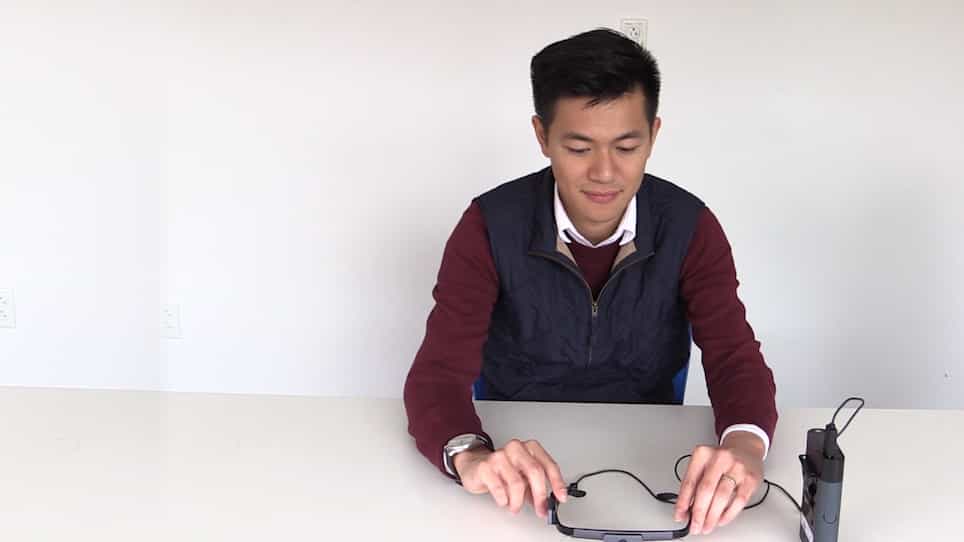
IEEE transactions on visualization and computer graphics
|September 9, 2024

概括
本研究介绍了一个强大的协作多代理视觉惯性同时定位和映射 (VI-SLAM) 系统,用于移动增强现实 (AR). 它通过合并来自多个设备的子地图来提高跟踪精度和系统稳定性,以实现一致的全球映射.
科学领域:
- 计算机视觉 计算机视觉
- 机器人技术 机器人技术 机器人技术
- 增强现实是一种增强现实.
背景情况:
- 实时本地化和稳定性是多用户移动AR的关键挑战.
- 轻量级设备需要协作信息来提高跟踪精度和系统弹性.
研究的目的:
- 为移动AR提出一个强大的集中式协作多代理VI-SLAM系统.
- 为了实现高效,一致的服务器端映射和移动设备上的实时跟踪.
主要方法:
- 一个轻量级的视觉惯性计数 (VIO) 前端在移动设备上用于跟踪.
- 一个远程服务器后台,用于更新多个子地图和执行子地图合并.
- 一个基于互联网可见性领域的地图注册和融合战略,以实现在线一致性.
主要成果:
- 该系统通过重叠区域的子地图融合实现了全球一致的映射.
- 通过将全球地图更新到本地地图,可以提高前端跟踪的准确性.
- 紧密结合的策略确保了多代理前端阵地估计的一致性.
结论:
- 拟议的VI-SLAM系统有效地提高了多用户移动AR的本地化准确性和稳定性.
- 该系统展示了高效的服务器端映射和可扩展的AR应用程序的部署.
更多相关视频
相关概念视频
 01:03
Inertial Frames of Reference
7.0K
Newton’s first law is usually considered to be a statement about reference frames. It provides a method for identifying a special type of reference frame: the inertial reference frame. In principle, we can make the net force on a body zero. If its velocity relative to a given frame is constant, then that frame is said to be inertial. So, by definition, an inertial reference frame is a reference frame where Newton's first law holds valid. Newton's first law applies to objects with...
7.0K
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
394
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
394
 01:28
Field Application of Global Positioning System
38
The Global Positioning System (GPS) has become an indispensable tool in fieldwork, offering unparalleled precision and efficiency for surveying, navigation, and infrastructure development. By harnessing signals from a constellation of satellites, GPS receivers determine the location of objects with remarkable speed and accuracy, often completing calculations within a second.Advantages of Modern GPS TechnologyContemporary GPS receivers are designed to meet the practical demands of field...
38
 01:25
Relative Motion Analysis using Rotating Axes
450
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
450
 01:27
Non-inertial Frames of Reference
5.8K
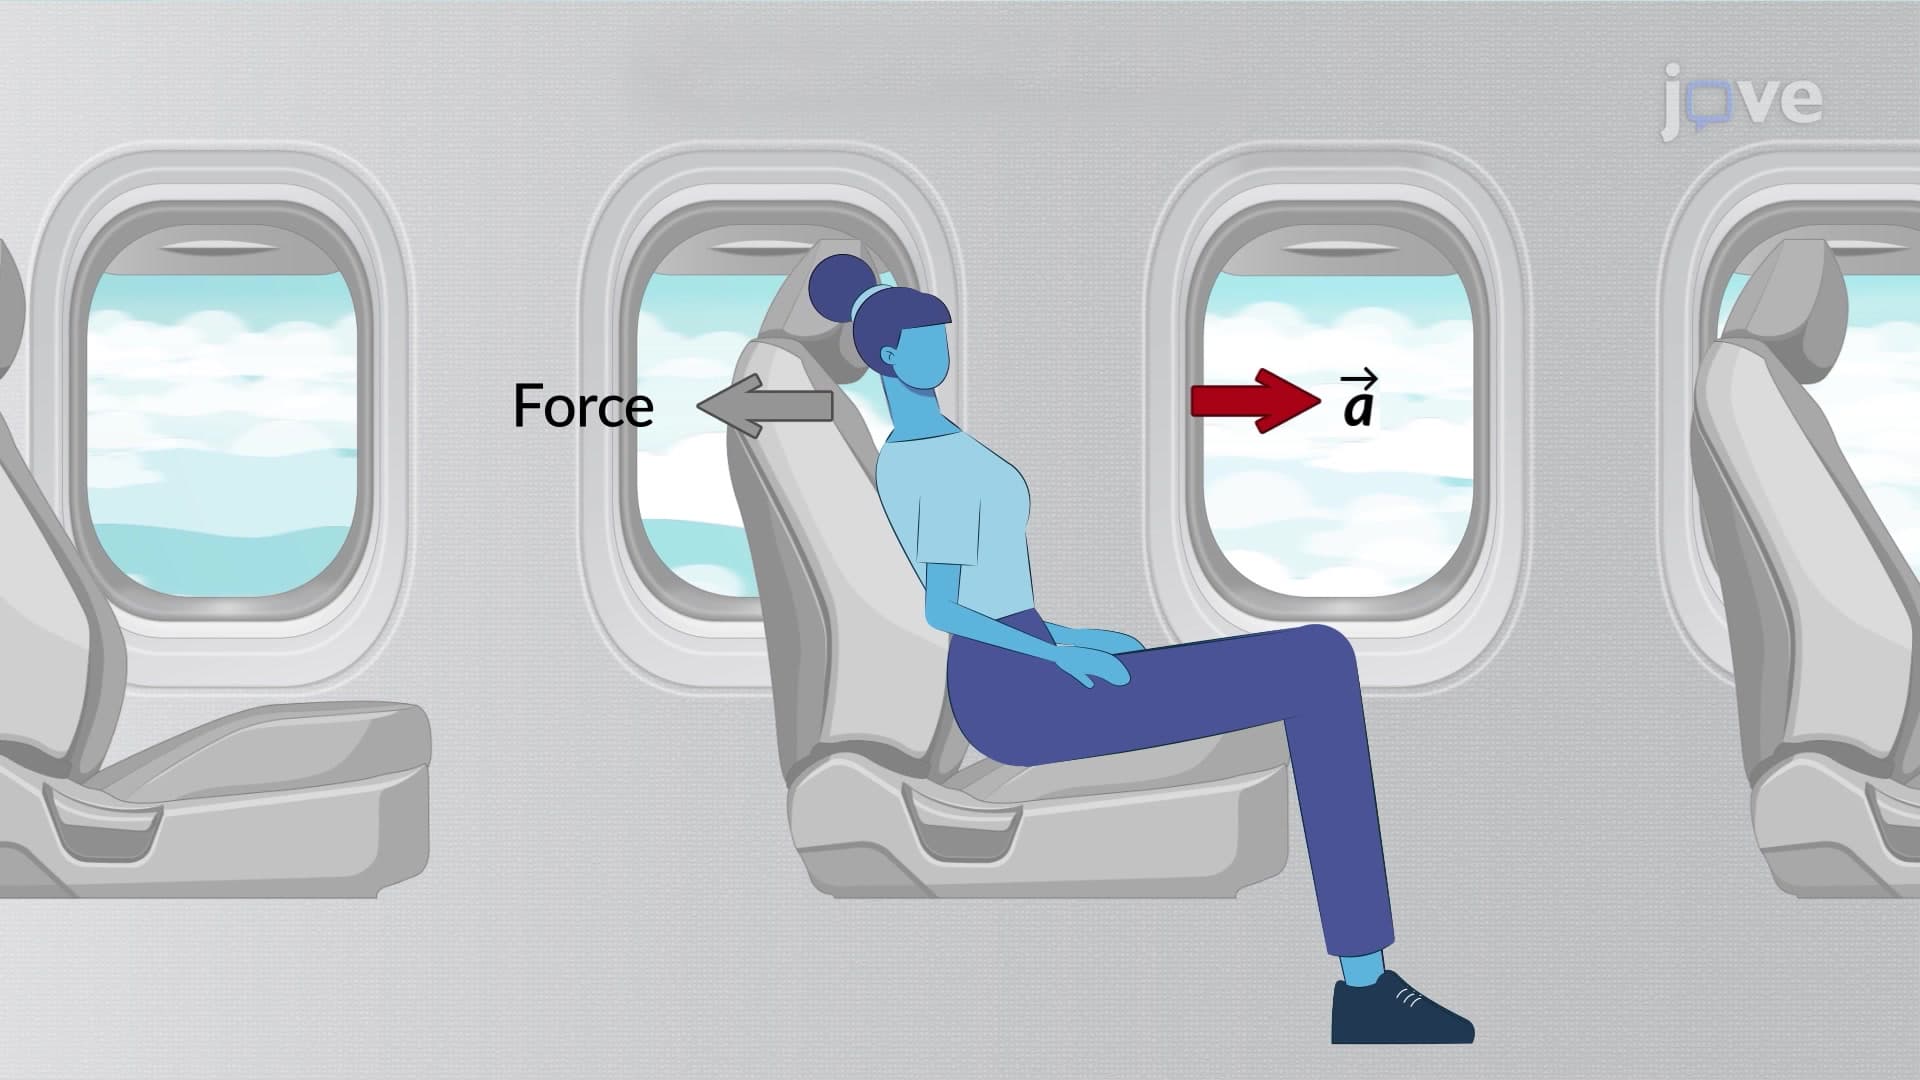
A reference frame accelerating or decelerating relative to an inertial frame is a non-inertial frame. To help understand this, consider what taking off in an airplane, turning a corner in a car, riding a merry-go-round, and the circular motion of a tropical cyclone all have in common. All these systems are accelerating, decelerating, or rotating relative to the Earth; hence, they all are non-inertial frames. All these systems exhibit inertial forces, which merely seem to arise from motion,...
5.8K
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
327
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
327