

虚拟人群病理学:评估角色表现对用户群体运动的影响
IEEE transactions on visualization and computer graphics
|September 9, 2024

概括
虚拟现实模拟有助于研究人群行为. 虚拟人群的图形表示对用户导航的影响有限,而人形模型提供了良好的平衡.
科学领域:
- 人与计算机的互动.
- 计算社会科学 计算社会科学
- 虚拟现实模拟的虚拟现实模拟.
背景情况:
- 群众数据对于建模集体行为和启用模拟用于研究或预测至关重要.
- 虚拟现实 (VR) 提供了一种通过简化实验过程来获取人群数据的解决方案.
- 评估VR技术带来的偏差对于模拟结果的有效性至关重要.
研究的目的:
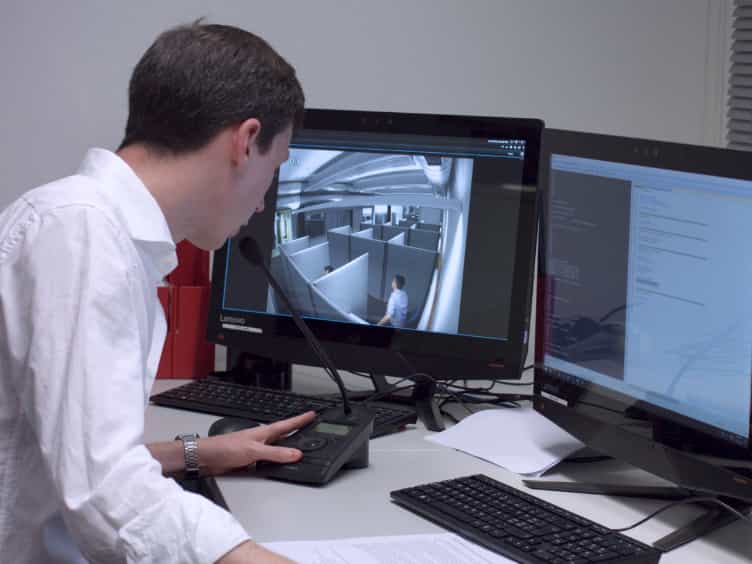
- 调查图形人群表示对沉浸式虚拟环境中的用户行为的影响.
- 基于虚拟代理的不同视觉模型来分析虚拟导航 (旅行速度,本地选择).
- 为沉浸式人群行为模拟提供设计建议.
主要方法:
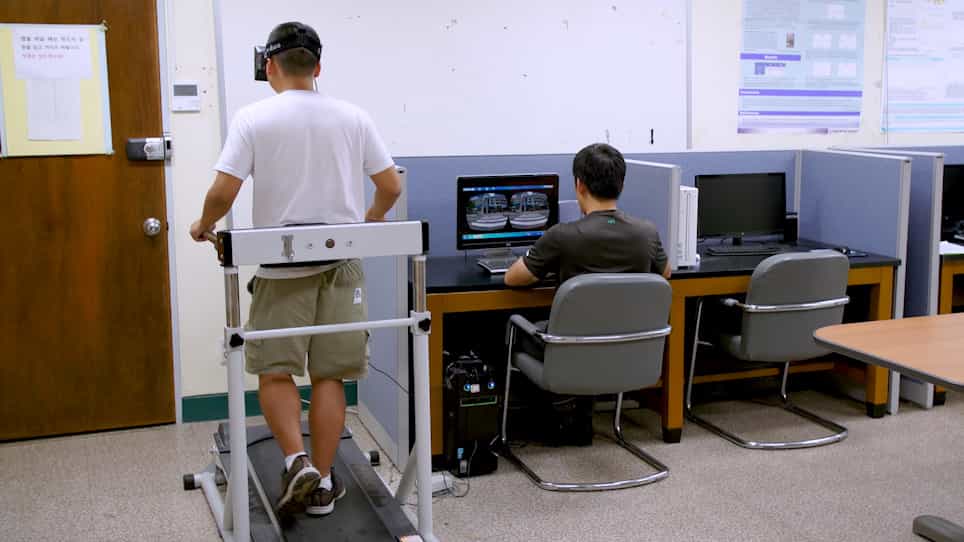
- 进行了一项实验,参与者通过不同密度的虚拟人群进行了导航.
- 虚拟代理的视觉表示系统地变化 (简单的几何模型,人形模型,现实模型).
- 收集和分析了用户导航数据,包括旅行速度和本地选择.
主要成果:
- 发现图形表示对用户行为的影响在不同人群密度之间是有限的.
- 人类形态模型提供了计算复杂性和生态有效性之间的最佳权衡.
- 对具体用户行为进行详细研究,可能更喜欢现实的模型.
结论:
- 在虚拟人群中选择图形表示对导航行为有明显但有限的影响.
- 人形模型被推用于一般人群行为模拟,因为它们的效率和有效性.
- 特定的研究问题可能需要使用更现实的代理模型进行深入分析.
相关概念视频
 01:06
Virtual Work for a System of Connected Rigid Bodies
374
Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
Next,...
374
 01:21
Rigid Body Equilibrium Problems - II
7.0K
A rigid body is in static equilibrium when the net force and the net torque acting on the system are equal to zero.
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
7.0K
 00:49
Rigid Body Equilibrium Problems - I
4.4K
A rigid body is said to be in static equilibrium when the net force and the net torque acting on the system is equal to zero. To solve for rigid body equilibrium problems, do the following steps.
4.4K
 01:11
Relative Velocity in Two Dimensions
7.1K
Relative velocity is the velocity of an object as observed from a particular reference frame, or the velocity of one reference frame with respect to another reference frame. The concept of relative velocity can be used to describe motion in two dimensions. Consider a particle P and two reference frames S and S′. The position of the origin of S′ as measured in S is , the position of P as measured in S′ is , and the position of P as measured in S is , which can be evaluated by...
7.1K
 01:22
Planar Rigid-Body Motion
414
Understanding the movement of a rigid body in planar motion involves recognizing that every particle within this body is traversing a path that maintains a consistent distance from a specific plane. This concept is fundamental in the study of physics and mechanical engineering, and it allows us to comprehend better how objects move in space.
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
414
 01:10
Relative Velocity in One Dimension
7.6K
The understanding of the concept of reference frames is essential to discuss relative motion in one or more dimensions. When we say that an object has a certain velocity, we must state the velocity with respect to a given reference frame. In most examples, this reference frame has been Earth. For instance, if a statement reads that a person is sitting in a train moving at 10 m/s east, then it implies that the person on the train is moving relative to the surface of Earth at this velocity,...
7.6K