

扩展基于卡尔曼波器的可靠滚角估计方法用于车辆
Lu Feng1,2, Peng Wu3,2,4, Linhua Zheng1
1College of Electronic Science and Technology, National University of Defense Technology, Changsha, 410073, China.
Heliyon
|September 10, 2024

概括
本研究介绍了一种使用全球导航卫星系统 (GNSS) 信号来准确测量车辆滚动角度的强大方法,即使信号中断. 与传统方法相比,新方法显著提高了精度.
科学领域:
- 工程 工程师 工程师 工程师
- 地理学就是地质学.
- 导航系统 导航系统
背景情况:
- 车辆姿势测量对于运动监测和安全至关重要.
- 旋转运动使态度角度合复杂化,影响导航和控制.
- 由于循环锁损失,现有的全球导航卫星系统 (GNSS) 方法经常在不连续的信号功率下失败.
研究的目的:
- 为使用GNSS信号的车辆开发一个可靠的滚角估计方法.
- 为了应对在态度测量中不连续的信号接收的挑战.
- 为了提高车辆滚角估计的准确性和稳定性.
主要方法:
- 一种使用Tukey重量函数用于GNSS信号功率的可靠估计方法.
- 分析GNSS信号特征和信号功率和滚动角度之间的几何关系.
- 在旋转平台上使用单贴贴天线GNSS接收器进行实验验证.
主要成果:
- 与传统的最小平方 (LS) 方法相比,提出的强大估计方法显著提高了滚角的准确性.
- 估计误差为6.57° (68%的信心) 和15.49° (95%的信心),而LS则为11.38°和37.31°.
- 算法的准确性独立于车辆的旋转速度,证明了它的稳定性.
结论:
- 强大的估计方法提高了车辆滚角测量的准确性,特别是在粗度测量误差和不连续的信号接收的情况下.
- 拟议的算法提供了高精度和稳定的滚角估计,适合各种车辆动态.
- 基于GNSS的态度测量可以通过先进的信号处理技术变得更加可靠.


相关概念视频
 01:16
Equation of Motion: General Plane motion - Problem Solving
173
Consider a lawn roller with a mass of 100 kg, a radius of 0.2 meters, and a radius of gyration of 0.15 meters. A force of 200 N is applied to this roller, angled at 60 degrees from the horizontal plane. What will be the angular acceleration of the lawn roller?
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
173
 01:30
Kinematic Equations for Rotation
320
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
320
 01:25
Relative Motion Analysis using Rotating Axes
450
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
450
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
394
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
394
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
327
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
327
 01:09
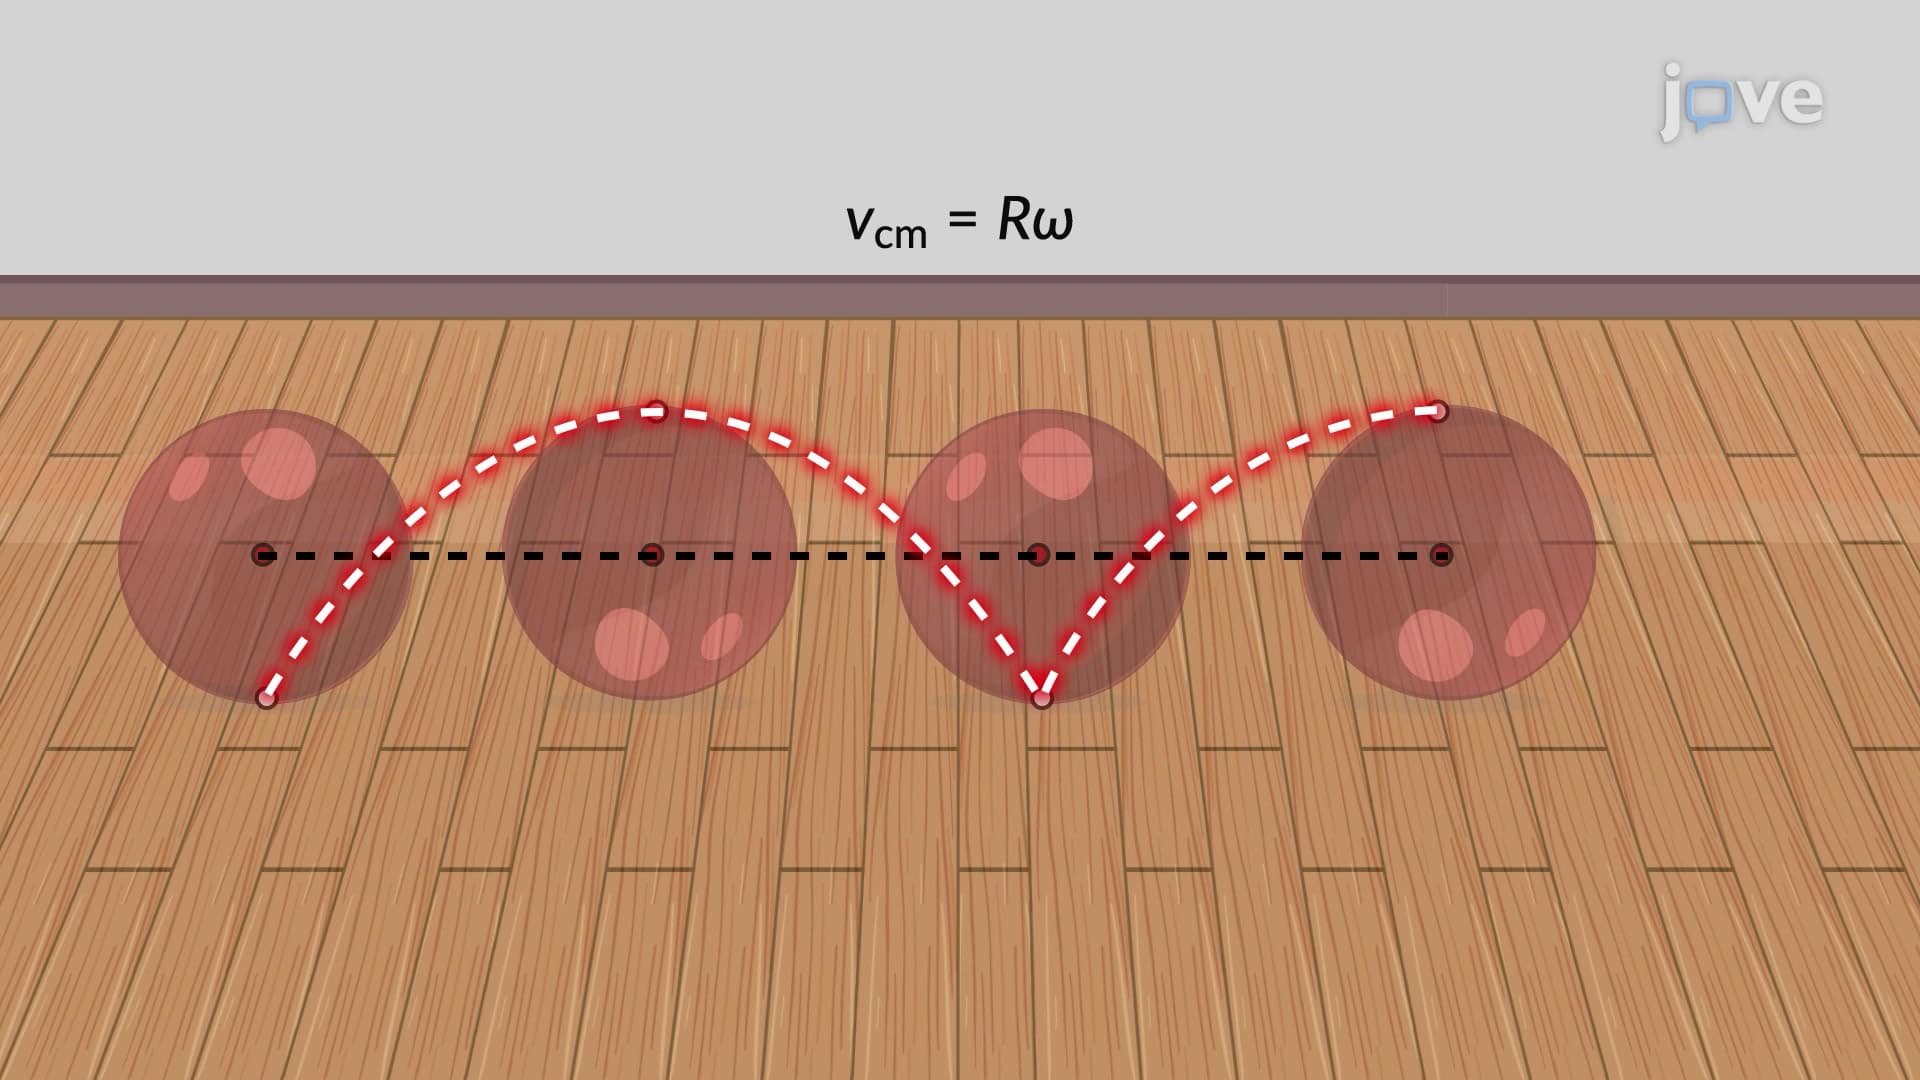
Rolling Without Slipping
3.6K
People have observed the rolling motion without slipping ever since the invention of the wheel. For example, one can look at the interaction between a car's tires and the surface of the road. If the driver presses the accelerator to the floor so that the tires spin without the car moving forward, there must be kinetic friction between the wheels and the road's surface. If the driver slowly presses the accelerator, causing the car to move forward, the tires roll without slipping. It is...
3.6K