相关实验视频
Updated: Jun 13, 2025
10:41

Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
17.5K
一种新的方法和系统实施,用于精确估计单轴旋转角度
Qinghua Yang1, Yang Shen1, Xuetao Sun1
1School of Mechatronic Engineering and Automation, Shanghai University, Shanghai 200444, China.
Sensors (Basel, Switzerland)
|September 14, 2024

概括
这项研究提出了一种用于准确单轴旋转角度估计的新方法,克服了传统技术的局限性. 开发的高精度测量系统 (HAMS) 即使与轴不对齐,也可以实现精确的测量.
科学领域:
- 工程 工程师 工程师 工程师
- 测量科学 测量科学 测量科学
- 机器人技术 机器人技术 机器人技术
背景情况:
- 传统的角度估计方法受到传感器限制,环境干扰和轴不对齐的影响.
- 现有的技术经常使用固定轴模型,导致动态测量中的重大错误.
研究的目的:
- 为精确的单轴旋转角度估计提出创新方法.
- 为了解决由传感器安装错误和轴不对齐造成的不准确性.
主要方法:
- 开发了一种校准技术,以纠正惯性测量单元和系统之间的安装错误.
- 使用三轴加速度计和零速度检测来估计旋转轴位置.
- 分析了四边形-轴-角度关系,以减少噪声和提高估计准确度.
主要成果:
- 设计并实施了一个低成本,高精度测量系统 (HAMS),集成传感器融合.
- 在±180°范围内达到±0.15°以下的静态测量误差.
- 已证明的动态测量误差在±0.5°以下,在±180°范围内.
结论:
- 拟议的方法有效地以高精度和稳定性估计单轴旋转角度.
- 在高科技应用中,HAMS系统为准确的角度测量提供了具有成本效益的解决方案.
- 这种方法成功地减轻了轴不对齐和传感器噪声造成的错误.

相关概念视频
 01:25
Relative Motion Analysis using Rotating Axes
450
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
450
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
394
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
394
 01:26
Rotational Motion about a Fixed Axis
443
A rigid body's rotation around a fixed axis makes every point within it trace a circular path around a specific line or point. The term given to this type of spinning is defined by the angular position, symbolized by the angle θ. This angle is gauged from a static reference line to the revolving object. From this angular position, any variation is referred to as angular displacement, denoted by dθ. The extent of this displacement can be calculated in degrees, radians, or...
443
 01:30
Kinematic Equations for Rotation
320
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
320
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
327
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
327
 01:37
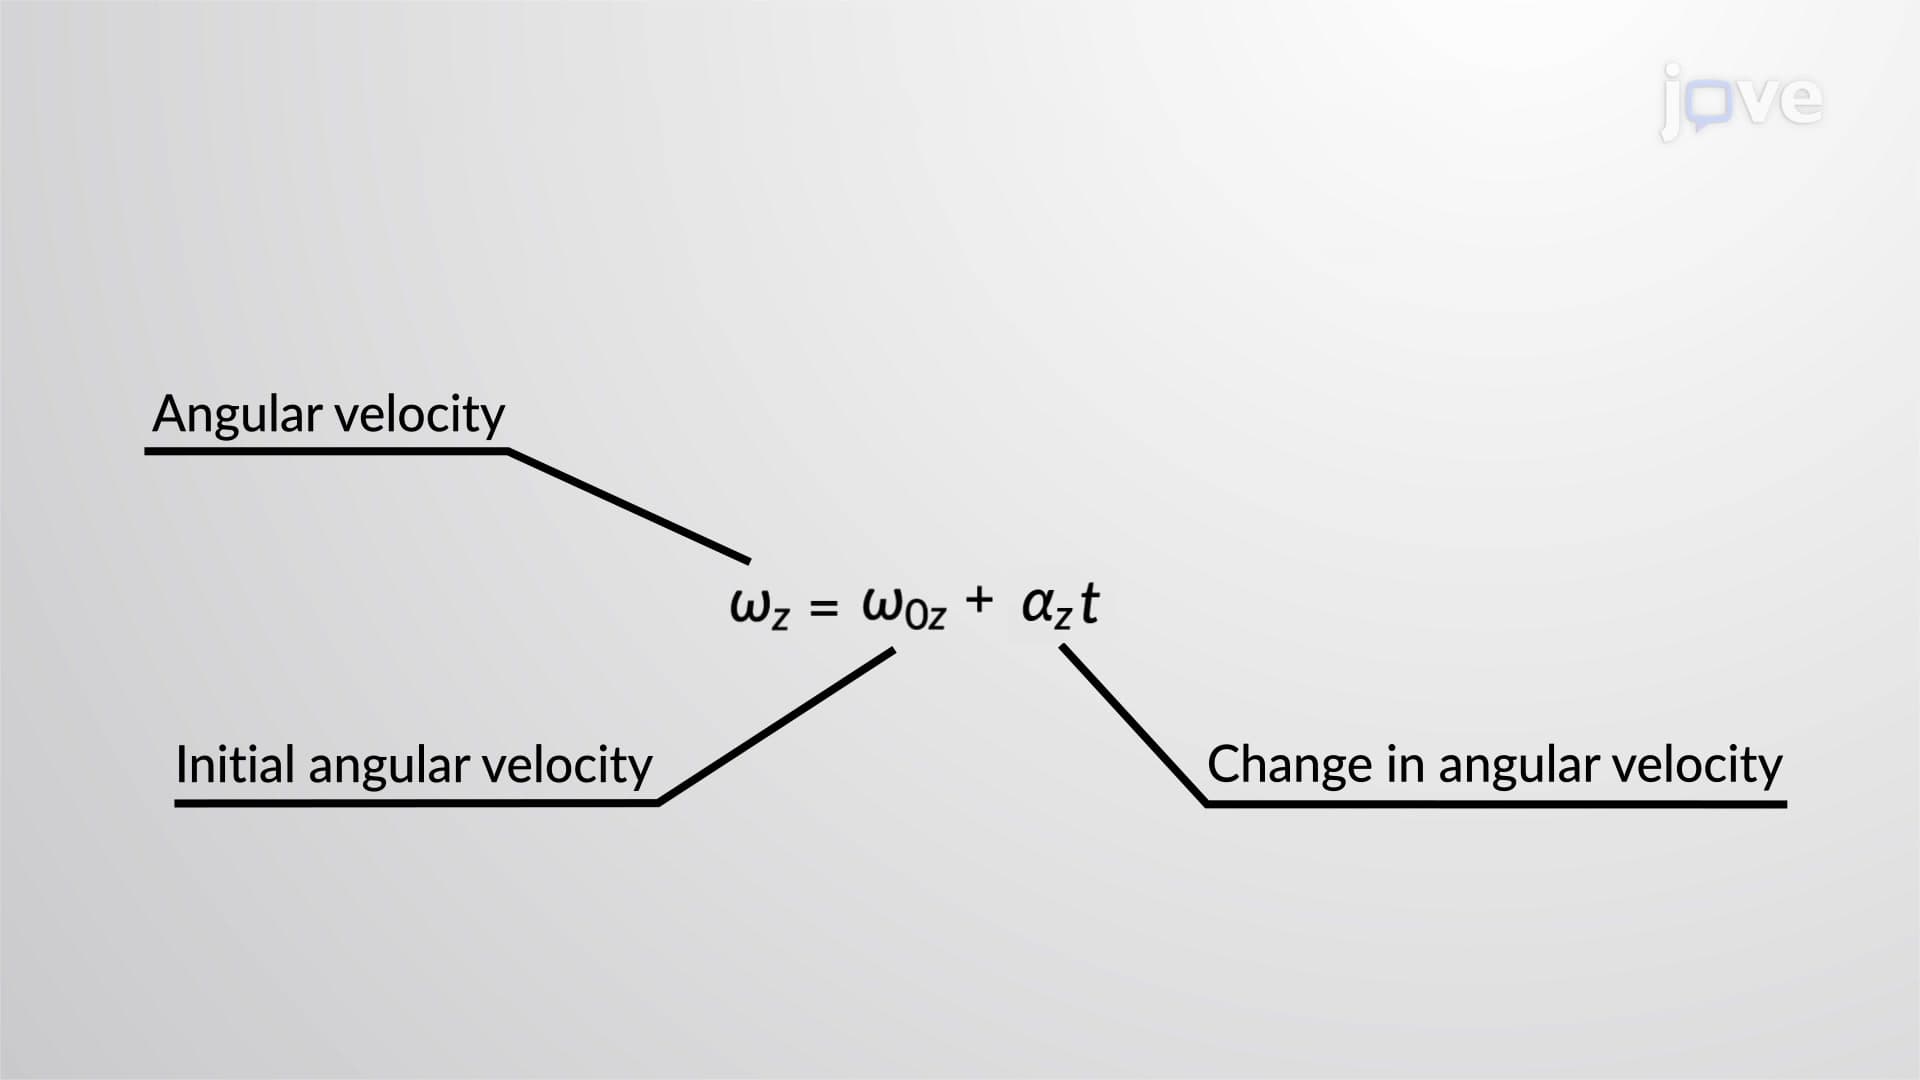
Rotation with Constant Angular Acceleration - I
6.7K
If angular acceleration is constant, then we can simplify equations of rotational kinematics, similar to the equations of linear kinematics. This simplified set of equations can be used to describe many applications in physics and engineering where the angular acceleration of a system is constant.
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
6.7K